
1T2Rの解き放たれた輪脚型再構成メカニズムの構成合成と性能分析
Jingjing Shi1, Ruiqin Li1, Wenxiao Guo1
1School of Mechanical Engineering, North University of China, Taiyuan 030051, China.
Micromachines
|August 28, 2025

まとめ
この研究では 再構成可能なロボットの脚の合成と最適化のための 新しい方法が紹介されています このアプローチは 効率的な動きと 安定した歩行を ロボットに保証し 生物学的モデルからインスピレーションを得ています
科学分野:
- ロボット
- 機械工学
- バイオメカニクス
背景:
- 再構成可能なロボットの脚は適応力を提供しますが,構成合成とパフォーマンスの最適化で課題に直面します.
- 既存のデザインには 効率的な運動計画や 歩行生成機能が欠けています
研究 の 目的:
- 再構成可能な分離された並列メカニカル脚の構成合成方法を提案する.
- 最適な足の構成を選択するための評価指標を開発する.
- ロボットにタスク固有の動作モードの選択と歩行計画を可能にします.
主な方法:
- コンフィギュレーションを合成するために,分離された並列メカニズムのための型合成理論を使用した.
- メカニズム選択のための構造的複雑性評価指数を開発した.
- 運動分析を行い 逆位置方程式を導き出し ジャコビアン行列を計算した
- 分析された作業空間と運動/力の伝達性能.
- グローバル・パフォーマンス・フラクチュエーション・インデックスを用いた 構造パラメータの最適化
- バイオニクスの原理と静的安定性基準に基づいて計画されたロボットの歩き方
主要な成果:
- 再構成可能な機械脚の構成を成功裏に合成し,評価しました.
- 2つのモーションモードで自由度の完全な分離を達成しました.
- メカニカル・レグのパラメータを最適化して 性能を向上させる
- 昆虫モードで人工足を使った ロボットの歩行計画に成功しました
結論:
- 提案された方法は,再構成可能な機械脚を効果的に合成し,最適化します.
- 開発された評価指標は,優れた構成を選択するのに役立ちます.
- このアプローチは様々なタスクに適応できる ロボット移動を容易にする.
関連する概念動画
 01:22
Controller Configurations
149
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
149
 01:24
One-Degree-of-Freedom System
555
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
555
 01:27
Support Reactions in Three Dimensions
1.1K
Support reactions in three dimensions help maintain the stability and equilibrium of various structures and systems. These reactions prevent the system from translating and rotating, ensuring the design can withstand external forces and perform its intended function efficiently and safely. Some of the supports providing support reactions in three dimensions are discussed below:
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
1.1K
 01:23
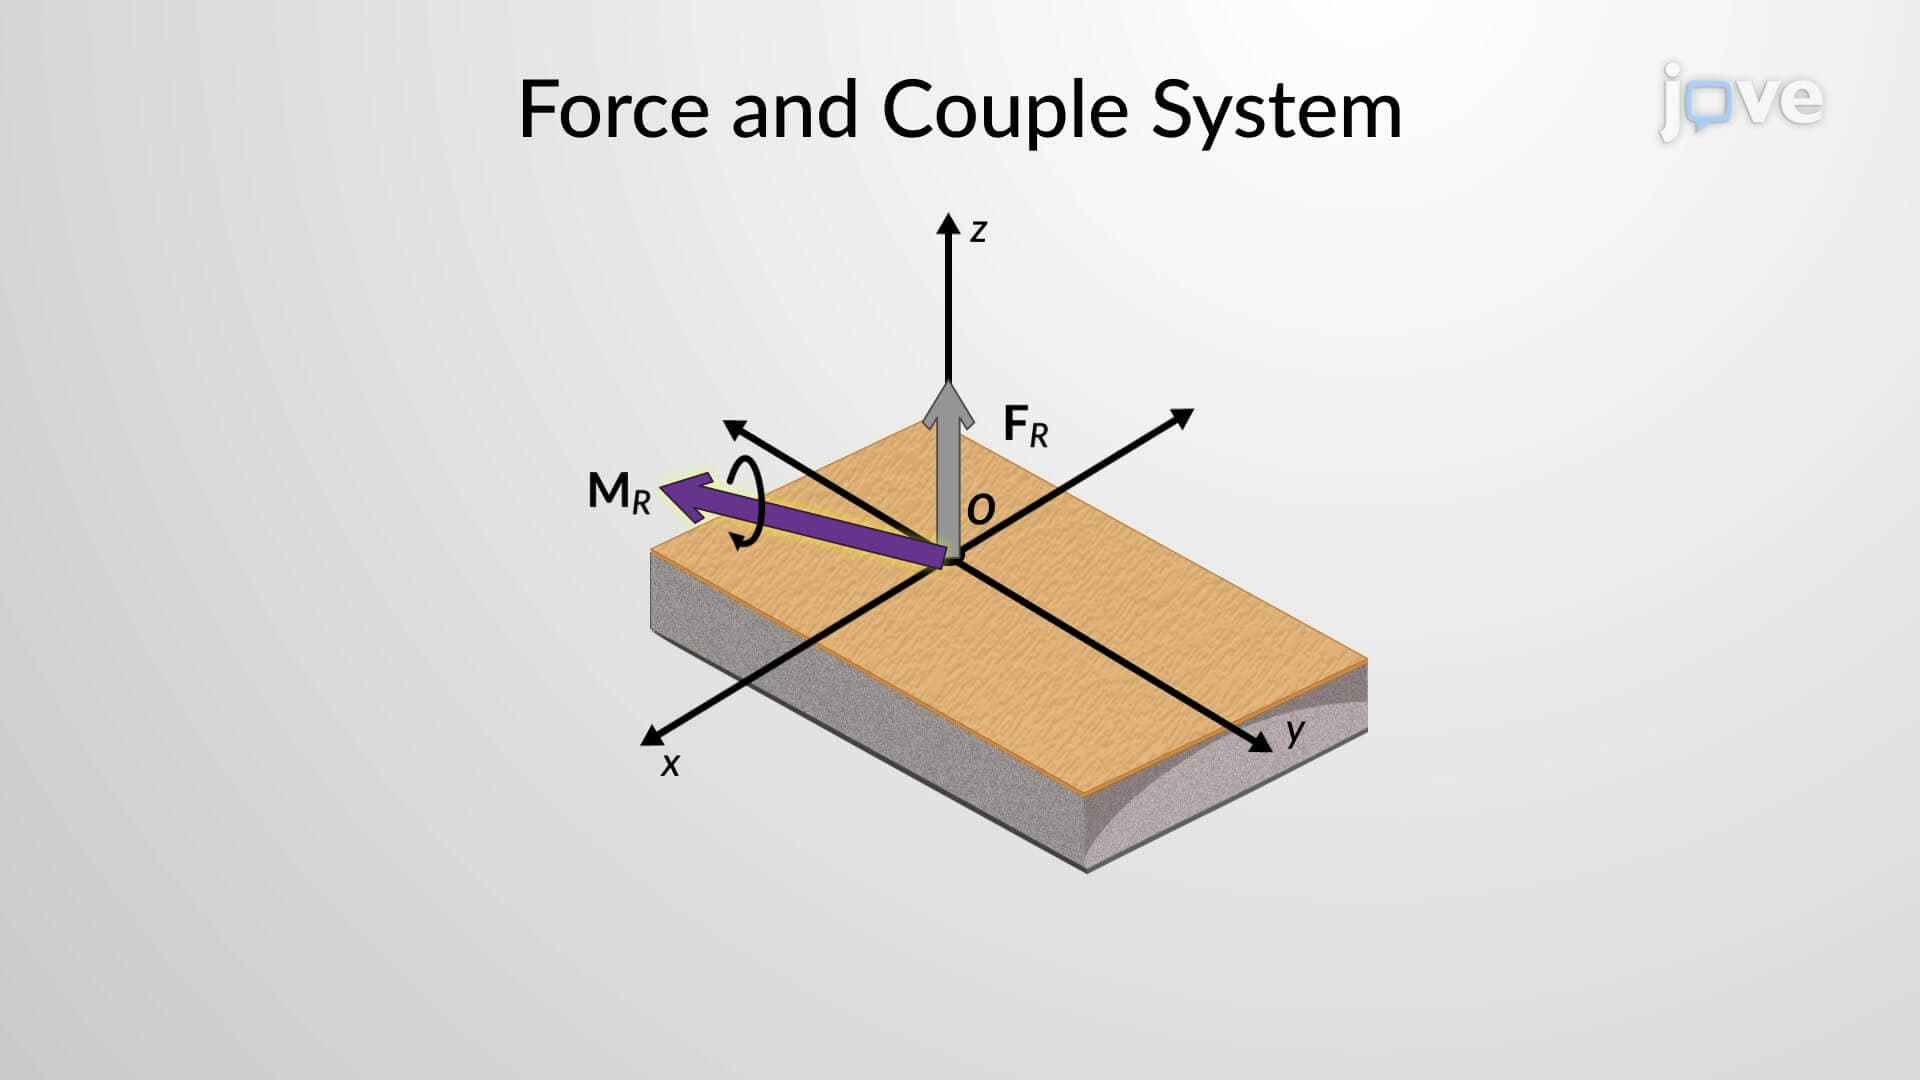
Simplification of a Force and Couple System: II
329
In a three-dimensional system, multiple forces can act on an object. These forces can be combined into a single equivalent force, known as the resultant force. Similarly, the moments generated by these forces can be combined into a single equivalent moment, the resultant couple moment. In certain situations, these two entities may not be mutually perpendicular, meaning they do not have a 90-degree angle between them. This unique condition requires a deeper understanding of the interplay between...
329
 01:30
Simplified Synchronous Machine Model
328
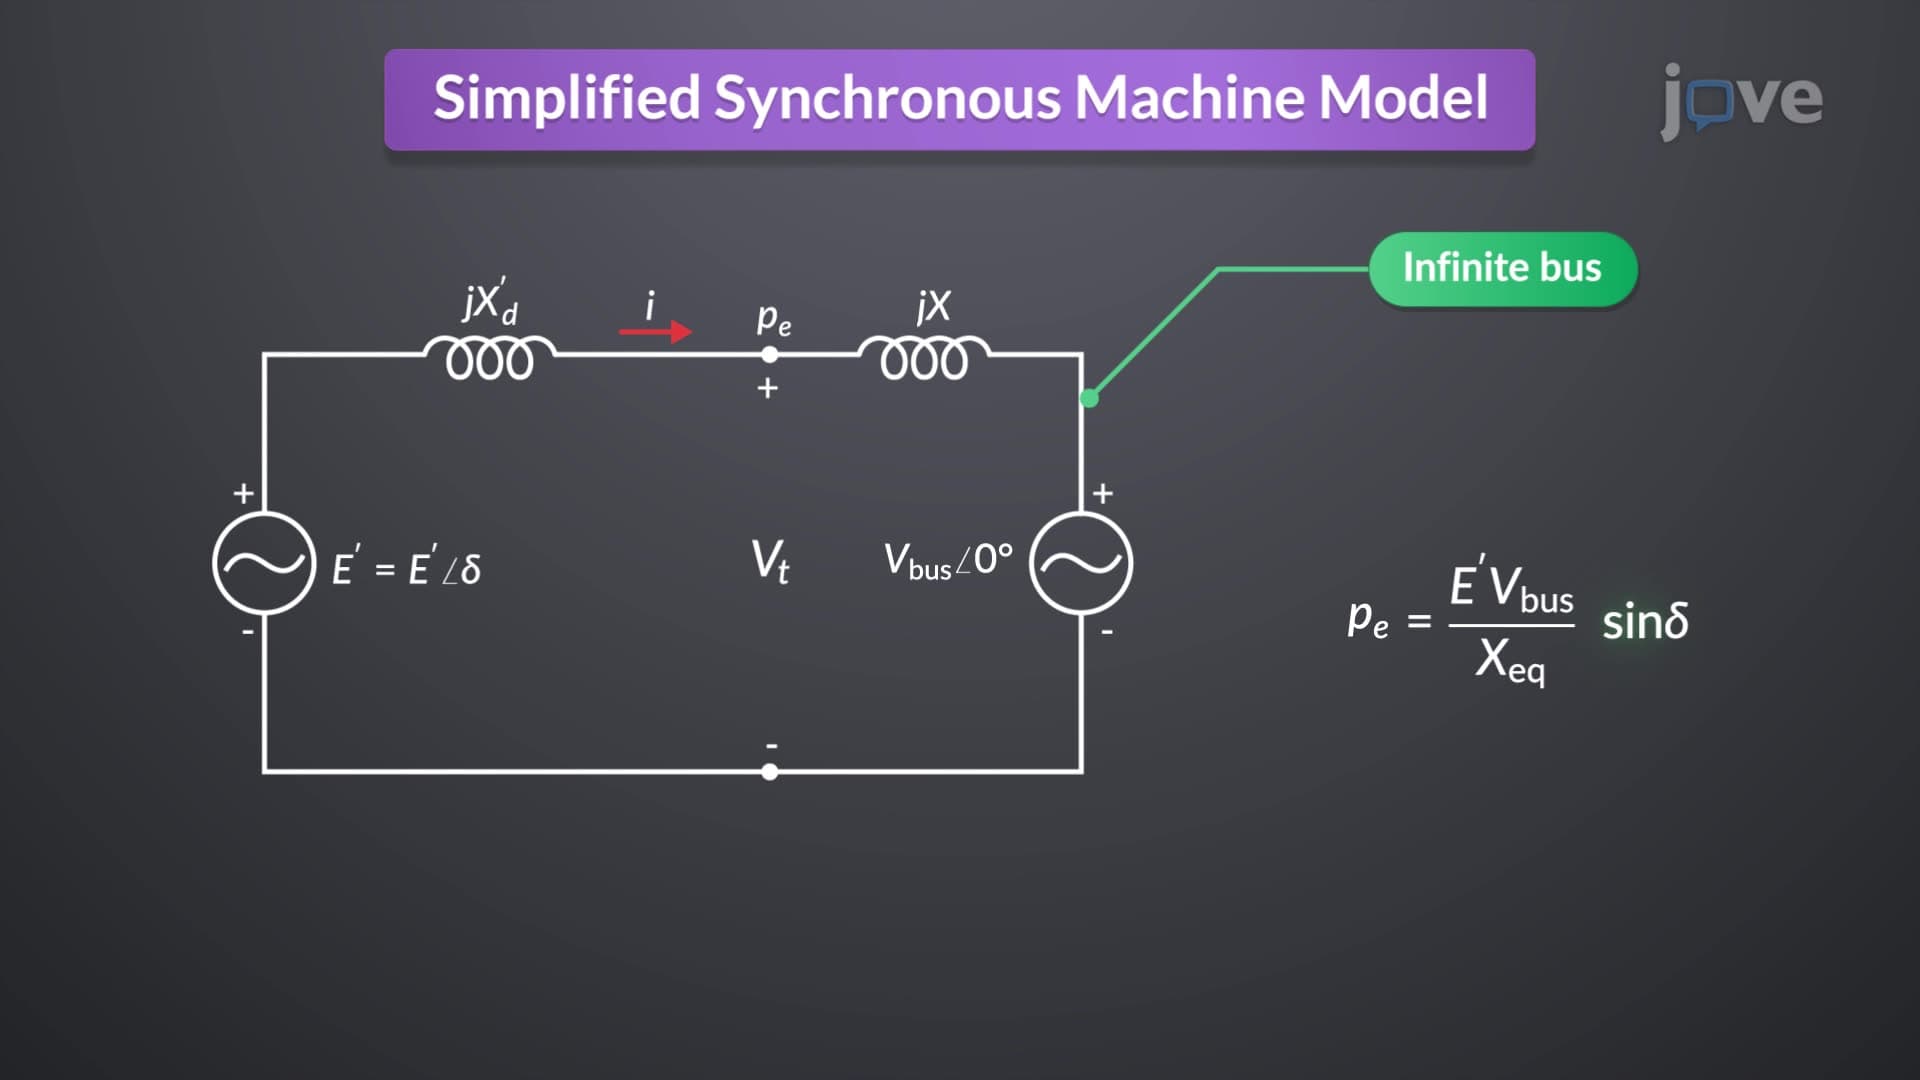
The Synchronous Machine Model is a fundamental tool in analyzing and ensuring the transient stability of power systems. This model simplifies the representation of a synchronous machine under balanced three-phase positive-sequence conditions, assuming constant excitation and ignoring losses and saturation. The model is pivotal for understanding the behavior of synchronous generators connected to a power grid, particularly during transient events.
In this model, each generator is connected to a...
In this model, each generator is connected to a...
328
 01:17
Rolling Resistance: Problem Solving
447
Rolling resistance, also known as rolling friction, is the force that resists the motion of a rolling object, such as a wheel, tire, or ball, when it moves over a surface. It is caused by the deformation of the object and the surface in contact with each other, as well as other factors like internal friction, hysteresis, and energy losses within the materials. Rolling resistance opposes the object's motion, requiring additional energy to overcome it and maintain movement. In practical...
447