関連する実験動画
Updated: May 3, 2026
07:51

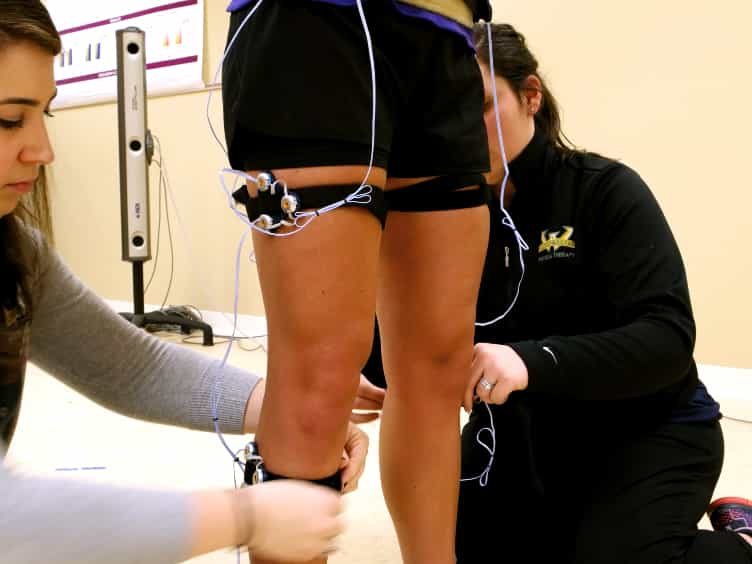
Video Movement Analysis Using Smartphones ViMAS: A Pilot Study
Published on: March 14, 2017
16.9K
非特異的な慢性腰痛サブグループにおける前向きの屈折時の脊椎運動の軌跡ベースの分析:スマートフォンによる2Dビデオ追跡
Hwa-Ik Yoo1, Il-Kyu Ahn1, Oh-Yun Kwon1
1Department of Physical Therapy, College of Software and Digital Healthcare Convergence, Yonsei University, Wonju-si, Gangwon-do, the Republic of Korea.
Journal of back and musculoskeletal rehabilitation
|August 29, 2025

まとめ
スマートフォンのビデオ分析では,非特異的な慢性腰痛 (NSCLBP) のサブグループで明確な脊髄運動パターンが示されています. 伸縮パターン (EP) グループは,屈折パターン (FP) と健康なグループよりも大きな水平移転を示しました.
科学分野:
- バイオメカニクス
- 脊髄運動
- デジタル・ヘルス
背景:
- 非特異的な慢性腰痛 (NSCLBP) の伝統的な運動範囲測定は,詳細な方向性のある洞察が欠けている.
- NSCLBPの標的の評価には 胸椎運動パターンの理解が不可欠です
研究 の 目的:
- 前向きに曲げるときの横と垂直の胸部 (T12,L2) の移動を分析する.
- NSCLBPサブグループ (屈折パターン [FP],伸縮パターン [EP]) と健康な対照群の脊髄運動を比較する.
- NSCLBPの運動を評価するためにスマートフォンベースの2Dビデオ分析を評価する.
主な方法:
- 185人の参加者 (58人の健康者,87人のFP,40人のEP) を分析した.
- スマートフォンの2Dビデオ分析 (Kinoveaソフトウェア) で追跡されたT12およびL2の棘状プロセス上のマーカー.
- 前後 (x軸) と上下 (y軸) の位移を定量化した.
主要な成果:
- EPグループは,FPグループと比較して,T12とL2で前部位移転が著しく増加した.
- EPグループは,健康な対照群よりもL2でより大きな前部移位を示した.
- 垂直の移動やFPと健康なグループの間の有意な違いは観察されなかった.
結論:
- 水平移動の軌道はNSCLBPのサブグループを効果的に区別し,特にEPグループのユニークな移動戦略です.
- スマートフォンベースのビデオ分析は,サブグループ特有のNSCLBP評価のためのアクセスしやすく,臨床的に価値のあるツールを提供します.
さらに関連する動画
関連する概念動画
 01:24
Relative Motion Analysis - Velocity
975
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
975
 01:25
Relative Motion Analysis using Rotating Axes
1.0K
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
1.0K
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
839
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
839
 01:10
Relative Motion Analysis - Acceleration
1.1K
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
1.1K
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
1.0K
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
1.0K