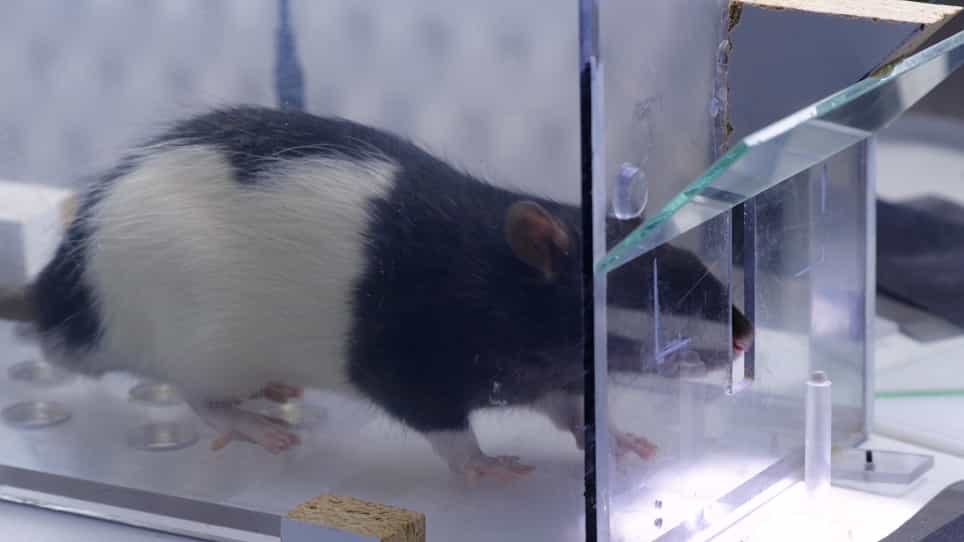
関連する実験動画
Updated: Jan 8, 2026
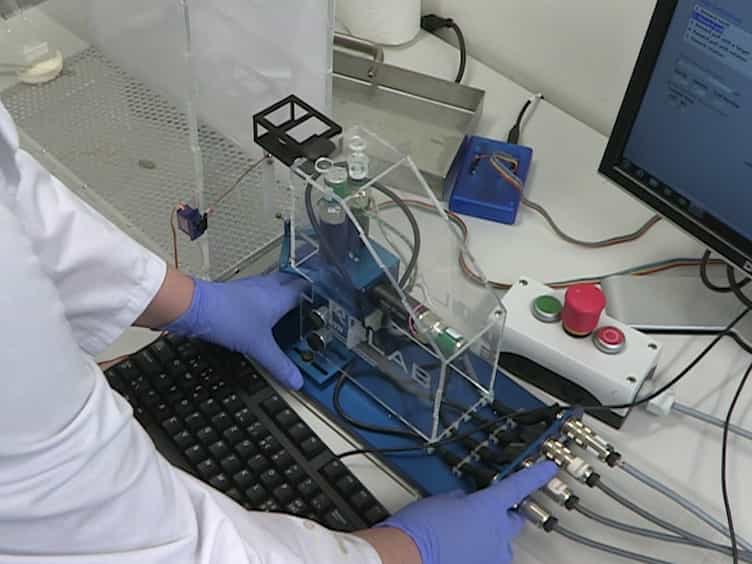
Investigating Motor Skill Learning Processes with a Robotic Manipulandum
Published on: February 12, 2017
ペックマン反応ネットワークのロボット支援再構築と制御
Bibek Prajapati1, Wai-Shing Wong1, Rafał Frydrych1
1IBS Center for Algorithmic and Robotized Synthesis (CARS), Ulsan National Institute of Science and Technology, 50 UNIST-gil, Ulsan, 44919, Republic of Korea.

Abstract:
A robotic platform was deployed to map the distributions of products and by-products of the classic Pechmann reaction over a four-dimensional "hyperspace" of conditions. This systematic scan reveals the presence of 15 products of which 11 are unprecedented, including those forming by unusual mechanistic routes. In turn, the knowledge of the hyperspace allows for the deduction of causal relationships between the forming species, ultimately enabling the reconstruction of the underlying reaction network. The hyperspace approach provides a more complete description of organic reactions as dynamic networks which, depending on conditions, can be steered toward different outcomes.