legged robot locomotionにおける模倣学習:サーベイ
関連する実験動画
Updated: May 6, 2026
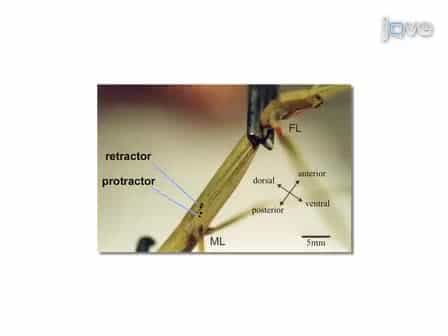
Studying the Neural Basis of Adaptive Locomotor Behavior in Insects
Published on: April 13, 2011
Khojasteh Z Mirza1, Shubham Singh2
1Friedman Brain Institute, Icahn School of Medicine at Mount Sinai, New York, NY, United States.

Abstract:
Imitation learning (IL) has fundamentally transformed the field of legged robot locomotion, removing the dependence on hand-engineered reward functions. Since 2019, this area of research has progressed rapidly, from simple motion-capture replication to the generation of sophisticated policies using diffusion models. This survey offers a comprehensive analysis of 35 pivotal research works, using a structured six-dimensional framework to investigate advancements using quadrupedal and humanoid platforms. The review also pinpoints significant challenges related to deployment and outlines new research directions. A key finding from the survey indicates that behavior cloning is utilized in almost half of the analyzed studies. Moreover, data generated through model-predictive control (MPC) now represents the most frequently used training data source for advanced imitation learning systems.
関連する概念動画
 01:23
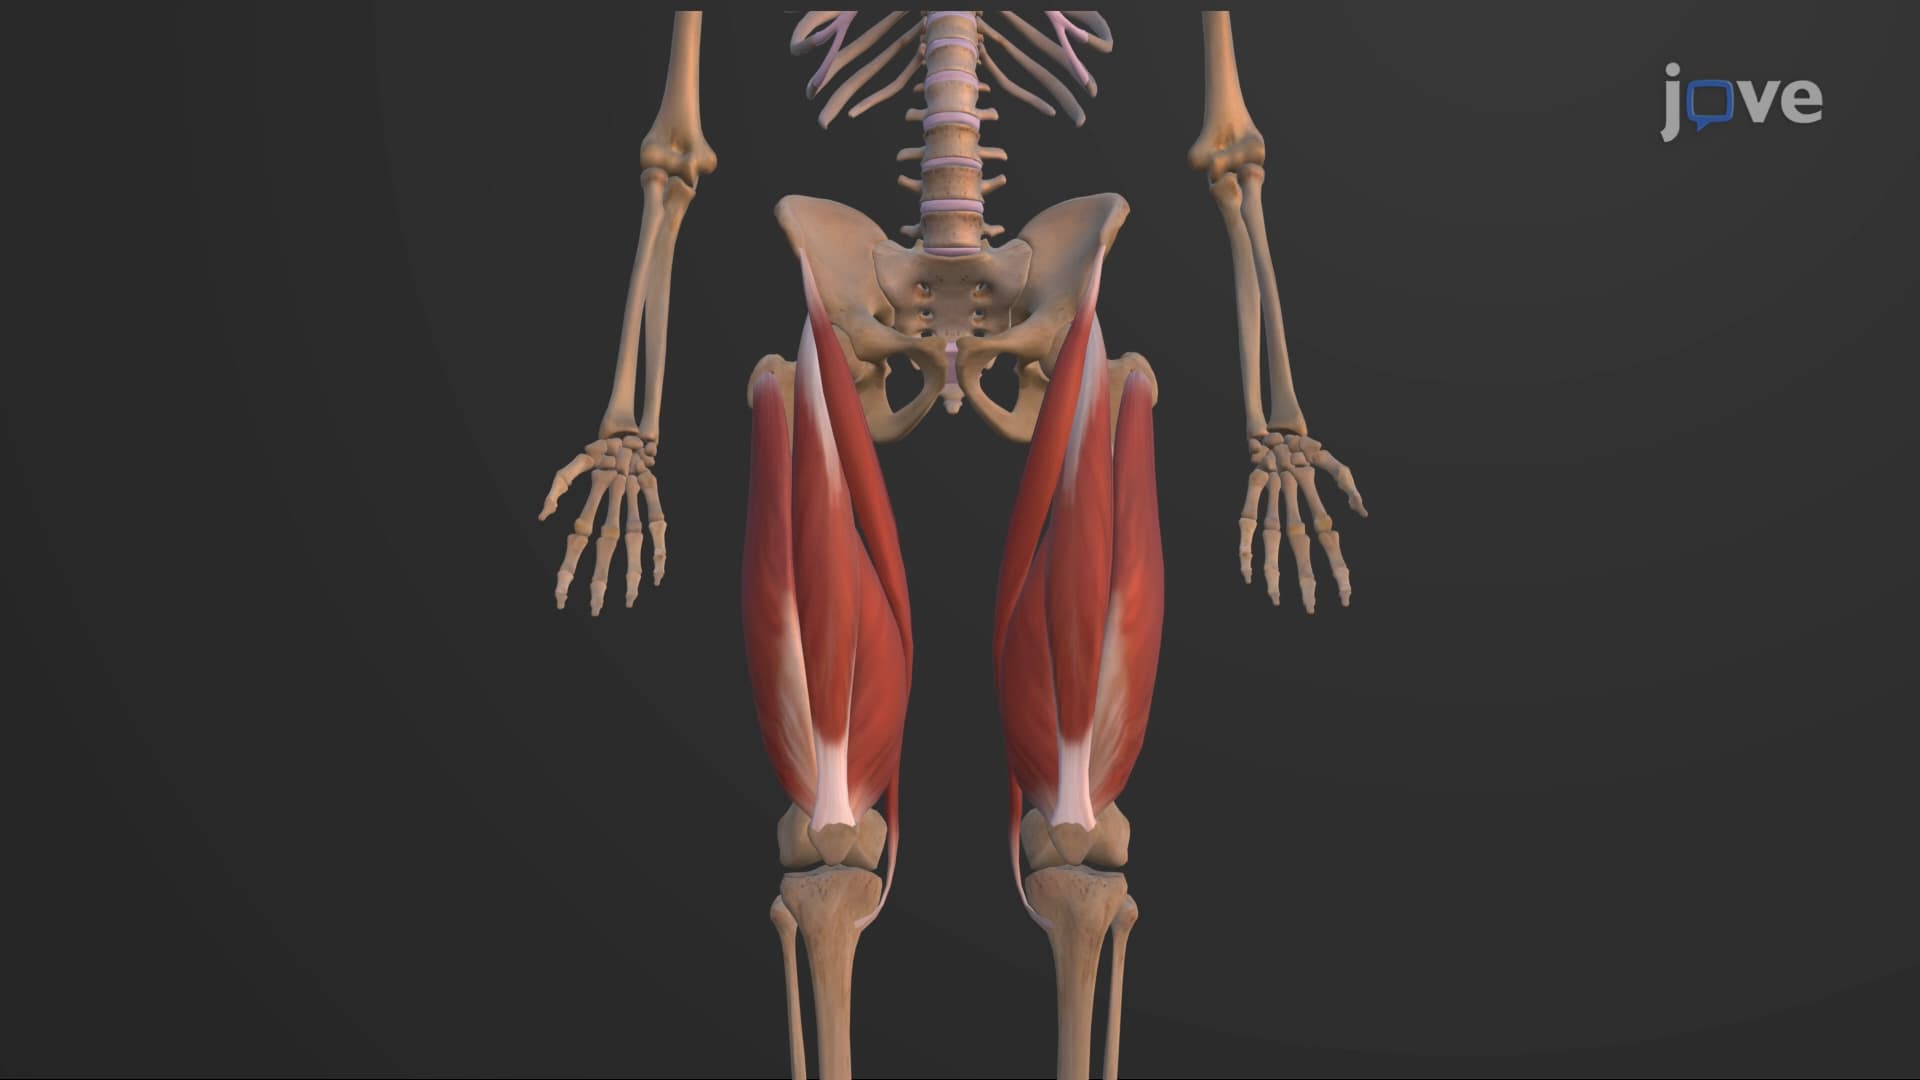
Muscles that Move the Leg
Anterior Compartment
The quadriceps femoris, the most visible muscle of the anterior compartment, is integral for leg extension and thigh flexion. It is formed by merging four distinct muscles — the vastus lateralis, vastus medialis, vastus intermedius, and rectus femoris. The quadriceps tendon, a shared tendon of the four quadriceps muscles, is affixed...
 01:12
Observational Learning