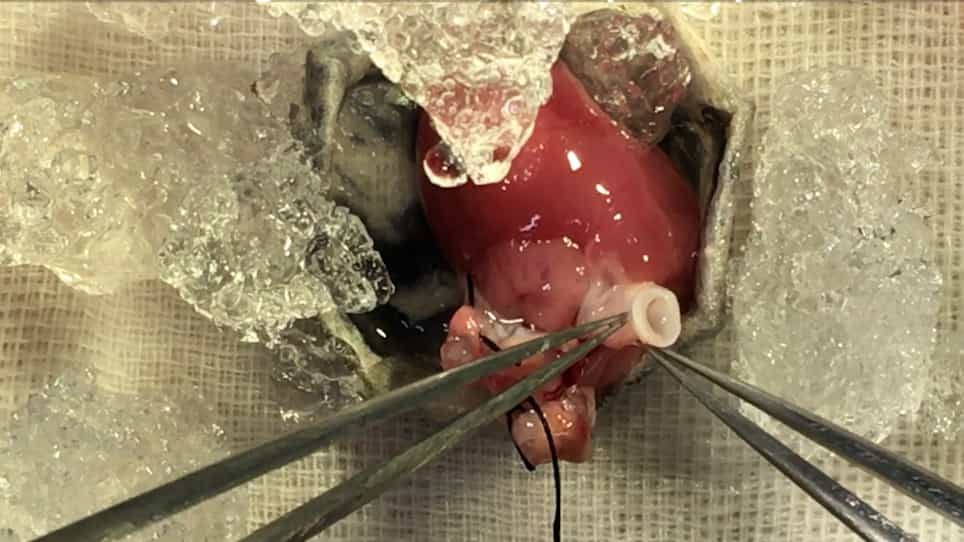

ロボット支援による上行大動脈置換術:解剖学的モデルにおける実現可能性の研究
Bryant W Fisher1, Hubert Stein2, Olga Greenberg2
1Department of Cardiothoracic Surgery, UPMC, Pittsburgh, PA, USA.

Objectives:
Robotic cardiac surgery is well established in mitral valve repair and coronary artery bypass grafting. Outside of limited applications addressing abdominal aorta, robotic technology is rarely utilized in vascular surgery. Robotic replacement of the ascending aorta has not yet been described. The aim of this experimental study was to establish the fundamental surgical techniques for robotically assisted replacement of the ascending aorta.
Methods:
Robotic ascending aortic replacement was performed in 6 porcine thoracic organ packs and 2 human cadaver models by an experienced robotic surgeon and a surgical resident. All essential steps of the procedure were performed utilizing the DaVinci 5 robotic platform. Dacron grafts were implanted after ascending aorta resection in all models. Operative times and comfort level were recorded for each step of the procedure.
Results:
Robotically assisted ascending aortic replacement was deemed feasible in all porcine and human cadaveric simulations. Distal and proximal anastomoses in the porcine organ block were completed in 10.7 (SD 4.5) and 9.7 (SD 3.2) min, respectively. Anastomotic times were slightly longer in the cadaveric model at 13.3 (SD 2.0) and 12.3 (SD 1.9) min. No gaps in suture alignment were noted in the porcine organ model whereas 4 gaps out of 273 stitches in the human cadaveric model were observed.
Conclusions:
Robotic replacement of the ascending aorta is technically feasible in anatomical models with reasonable anastomotic times which may be suitable for the clinical setting. Robotic suturing on the ascending aorta can be performed with accuracy and efficiency.
さらに関連する動画
 06:51
Author Spotlight: Development of a Minimally Invasive Large-Animal Model for Reliable and Reproducible Cardiovascular Research
Published on: October 20, 2023
 07:46
Author Spotlight: Revolutionizing Remote Surgery with Augmented Reality and Robotics for Enhanced Precision and Accessibility
Published on: August 9, 2024