
3D-AOAモデルの状態制限およびノイズ分離型擬似線形カルマンフィルタリングアルゴリズム
Jinjie Huang1, Qingyang Jia1, Hengyu Liang2
1School of Automation, Harbin University of Science and Technology, Harbin, 150080, China.
ISA transactions
|January 4, 2026

まとめ
No abstract available in PubMed .
関連する概念動画
 01:20
Calibration Curves: Linear Least Squares
4.0K
A calibration curve is a plot of the instrument's response against a series of known concentrations of a substance. This curve is used to set the instrument response levels, using the substance and its concentrations as standards. Alternatively, or additionally, an equation is fitted to the calibration curve plot and subsequently used to calculate the unknown concentrations of other samples reliably.
For data that follow a straight line, the standard method for fitting is the linear...
For data that follow a straight line, the standard method for fitting is the linear...
4.0K
 01:26
Linear Approximation in Frequency Domain
329
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
329
 01:21
Linear Approximation in Time Domain
314
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
314
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
675
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
675
 01:18
Kinematic Equations - III
10.2K
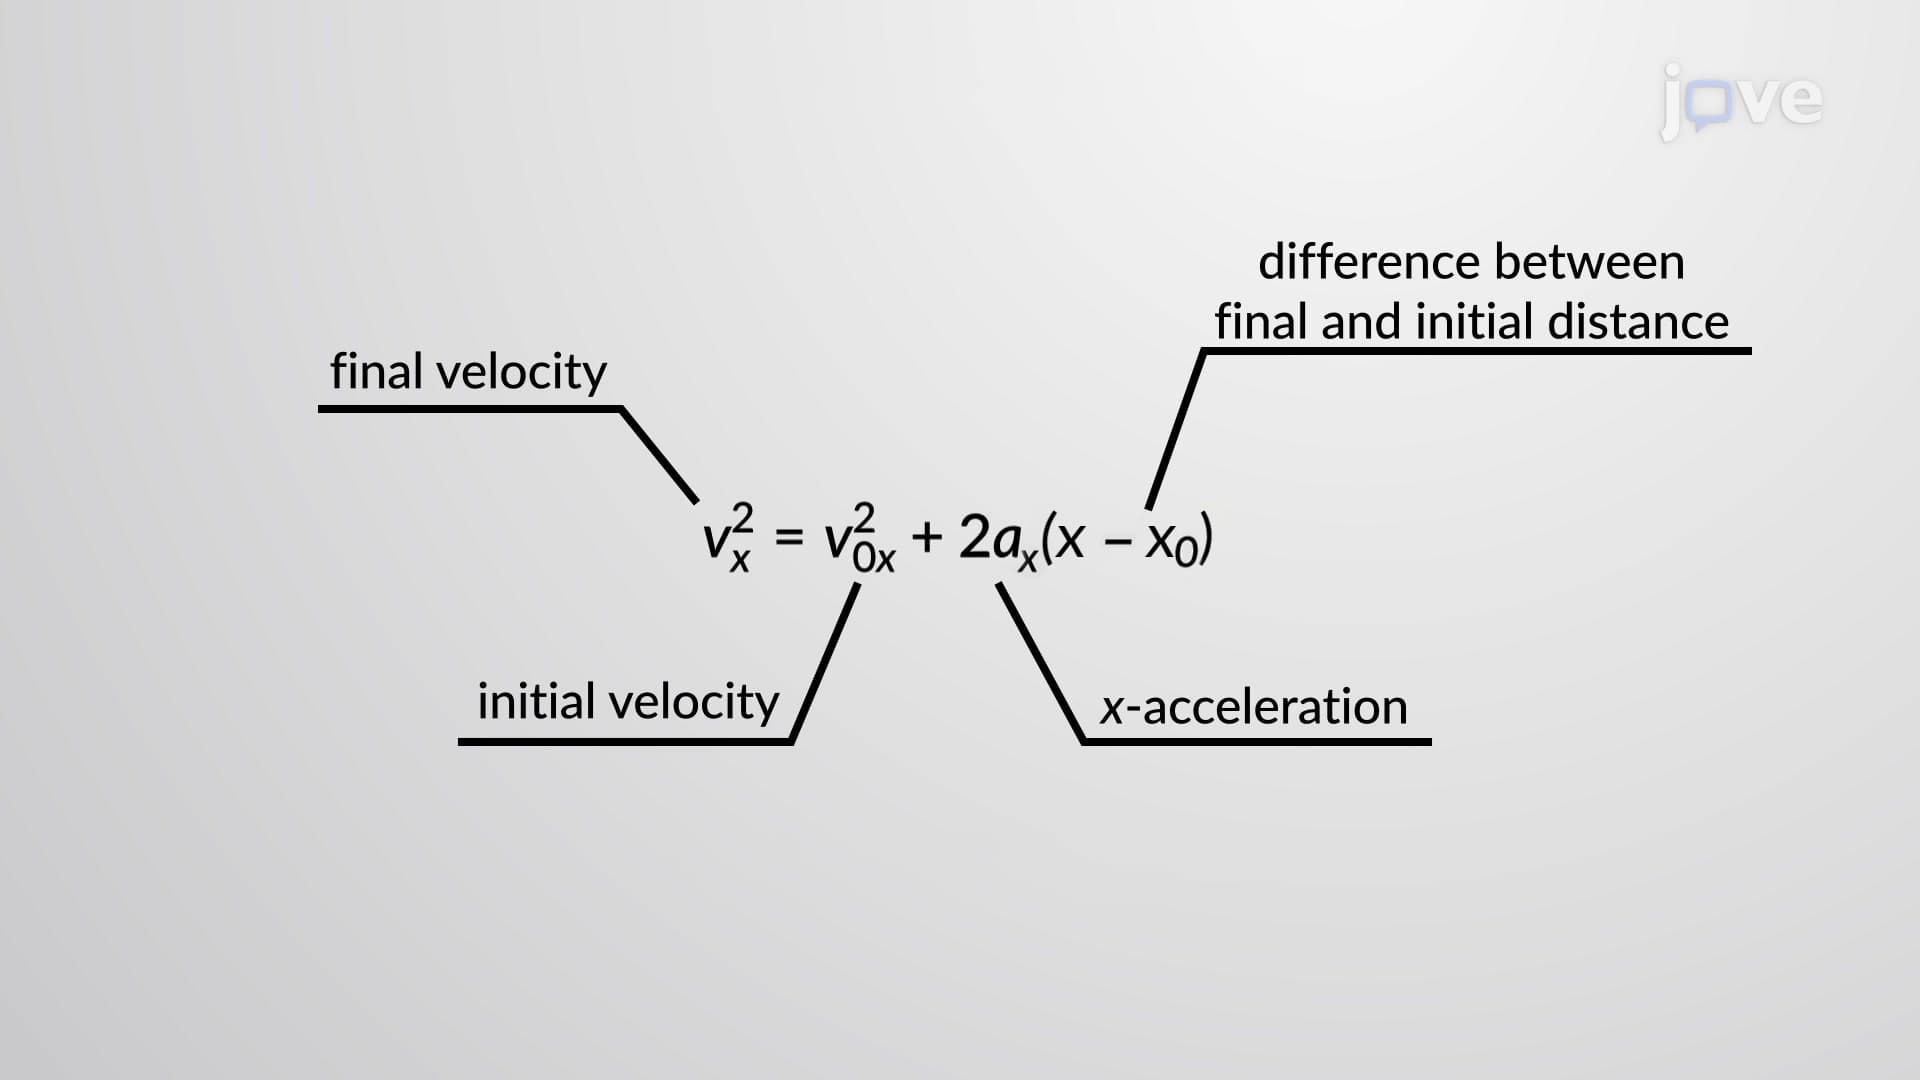
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
10.2K
 01:25
Relative Motion Analysis using Rotating Axes
854
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
854