関連する実験動画
Updated: Jan 14, 2026
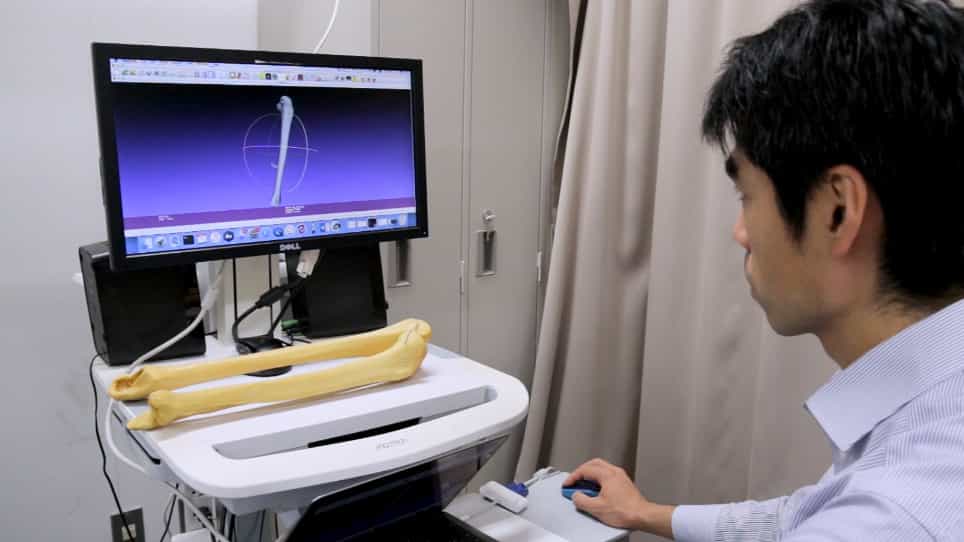
Four-Dimensional CT Analysis Using Sequential 3D-3D Registration
Published on: November 23, 2019
OIF-PCR++: 条件付き位置エンコーディングの段階的蒸留による点群レジストレーション

Abstract:
Transformer architecture has shown significant potential in various visual tasks, including point cloud registration. Positional encoding, as an order-aware module, plays a crucial role in Transformer framework. In this paper, we propose OIF-PCR++, a conditional positional encoding (CPE) method for point cloud registration. The core CPE module utilizes length and vector encoding at different stages, conditioned on the relative pose states between the point clouds to be registered. As a result, it progressively alleviates the feature ambiguity through the incorporation of geometric cues. Building upon the proposed CPE, we introduce an iterative positional encoding optimization pipeline comprising two stages: 1) We find one correspondence via a differentiable optimal transport layer, and use it to encode length information into the point cloud features, which alleviates challenges arising from differing reference frames by enhancing spatial consistency. 2) We apply a progressive direction alignment strategy to achieve rough alignment between the paired point clouds, and then gradually incorporate direction information with the aid of this alignment, further enhancing feature distinctiveness and reducing feature ambiguity. Through this iterative optimization process, length and direction information are effectively integrated to achieve consistent and distinctive positional encoding, thus enabling the learning of discriminative point cloud features. Additionally, we present an inlier propagation mechanism that harmoniously integrates consistent geometric information for positional encoding. The proposed positional encoding is highly efficient, introducing only a marginal increase in computational overhead while significantly improving feature distinguishability. Extensive experiments demonstrate that our method achieves superior performance compared to state-of-the-art methods across indoor, outdoor, object-level, and multi-way benchmarks, while also generalizing well to complex real-world scenarios. The code will be released upon acceptance to support the research community.
関連する概念動画
 01:00
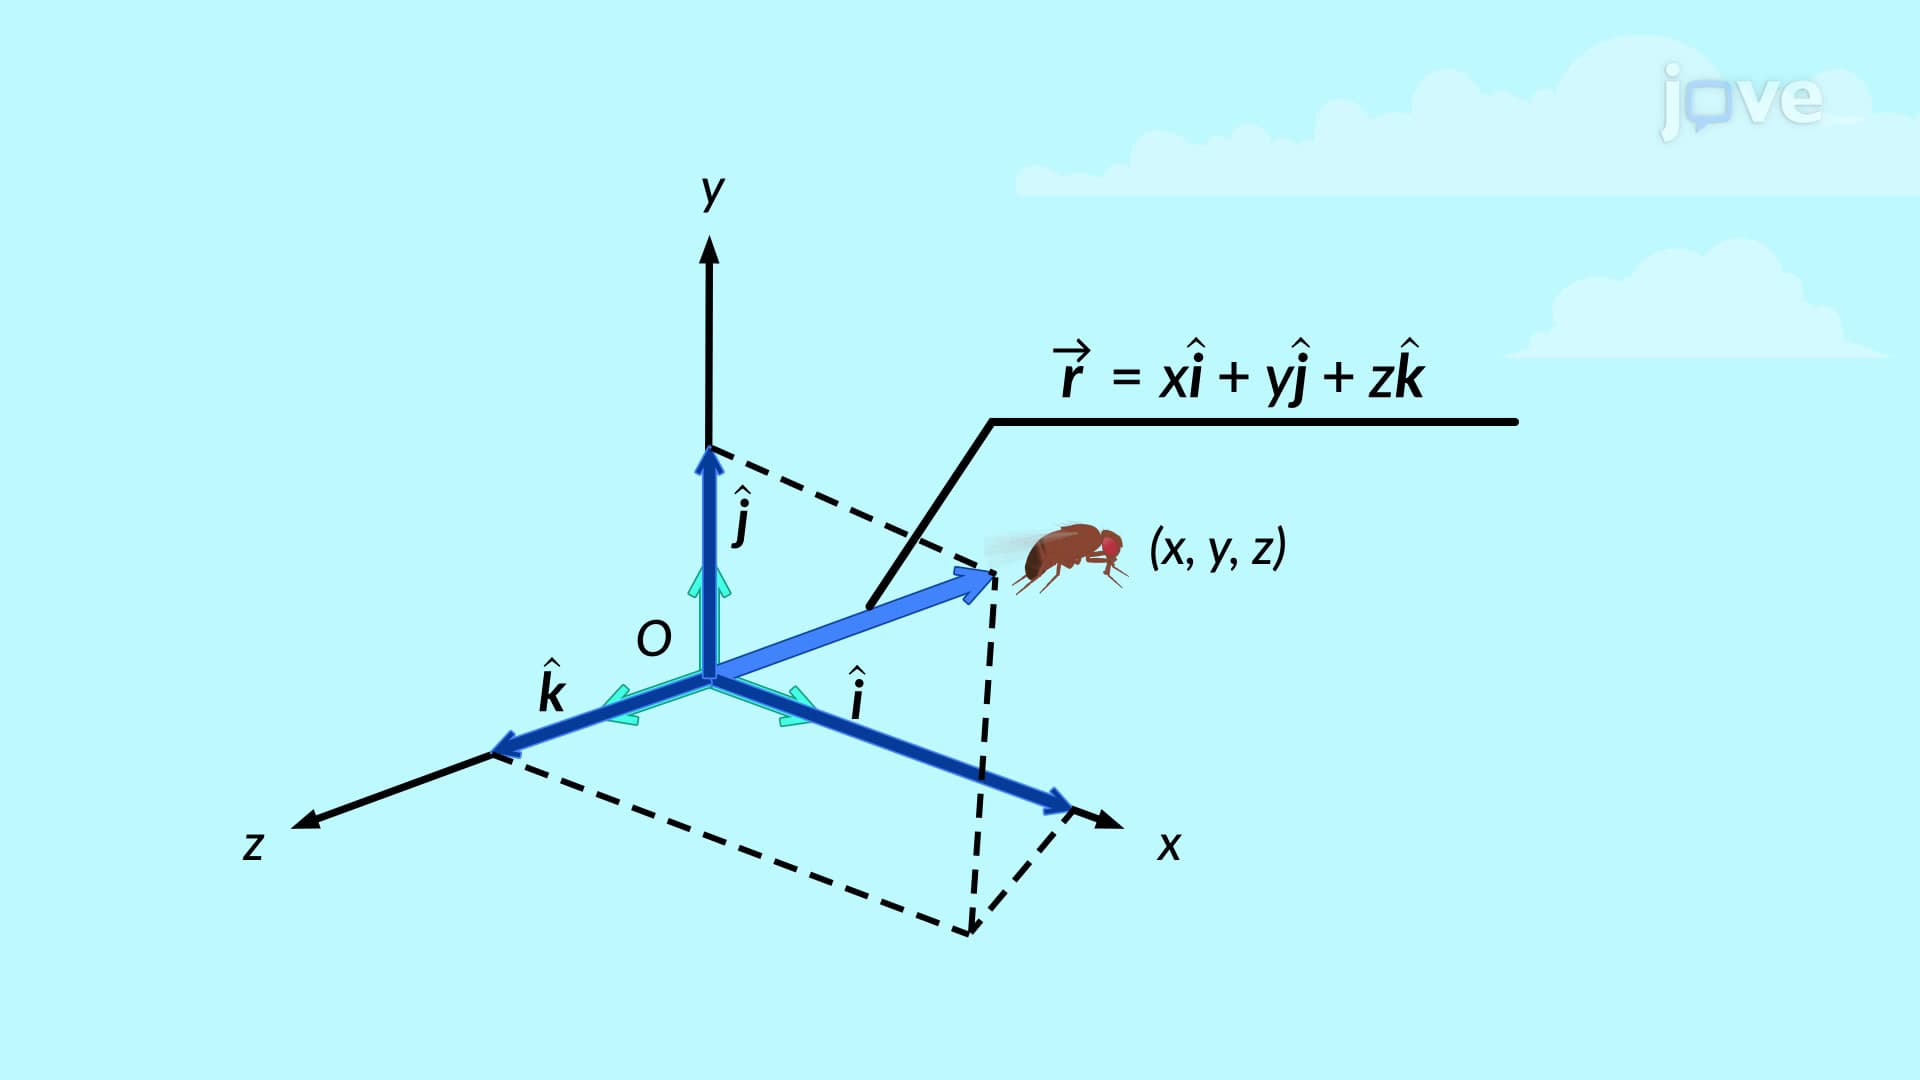
Position and Displacement Vectors
Further, several important kinds of...
 01:20
¹³C NMR: Distortionless Enhancement by Polarization Transfer (DEPT)
 01:29
Position Vectors
For instance, we want to locate a point P(x, y, z) relative to the origin of coordinates O. In that case, we can define a position...
 01:31
Position and Displacement
 01:21
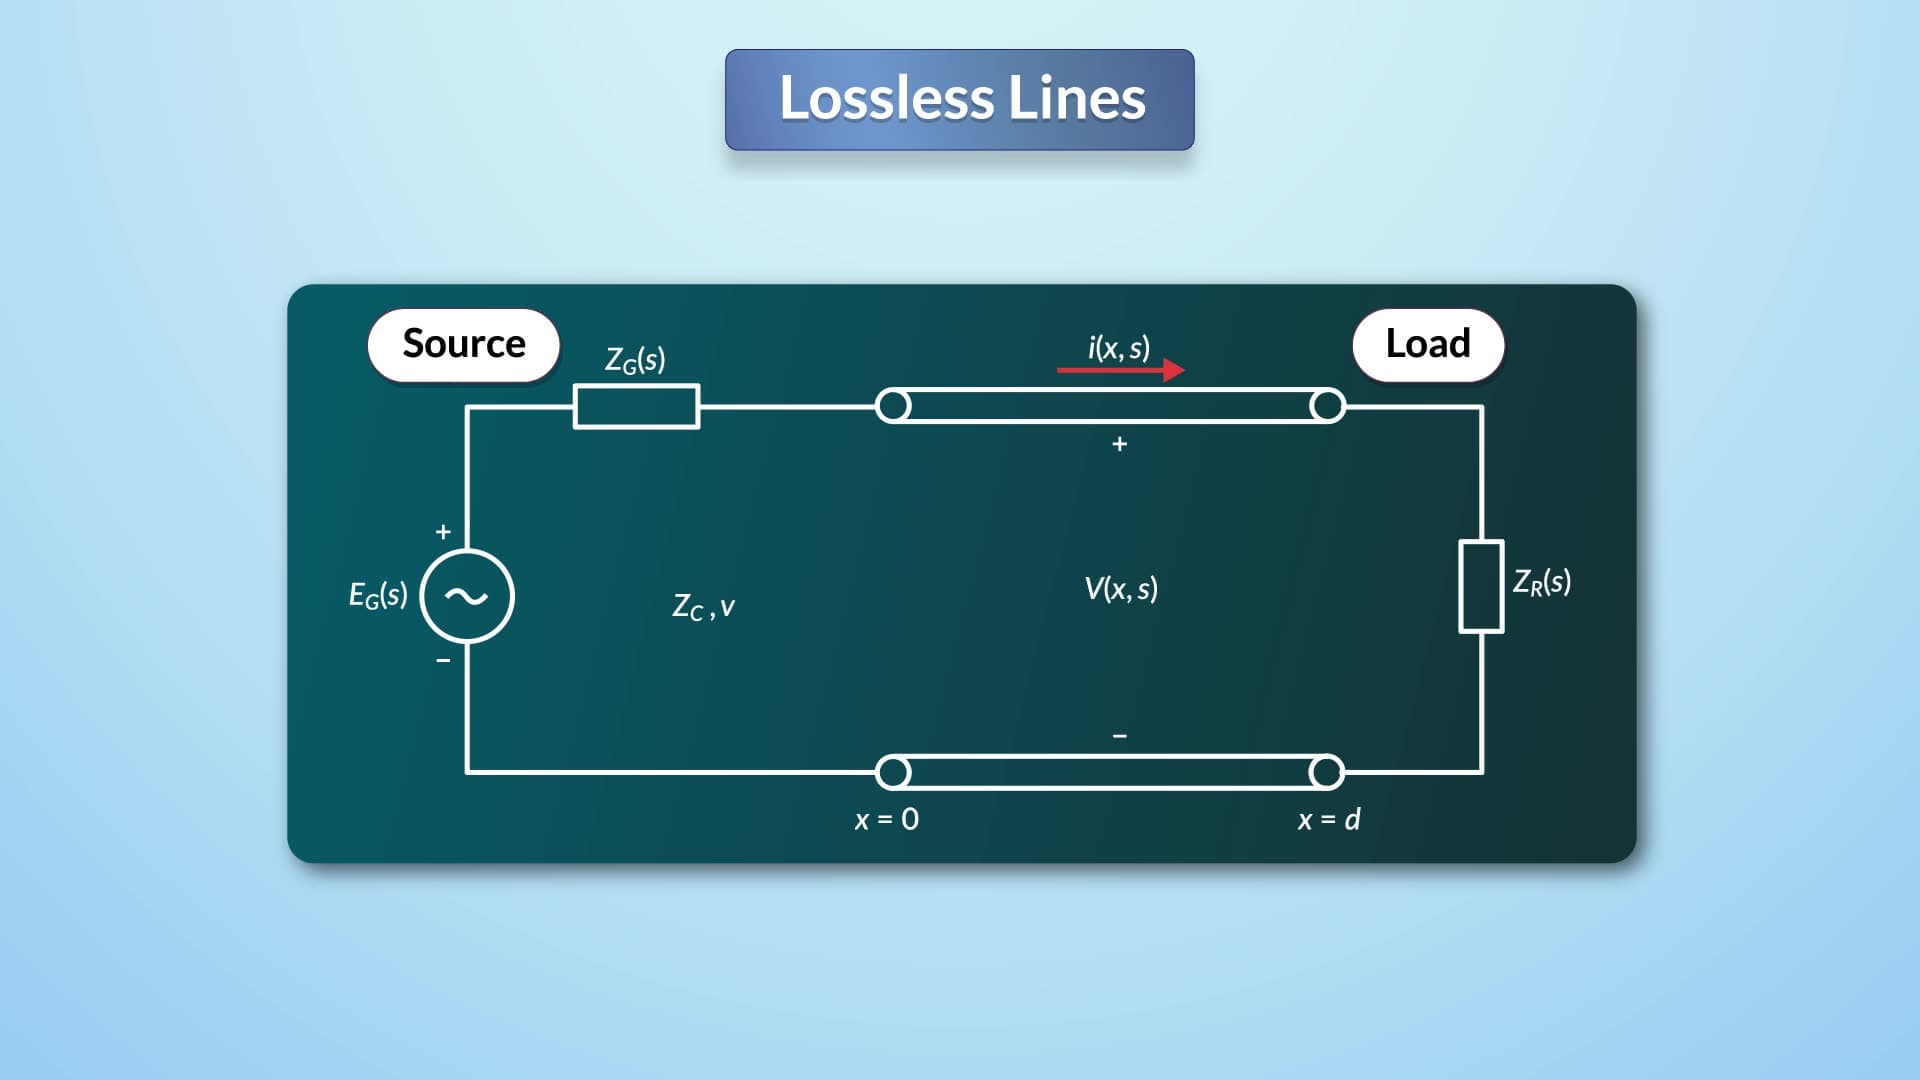
Boundary Conditions: Lossless Lines
At the receiving end, the boundary condition states that the voltage equals the product of the receiving-end impedance and current. This relationship is expressed as a function of the incident and...
 01:15
Distance Corrections