関連する実験動画
Updated: May 3, 2026
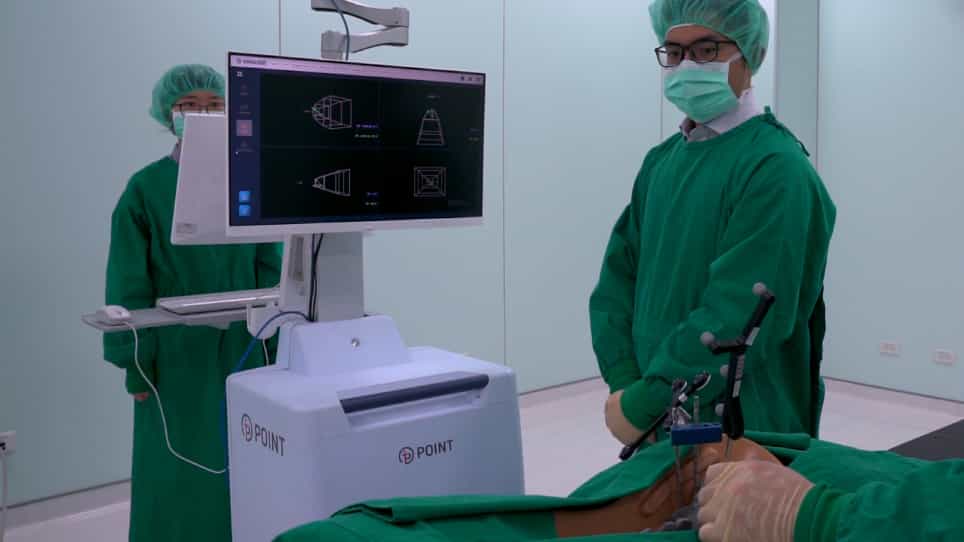
A Spine Robotic-Assisted Navigation System for Pedicle Screw Placement
Published on: May 11, 2020
後骨盤輪安定化のための新しい3Dナビゲーションスクリュー経路:有限要素解析
Eftychios Bolierakis1,2, Maximilian Praster3, Hatem Alabdulrahman3
1Department of Orthopaedics, Trauma and Reconstructive Surgery, Medical Faculty, RWTH Aachen University, Pauwelsstraße 30, 52074, Aachen, Germany. ebolierakis@ukaachen.de.

Purpose:
Posterior pelvic ring stabilization is technically demanding due to the complex local anatomy and limited osseous corridors. Advances in 3D navigation may allow for new screw trajectories previously infeasible with conventional fluoroscopy.
Methods:
A finite element model (FE) of a pelvis (Synbone LSS4060/Hard®) was developed, simulating seven screw configurations, including three novel oblique navigated pathways (Variants III-V). A 600 N vertical load was applied to simulate bipedal stance. Stress distribution and von Mises stresses were compared among configurations.
Results:
Conventional transsacral screws (Variants I-II) demonstrated the most uniform stress distribution and lowest peak stresses (7.17 MPa). Among novel configurations, Variant III achieved favorable compressive load transfer and lower shear stresses. Variant IV exhibited the highest overall stress (17.80 MPa), while Variant V demonstrated intermediate behavior.
Conclusion:
The proposed 3D-navigated oblique screw pathways are anatomically feasible and may offer biomechanical advantages under certain conditions. These findings support further validation using cadaveric and clinical studies.