
非負テンソルのHスペクトル半径を求めるNQZアルゴリズムの線形収束性
1Fujian Key Laboratory of Financial Information Processing, Putian University, Putian, Fujian, China.
PloS one
|January 23, 2026

Abstract:
The R-linear convergence of the NQZ algorithm for computing the H-spectral radius of a class of weakly irreducible nonnegative tensors is established by utilizing the directed graphs of tensors. Meanwhile, an upper bound for the root convergence factor R is derived and a general condition ensuring the linear convergence of the NQZ algorithm is provided.
関連する概念動画
 01:54
Convergent Evolution
31.6K
Evolution shapes the features of organisms over time, ensuring that they are suited for the environments in which they live. Sometimes, selection pressure leads to the rise of similar but unrelated adaptations in organisms with no recent common ancestors, a process known as convergent evolution.
31.6K
 01:12
Radius of Gyration of an Area
2.7K
The second moment of area, also known as the moment of inertia of area, is a crucial factor in understanding an object's resistance against bending deformation, or stiffness. To accurately estimate the second moment of area along any axis, one needs to concentrate all areas associated with that object into a thin strip, which should be placed parallel to that particular axis.
2.7K
 01:24
Inertia Tensor
1.1K
The concept of the inertia tensor is employed to depict the mass distribution and rotational inertia of a solid or rigid object. This tensor is expressed through a three-by-three matrix. Each component within this matrix corresponds to varying moments of inertia about specific axes.
The diagonal components of the inertia tensor matrix represent the moments of inertia concerning the principal axes of the object. These primary axes are defined as the axes where the object experiences the least...
The diagonal components of the inertia tensor matrix represent the moments of inertia concerning the principal axes of the object. These primary axes are defined as the axes where the object experiences the least...
1.1K
 01:09
Bones of the Upper Limb: Radius
4.6K
The radius is longer of the two bones that make up the human antebrachium or forearm. At the proximal end, the radius articulates with the capitulum of the humerus and the radial notch of the ulna to form the elbow joint. At the distal end, the radius articulates with the ulna via the ulnar notch, forming the distal radioulnar joint. Distally, the radius also attaches to the carpal wrist bones (scaphoid and lunate) to form the radiocarpal joint.
The radius has a nail-shaped head, and a...
The radius has a nail-shaped head, and a...
4.6K
 01:21
Schwarzschild Radius and Event Horizon
2.7K
No object with a finite mass can travel faster than the speed of light in a vacuum. This fact has an interesting consequence in the domain of extremely high gravitational fields.
The minimum speed required to launch a projectile from the surface of an object to which it is gravitationally bound so that it eventually escapes the object’s gravitational field is called the escape velocity. The escape velocity is independent of the mass of the object. Merging the idea of escape...
The minimum speed required to launch a projectile from the surface of an object to which it is gravitationally bound so that it eventually escapes the object’s gravitational field is called the escape velocity. The escape velocity is independent of the mass of the object. Merging the idea of escape...
2.7K
 01:19
Degree of Curvature and Radius of Curvature
481
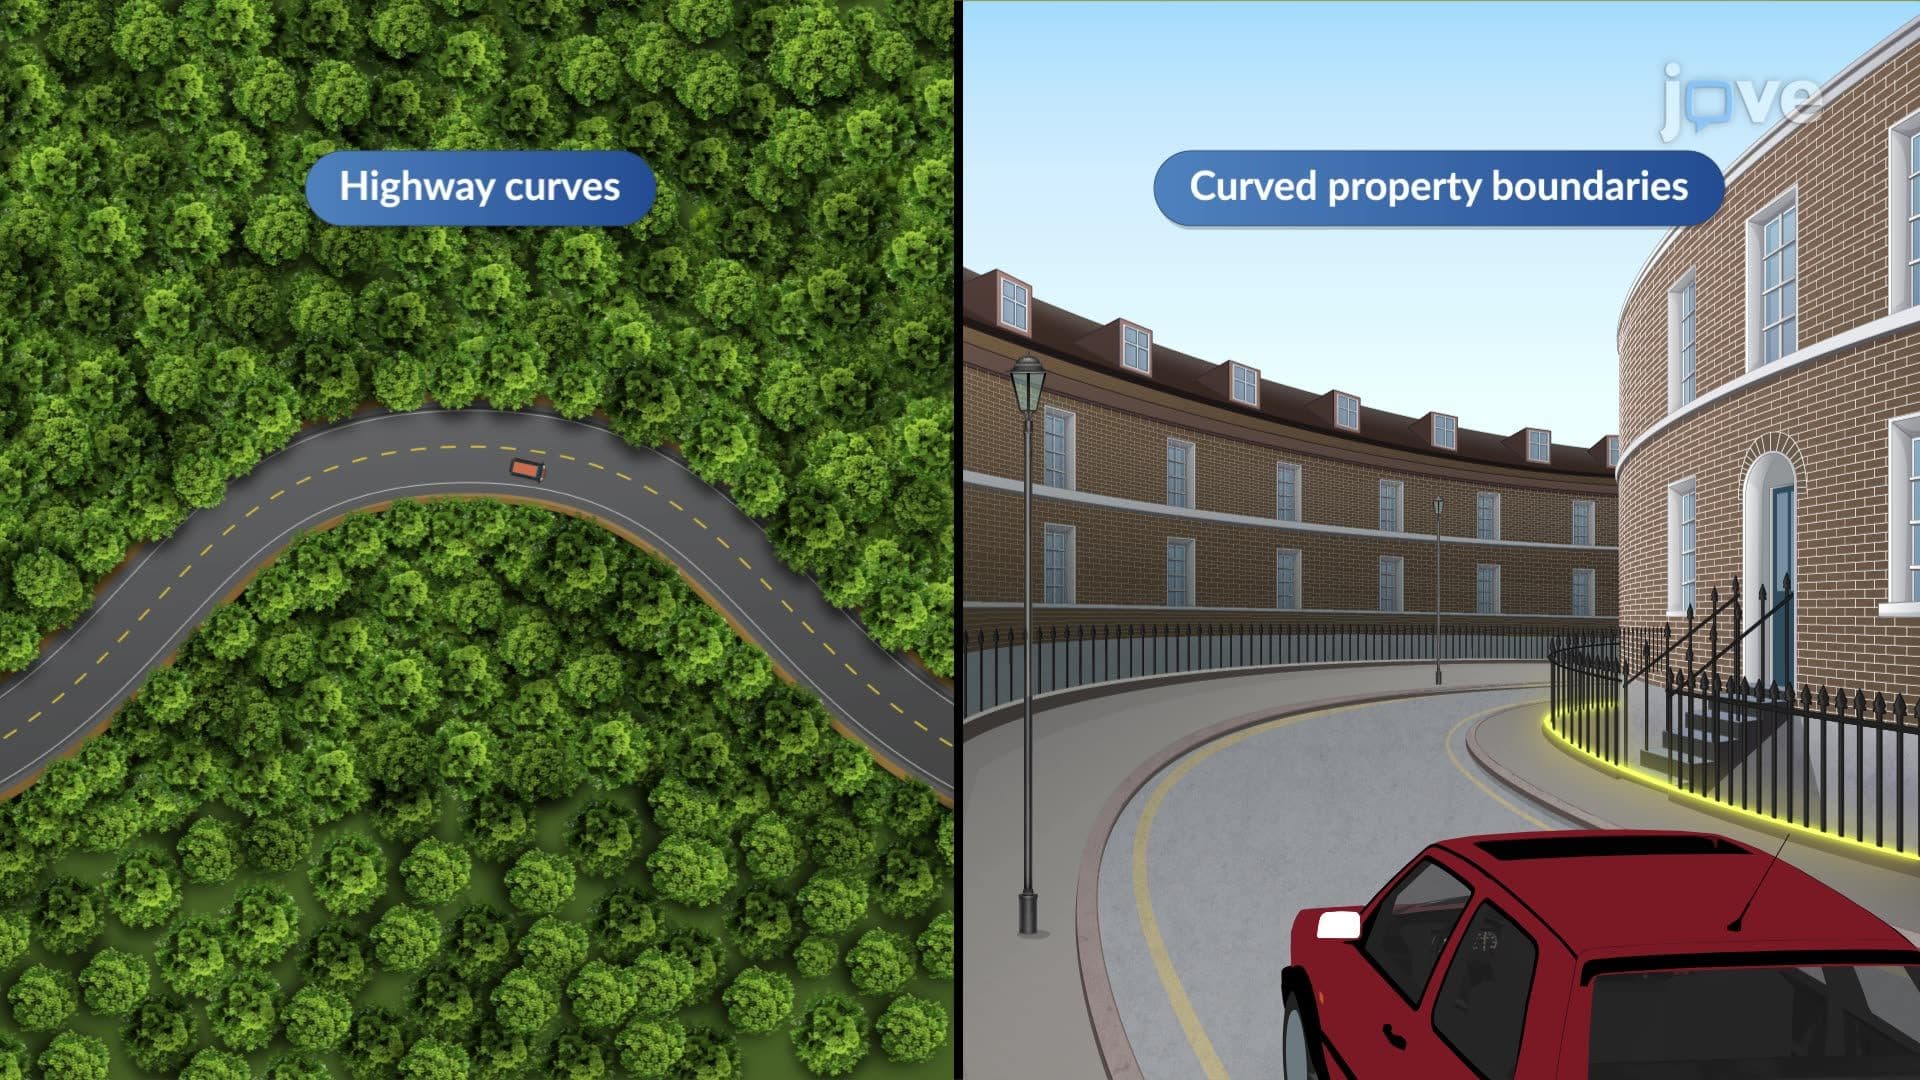
The degree of curvature and the radius of curvature are fundamental concepts in determining the sharpness or smoothness of a curve. The degree of curvature is a measure of how steeply a curve bends and can be determined using the chord basis or the arc basis. In the chord basis method, the degree of curvature is defined as the central angle subtended by a chord of 30.48 meters, helping in the calculation of the radius of the curve. The arc basis method defines the degree of...
481