
エッジクラウドセンサーフュージョンとCNNベースのパーセプトロンによるリアルタイム車両制御
Sumukh Chaurasia1, Parambrata Sanyal1, Gagandeep Kaur1
1Symbiosis Institute of Technology, Nagpur Campus, Symbiosis International (Deemed University), Pune, India.

Abstract:
Reliable real-time vehicle control is essential for intelligent transport systems where accurate perception and decision-making depend on fast sensor data processing. This study developed a hybrid edge-cloud method integrating deep learning with Internet of Things (IoT) sensor fusion for adaptive vehicle control. Ultrasonic range data were combined with convolutional neural networks (CNNs) to enable object detection, stopping-time prediction, and braking control under varying environmental conditions. The CNN-based model was trained and evaluated under normal and simulated adverse driving scenarios. Results indicated strong performance with R² = 0.99 under normal and 0.98 under adverse conditions, and a mean squared error (MSE) of 0.0085. Average inference latency is 110-116 ms on Jetson Nano and 210-230 ms on Raspberry Pi, confirming suitability for real-time deployment on edge hardware. The hybrid edge-cloud method enables adaptive, real-time vehicle control through IoT sensor fusion. CNN-based perception enhances prediction accuracy and operational safety under variable driving conditions. Demonstrates feasibility of deep learning deployment on low-cost edge devices for intelligent transport applications. Thus, integrating deep learning with IoT-enabled sensors on an edge-cloud platform provides a reliable and scalable pathway toward safe, adaptive, and efficient vehicle control in intelligent transportation systems.
さらに関連する動画
 09:21
Real Time Monitoring of Intracellular Bile Acid Dynamics Using a Genetically Encoded FRET-based Bile Acid Sensor
Published on: January 4, 2016
 10:28
Sensitivity Enhancement of Soft Capacitive Pressure Sensors Using a Solvent Evaporation-Based Porosity Control Technique
Published on: March 24, 2023
関連する概念動画
 02:45
Nuclear Fusion
A helium nucleus has a mass that is 0.7% less than that of four hydrogen nuclei; this lost mass is converted into energy during the fusion. This reaction produces about...
 02:57
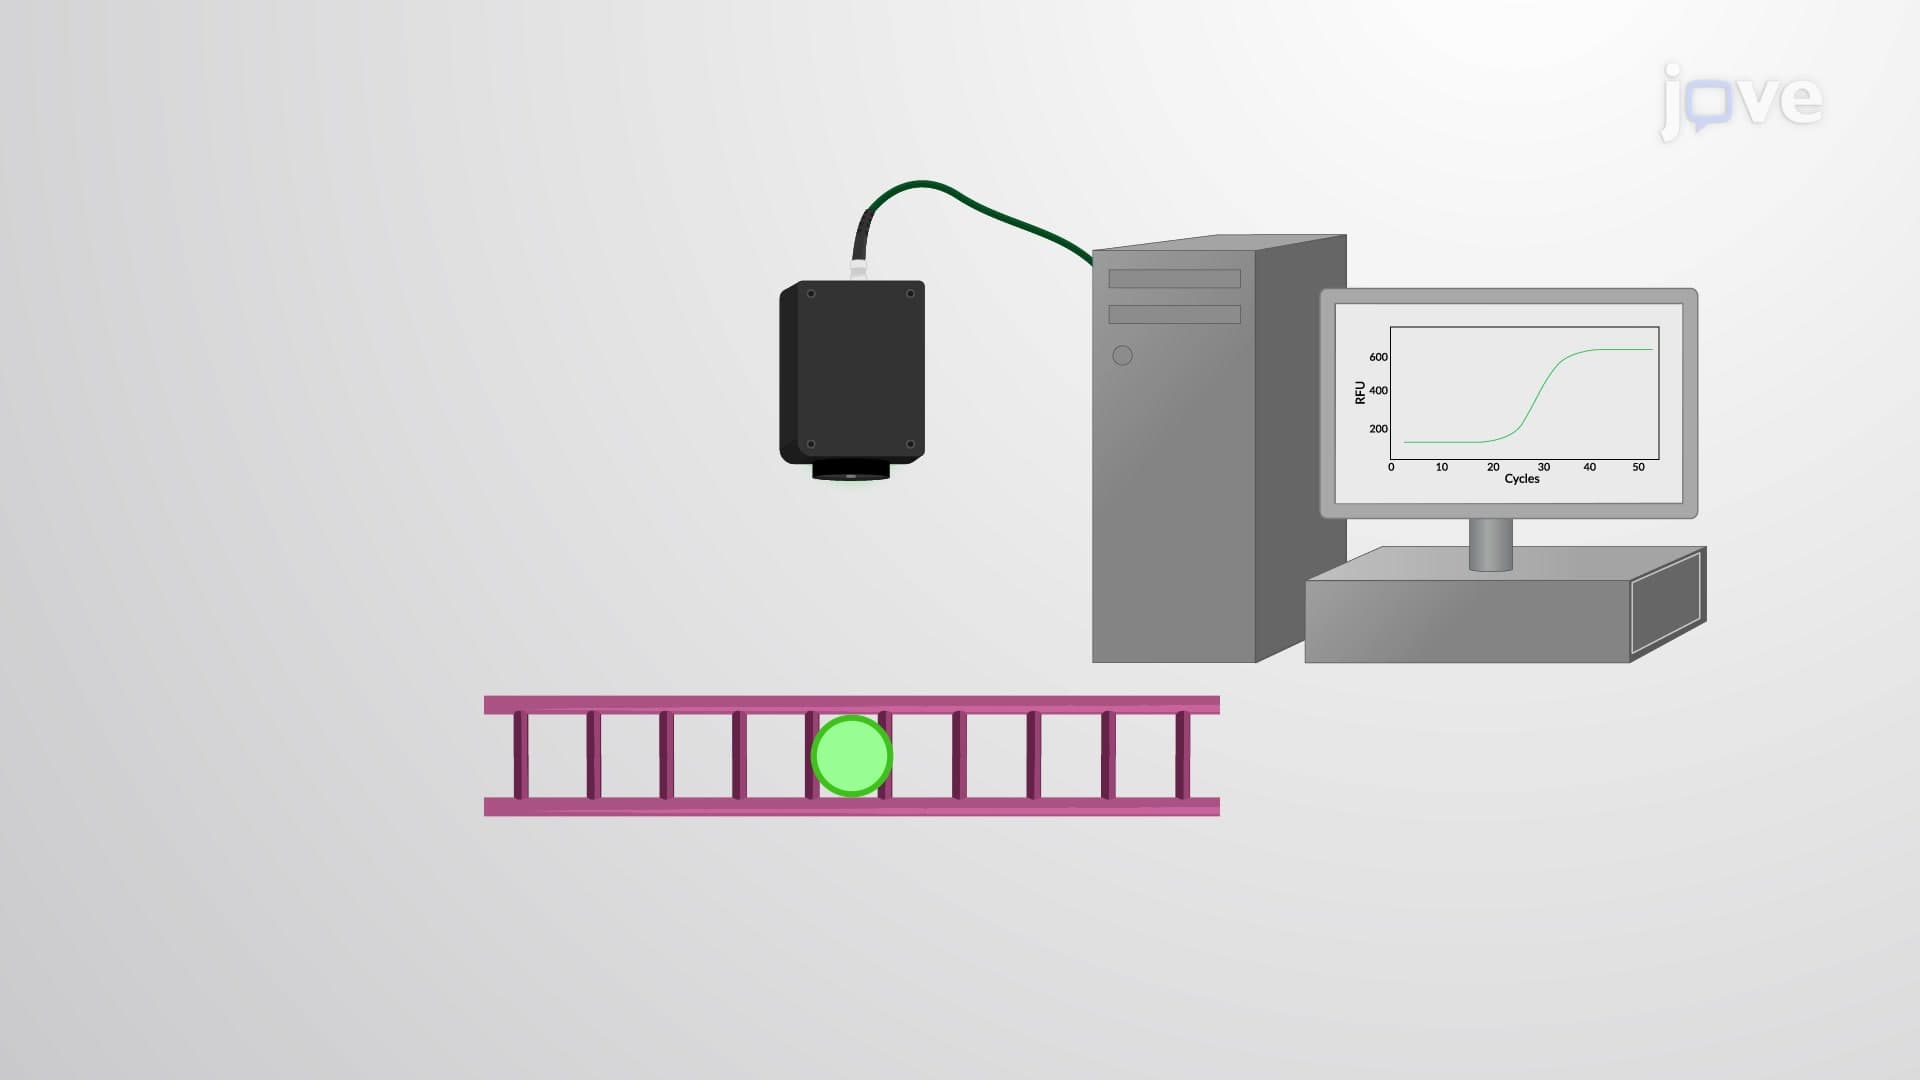
Real Time RT-PCR
The real-time quantification of the number of amplified products is...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...