関連する実験動画
Updated: Jan 28, 2026

Controlling Parkinson's Disease With Adaptive Deep Brain Stimulation
Published on: July 16, 2014
ピクセルベースの深層アクティブ推論コントローラーの収束安定化のための適応的平滑化フィルター
Kazuma Nagatsuka1, Kyo Kutsuzawa1, Dai Owaki1
1Department of Robotics, Graduate School of Engineering, Tohoku University, Sendai 9808579, Miyagi, Japan.

Abstract:
In recent years, active inference has gained attention in robot control owing to its adaptability to environmental changes. However, its reliance on gradient descent of variational free energy offers no guarantee of convergence to an optimal solution. In this study, we propose an approach that applies a smoothing filter to a pixel-based active inference controller to mitigate the risk of local minima. By smoothing the observed, predicted, and target values, the free energy function becomes smoother, yielding a broader distribution of gradients toward the target, thereby reducing the risk of being trapped in the local minima. In addition, in order to prevent excessive smoothing from eliminating the gradient of the free energy function, we also proposed a method for dynamically adjusting the intensity of smoothing based on prediction and target errors. To evaluate the effectiveness of our method, we applied it to two simulation environments: a simple object-tracking task using a 3-degrees-of-freedom camera, and a robot control task using a 2-degrees-of-freedom robotic arm, and compared it with the conventional active inference controller as a baseline. The experimental results demonstrate that the proposed approach achieves improved convergence performance over the conventional method.
関連する概念動画
 01:25
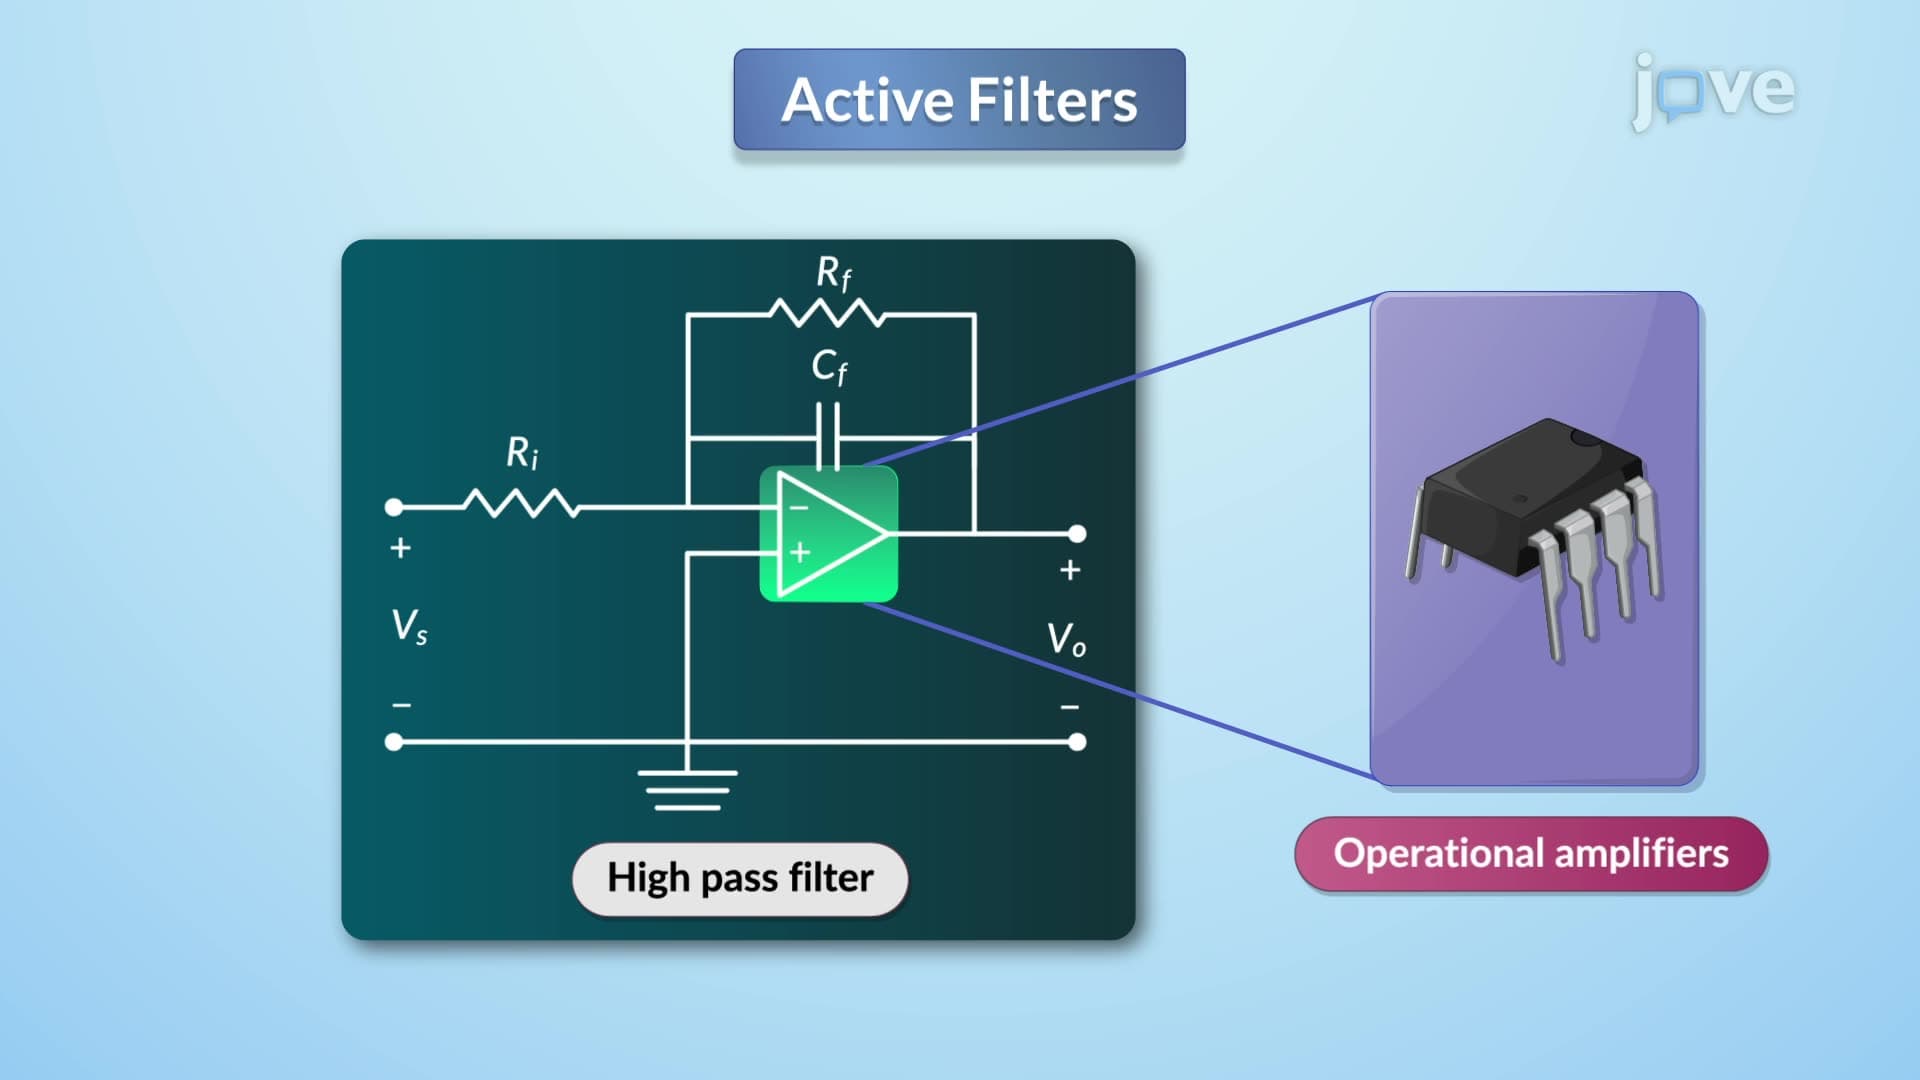
Active Filters
 01:54
Convergent Evolution
 01:17
Region of Convergence
 01:27
Passive Filters
Low-Pass Filters
Low-pass filters are designed to transmit signals with frequencies lower than the cutoff frequency, ωc, and attenuate those above it. The cutoff...
 01:53
RNA Stability
 03:18
Nuclear Stability
To hold positively charged protons together...