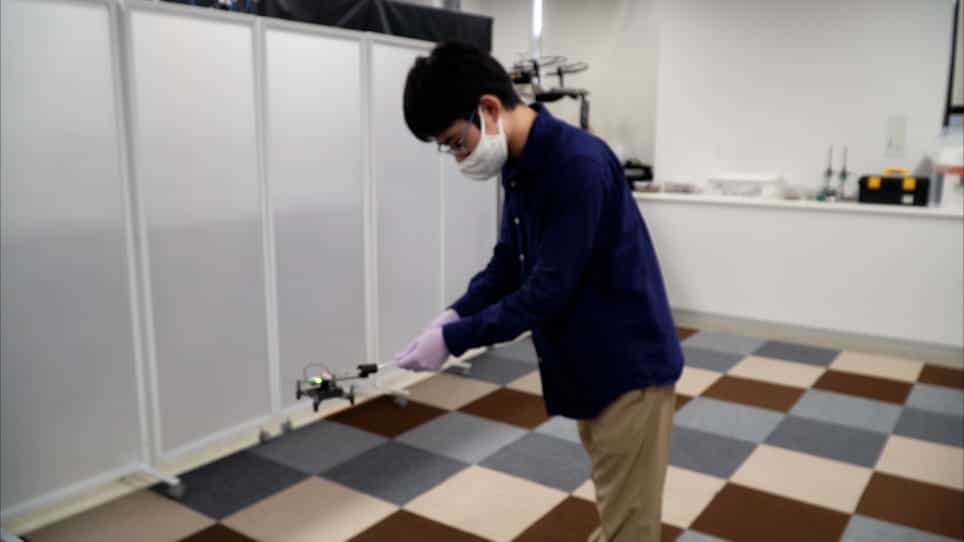

自動グリッピングシステムとハイブリッドコントローラーによるマルチドローン小包配送
Bruno J Guerreiro1,2, Francisco Azevedo2, Paulo Oliveira2,3
1DEEC/CTS/LASI, NOVA School of Science and Technology, Universidade NOVA de Lisboa, 2829-516 Caparica, Portugal.

Abstract:
This paper presents the development of an autonomous grasping mechanism for drone-based parcel delivery systems towards developing capabilities for in-flight package transfer. The approach integrates a mechanical gripper fitted with sensors and a pose estimation method for parcels, all coordinated through a hybrid Model Predictive Control (MPC) architecture. The gripper's mechanical structure and prototype are developed using 3D printing technology for both the main framework and gear components. A hybrid dynamical model is formulated that integrates the gripper mechanics with simplified drone dynamics, capturing distinct operational phases including package acquisition, transport, and release. The hybrid MPC framework computes reference trajectories for both the gripper arm configuration and the drone's spatial path toward designated target positions. Experimental validation is conducted using the operational gripper prototype and pose estimation system, while drone behavior is represented through simulation.

関連する概念動画
 01:28
Automatic Processing and Automatic Social Behavior
 02:29
Hybrid Zones
 03:24
Hybridization of Atomic Orbitals I
 03:35
Hybridization of Atomic Orbitals II
 01:22
Multi-input and Multi-variable systems
In the absence of...
 02:31
In-situ Hybridization
Types of probes and labels
A probe is a complementary strand of DNA or RNA that binds to corresponding nucleotide sequences in a cell. Many...