

肋間ロボット超音波画像診断のための強化学習を用いた自律経路計画
Yuan Bi1, Cheng Qian1, Zhicheng Zhang2
1Chair for Computer Aided Medical Procedures (CAMP), Technical University of Munich, Munich, Germany.

Abstract:
Ultrasound (US) is widely used in clinical practice for the screening internal organs and guiding interventions. Nonetheless, US imaging suffers from inter- and intra-operator variations. Leveraging the reproducibility offered by robots, robotic ultrasound systems emerge as a promising solution, offering enhanced precision, stability, and repeatability. To realize autonomous US scanning, robot learning algorithms have been widely explored. However, current approaches primarily base the decision-making process for US navigation on 2D US images data, often overlooking the integration of 3D anatomical knowledge, which is a critical component for path planning in anatomically complex regions, such as the intercostal area. To address this limitation, we propose a novel reinforcement learning (RL) approach for intercostal US scanning path planning, leveraging computed tomography (CT) templates and utilizing 3D state representations. To this end, a virtual environment is developed using CT templates with randomly initialized tumors of various shapes and locations as a training environment. In addition, task-specific state representation and reward functions are introduced to encourage the convergence of the training process while minimizing the effects of acoustic attenuation and shadows during scanning. It is important to note that the scope of this work is limited to the autonomous path planning component, while robotic execution and control integration will be addressed in future studies. To validate the effectiveness of the proposed approach, experiments have been carried out on unseen patient models with randomly defined single or multiple scanning targets. The results demonstrate the efficiency of the proposed RL framework in planning non-shadowed US scanning trajectories in areas with limited acoustic access.
関連する概念動画
 01:22
Mean free path and Mean free time
 01:21
Path Between Thermodynamics States
 01:23
Reinforcement
Positive reinforcement occurs when a behavior is followed by the presentation of a rewarding stimulus, increasing the frequency of that behavior. For example:
 01:22
Autonomic Nervous System
The ANS comprises two main divisions: the sympathetic and parasympathetic divisions. These divisions function antagonistically to maintain a dynamic...
 01:10
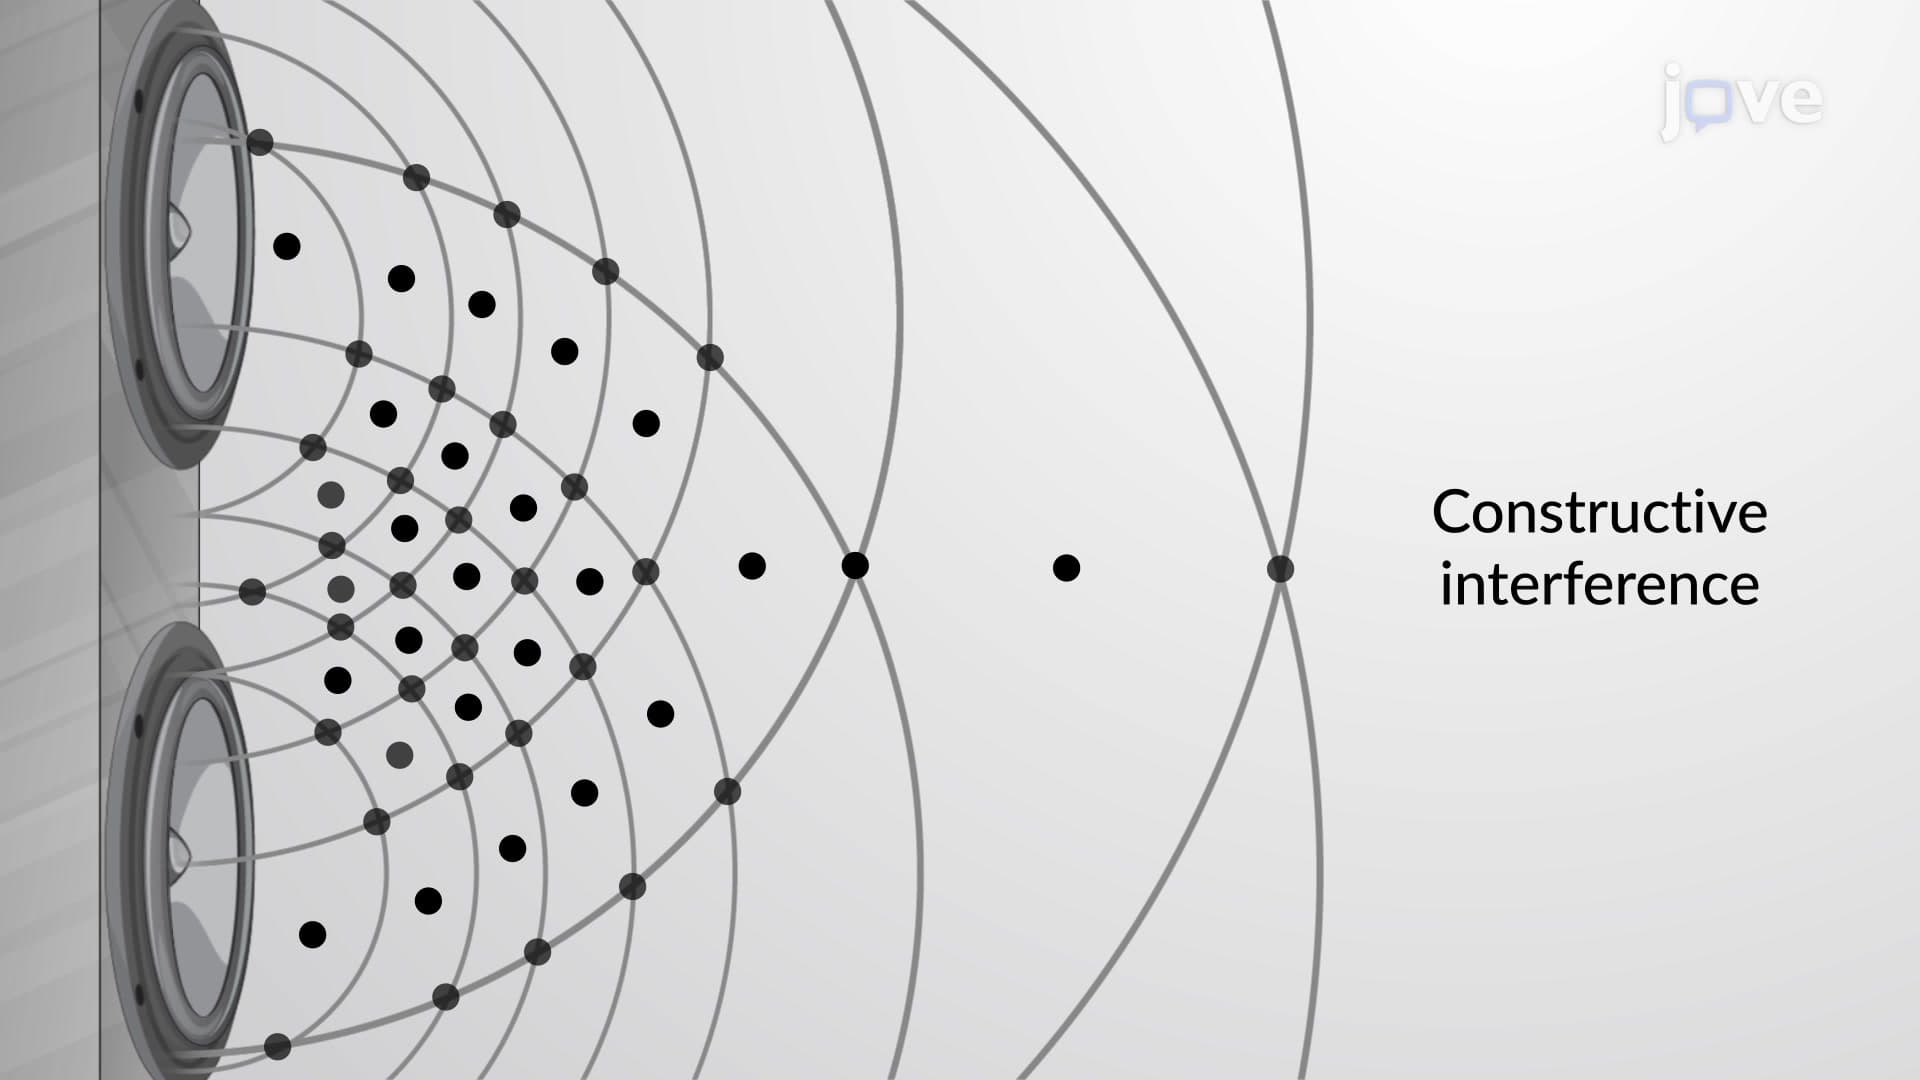
Interference: Path Lengths
Two special sources may be considered when they are in phase. This can be easily achieved by feeding the two sources from the same source. An example would be synchronizing the two speakers by feeding them with the same source, such as the sound waves produced by a tuning fork. This setup ensures that the two sources have the same frequency and are...
 01:27
Corrosion of Reinforcement
However, over time and under certain conditions like carbonation, chloride ingress, and cracking this protective state can be compromised. Steel has areas with...