
冗長感知ベースの6軸フォース/トルクセンサで,コンパクト性と高感度性を可能にします
Seung Yeon Lee1,2, Jae Yoon Sim1,2, Dong-Yeop Seok2
1Department of Mechanical Engineering, Sungkyunkwan University, Suwon-si 16419, Republic of Korea.
Sensors (Basel, Switzerland)
|February 13, 2026

まとめ
この研究では,冗長な容量センサーアーキテクチャを使用したコンパクトの6軸力/トルク (F/T) センサーを導入しています. この新しいデザインは,小型化ロボットシステムの感度と測定の強さを高めます.
科学分野:
- ロボット工学 ロボット工学 ロボット工学
- センサー技術 センサー技術
- メカトロニクス メカトロニクス
背景:
- 容量センサーはコンパクトなロボットにとって不可欠ですが,小型化すると感度が低下し,不均衡になります.
- 容量センサーの小型化の課題,特にトルク測定の課題は,限られた電極面積と空間的制約から生じる.
研究 の 目的:
- ミニチュライゼーションの限界を克服するコンパクトな6軸フォース/トルク (F/T) センサーを開発する.
- ロボットアプリケーションの多軸F/T測定における感度を高め,コップリングエラーを減らすために.
主な方法:
- 多数の電極の対称的な配置を持つ冗長な容量センサーアーキテクチャが設計されました.
- 複合的な機械的な分離を回避し,測定の堅実性を向上させるために冗長な容量反応を活用した.
- コンパクトな6軸F/Tセンサー (20mm直径,12mm高さ) を開発した.
主要な成果:
- 実験的検証で高い線形性 (>98.2%) を達成しました.
- 横軸干渉の減少が実証され,感度と信頼性の向上を示しています.
- センサーの性能を検証し,多軸の力/トルク測定を確実に行えるようにしました.
結論:
- 提案された冗余の容量センサーアーキテクチャは,効果的に感度と測定の堅牢性を高めます.
- コンパクトな6軸F/Tセンサは,スペースが限られたロボットシステムにとって,実用的でスケーラブルなソリューションです.
- この研究は,小型化ロボットにおける高性能F/Tセンシングの統合を進めている.
さらに関連する動画
 10:28
Sensitivity Enhancement of Soft Capacitive Pressure Sensors Using a Solvent Evaporation-Based Porosity Control Technique
Published on: March 24, 2023
2.7K
 08:25
Construction of a Wireless-Enabled Endoscopically Implantable Sensor for pH Monitoring with Zero-Bias Schottky Diode-based Receiver
Published on: August 27, 2021
3.0K
関連する概念動画
 01:28
Moment of a Force About an Axis: Scalar
717
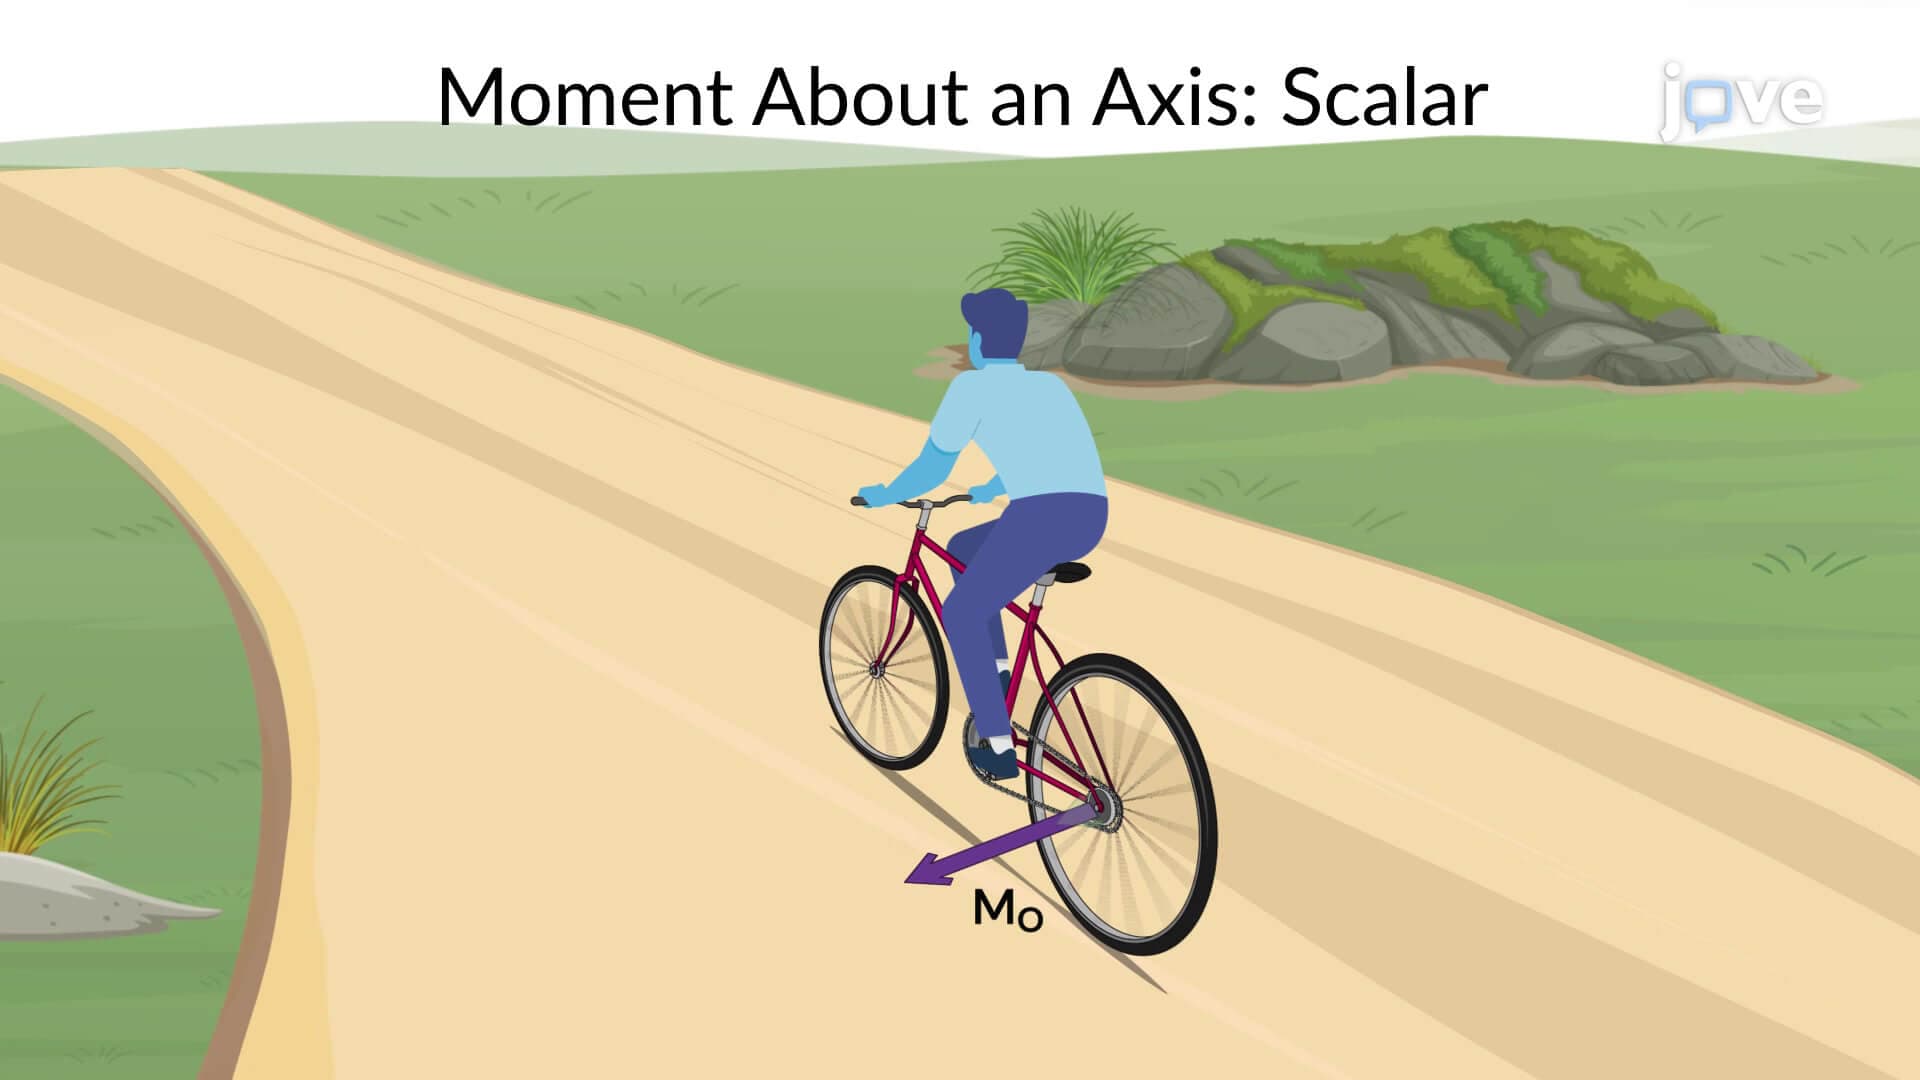
The moment of a force about an axis is a crucial concept in mechanics that helps determine an object's rotational motion around a specific point or axis. The moment of force can be calculated using scalar analysis, which involves considering the perpendicular distance between the axis of rotation and the line of action of the force or simply the moment arm.
To better understand the concept of moment of force, consider the example of a cyclist riding a bicycle. When the cyclist applies force on...
To better understand the concept of moment of force, consider the example of a cyclist riding a bicycle. When the cyclist applies force on...
717
 01:29
Moment of a Force About an Axis: Vector
935
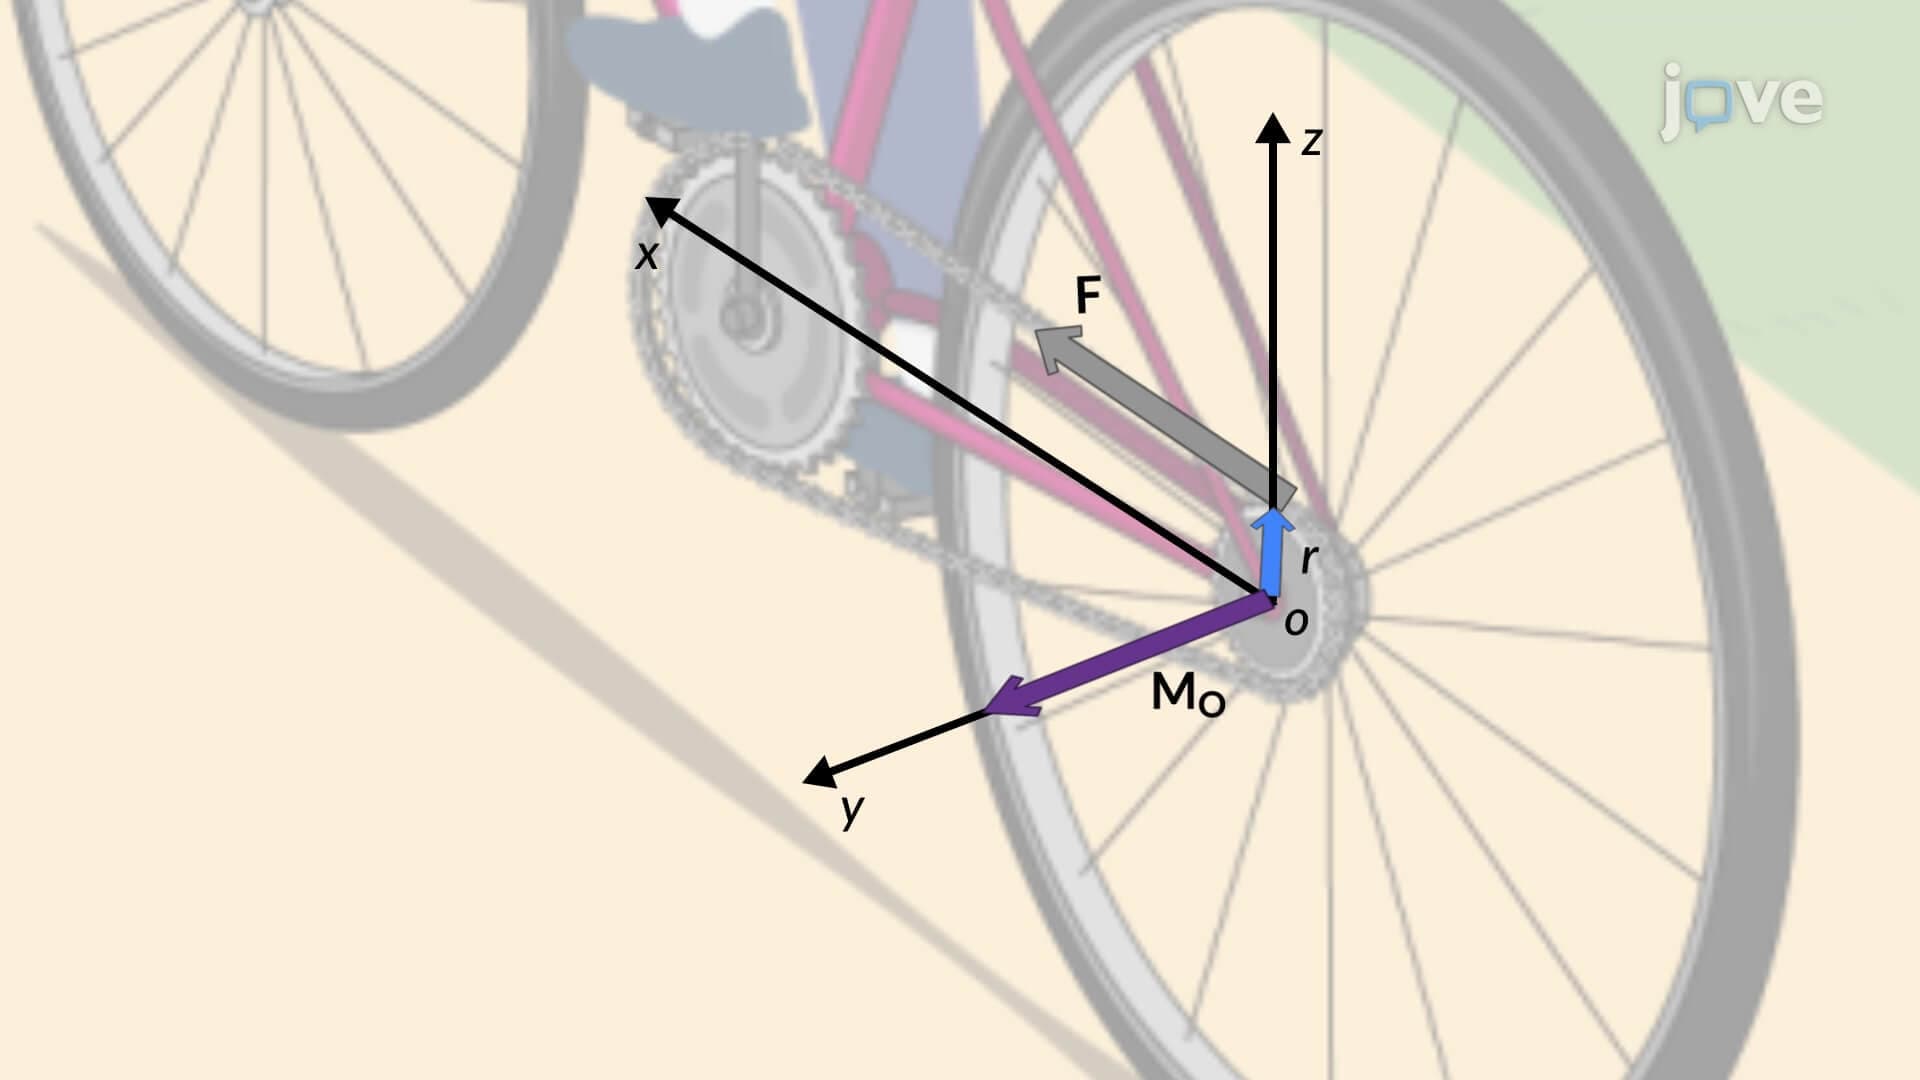
When a force is exerted on an object, it can cause that object to rotate about an axis. The moment of a force, also known as torque, measures the force's ability to cause that rotation. In the case of a cyclist pedaling a bicycle, the force exerted on the pedal causes the crankshaft to rotate, which in turn causes the wheel to spin. The moment of the force exerted on the pedal drives the wheel's rotation.
First, establish a coordinate system to understand how the moment of a force...
First, establish a coordinate system to understand how the moment of a force...
935
 01:10
Torque
22.7K
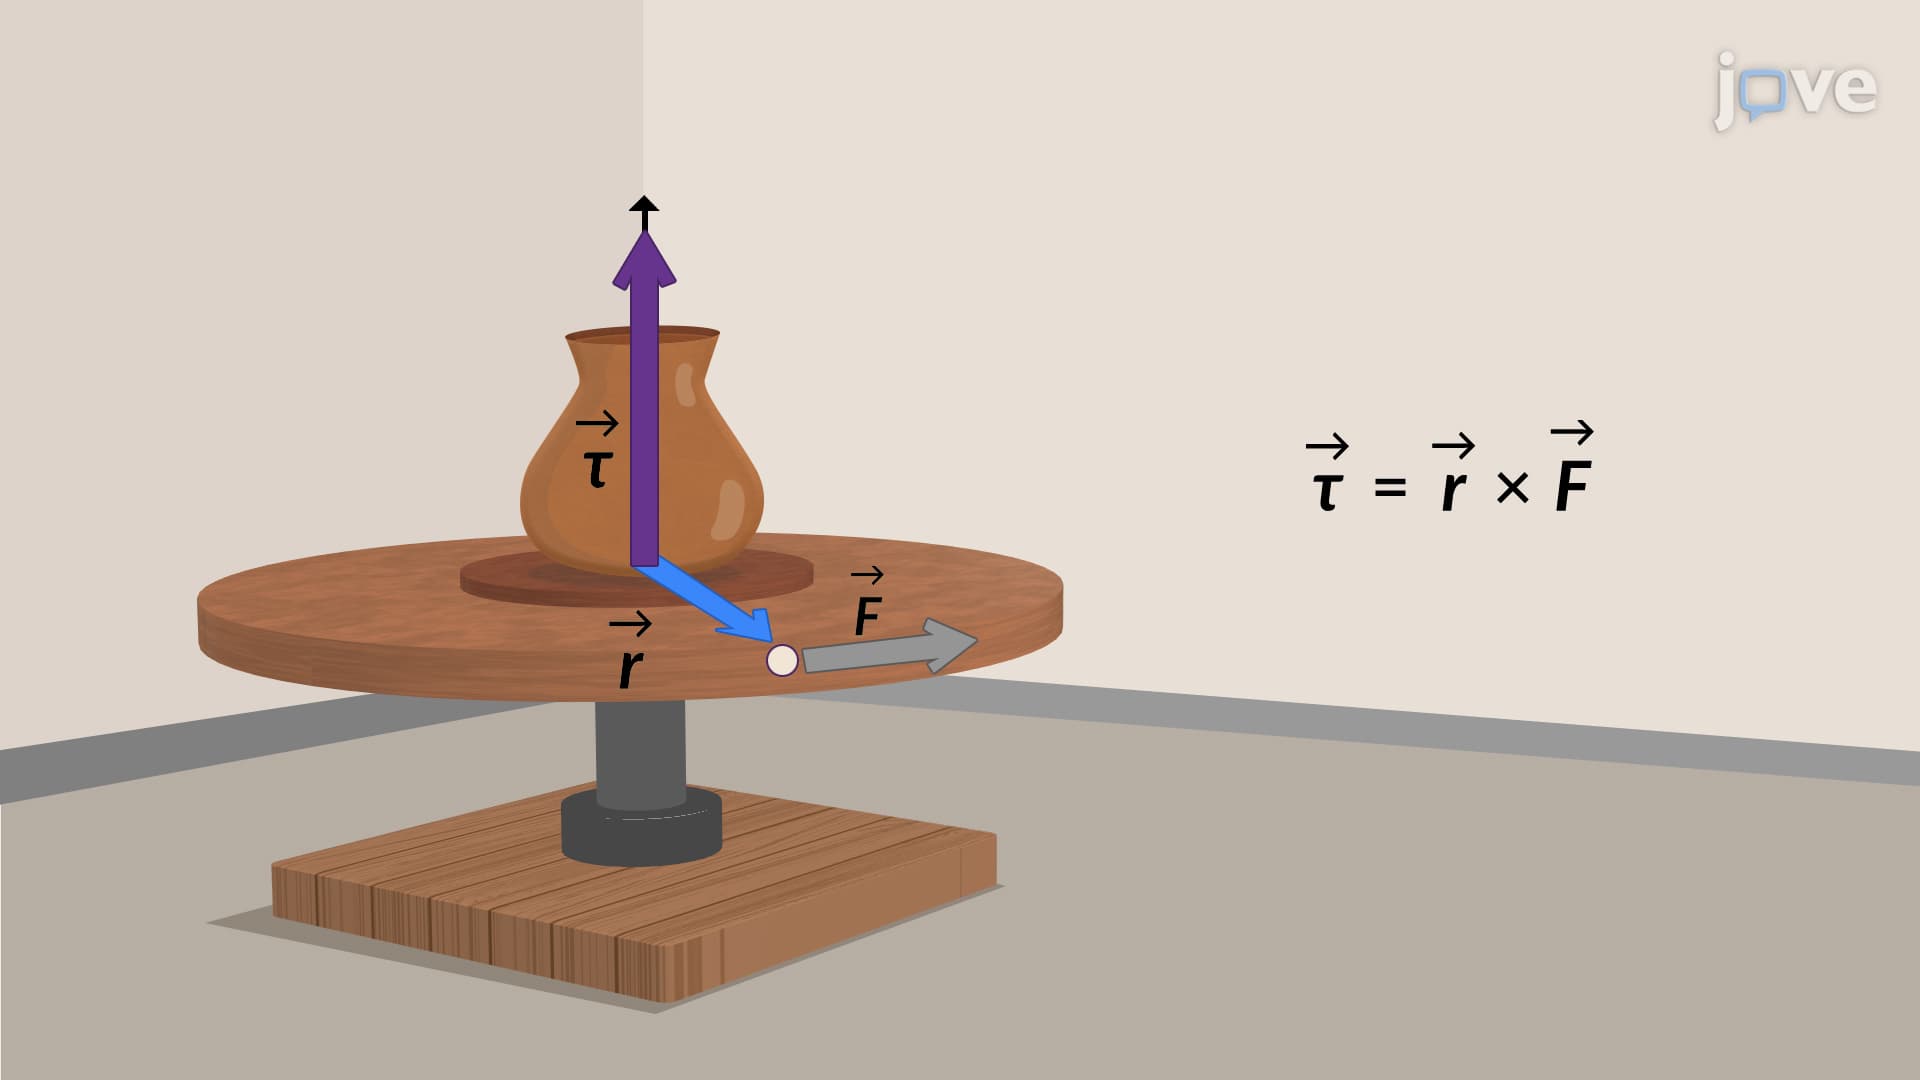
Torque is an important quantity for describing the dynamics of a rotating rigid body. We see the application of torque in many ways in the world, such as when pressing the accelerator in a car, which causes the engine to apply additional torque on the drivetrain. Here, we define torque and provide a framework to create an equation to calculate torque for a rigid body with fixed-axis rotation.
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
22.7K
 01:27
Compact Bone
16.9K
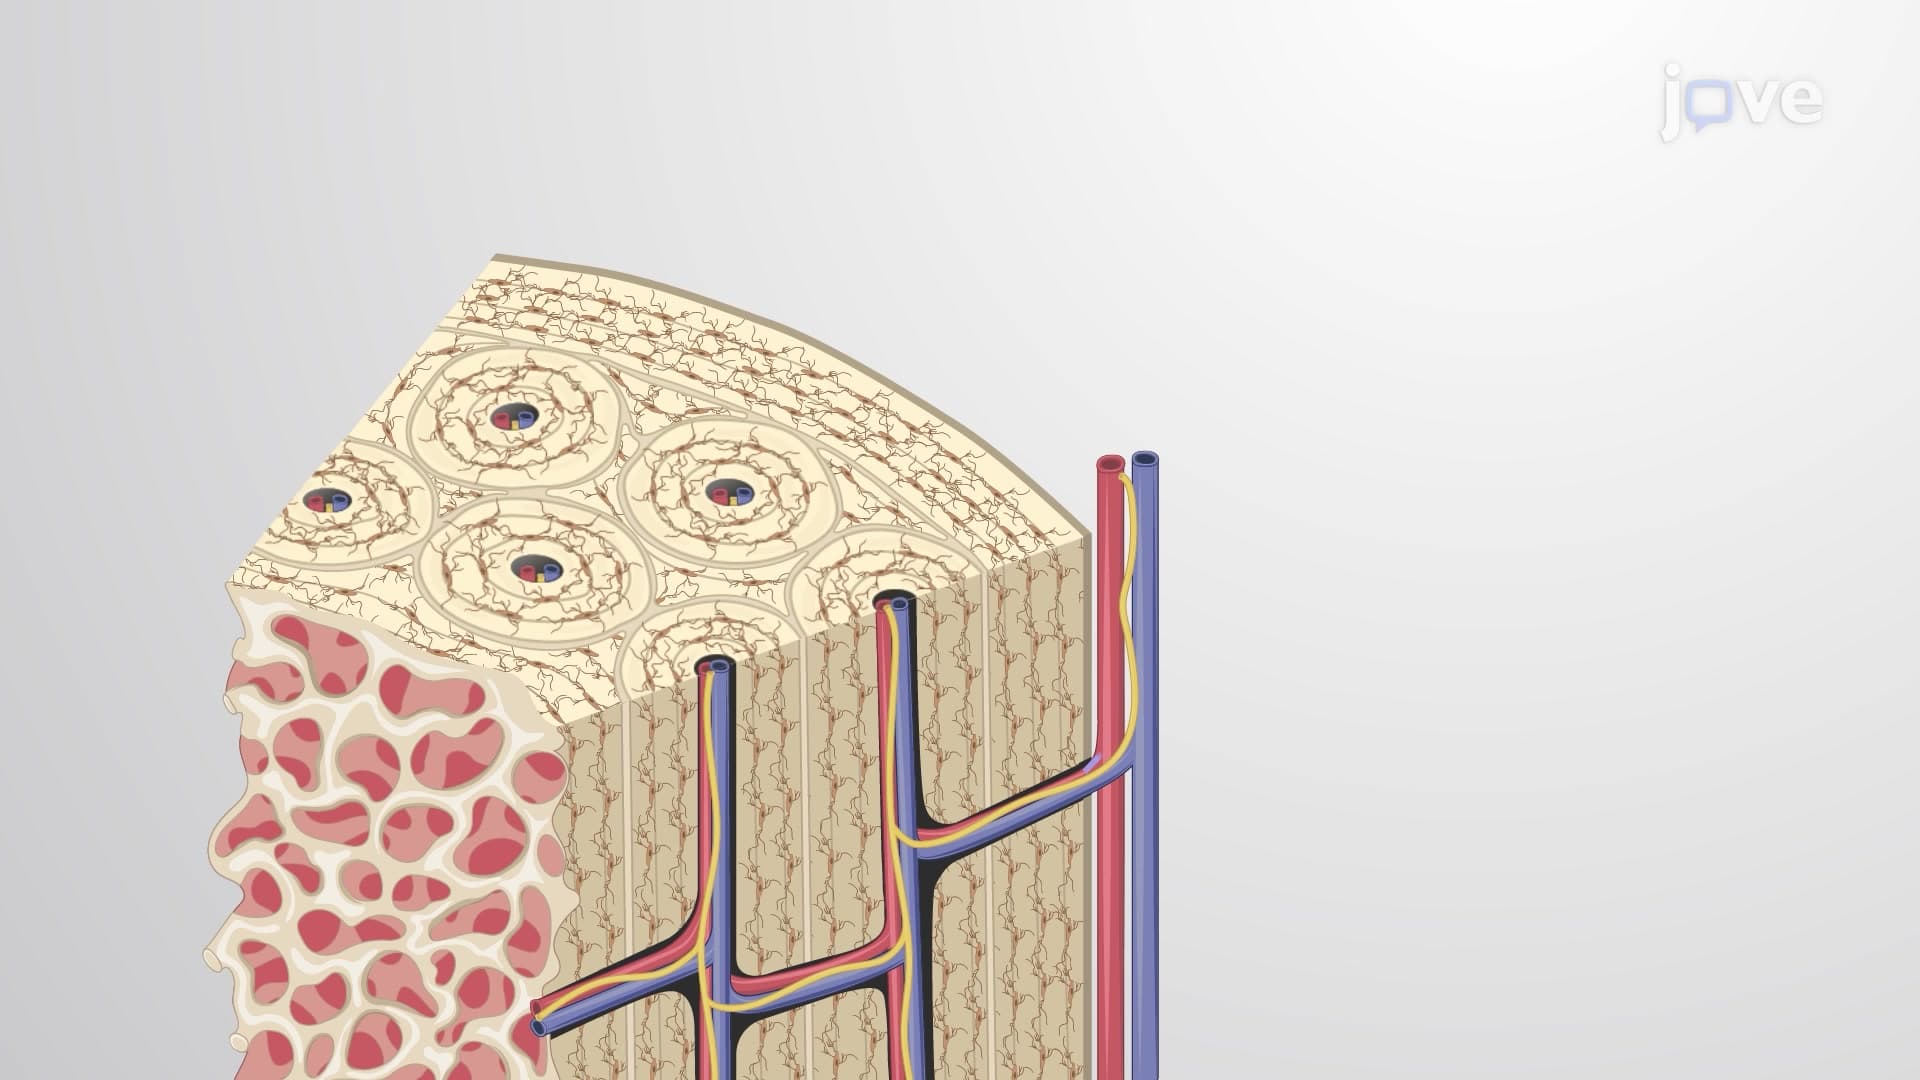
Most bones contain compact and spongy osseous tissue, but their distribution and concentration vary based on the bone's overall function.
Compact bone, also called cortical bone, is the denser, stronger of the two types of bone tissue. It is found under the periosteum and in the diaphyses of long bones, where it provides support and protection. The microscopic structural unit of compact bone is called an osteon, or haversian system. Each osteon is composed of concentric rings of calcified...
Compact bone, also called cortical bone, is the denser, stronger of the two types of bone tissue. It is found under the periosteum and in the diaphyses of long bones, where it provides support and protection. The microscopic structural unit of compact bone is called an osteon, or haversian system. Each osteon is composed of concentric rings of calcified...
16.9K
 01:15
Torque Free Motion
849
The torque-free motion refers to the movement of a rigid body in space when no external torques are acting upon it. This type of motion can be observed in environments where there are no external forces or frictions, like in outer space. For example, a rotation of Mars in space is a torque-free motion. Mars is an axisymmetric object, meaning it has an axis of symmetry along which it rotates, designated as the z-axis. The rotating frame of reference is defined such that the center of mass of...
849
 01:19
Net Torque Calculations
11.6K
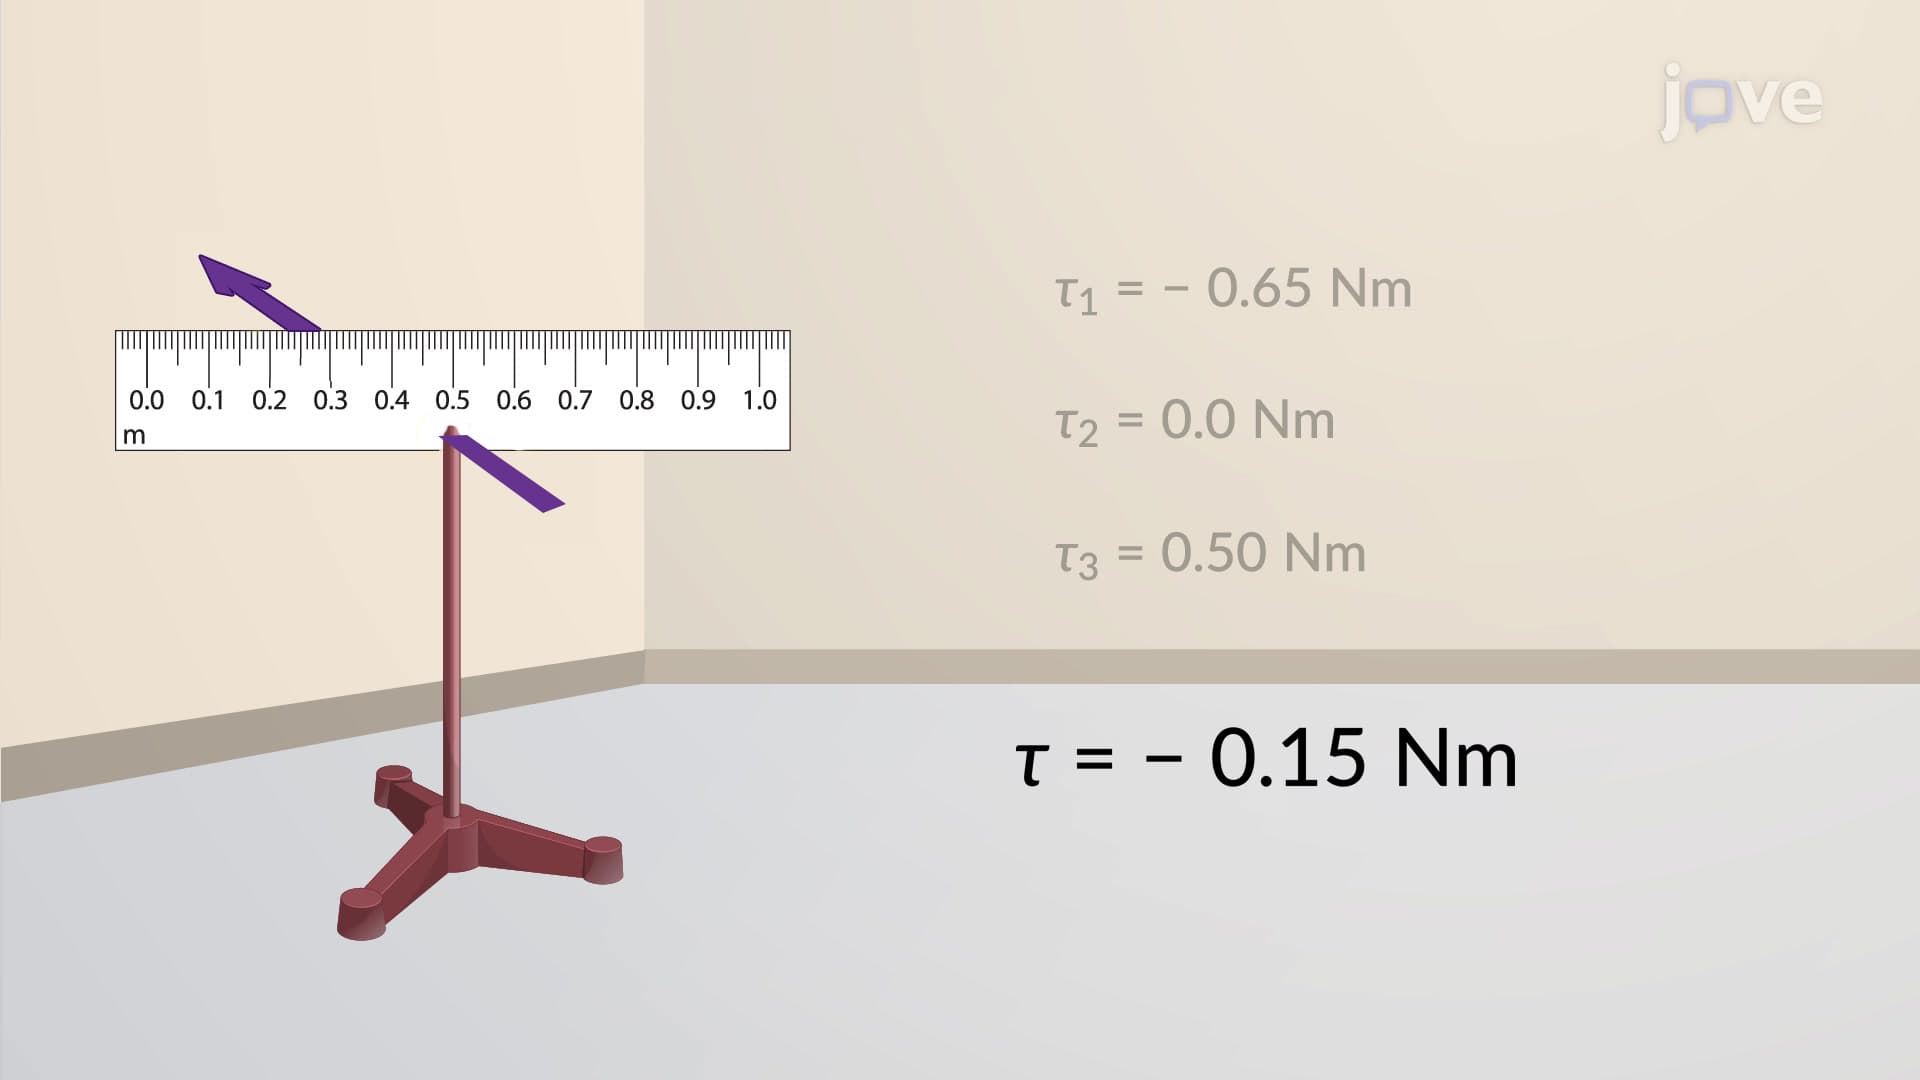
When a mechanic tries to remove a hex nut with a wrench, it is easier if the force is applied at the farthest end of the wrench handle. The lever arm is the distance from the pivot point (the hex nut in this case) to the person’s hand. If this distance is large, the torque is higher. Only the component of the force perpendicular to the lever arm contributes to the torque. Therefore, pushing the wrench perpendicular to the lever arm is more advantageous. If multiple people apply force to...
11.6K