
均一な究極の境界性を持つ不確実な複数のセクションのウェブマシンの適応的有限時間ハイブリッドテンション-速度制御
Van Trong Dang1, Viet Thang Dang1, Xuan Bo Nguyen1
1Hanoi University of Science and Technology, Hanoi 100000, Viet Nam.
ISA transactions
|February 14, 2026

まとめ
この研究は,多セクションウェブマシンのための適応的有限時間制御を導入し,干渉と不確実性に対するパフォーマンスを向上させます. この新しいアプローチは,未知のパラメータであっても,安定性と高い精度を保証します.
科学分野:
- 製造業 エンジニアリング
- 制御システム理論 制御システム理論
- ロボット工学 ロボット工学 ロボット工学
背景:
- マルチセクション・ウェブ・マシンは,外部からの干渉,パラメータの不確実性,測定ノイズによる性能低下に直面しています.
- 効率的な制御設計は,要求の厳しい製造環境での運用パフォーマンスの維持に不可欠です.
- 既存の制御方法は,これらの複雑な課題を同時に解決するために苦労しています.
研究 の 目的:
- マルチセクション・ウェブ・マシンのための適応的有限時間ハイブリッド・テンション・スピード制御アプローチを開発する.
- パラメータの不確実性,外部干渉,測定ノイズを軽減することによって,機械の性能を向上させる.
- 限られた時間内に高精度の操作とシステムの安定性を確保するためです.
主な方法:
- フィルターベースの拡張状態オブザーバー (ESO) は,測定ノイズをフィルタリングしながら,不確実性と干渉を同時に推定するために提案されています.
- ダイナミック・サーフェス・コントロール (DSC) は,バックステッピングと非線形低通路フィルタを組み合わせて,精密なテンション・スピード制御を実現しています.
- 慣性の瞬間の事前の知識の必要性を排除するために,適応メカニズムが統合されています.
主要な成果:
- 提案されたESOは,実用的な有限時間安定性を達成し,推定精度を向上させます.
- DSCのアプローチは,有限時間におけるウェブマシンの高精度のパフォーマンスを保証します.
- Lyapunovの分析は,オブザーバーとクローズド・ループ・システムの均一な究極の境界性と明示的な定着時間を確認しています.
- シミュレーションは,最先端の方法と比較して優れた有効性を示しています.
結論:
- アダプティブ・フィニット・タイム・ハイブリッド・コントロール・ストラテジーは,マルチセクション・ウェブ・マシンの複雑な乱れや不確実性を効果的に対処します.
- 開発された方法は,安定性と有限時間収束を保証した堅牢で高精度の制御を保証します.
- このアプローチは,困難な産業環境でウェブマシンを制御する上で,大きな進歩をもたらします.
さらに関連する動画
 10:17
Insect-machine Hybrid System: Remote Radio Control of a Freely Flying Beetle Mercynorrhina torquata
Published on: September 2, 2016
12.8K
 09:35
Preparation and Evaluation of Hybrid Composites of Chemical Fuel and Multi-walled Carbon Nanotubes in the Study of Thermopower Waves
Published on: April 10, 2015
9.3K
関連する概念動画
 01:10
Tension
14.0K
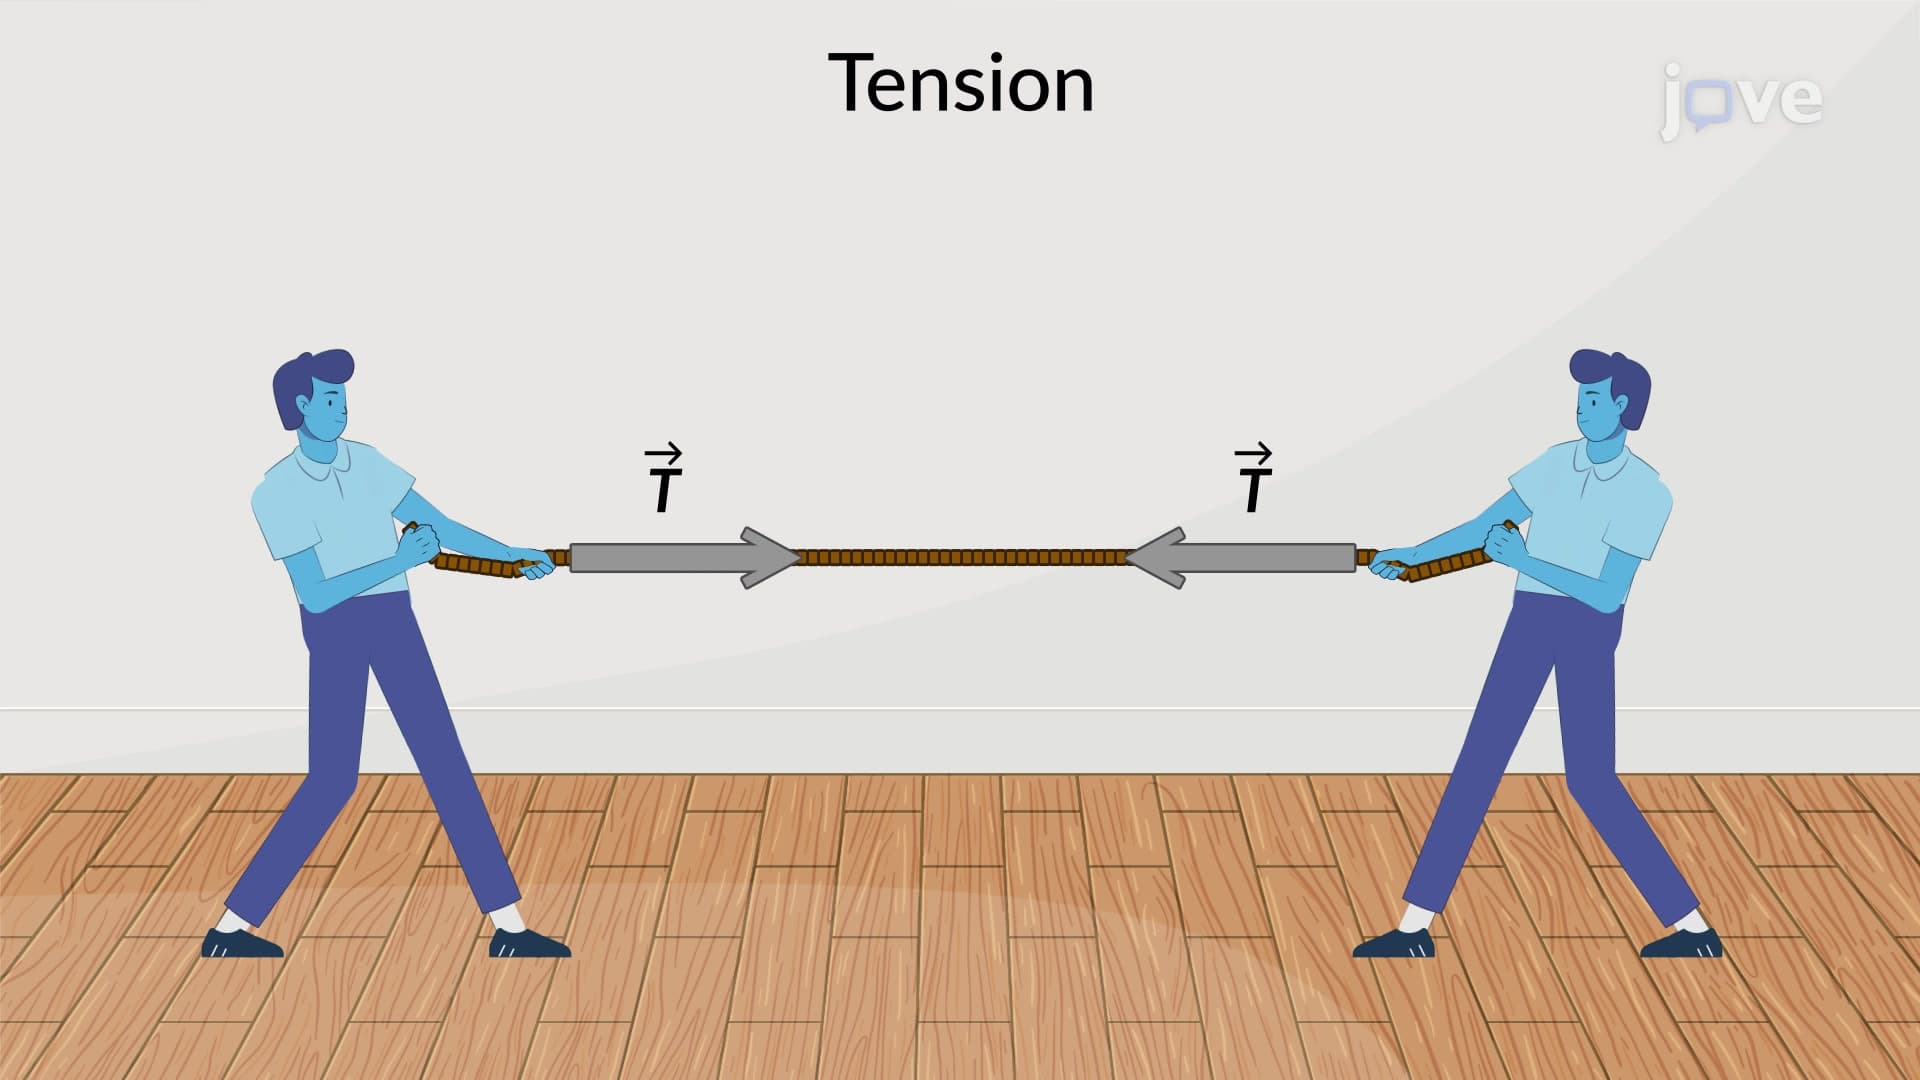
Tension is a force along the length of a medium, in particular, a force carried by a flexible medium, such as a rope or cable. The word "tension" comes from Latin, meaning "to stretch". Not coincidentally, the flexible cords that carry muscle forces to other parts of the body are called tendons. Any flexible connector, such as a string, rope, chain, wire, or cable, can exert pull only parallel to its length; so, a force carried by a flexible connector is a tension with a...
14.0K
 02:29
Hybrid Zones
22.0K
Hybrid zones are narrow regions where two closely related species interact, mate, and produce hybrids. Relative to either parent species, hybrids may possess distinct phenotypic or genetic differences that impact their survival and reproductive success. The genetic variances introduced by hybridization influence species diversity and speciation processes within the hybrid zone.
22.0K
 01:19
Uniform Distribution
6.2K
The uniform distribution is a continuous probability distribution of events with an equal probability of occurrence. This distribution is rectangular.
Two essential properties of this distribution are
Two essential properties of this distribution are
6.2K
 02:57
Surface Tension, Capillary Action, and Viscosity
33.7K
Surface Tension
The various IMFs between identical molecules of a substance are examples of cohesive forces. The molecules within a liquid are surrounded by other molecules and are attracted equally in all directions by the cohesive forces within the liquid. However, the molecules on the surface of a liquid are attracted only by about one-half as many molecules. Because of the unbalanced molecular attractions on the surface molecules, liquids contract to form a shape that minimizes the number...
The various IMFs between identical molecules of a substance are examples of cohesive forces. The molecules within a liquid are surrounded by other molecules and are attracted equally in all directions by the cohesive forces within the liquid. However, the molecules on the surface of a liquid are attracted only by about one-half as many molecules. Because of the unbalanced molecular attractions on the surface molecules, liquids contract to form a shape that minimizes the number...
33.7K
 01:07
Time-Domain Interpretation of PD Control
411
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
411
 01:19
Machines
584
Machines are complex structures consisting of movable, pin-connected multi-force members that work together to transmit forces. One example of a machine is the cutting plier, which is used to cut wires by applying forces to its handles. When equal and opposite forces are exerted on the handles of the cutting plier, they cause the cutting edges to come together and apply equal and opposite reaction forces on the wire, which are greater than the applied forces.
A free-body diagram of the...
A free-body diagram of the...
584