
卓球ポーズによる運動分析と,人工知能に基づく参加動機と選手の満足度の分析 YOLOv8
Kaihao Yu1, Shamsulariffin Bin Samsudin2, Mohd Aswad Ramlan3
1Department of Sports Studies, Faculty of Educational Studies, Universiti Putra Malaysia, 43400, Serdang, Selangor, Malaysia.
Scientific reports
|February 15, 2026

まとめ
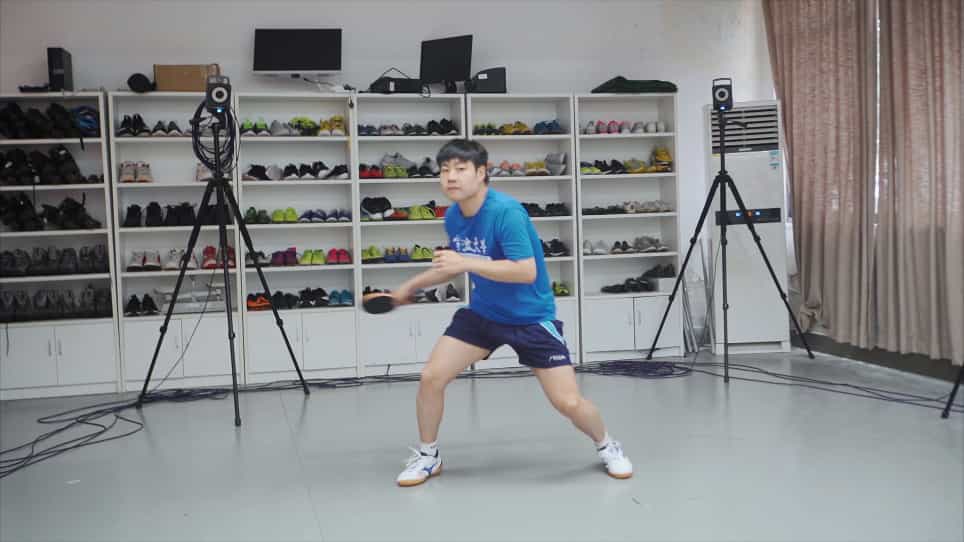
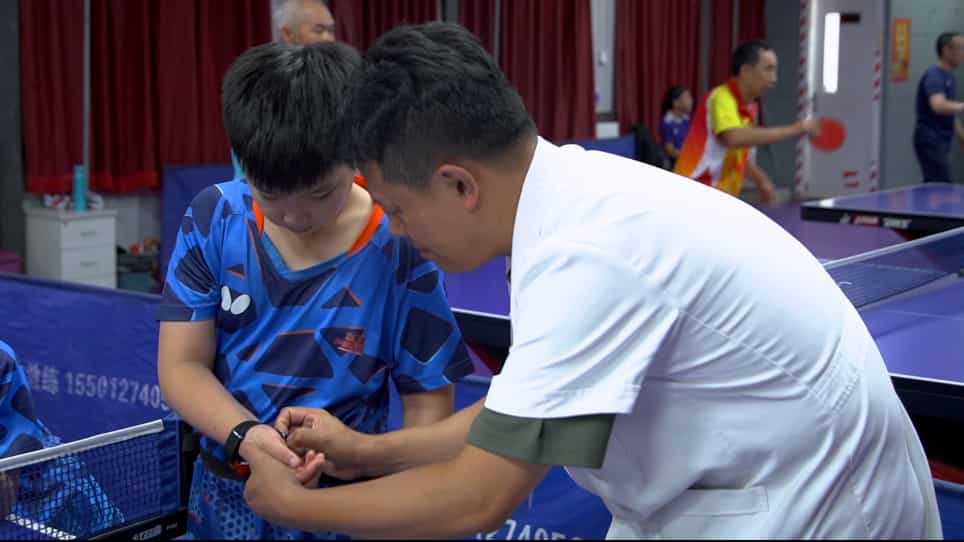
この研究では,テーブルテニスのポーズ推定のための軽量AIモデルであるLAFPoseを導入し,アスリートのモチベーションとトレーニングフィードバックを改善します. このシステムは,リアルタイムの運動分析を通じて,パフォーマンスの分析とアスリートのエンゲージメントを向上させます.
科学分野:
- スポーツ科学 スポーツ科学
- コンピュータ・ビジョン コンピュータ・ビジョン
- 人工知能 (AI) とは,人工知能 (AI) のことです.
背景:
- ポーズベースの運動分析は,卓球のテクニカル評価とフィードバックに不可欠です.
- 人工知能 (AI) とポーズ推定は,リアルタイム運動分析のための高度な方法を提供します.
研究 の 目的:
- 卓球のための軽量で効率的なポーズ推定ネットワークを開発する.
- スポーツ選手のモチベーションとトレーニング経験に対するAI駆動の運動分析の影響を評価する.
主な方法:
- YOLOv8m-Poseに基づいた軽量注意力強化融合ポーズ推定ネットワーク (LAFPose) を提案しました.
- 組み込みのMobileNetV3,CBAM,アダプティブキーポイント強化,およびネットワーク最適化のためのCARAFEモジュール.
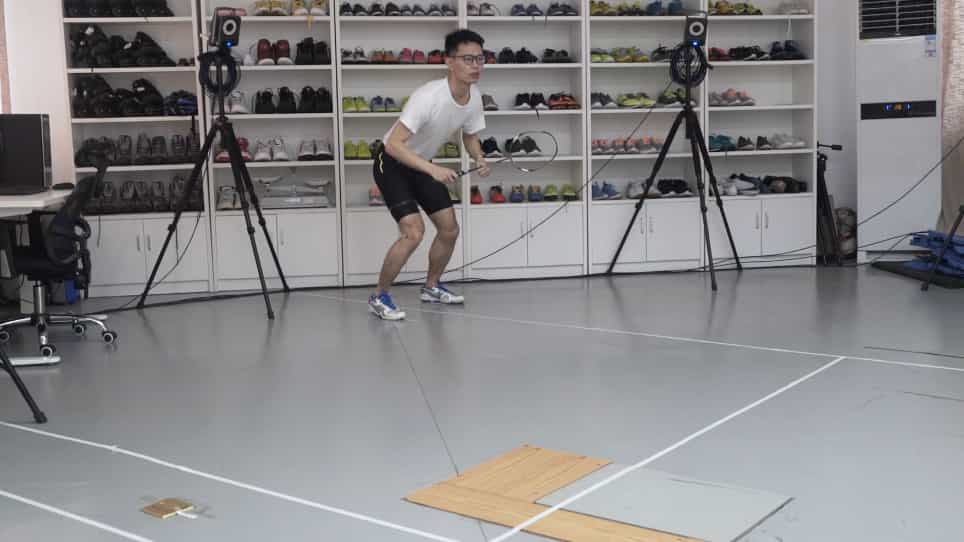
- UCF101データセットの実験と,3つのグループで120人のアスリートを対象とした経験的研究を行いました.
主要な成果:
- LAFPoseは33.2MBのモデルサイズと46GFLOPSで86.8%の精度を達成しました.
- リアルAI介入グループは,やる気 (18.45から20.75) と満足度 (3.62から4.21) のスコア (p <0.001) で有意な増加を示しました.
- AI主導のフィードバックは,アスリートのエンゲージメントを高めるのに大きな効果サイズ (Cohen's d) を示しました.
結論:
- LAFPoseは,ポーズ推定のための計算効率と精度の優れたバランスを提供します.
- AIが駆動する運動分析とリアルタイムのフィードバックは,アスリートのモチベーションとトレーニング体験を大幅に高めます.
- この発見は,インテリジェントなスポーツトレーニングシステムとスポーツ心理学に実用的な意味を持ちます.
関連する概念動画
 01:24
Absolute Motion Analysis- General Plane Motion
615
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
615
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
782
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
782
 01:25
Relative Motion Analysis using Rotating Axes
974
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
974
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
876
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
876
 01:10
Relative Motion Analysis - Acceleration
938
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
938