関連する実験動画
Updated: Feb 25, 2026
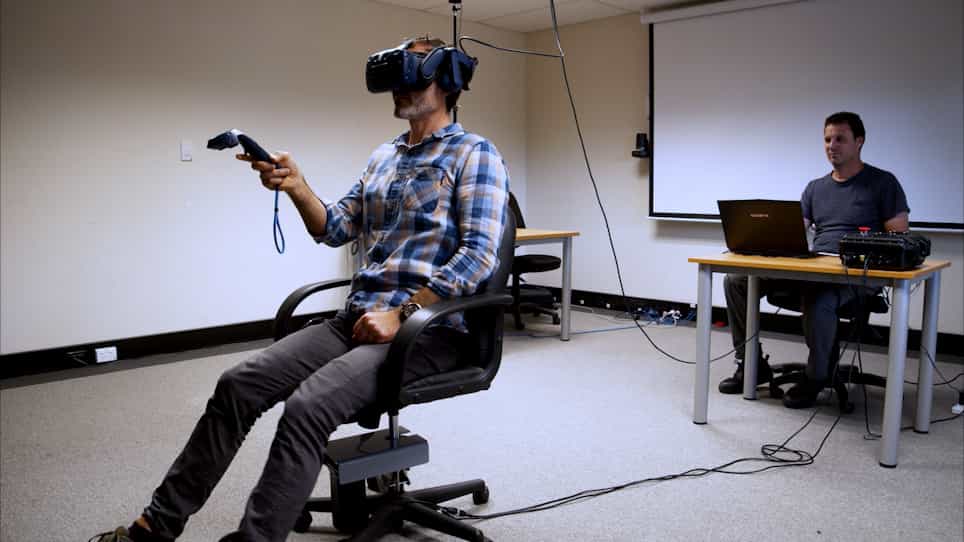

Controlled Rotation of Human Observers in a Virtual Reality Environment
Published on: April 21, 2022
ポイント操作 vs. 体重移動指示インターフェイスにおける離散的仮想回転: uni vs. bimanual の視点

Abstract:
In this work, we explore the integration of Orientation Selection into Steering interfaces, aiming to preserve the seamless sensation of real-world movement while mitigating the risk of inducing cybersickness. Our implementation encounters conflicts in standard input mappings, prompting us to adopt bimanual interaction as a solution. Recognizing the complexity of interaction that may arise from this step, we also develop unimanual alternatives, e.g., utilizing a Human-Joystick, commonly referred to as a Leaning interface. The outcomes of an empirical study centered around a primed search task yield unexpected findings. We observed a sample of users spanning multiple levels of gaming experience and a balanced gender distribution exhibit no significant difficulties with the bimanual, asymmetric interfaces. Remarkably, the performance of Orientation Selection is, as in prior work, at least on par with Snap Rotation. Moreover, through a subsequent exploratory analysis, we uncover indications that Pointing-Directed Steering outperforms embodied interfaces in usability and task load in the given setting.
関連する概念動画
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:20
Instantaneous Center of Zero Velocity
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...