関連する実験動画
Updated: Feb 27, 2026


Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
球形ベジェ曲線ベースの効率的な改良型指数三角法最適化を利用した3D無人航空機スムーズ経路計画
Yitao Cao1, Kang Chen1, Gang Hu2
1Unmanned System Research Institute, Northwestern Polytechnical University, Xi'an 710072, China.

Abstract:
Path planning, as a key technology in unmanned aerial vehicle (UAV) systems, affects the overall efficiency of task completion and is often limited by energy consumption, obstacles, and maneuverability in complex application environments. Traditional algorithms have insufficient performance in nonlinear, multimodal, and multiconstraints problems. Based on this, this paper proposes an improved exponential-trigonometric optimization (ETO) to solve a 3D smooth path planning model based on a spherical Bezier curve. Firstly, a fixed arc length resampling strategy is proposed to address the issue of the insufficient adaptability of existing path smoothing methods to dynamic threats. Generate a uniformly distributed set of reference points along the Bezier curve and combine it with spherical projection to improve the safety and efficiency of the flight path. On this basis, establish a total cost function that includes four types of costs. Secondly, a new ETO variant called IETO is proposed by introducing the alpha evolution strategy, noise and physical attack strategy, and opposition-based cross teaching strategy into ETO. Then, the effectiveness of IETO for addressing various optimization problems is showcased through population diversity analysis, ablation analysis, and benchmark experiments. Finally, the results of the simulation experiment indicate that IETO stably provides shorter and smoother safe paths for UAVs in three elevation maps with different terrain features.

関連する概念動画
 01:20
Elevation of Intermediate Points on Vertical Curves
 01:26
Orthogonal Trajectories
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:23
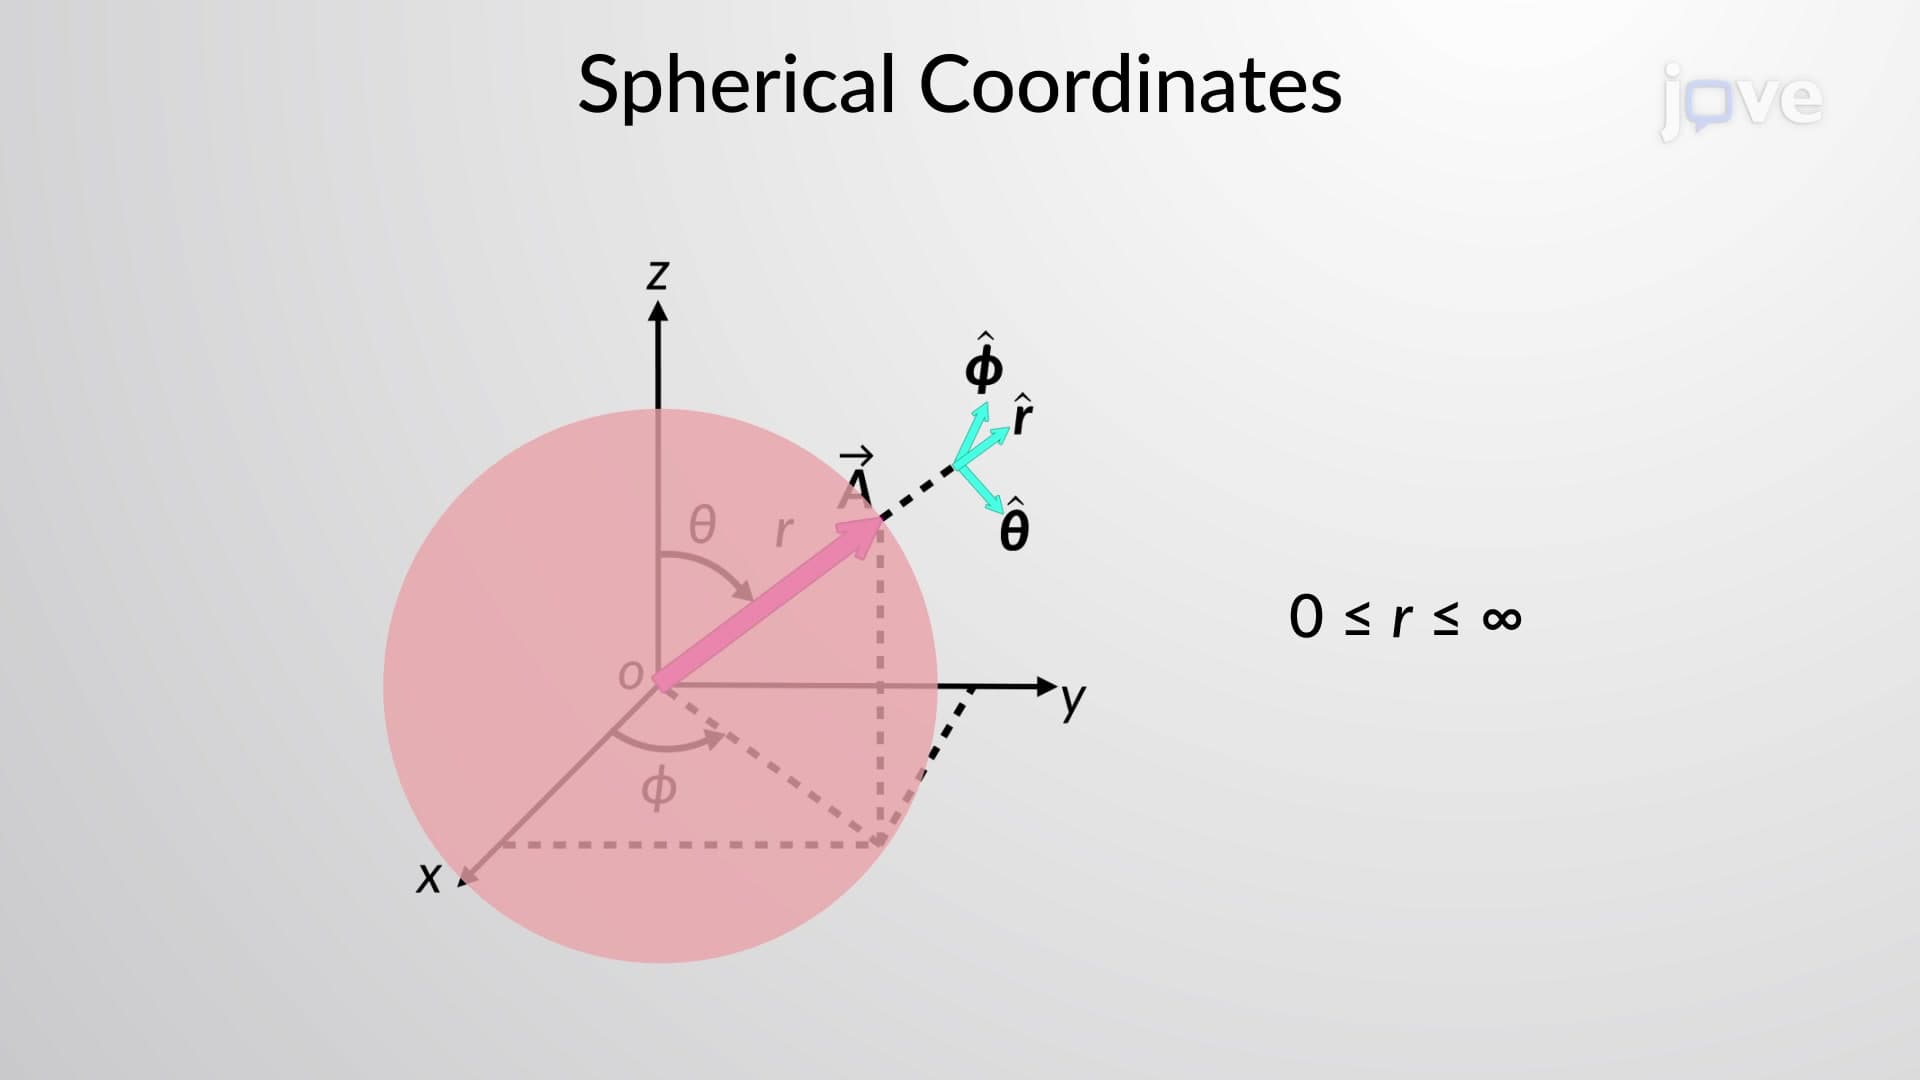
Spherical Coordinates
 01:22
Non-uniform Circular Motion
For example, such...
 01:21
Arc Length of a Curve: Problem Solving