
注意偏差对3D旋转物体的影响 狗的识别能力
Marcello Siniscalchi1, Serenella d'Ingeo1, Angelo Quaranta1
1Animal Physiology and Behaviour Unit, Department of Veterinary Medicine, University of Bari Aldo Moro, 70121 Bari, Italy.
Animals : an open access journal from MDPI
|May 27, 2023

概括
狗可以识别旋转的3D物体,当图像在左边时表现更好,这表明右脑对空间任务的主导地位. 这表明狗可能具有用于形状歧视的旋转不变性.
科学领域:
- 认知科学是一种认知科学.
- 动物行为 动物行为
- 神经科学是一个神经科学.
背景情况:
- 视觉空间认知能力对于在动态环境中生存至关重要.
- 虽然许多动物可以识别旋转的物体,但狗的视觉空间技能仍未得到充分研究.
- 物从事需要先进视觉空间能力的活动.
研究的目的:
- 为了研究家养狗的视觉空间技能.
- 为了确定狗能否区分三维 (3D) 物体和它们的旋转版本.
- 探索潜在的半球专业化在狗视觉空间处理.
主要方法:
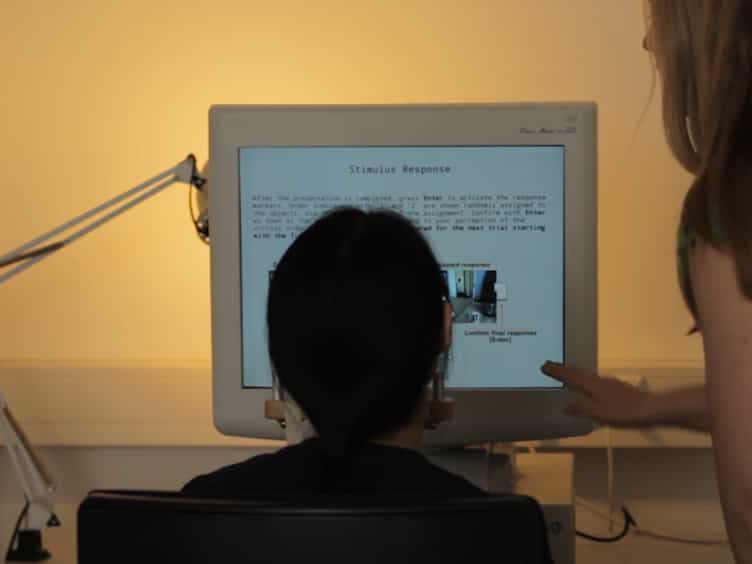
- 六只狗被训练使用修改的谢帕德-梅茨勒任务.
- 数字3D对象及其旋转版本 (45°和180°) 在计算机屏幕上呈现.
- 对象识别性能是根据呈现侧面 (左与右) 进行评估的.
主要成果:
- 狗成功地区分了3D物体和它们的旋转形式.
- 当刺激呈现在屏幕左侧时,对象识别更准确.
- 在任务执行方面观察到显著的个体间变化.
结论:
- 初步发现表明,狗可能表现出右半球对视觉空间功能的优越性.
- 狗可能会使用旋转不变过程来区分3D旋转形状.
- 需要进一步的研究来证实狗的视觉空间能力.
相关概念视频
 01:25
Relative Motion Analysis using Rotating Axes
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...