相关实验视频
Updated: Jul 29, 2025

10:09

Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
6.7K
基于MZI的矩阵计算的硬件错误纠正
Huihuang Hou1,2, Pengfei Xu3, Zhiping Zhou3,4
1Key Laboratory of Optoelectronic Materials Chemistry and Physics, Fujian Institute of Research on the Structure of Matter, Chinese Academy of Sciences, Fuzhou 350002, China.
Micromachines
|May 27, 2023

概括
使用马赫-泽恩德干扰仪 (MZI) 的基于的光电子计算为更快的人工智能提供了一条道路. 这项研究确定了MZI硬件错误,并提出了一种新的架构,以显著提高改进的光电子系统的计算精度.
科学领域:
- 光电学是指光电子产品.
- 光子学 光子学
- 人工智能 硬件 硬件
背景情况:
- 随着人工智能的发展,电子系统面临着计算速度的限制.
- 基于的光电子计算,特别是基于马赫-泽恩德干扰仪 (MZI) 的矩阵计算,是一个有前途的替代方案.
- 在MZI计算中的精度问题阻碍了其广泛采用.
研究的目的:
- 在基于MZI的矩阵计算中识别主要的硬件错误源.
- 审查MZI设备和网格的现有硬件错误纠正策略.
- 提出一种新的架构,以提高MZI计算精度,而不会增加设备足迹.
主要方法:
- 分析马赫-泽恩德干扰仪 (MZI) 设备中的硬件错误来源.
- 对基于MZI的光电子系统的错误纠正技术的文献综述.
- 开发和模拟一种新的MZI架构,以改进矩阵计算.
主要成果:
- 在MZI计算中详细识别关键的硬件错误贡献者.
- 目前的错误缓解方法的全面总结.
- 一个拟议的架构展示了显著的精度增强潜力.
结论:
- 解决硬件错误对于实现基于MZI的精确光电子计算至关重要.
- 拟议的架构为高精度矩阵运算提供了可行的解决方案.
- 这一进步为更快,更准确的AI系统铺平了道路.

相关概念视频
 01:24
Bus Impedance Matrix
152
Calculating subtransient fault currents for three-phase faults in an N-bus power system involves using the positive-sequence network. When a three-phase short circuit occurs at a specific bus, the analysis uses the superposition method to evaluate two separate circuits.
In the first circuit, all machine voltage sources are short-circuited, leaving only the prefault voltage source at the fault location. The positive-sequence bus impedance matrix can be determined by solving the nodal equations,...
In the first circuit, all machine voltage sources are short-circuited, leaving only the prefault voltage source at the fault location. The positive-sequence bus impedance matrix can be determined by solving the nodal equations,...
152
 01:36
Mismatch Repair
40.4K
Overview
40.4K
 01:12
Types of Errors: Detection and Minimization
1.7K
Error is the deviation of the obtained result from the true, expected value or the estimated central value. Errors are expressed in absolute or relative terms.
Absolute error in a measurement is the numerical difference from the true or central value. Relative error is the ratio between absolute error and the true or central value, expressed as a percentage.
Errors can be classified by source, magnitude, and sign. There are three types of errors: systematic, random, and gross.
Systematic or...
Absolute error in a measurement is the numerical difference from the true or central value. Relative error is the ratio between absolute error and the true or central value, expressed as a percentage.
Errors can be classified by source, magnitude, and sign. There are three types of errors: systematic, random, and gross.
Systematic or...
1.7K
 01:00
Detection of Gross Error: The Q Test
6.3K
When one or more data points appear far from the rest of the data, there is a need to determine whether they are outliers and whether they should be eliminated from the data set to ensure an accurate representation of the measured value. In many cases, outliers arise from gross errors (or human errors) and do not accurately reflect the underlying phenomenon. In some cases, however, these apparent outliers reflect true phenomenological differences. In these cases, we can use statistical methods...
6.3K
 01:25
Multimachine Stability
200
Multimachine stability analysis is crucial for understanding the dynamics and stability of power systems with multiple synchronous machines. The objective is to solve the swing equations for a network of M machines connected to an N-bus power system.
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
200
 01:19
Routh-Hurwitz Criterion II
304
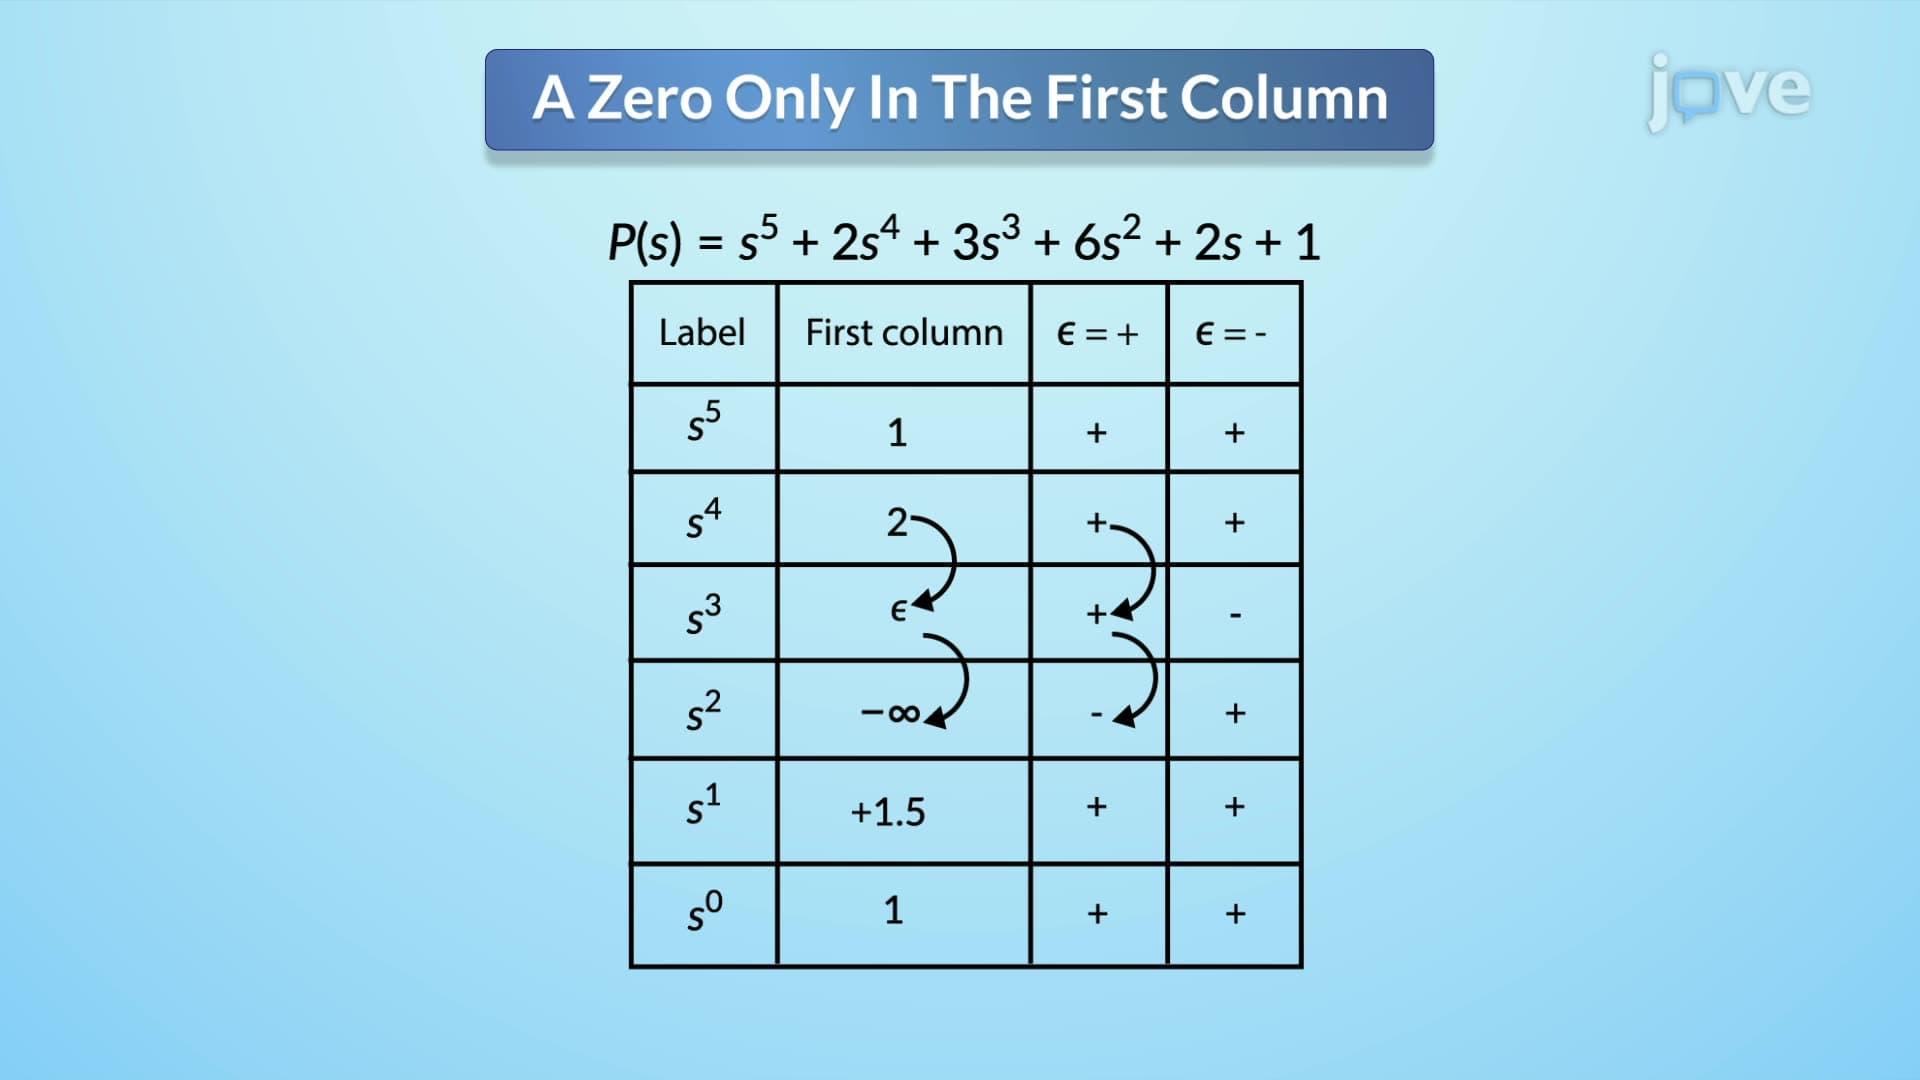
In the application of the Routh-Hurwitz criterion, two specific scenarios can arise that complicate stability analysis.
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first...
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first...
304