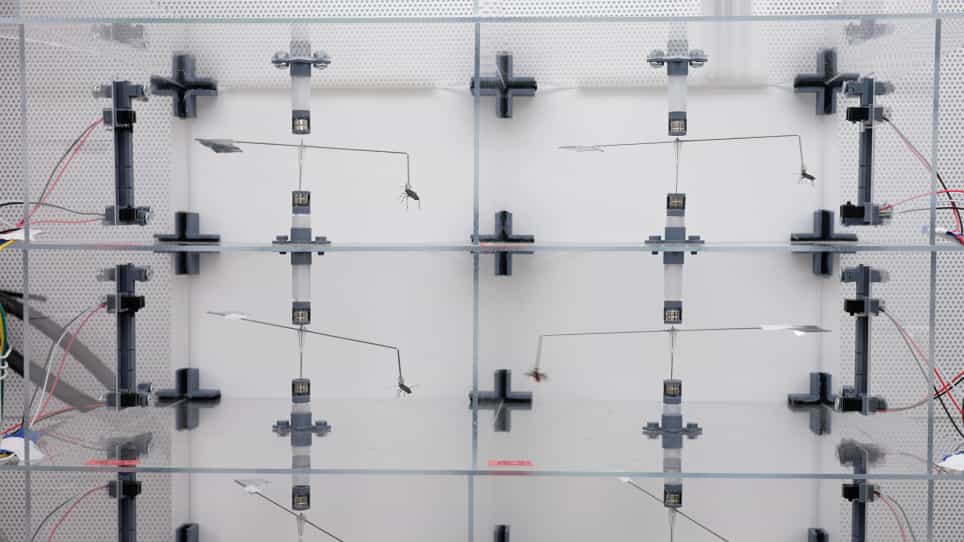
在高海拔环境中,无尾翼飞机器人的首次起飞和飞行性能
Shu Tsuchiya1, Hikaru Aono2,3, Keisuke Asai4,5
1Graduate School of Science and Technology, Shinshu University, Nagano, 3868567, Japan.
Scientific reports
|June 2, 2023

概括
研究人员首次在低密度,高空条件下实现了摇机器人的起飞. 机翼大小和运动缩放使得持续升空成为可能,为多高度自主传感铺平了道路.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 空气动力学 在空气动力学.
- 生物启发工程 生物启发工程
背景情况:
- 动物的飞行是复杂的,使其能够在各种环境中进行导航.
- 由于在低密度空气中产生升力方面的挑战,高空飞飞行仍然未被充分探索.
研究的目的:
- 为了在低密度环境中演示飞翼机器人首次成功起飞.
- 为了研究在降低空气密度的条件下飞行飞行的缩放原理.
主要方法:
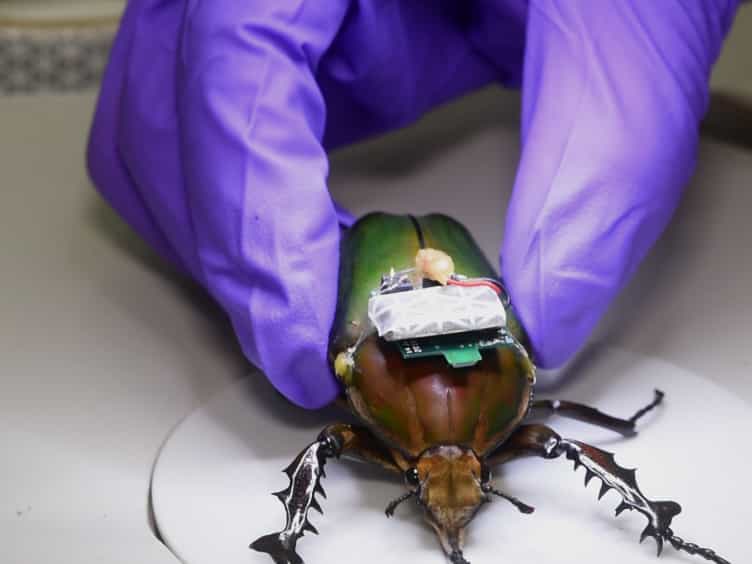
- 开发了一种能够调整翅膀大小和运动的飞机器人.
- 在模拟的低密度环境中进行飞行测试 (66%的空气密度降低).
- 测量了起重力和分析了机翼动力学 (振幅,斜率).
主要成果:
- 在低密度条件下实现0.14N的提升力.
- 增加了翻拍幅度 (148°到233°),同时保持了音调幅度 (38.2°).
- 证明,缩小翅膀尺寸和降低飞频率,而不仅仅是增加频率,是低密度飞行的关键.
结论:
- 在低密度,高海拔环境中,通过利用不稳定的空气动力学机制来实现翼飞行.
- 这项研究为翼变形和被动旋转提供了生物启发的缩放关系.
- 这项研究是自主多高度感应机器人和潜在的火星大气飞行的基本步骤.

相关概念视频
 01:23
Lift
203
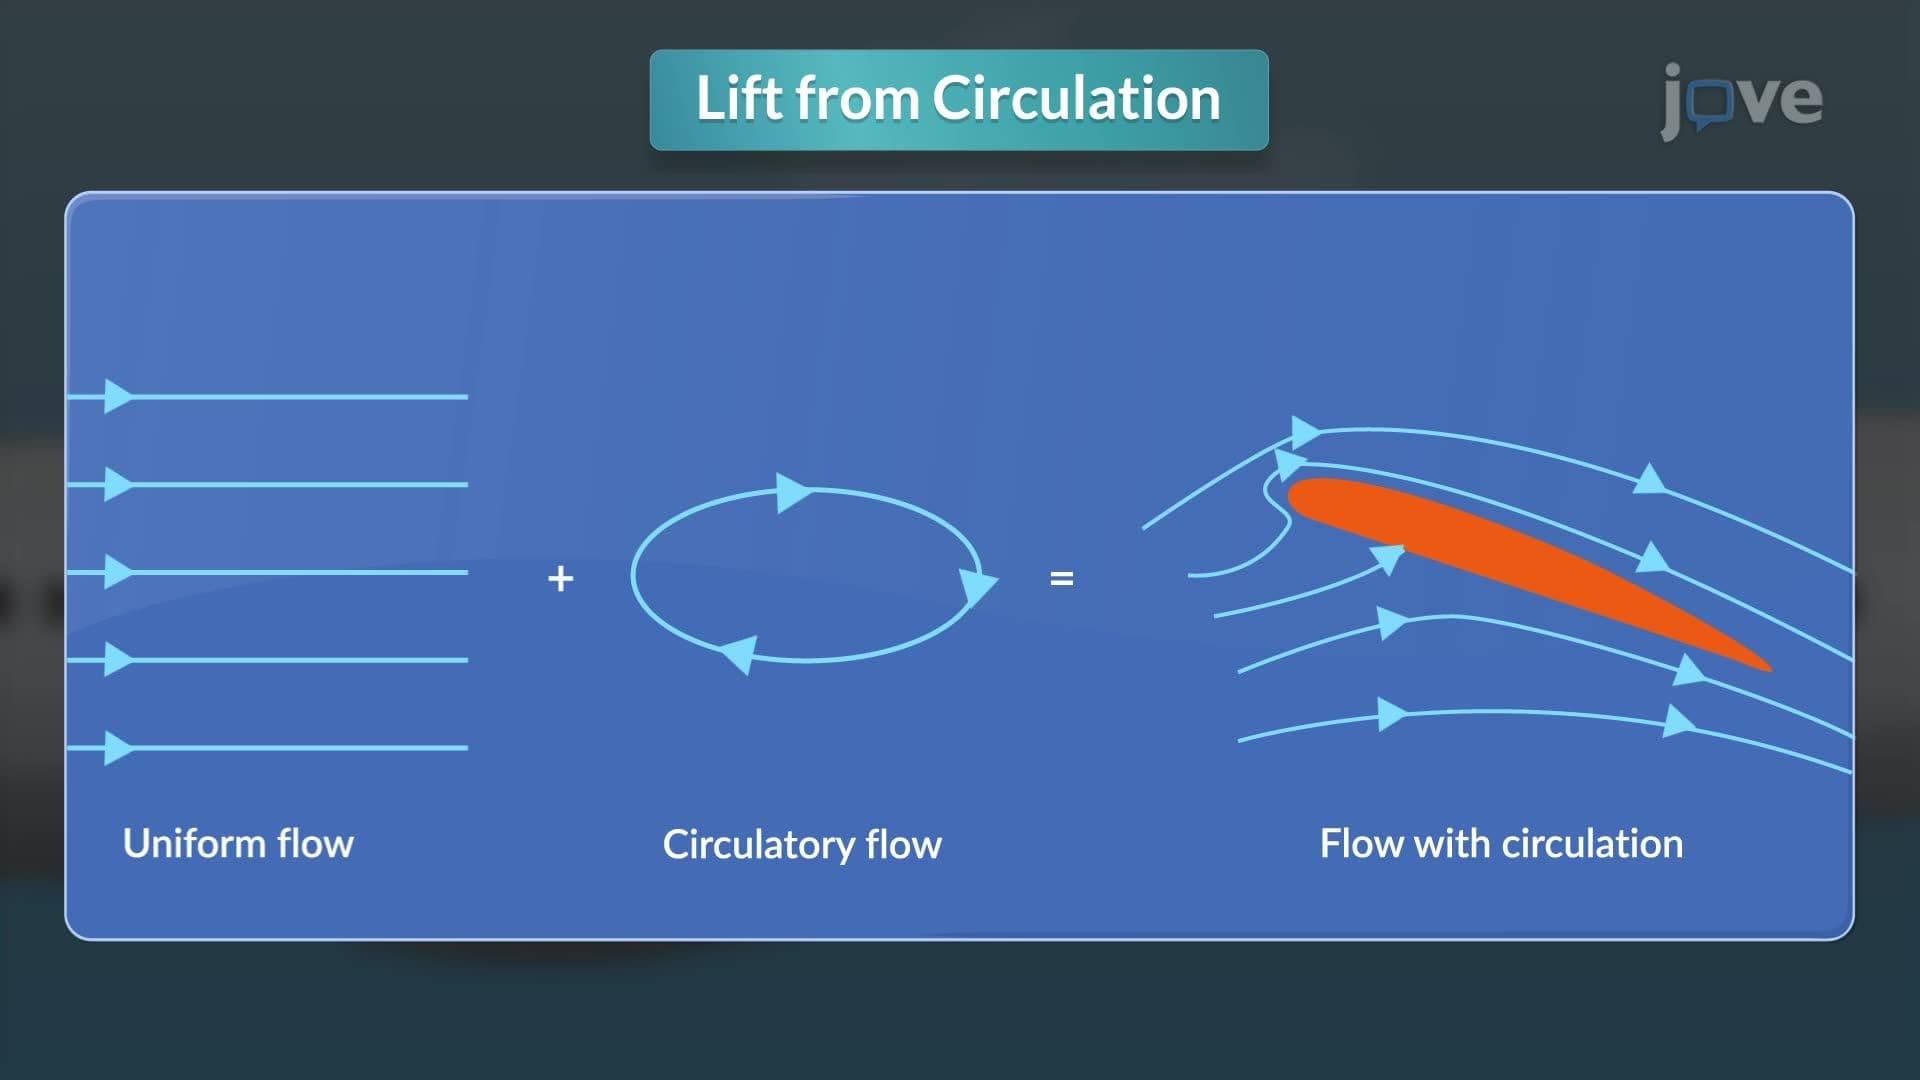
Lift is a fundamental aerodynamic force that acts perpendicular to the direction of airflow. It plays a central role in achieving and sustaining flight and in stabilizing various vehicles. Lift primarily originates from pressure differences created across surfaces, such as an airfoil. A lower pressure region forms above the wing, while a higher pressure region forms below it, generating an upward force. This differential results from the shape and orientation of the airfoil, enabling the wing...
203
 01:24
Absolute Motion Analysis- General Plane Motion
244
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
244
 01:26
Impact: Problem Solving
247
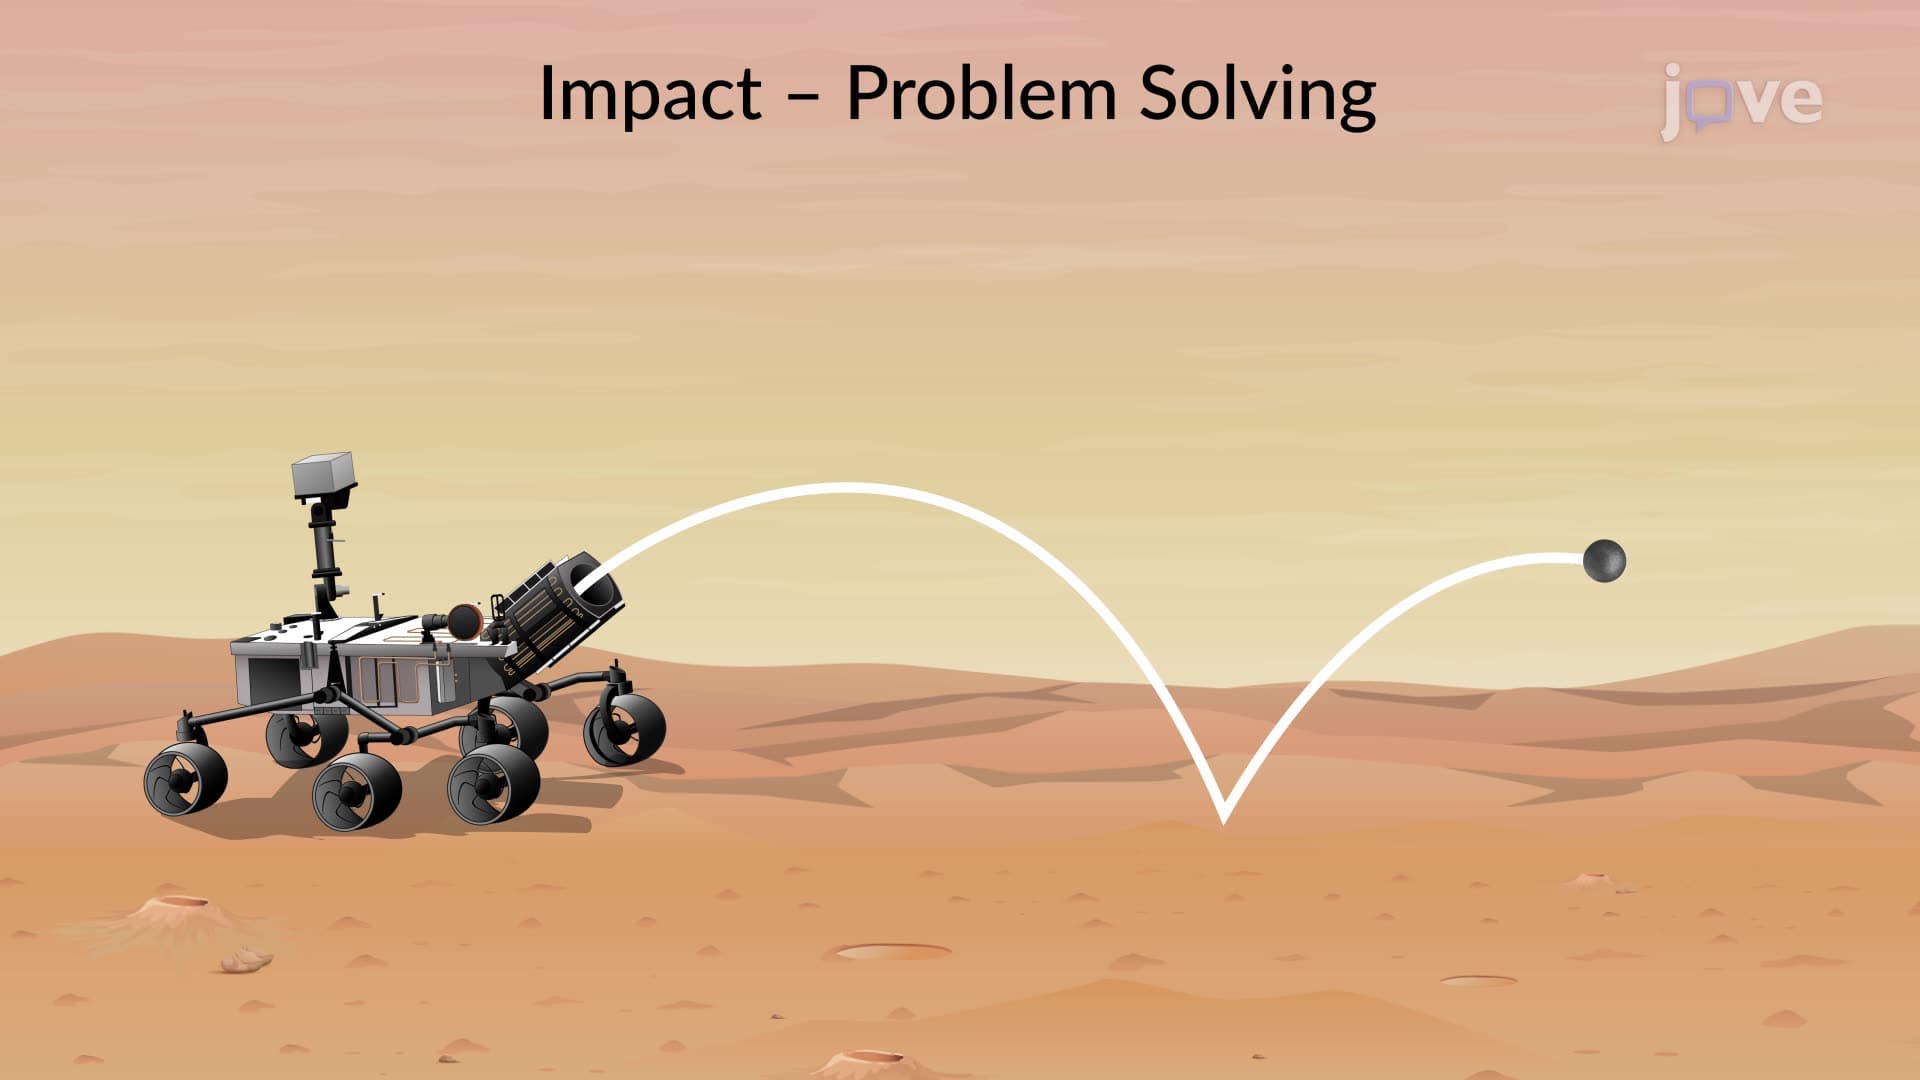
In an experiment conducted during a Mars mission, a rover propels a projectile with an initial velocity, and the projectile rebounds after colliding with the Martian surface. To ascertain the maximum height attained by the projectile after this collision, the known restitution coefficient and acceleration due to gravity are employed.
By designating the launch point as the origin and utilizing kinematic equations, the vertical component of the projectile's velocity at the point of impact is...
By designating the launch point as the origin and utilizing kinematic equations, the vertical component of the projectile's velocity at the point of impact is...
247