

对于近中心摄像系统的非代通用摄像机模型
Taehyeon Choi1, Seongwook Yoon1, Jaehyun Kim1
1School of Electrical Engineering, Korea University, 145 Anam-ro, Seongbuk-gu, Seoul 02841, Republic of Korea.

这项研究引入了非中心摄像头的新摄像头校准方法,提高了准确性和速度. 该方法使用稀疏点和光滑的3D残余框架进行高效和精确的摄像机模型校准.
科学领域:
- 计算机视觉 计算机视觉
- 几何建模 几何建模
背景情况:
- 传统的摄像机校准方法与非中心摄像机模型相斗争.
- 一般化的摄像机模型需要密集点,并且计算密集.
研究的目的:
- 为近中心摄像头开发一种高效准确的校准方法.
- 为了解决现有的代和密度点依赖校准技术的局限性.
主要方法:
- 提出了一种使用稀疏观察点的非代射线校正方法.
- 建立了一个光滑的三维 (3D) 残余框架.
- 使用局部逆距离权重进行剩余插值.
主要成果:
- 实现了快速而准确的摄像机校准.
- 在的盾牌数据集上,降低了约63%的深度误差.
- 与代方法相比,证明了两次数量级的速度改善.
结论:
- 拟议的非代方法为近中心相机校准提供了计算效率高,准确的解决方案.
- 平滑的3D余向量提供比2D实体更准确的射线方向表示.
更多相关视频
 11:53
The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
 11:57
Three-dimensional Super Resolution Microscopy of F-actin Filaments by Interferometric PhotoActivated Localization Microscopy iPALM
Published on: December 1, 2016
相关概念视频
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:27
Curvilinear Motion: Normal and Tangential Components
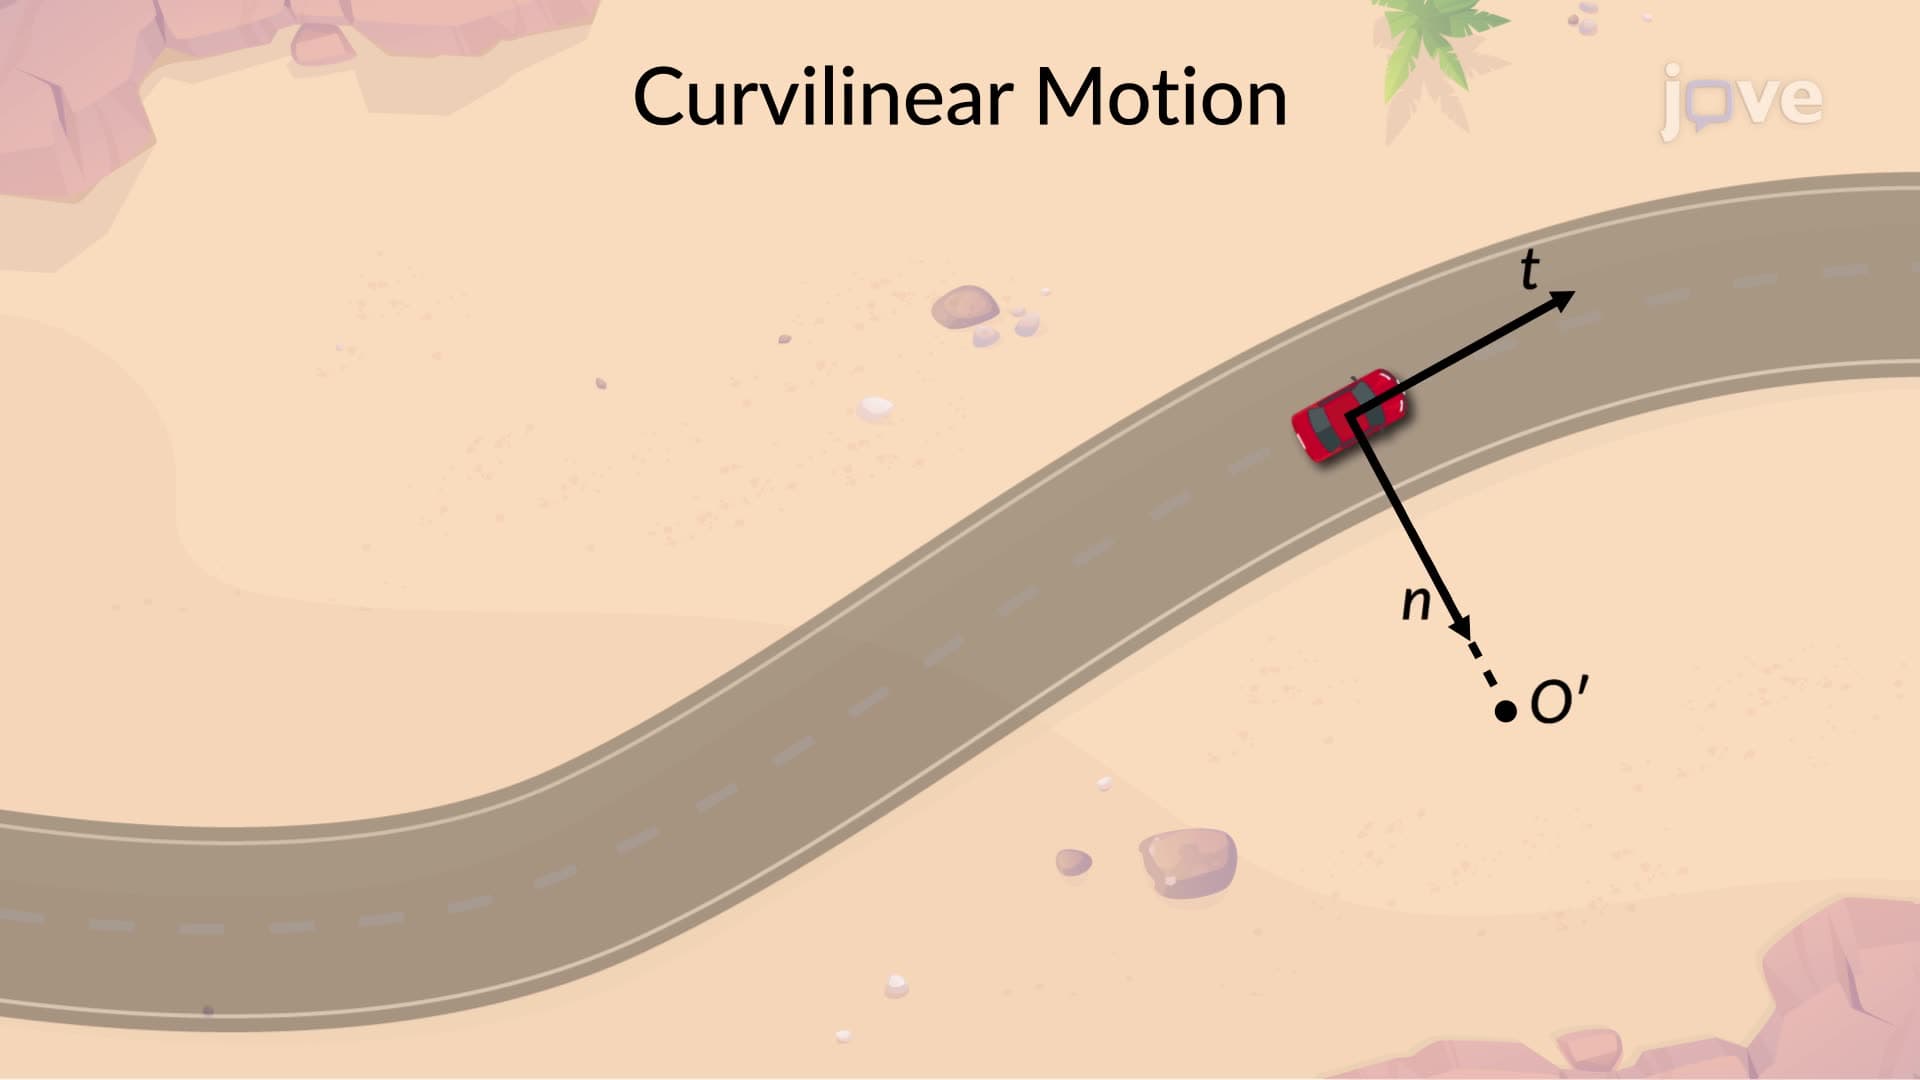
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...