

新型自适应式归零神经动力学方案,用于时间变化的线性方程处理,应用于臂路径跟踪和目标运动定位
1School of Computer Science and Engineering, Sun Yat-sen University, Guangzhou 510006, China; Key Laboratory of Machine Intelligence and Advanced Computing, Ministry of Education, Guangzhou 510006, China.

概括
这项研究引入了自适应式归零神经动力学 (ZND) 来解决具有时间变化的参数的线性方程,比传统方法提高速度和准确性. 新的自适应离散ZND算法为现实应用提供了卓越的性能.
科学领域:
- 神经动力学 神经动力学
- 计算数学是指计算数学.
- 机器人技术 机器人技术 机器人技术
背景情况:
- 对于时间变量的线性方程 (TVLE) 的传统方法在计算精度和趋同率之间面临着权衡.
- 现有的归零神经动力学 (ZND) 方法往往难以平衡这些竞争因素.
研究的目的:
- 提出新的自适应式归零神经动力学 (ZND) 方案,消除TVLE计算精度和融合率之间的冲突.
- 开发适合数字硬件实现的离散算法.
主要方法:
- 设计了一个新的自适应连续ZND (ACZND) 模型,具有全球和指数趋同属性.
- 开发了两种通用可变时间离散技术,以创建自适应离散ZND (ADZND) 算法.
- 进行严格的数学分析来证明ADZND算法的收性质.
主要成果:
- 与传统的离散ZND (TDZND) 算法相比,提出的ADZND算法显示出更高的融合率和计算精度.
- 理论和实验比较验证了ADZND的增强性能.
- 在TVLE解决,手臂路径跟踪和目标运动定位方面成功进行模拟实验.
结论:
- 开发的ADZND算法有效地解决了TVLE.的精度-融合率冲突.
- 这些算法为现实应用提供了更高的效率,优越性和实用性,特别是在机器人领域.
- 这项研究为解决动态系统中的自适应神经动态提供了一个强大的框架.

相关概念视频
 01:21
Linear Approximation in Time Domain
108
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
108
 01:15
Kinematic Equations: Problem Solving
12.5K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
12.5K
 01:13
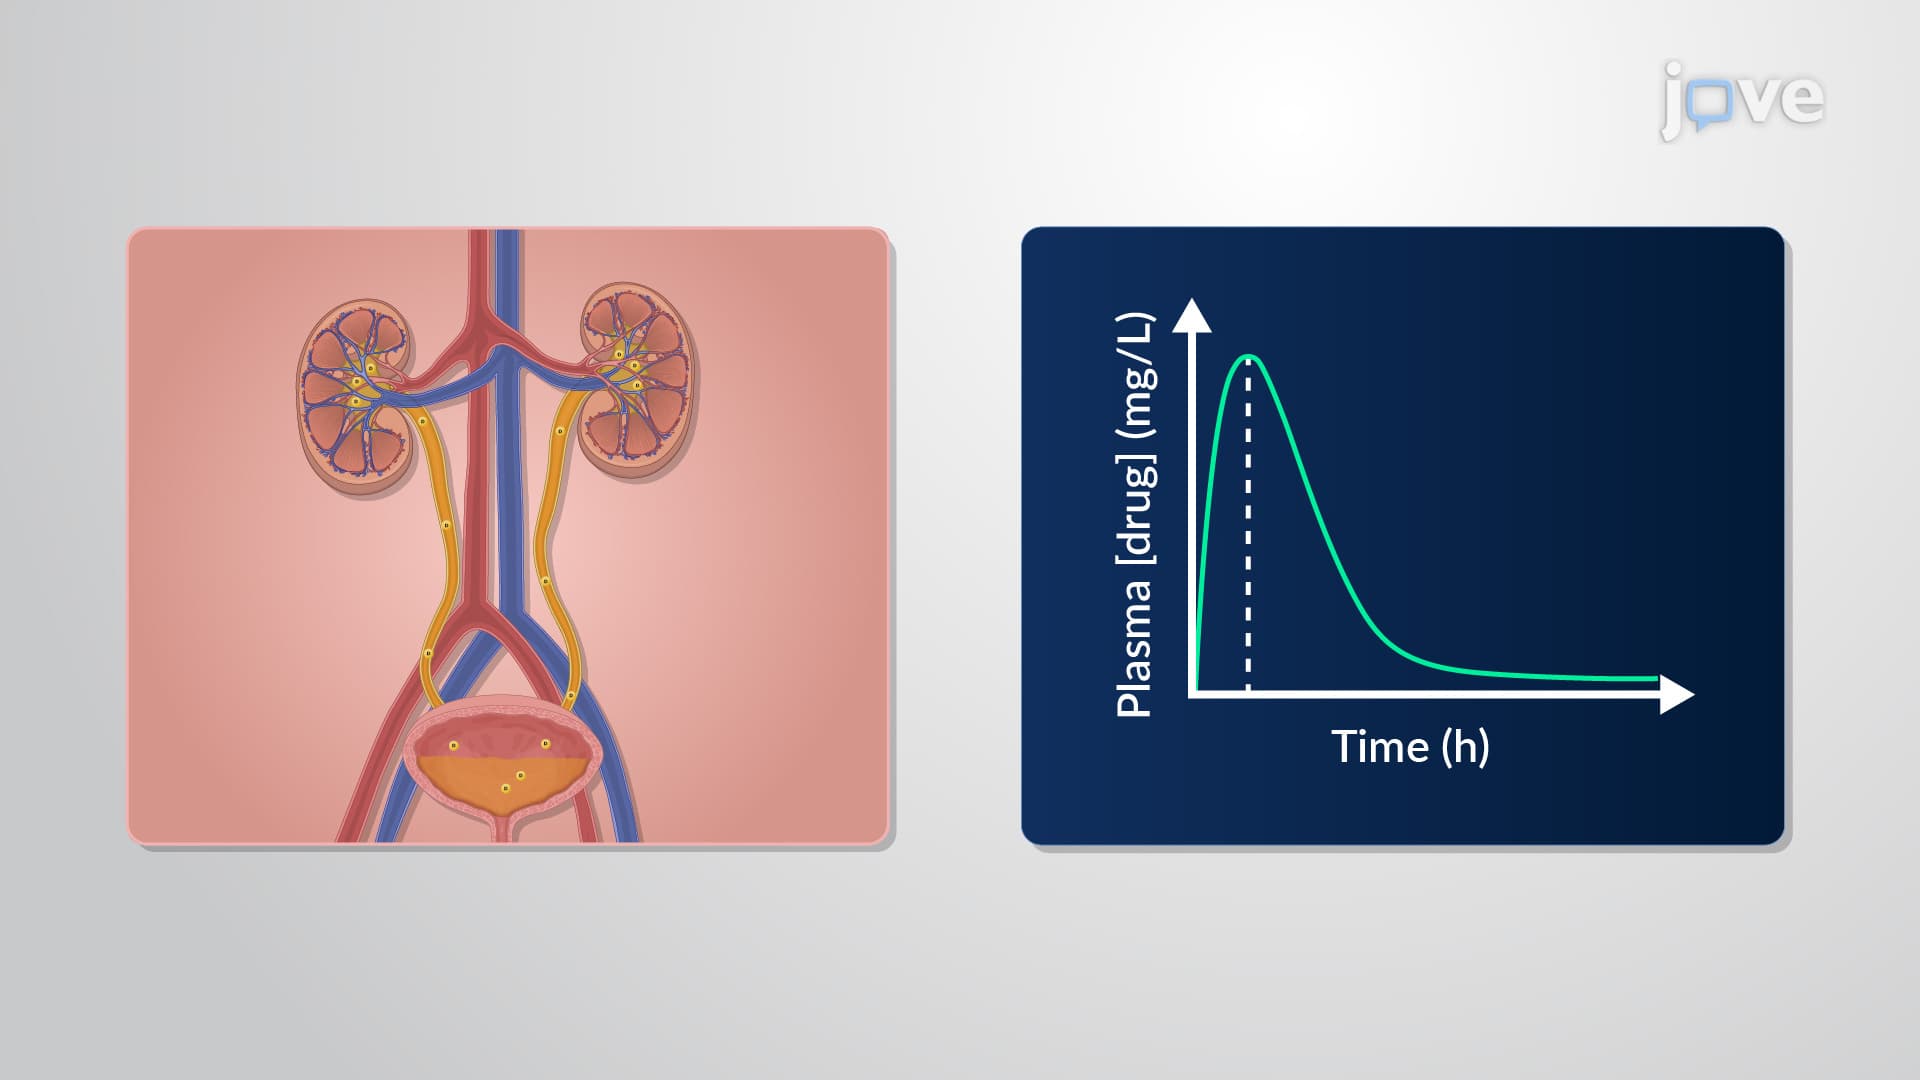
Parameters Affecting Nonlinear Elimination: Zero-Order Input, First-Order Absorption and Two-Compartment Model
98
Drugs administered through various routes can lead to nonlinear elimination, resulting in complex pharmacokinetic behaviors crucial to understanding efficacious drug dosing.
When a drug is administered through a constant intravenous infusion and eliminated via nonlinear pharmacokinetics, it follows zero-order input. For example, oral drugs undergo first-order absorption upon administration and are eliminated through nonlinear pharmacokinetics.
In the case of subcutaneously administered drugs,...
98
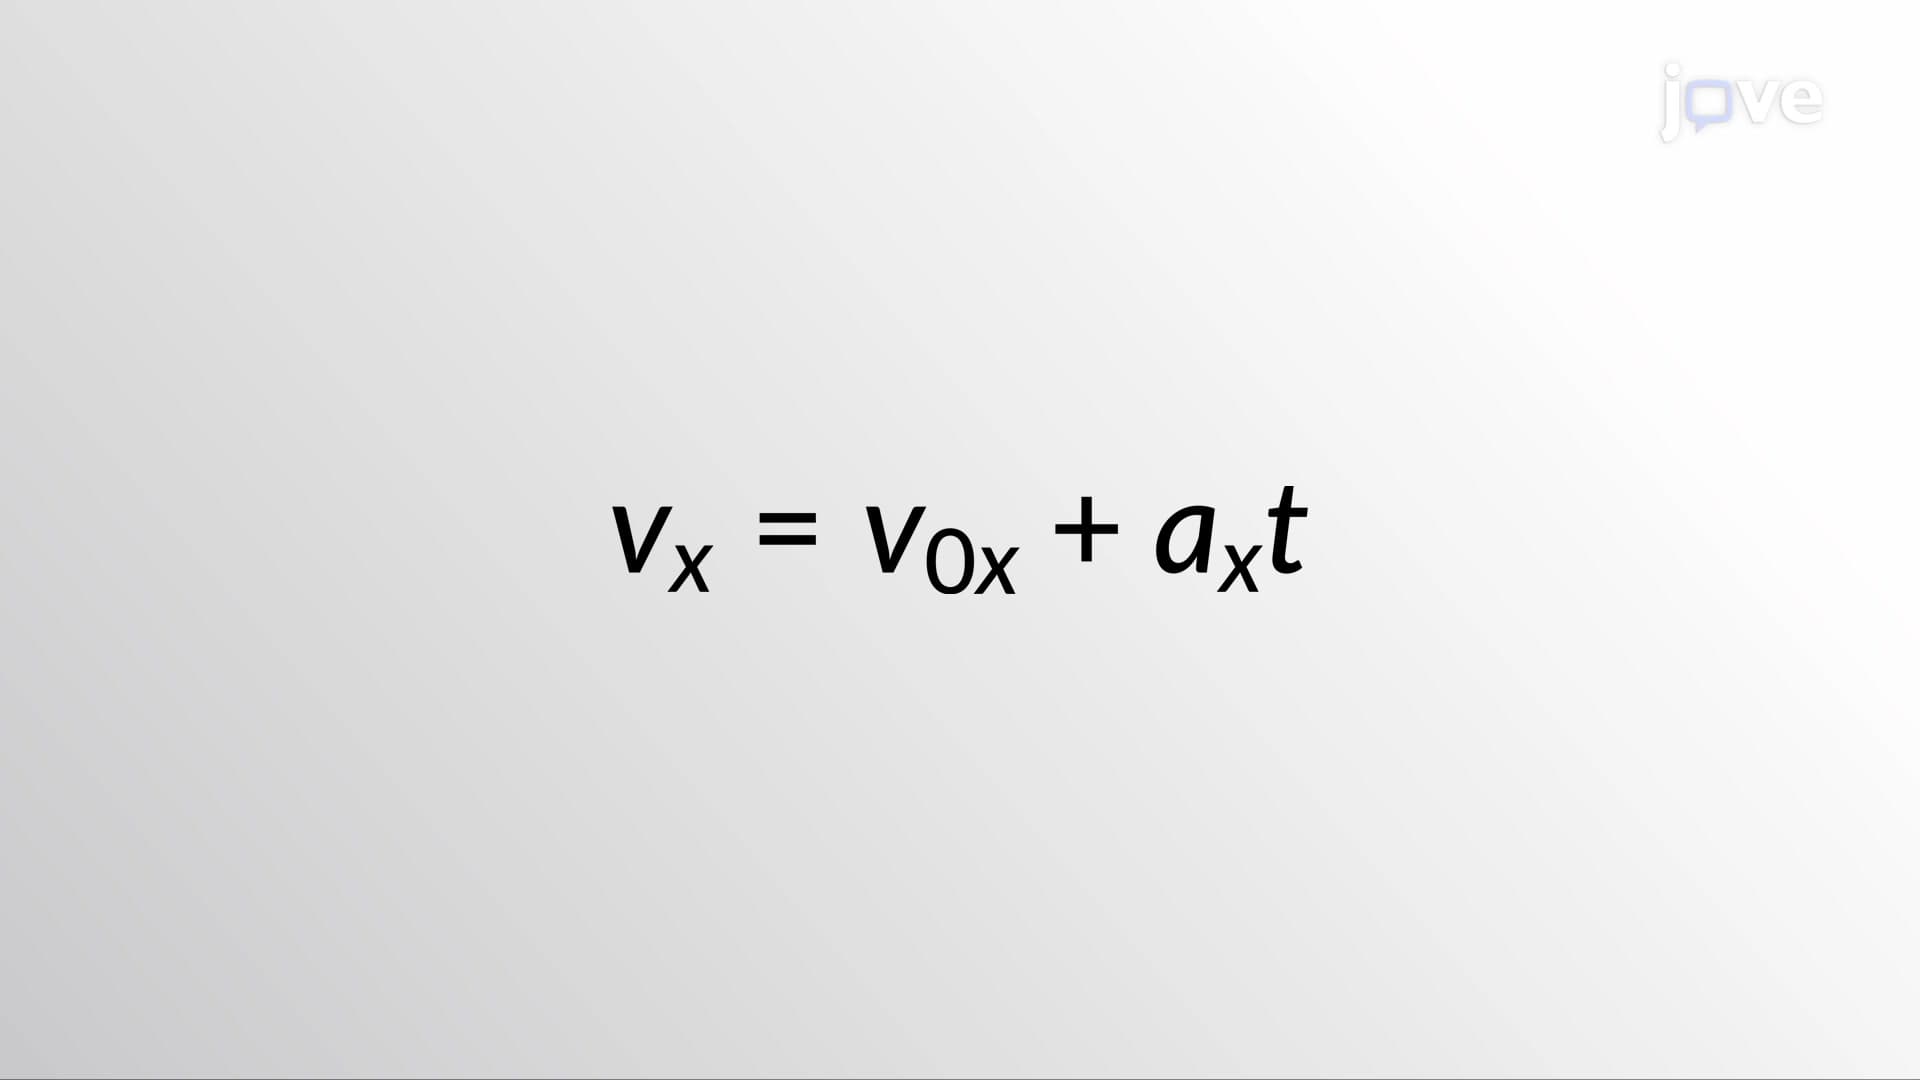 01:26
Kinematic Equations - I
10.7K
When an object moves with constant acceleration, the velocity of the object changes at a constant rate throughout the motion. The kinematic equations of motions are derived for such cases where the acceleration of the object is constant. The first kinematic equation gives an insight into the relationship between velocity, acceleration, and time. We can see, for example:
10.7K
 01:24
One-Degree-of-Freedom System
519
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
519
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
425
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
425