
识别与控制相关的信号路径,以半活跃的车辆悬架与磁铁修复学阻尼器的信号路径
1Department of Measurements and Control Systems, Silesian University of Technology, Akademicka 16, 44-100 Gliwice, Poland.
Sensors (Basel, Switzerland)
|July 8, 2023

概括
本研究确定了使用磁修学 (MR) 阻尼器在半活性悬浮中的控制信号路径. 该方法分解振动信号,以了解MR阻尼器对车辆动态的影响,用于自适应式悬挂控制.
科学领域:
- 汽车工程 汽车工程
- 控制系统工程 控制系统工程
- 振动分析 振动分析
背景情况:
- 带有磁修学 (MR) 阻尼器的半活性悬浮提供适应性阻尼.
- 识别控制信号路径对于优化MR阻尼器性能至关重要.
- 同时的道路激发和MR阻尼器控制构成了复杂的识别挑战.
研究的目的:
- 开发和验证一种用于识别MR阻尼器配备的半活性悬浮中与控制相关的信号路径的方法.
- 分析控制电流配置对车辆响应的影响.
- 为了使先进的自适应式悬挂控制算法的合成.
主要方法:
- 使用全地形车辆,专用激发器和MR阻尼器的实验设置.
- 应用状路刺激 (12 Hz) 和宽带随机控制信号 (25 Hz带宽).
- 车身加速信号的分解成与道路和控制相关的组件.
- 使用传感器数据识别与控制相关的模型的频域识别.
主要成果:
- 成功识别了与控制相关的信号路径及其依赖频率的共振.
- 证明了车辆响应对MR阻尼器控制电流配置的依赖.
- 估计的车辆模型参数和诊断站特征.
- 揭示了车辆负载对控制相关信号路径特征的影响.
结论:
- 开发的识别方法对MR半活性悬浮剂有效.
- 已识别的模型可用于自适应式悬挂控制算法开发 (例如,FxLMS).
- 适应式悬架提高了适应不断变化的道路和车辆条件的适应性.
相关概念视频
 01:26
PD Controller: Design
291
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
291
 01:17
Magnetic Damping
502
Eddy currents can produce significant drag on motion, called magnetic damping. For instance, when a metallic pendulum bob swings between the poles of a strong magnet, significant drag acts on the bob as it enters and leaves the field, quickly damping the motion.
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
502
 01:19
Root-Locus Method
181
A cruise control system in a car is designed to maintain a specified speed automatically by adjusting the gas pedal. The system continuously measures the vehicle's speed and makes fine adjustments to the pedal to achieve this goal. The root locus method is particularly useful for understanding how the cruise control system's behavior changes under varying conditions, such as when the car goes uphill, downhill, or faces strong wind resistance.
This system can be represented by a block...
This system can be represented by a block...
181
 01:20
Relation between Mathematical Equations and Block Diagrams
443
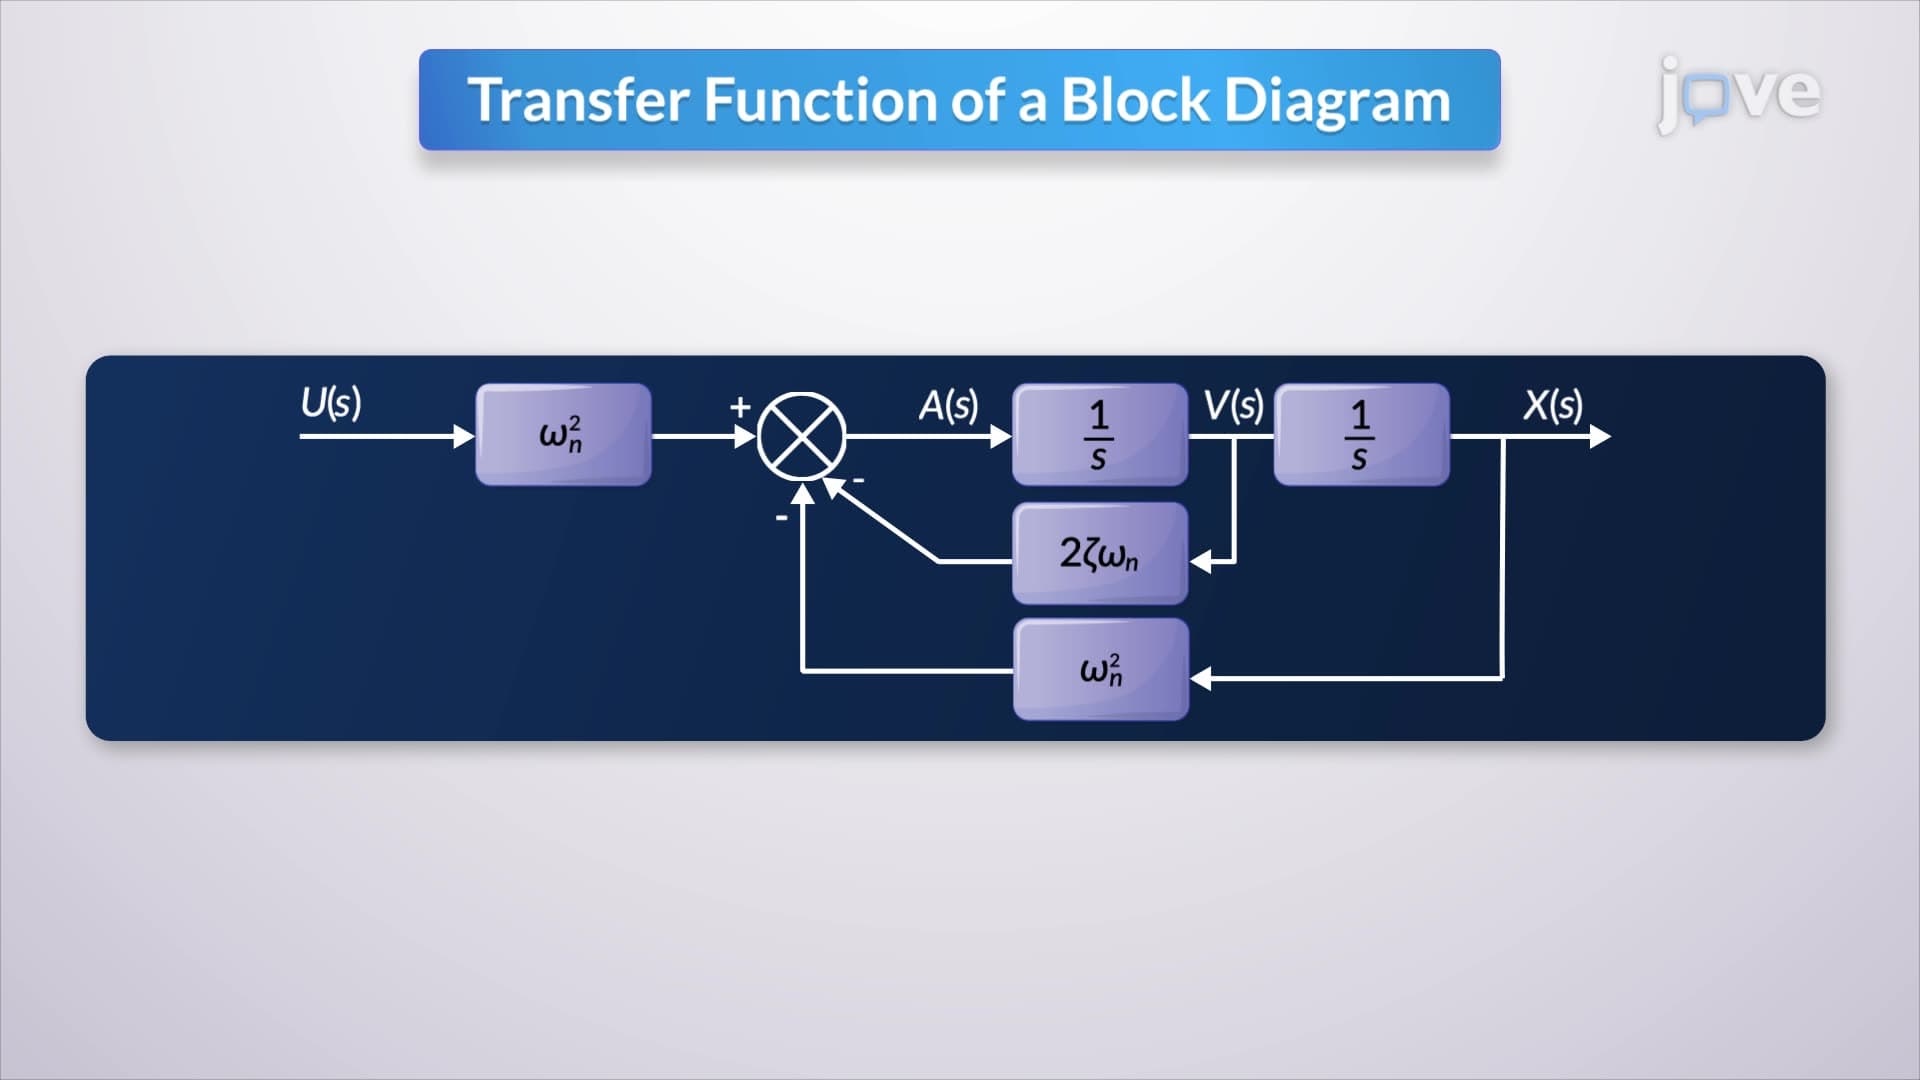
In a spring-mass-damper system, the second-order differential equation describes the dynamic behavior of the system. When transformed into the Laplace domain under zero initial conditions, this equation can be effectively analyzed and manipulated. The transformation into the Laplace domain converts differential equations into algebraic equations, simplifying the process of isolating the output.
443
 01:22
Mechanical Systems
243
Mechanical systems are analogous to to electrical networks where springs and masses play similar roles to inductors and capacitors, respectively. A viscous damper in mechanical systems functions similarly to a resistor in electrical networks, dissipating energy. The forces acting on a mass in such systems include an applied force in the direction of motion, counteracted by forces from the spring, a viscous damper, and the mass's acceleration. This interplay of forces is mathematically...
243
 01:22
Multi-input and Multi-variable systems
132
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence...
In the absence...
132