物理驱动的正确直角分解:部分微分方程的模拟方法
Alessandro Pulimeno1,2, Graham Coates-Farley3, Martin Veresko3
1Department of Mechanical and Aerospace Engineering, Clarkson University, Potsdam, NY 13699, USA.
MethodsX
|July 10, 2023

概括
一种新的物理驱动的正确直角分解 (POD) 模拟方法使用学习算法来解决部分微分方程 (PDEs). 这种方法显著减少了复杂物理问题的计算力度,同时保持了高精度.
科学领域:
- 计算物理学的计算物理.
- 科学计算是科学计算.
- 数字分析 数字分析
背景情况:
- 解决部分微分方程 (PDEs) 通常需要大量的计算资源.
- 直接数值模拟 (DNS) 提供了准确的解决方案,但在计算上很昂贵.
- 寻求模型缩小技术来加速模拟.
研究的目的:
- 介绍一种基于正确直角分解 (POD) 和加勒金投影的新型模拟方法.
- 开发一种以物理为导向的方法,以有效地解决PDE.
- 在复杂的物理问题上证明方法的有效性.
主要方法:
- 使用基于正确直角分解 (POD) 的学习算法.
- 来自DNS的解决方案数据用于训练POD模式.
- 盖勒金投影应用于POD空间内的PDE.
- 该方法包括数据收集,POD模式计算和模型推导.
主要成果:
- 根据POD-Galerkin的方法,可以显著降低自由度 (DoF).
- 尽管降低了DoF,但仍然保持了高精度.
- 与DNS相比,计算工作量大大减少.
- 对微处理器的动态热分析和施罗丁格方程进行了成功的模拟.
结论:
- 物理驱动的POD-Galerkin方法提供了一个计算效率高的替代DNS.
- 这种方法有效地通过减少模型复杂性来解决复杂的PDEs.
- 该方法在加速各种物理领域的模拟方面具有前景.
相关概念视频
 01:21
Linear Approximation in Time Domain
106
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
106
 01:23
Dimensional Analysis
919
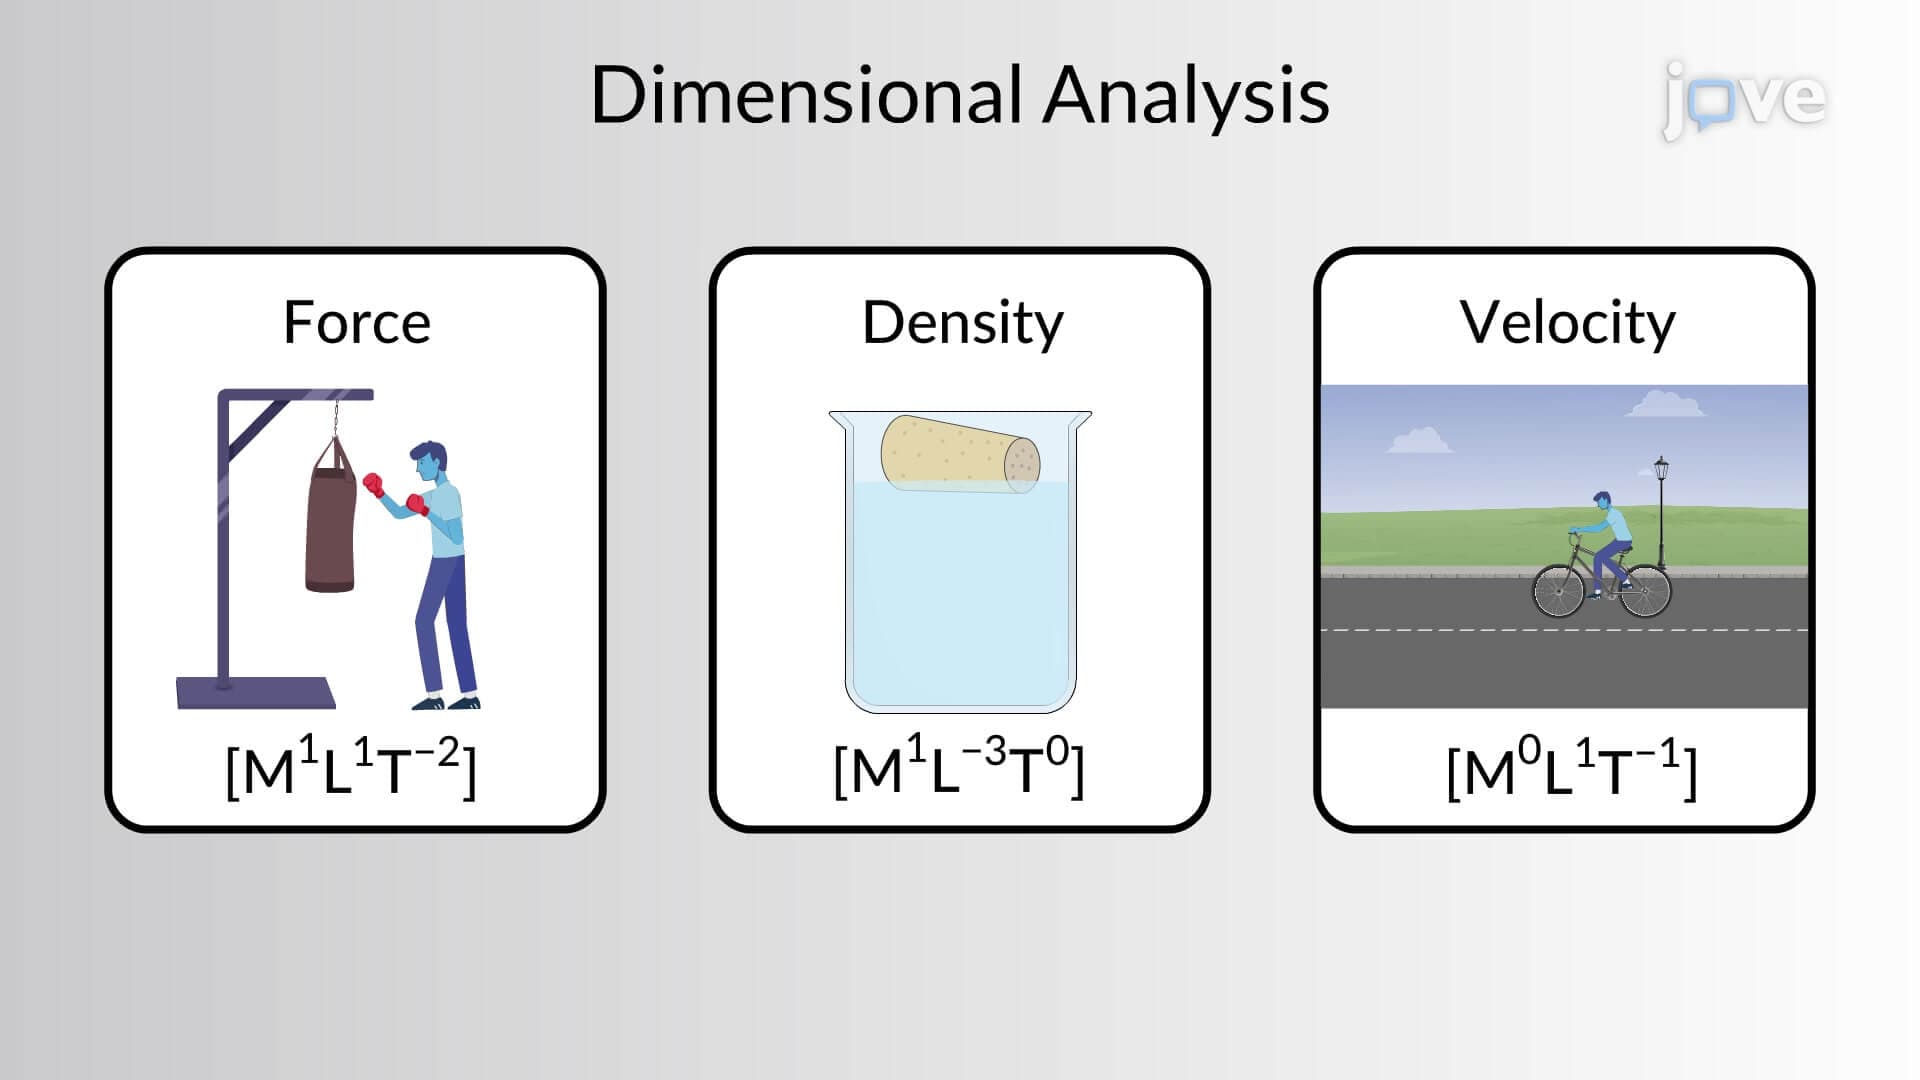
Dimensional analysis is a powerful tool that is used in physics and engineering to understand and predict the behavior of physical systems. The basic idea behind dimensional analysis is to express physical quantities in terms of fundamental dimensions such as the mass, length, and time. Derived dimensions like the velocity, acceleration, and force are derived from the combinations of these fundamental dimensions.
Dimensional analysis allows us to analyze and compare physical quantities on a...
Dimensional analysis allows us to analyze and compare physical quantities on a...
919
 01:15
Kinematic Equations: Problem Solving
12.5K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
12.5K
 01:07
Time-Domain Interpretation of PD Control
143
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
143
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
81
Mechanistic models play a crucial role in algorithms for numerical problem-solving, particularly in nonlinear mixed effects modeling (NMEM). These models aim to minimize specific objective functions by evaluating various parameter estimates, leading to the development of systematic algorithms. In some cases, linearization techniques approximate the model using linear equations.
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
81
 01:18
Second Order systems II
133
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
133