基于曲率优化的智能车辆路径跟踪控制方法
Qing Ye1, Chaojun Gao1, Yao Zhang1
1Automotive Engineering Research Institute, Jiangsu University, Zhenjiang 212013, China.
Sensors (Basel, Switzerland)
|July 11, 2023

概括
本研究介绍了智能汽车 (IV) 的曲率优化方法,以平衡路径跟踪精度和稳定性. 新的控制策略显著减少横向偏差,并在复杂的机动中提高车辆的稳定性.
科学领域:
- 汽车工程 汽车工程
- 控制系统 控制系统
- 机器人技术 机器人技术 机器人技术
背景情况:
- 智能汽车 (IV) 面临着路径跟踪精度和车身稳定性之间的冲突.
- 这种冲突是由于这两个性能指标在车辆移动过程中相互限制而产生的.
研究的目的:
- 提出基于曲率优化的智能车辆路径跟踪控制方法.
- 为了减少在IV中路径跟踪精度和机身稳定性之间的全面性能冲突.
主要方法:
- 开发了一个三度自由度的车辆动态模型.
- 包含了考虑车辆滚动的预览错误模型.
- 设计了一种利用曲率优化的路径跟踪控制方法.
主要成果:
- 在横向偏差中实现了高达84.10%的优化,在10 m/s和0.15 m-1曲率下稳定性得到了2%的改进.
- 证明了高达66.80%的横向偏差优化,在10 m/s和0.2 m-1曲率下稳定性得到了4%的改进.
- 在15 m/s和0.15 m-1曲率下,表现出20-30%的身体稳定性改善,甚至触发了边界条件.
结论:
- 曲率优化控制器有效地提高了模糊滑动模式控制器的跟踪精度.
- 拟议的方法通过在优化过程中结合车身稳定性约束来确保车辆顺运行.


相关概念视频
 01:27
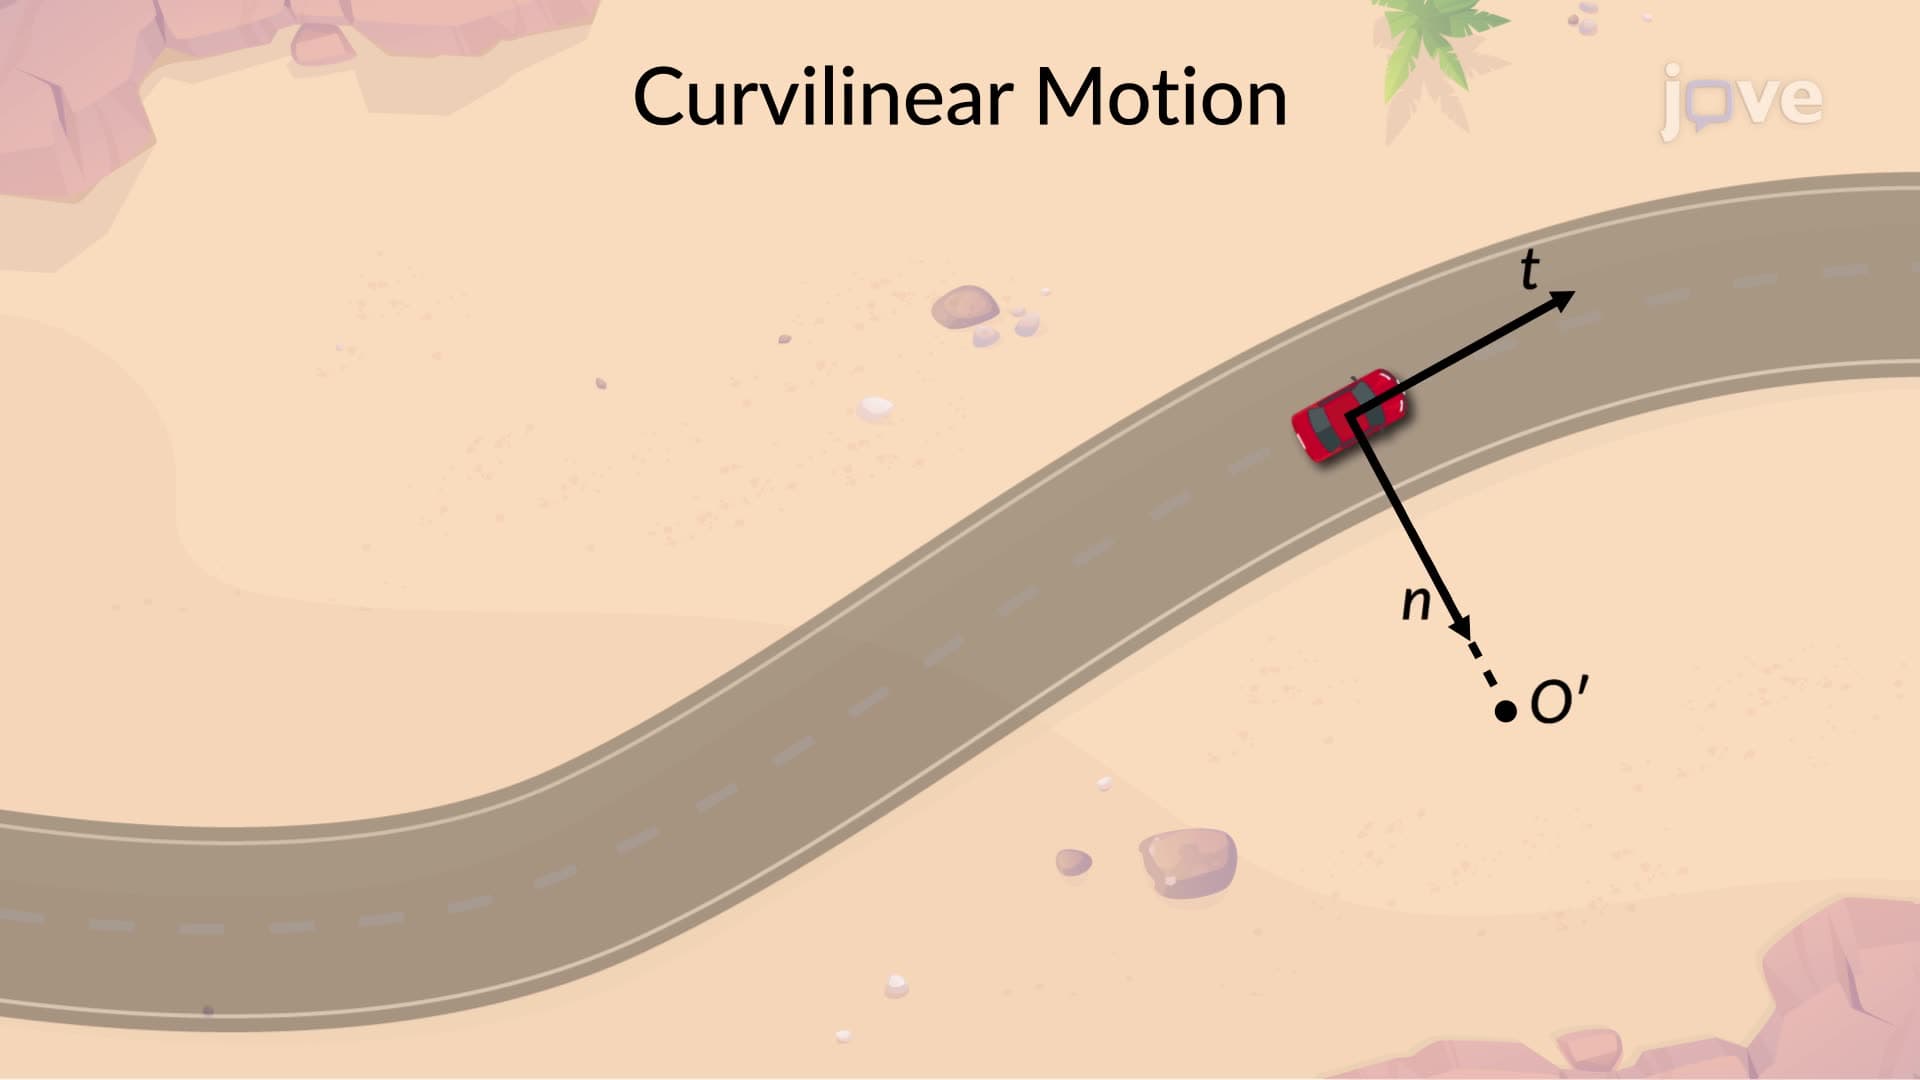
Curvilinear Motion: Normal and Tangential Components
427
When a car traverses a curved road, its motion can be elucidated by breaking it down into tangential and normal components. The car-centric coordinates attached to the vehicle move with it.
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
427
 01:23
Curvilinear Motion: Rectangular Components
501
Curvilinear motion characterizes the movement of a particle or object along a curved path, notably evident when envisioning a car navigating a winding road. If the car starts at point A, its position vector is established within a fixed frame of reference, where the ratio of the position vector to its magnitude signifies the unit vector pointing in the position vector's direction.
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
501
 01:19
Root-Locus Method
181
A cruise control system in a car is designed to maintain a specified speed automatically by adjusting the gas pedal. The system continuously measures the vehicle's speed and makes fine adjustments to the pedal to achieve this goal. The root locus method is particularly useful for understanding how the cruise control system's behavior changes under varying conditions, such as when the car goes uphill, downhill, or faces strong wind resistance.
This system can be represented by a block...
This system can be represented by a block...
181
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
424
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
424
 01:24
Introduction to Vertical Curves
68
Vertical curves are parabolic transitions that connect different grades on highways and railroads, ensuring a smooth alignment between back and forward tangents. The back tangent represents the initial grade, while the forward tangent defines the subsequent grade. These curves can be symmetrical, with equal tangent lengths, or nonsymmetrical, with varying lengths. The key points defining a vertical curve include the Point of Vertical Intersection (P.V.I.), where the tangents meet; the Point of...
68
 01:27
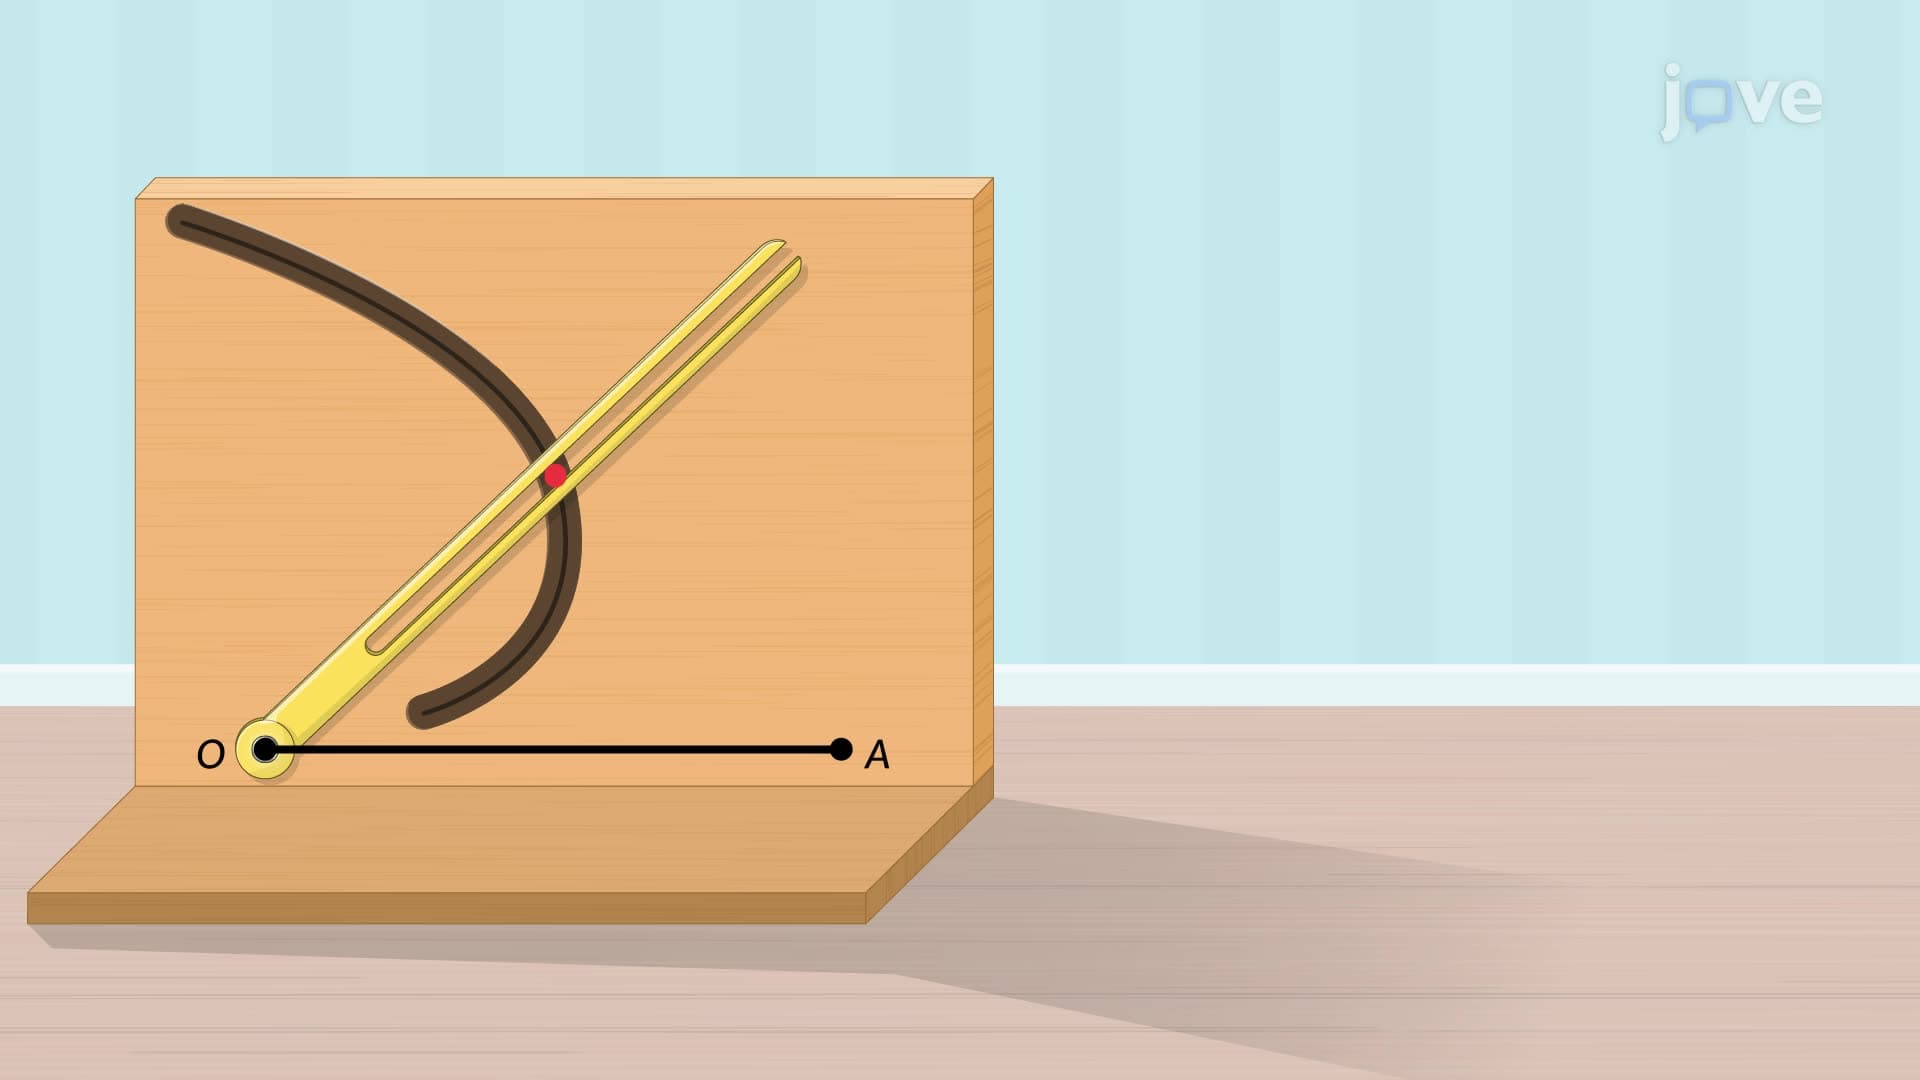
Curvilinear Motion: Polar Coordinates
393
In polar coordinates, the motion of a particle follows a curvilinear path. The radial coordinate symbolized as 'r,' extends outward from a fixed origin to the particle, while the angular coordinate, 'θ,' measured in radians, represents the counterclockwise angle between a fixed reference line and the radial line connecting the origin to the particle.
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...
393