
基于INS/GNSS/UWB的ESKF动态和静态过的研究
Zongbin Ren1, Songlin Liu1, Jun Dai1,2
1Institute of Geospatial Information, Information Engineering University, Zhengzhou 450001, China.
Sensors (Basel, Switzerland)
|July 11, 2023

概括
本研究引入了一种新的多源融合选算法,用于无人地面车辆 (UGV) 导航,使用多个传感器的错误状态卡尔曼波器 (ESKF) 提高定位准确性.
科学领域:
- 机器人技术和自主系统
- 导航和定位系统 导航和定位系统
- 传感器融合和数据集成
背景情况:
- 无人地面车辆 (UGV) 越来越依赖于多传感器融合,以实现强大的自主导航.
- 传统的联合过方法由于过器输出量之间的相互依赖性而存在局限性.
- 单传感器系统不足以满足UGV导航的复杂需求.
研究的目的:
- 为UGV定位状态估计提出一种新的动态和静态多源融合过算法.
- 提高导航准确度,克服现有的核聚变方法的局限性.
- 为UGV应用开发一个强大的和可通用的算法.
主要方法:
- 开发了一种使用错误状态卡尔曼过器 (ESKF) 的多源融合过算法.
- 集成惯性导航系统 (INS),全球导航卫星系统 (GNSS) 和超宽带 (UWB) 传感器.
- 实施了一种连续过方法,将动态ESKF (GNSS/INS) 和静态ESKF (UWB/INS) 结合起来.
主要成果:
- 提出的基于ESKF的融合方法显示了快速的趋同.
- 在定位精度方面取得了显著的改进:比松散合的GNSS/INS提高21.98%,比松散合的UWB/INS提高13.03%.
- 性能被证明受到动力ESKF传感器的精度和稳定性的影响.
结论:
- 这种新的算法为UGV导航提供了卓越的定位准确性和稳定性.
- 该方法表现出良好的通用性,插件功能和稳定性.
- 基于ESKF的融合是先进的UGV自主导航系统的一个有前途的方法.
相关概念视频
 01:30
Types of Global Positioning System Surveys
81
GPS surveying methods vary in application, accuracy, and data collection techniques, catering to diverse surveying and mapping needs. Static GPS, kinematic GPS, and real-time kinematic (RTK) surveying are widely used. Each technique offers distinct advantages.Static GPS involves placing one receiver at a known reference point and another at the target point. It collects exact positional data by observing multiple satellite ranges over an extended period, achieving centimeter-level accuracy for...
81
 01:26
Errors in Global Positioning System
71
Global Positioning System (GPS) technology has revolutionized navigation and positioning, but its accuracy is often compromised by various errors. These errors, stemming from environmental, satellite, and receiver-related factors, require careful mitigation to ensure reliable performance across applications.Atmospheric ErrorsGPS signals travel through the Earth’s ionosphere and troposphere, introducing delays which affect accuracy. The ionosphere is strongly influenced by charged particles,...
71
 01:28
Field Application of Global Positioning System
69
The Global Positioning System (GPS) has become an indispensable tool in fieldwork, offering unparalleled precision and efficiency for surveying, navigation, and infrastructure development. By harnessing signals from a constellation of satellites, GPS receivers determine the location of objects with remarkable speed and accuracy, often completing calculations within a second.Advantages of Modern GPS TechnologyContemporary GPS receivers are designed to meet the practical demands of field...
69
 01:27
Passive Filters
562
Passive filters are utilized to shape the frequency spectrum of signals across a diverse array of applications. These filters, using only passive elements like resistors (R), inductors (L), and capacitors (C), are capable of selectively allowing or blocking certain frequency ranges without the need for external power sources.
Low-Pass Filters
Low-pass filters are designed to transmit signals with frequencies lower than the cutoff frequency, ωc, and attenuate those above it. The cutoff...
Low-Pass Filters
Low-pass filters are designed to transmit signals with frequencies lower than the cutoff frequency, ωc, and attenuate those above it. The cutoff...
562
 01:25
Ultrasound II: Endoscopic Ultrasound and FibroScan
143
Endoscopic Ultrasound (EUS) and FibroScan are valuable diagnostic tools in gastroenterology and hepatology, each with specific applications and techniques.
Endoscopic Ultrasound (EUS):
Endoscopic Ultrasound (EUS):
143
 01:25
Active Filters
862
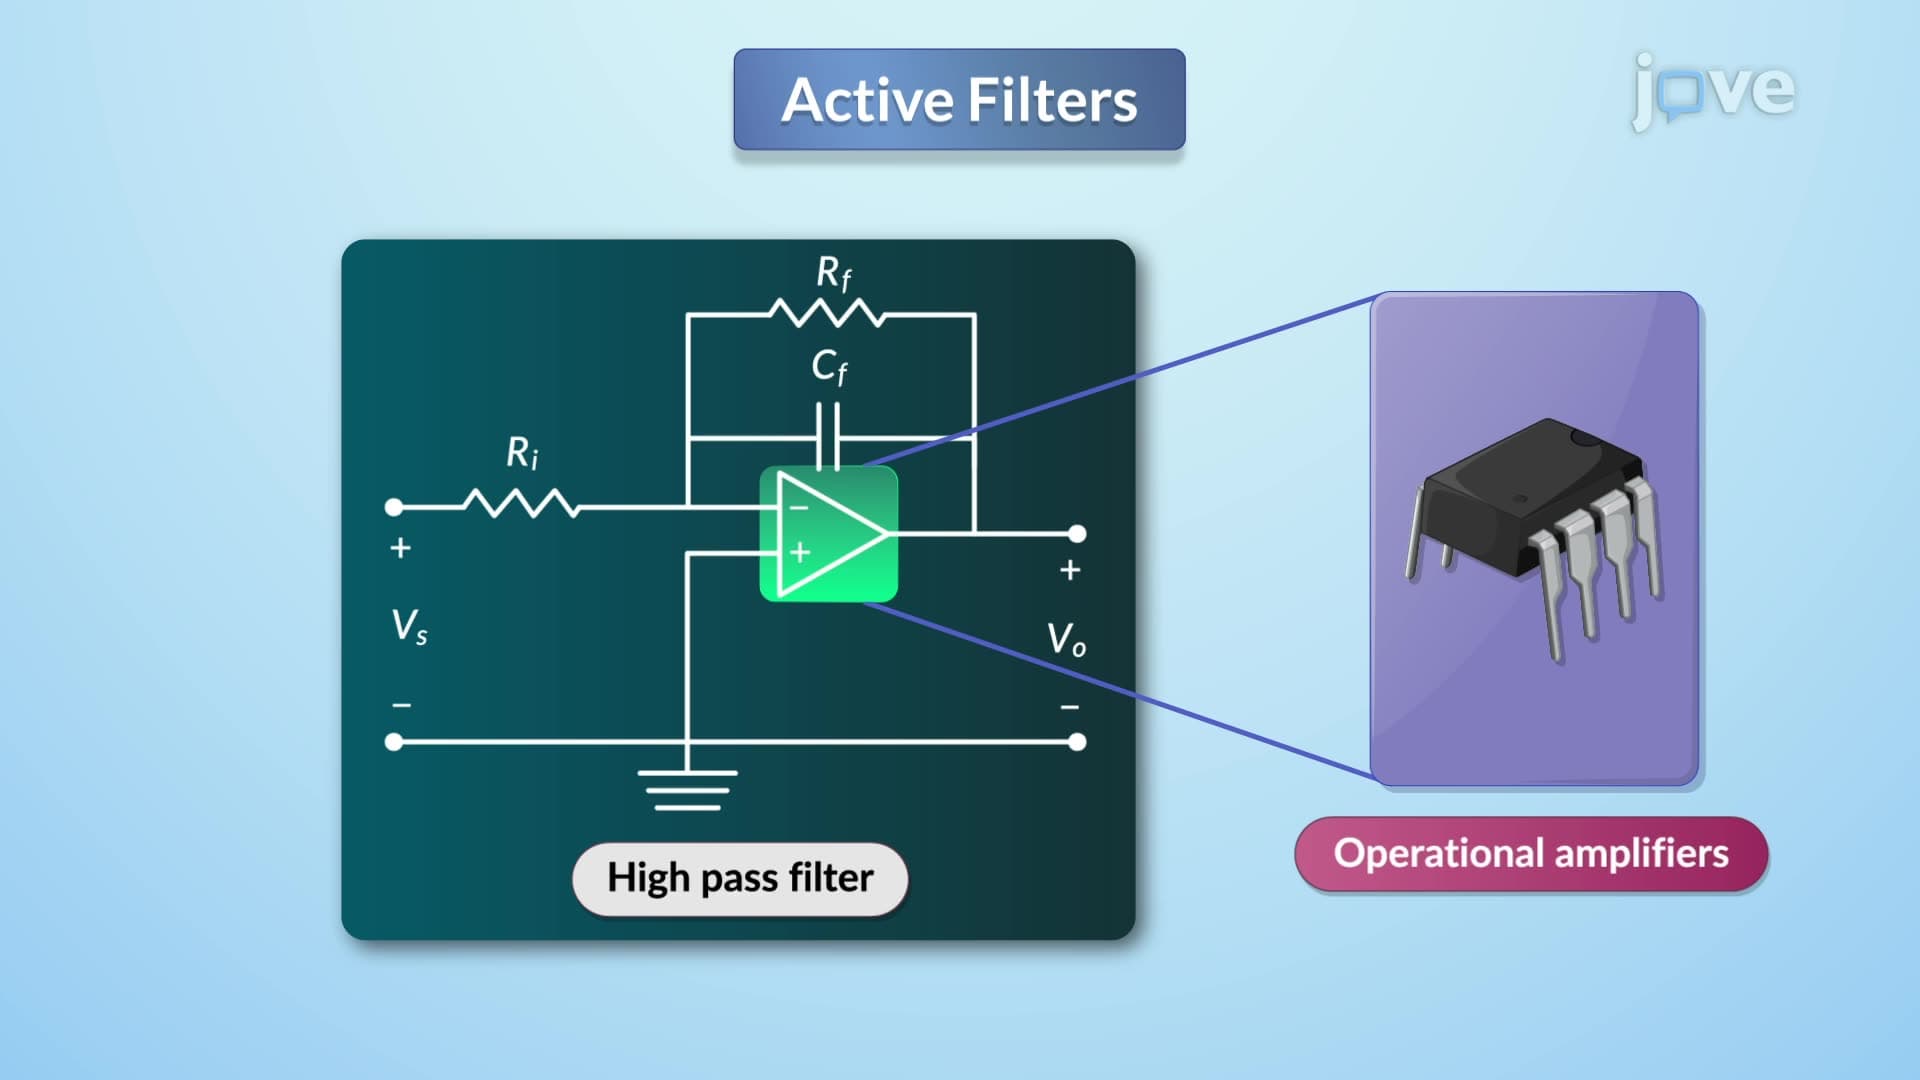
Active filters are electronic circuits that use operational amplifiers (op-amps), resistors, and capacitors to filter out unwanted frequency components from a signal. A first-order low-pass active filter is designed to pass signals with a frequency lower than a certain cutoff frequency and attenuate frequencies higher than that cutoff frequency. The transfer function for a first-order low-pass active filter is:
862