

基于单眼视觉和扭矩摆形原理的刚体旋转惯性测量技术的研究
Yeqing Chen1, Yi Zeng1, Haoran Li1
1School of Information Science and Engineering, Zhejiang Sci-Tech University, Hangzhou 310018, China.
Sensors (Basel, Switzerland)
|July 11, 2023

概括
这项研究引入了一种新的方法,使用单眼视觉和扭矩来通过识别系统阻尼来准确测量旋转惯性. 这种方法可以最大限度地减少错误,为精确的测量提供一种简单,具有成本效益的解决方案.
科学领域:
- 机械工程 机械工程
- 光学测量 测量 光学测量
- 物理 物理学 物理
背景情况:
- 缓冲显著影响使用扭矩的旋转惯性测量.
- 准确识别系统减压对于最小化测量误差至关重要.
- 现有的方法往往在精确的减压特征方面扎.
研究的目的:
- 提出一种用于测量刚体旋转惯性的新方法.
- 为了提高准确性,将单眼视觉与扭矩子方法集成在一起.
- 为了解决和最大限度地减少因系统阻尼引起的测量错误.
主要方法:
- 建立了扭转振荡与线性阻尼的数学模型.
- 使用高速工业摄像头进行连续角位移采样.
- 应用图像处理技术 (预处理,边缘检测,特征提取) 和几何建模来计算角位移.
- 从角位移曲线上的特点点得出的旋转惯性.
主要成果:
- 在0-100 × 10-3kg·m2范围内实现了精确的旋转惯性测量.
- 证明了比0.90 × 10⁻⁴ kg·m2更好的标准偏差.
- 展示的绝对测量误差小于2.00 × 10⁻⁴ 公斤·米2.
- 通过机器视觉有效识别阻尼,与传统方法相比减少错误.
结论:
- 拟议的基于单眼视觉的扭矩子方法准确地测量了旋转惯性.
- 该系统有效地识别了阻尼,大大减少了测量误差.
- 该方法为旋转惯性测量提供了一个简单,低成本和实用的解决方案.
相关概念视频
 01:09
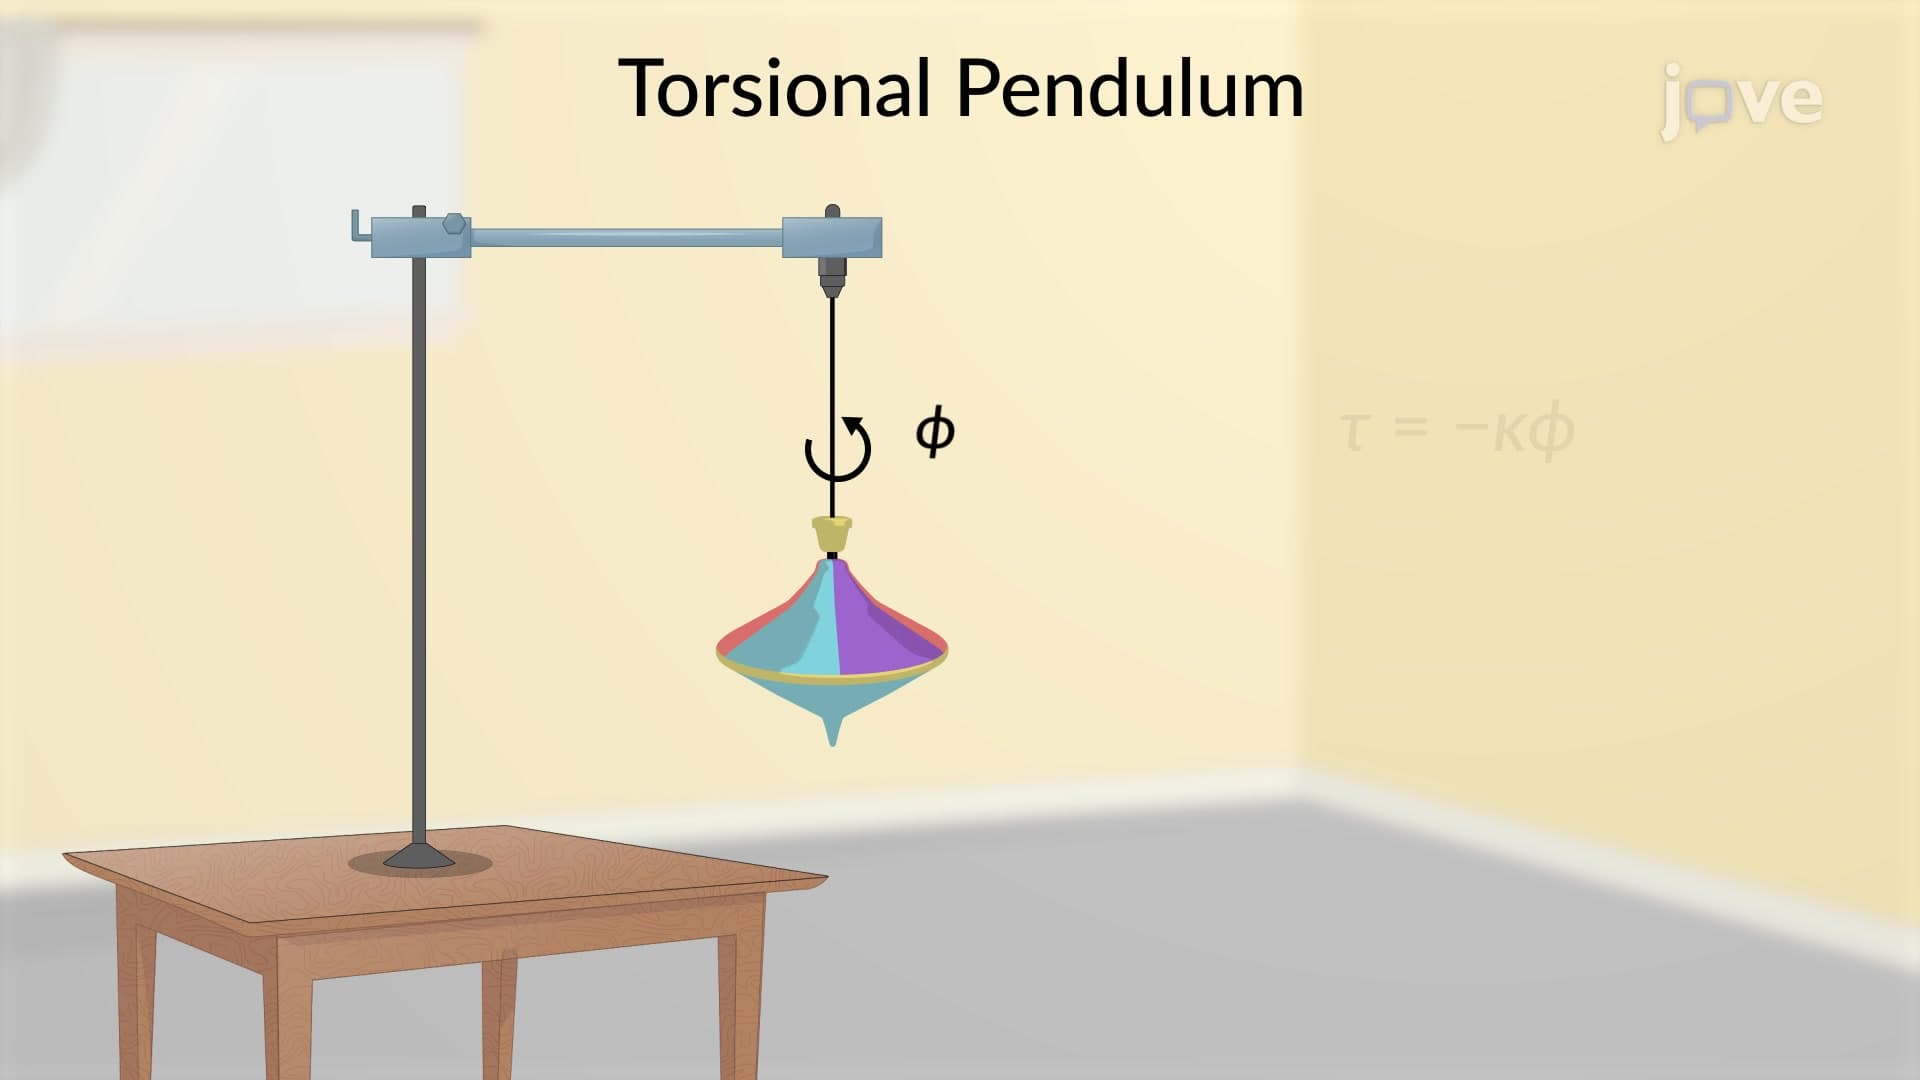
Torsional Pendulum
5.6K
A torsional pendulum involves the oscillation of a rigid body in which the restoring force is provided by the torsion in the string from which the rigid body is suspended. Ideally, the string should be massless; practically, its mass is much smaller than the rigid body's mass and is neglected.
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
5.6K
 01:06
Physical Pendulum
1.8K
When a rigid body is hanging freely from a fixed pivot point and is displaced, it oscillates similar to a simple pendulum and is known as a physical pendulum. The period and angular frequency of a physical pendulum are obtained by using the small-angle approximation and drawing parallels with a spring-mass system. The small-angle approximation (sinθ=θ) is valid up to about 14°.
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it...
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it...
1.8K
 01:12
Equation of Motion for a Rigid Body
328
The movement of a rigid object can be understood through the equations that explain both translational and rotational motion about the center of mass of the object, point G. This center of mass is the point where the equation of motion for translational motion comes into play, as per Newton's Second Law.
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different...
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different...
328
 00:49
Rigid Body Equilibrium Problems - I
4.5K
A rigid body is said to be in static equilibrium when the net force and the net torque acting on the system is equal to zero. To solve for rigid body equilibrium problems, do the following steps.
4.5K
 01:11
Angular Momentum: Rigid Body
9.1K
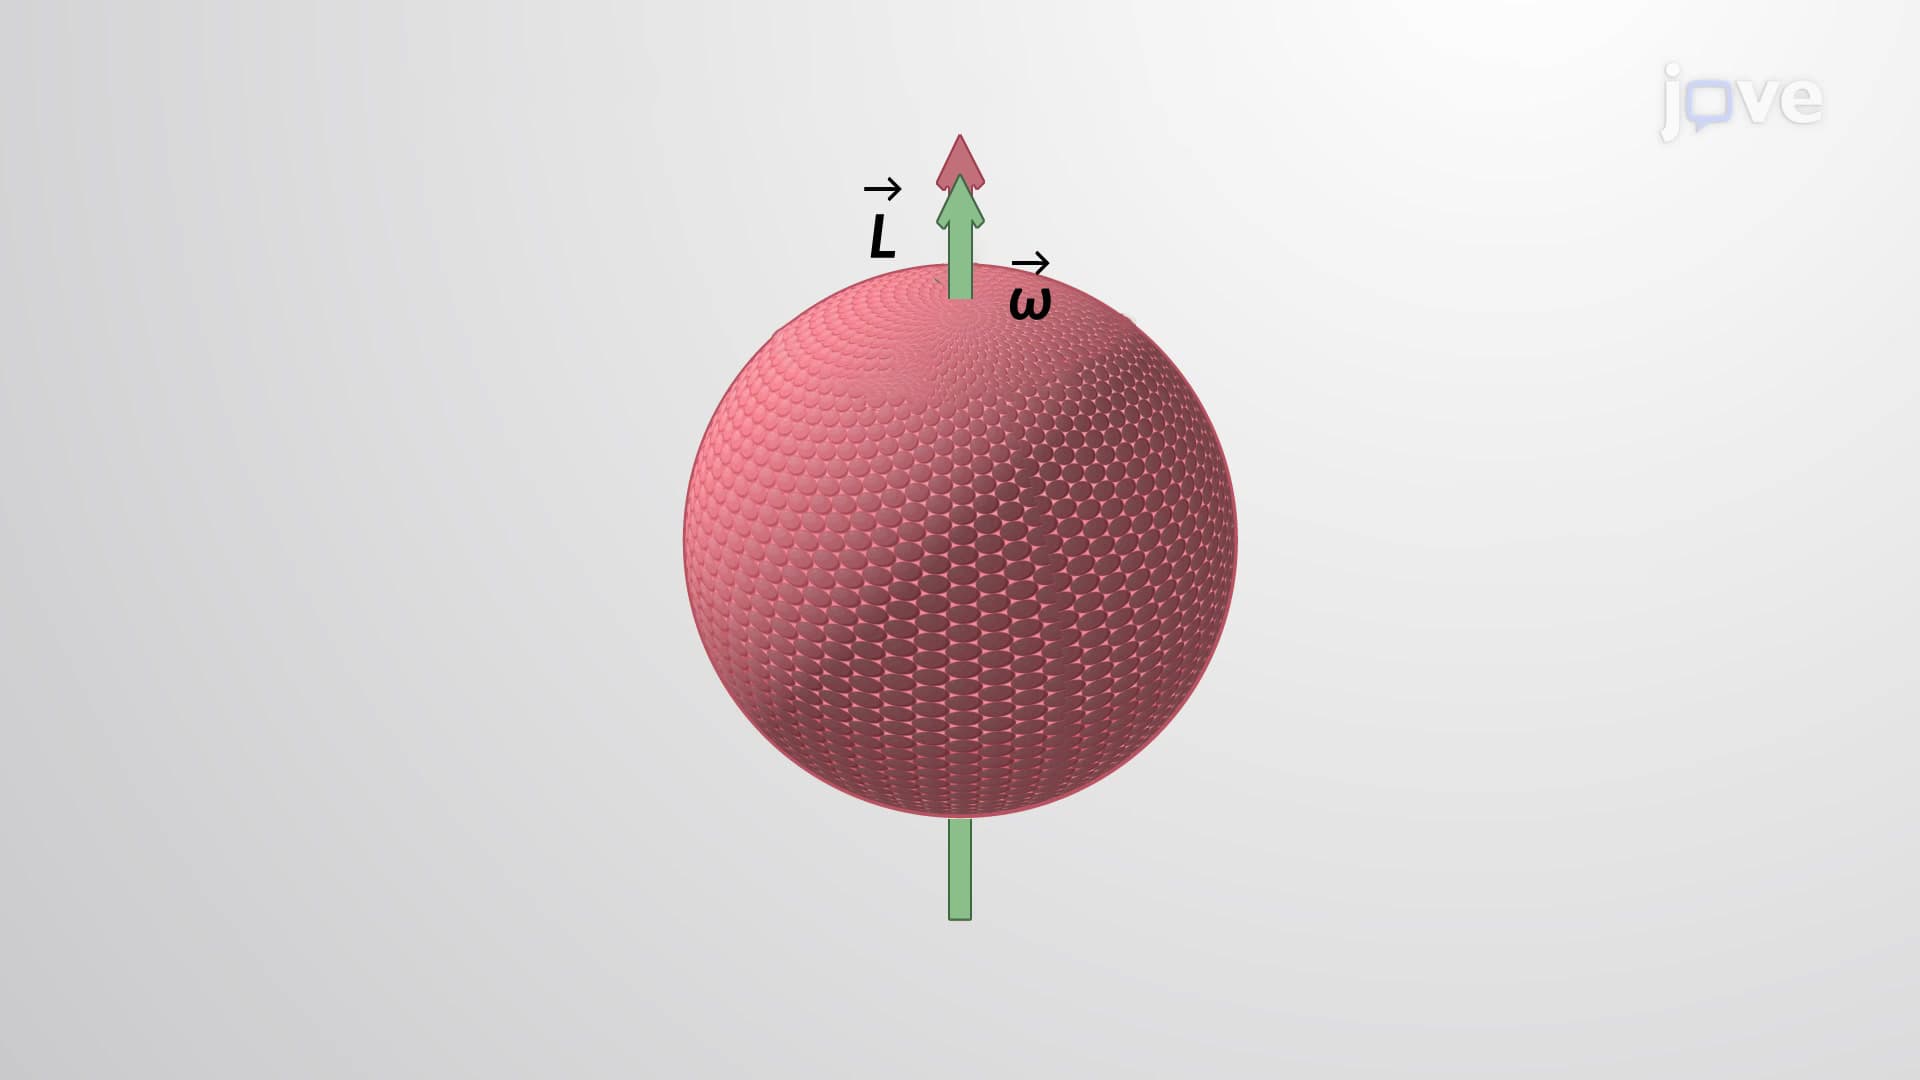
The total angular momentum of a rigid body can be calculated using the summation of the angular momentum of all the tiny particles rotating in the same plane. Considering all the tiny particles rotating in the x-y plane, the direction of angular momentum of all such particles and that of the rigid body would be perpendicular to the plane of the rotation along the z-axis.
This calculation can get complicated when tiny particles within the rigid body are not rotating in the same plane but have...
This calculation can get complicated when tiny particles within the rigid body are not rotating in the same plane but have...
9.1K
 01:14
Moment of Inertia
12.4K
The comparability between linear and angular velocities, linear and angular accelerations, and the kinematic equations of translational and rotational motion can be extended to the concept of inertia.
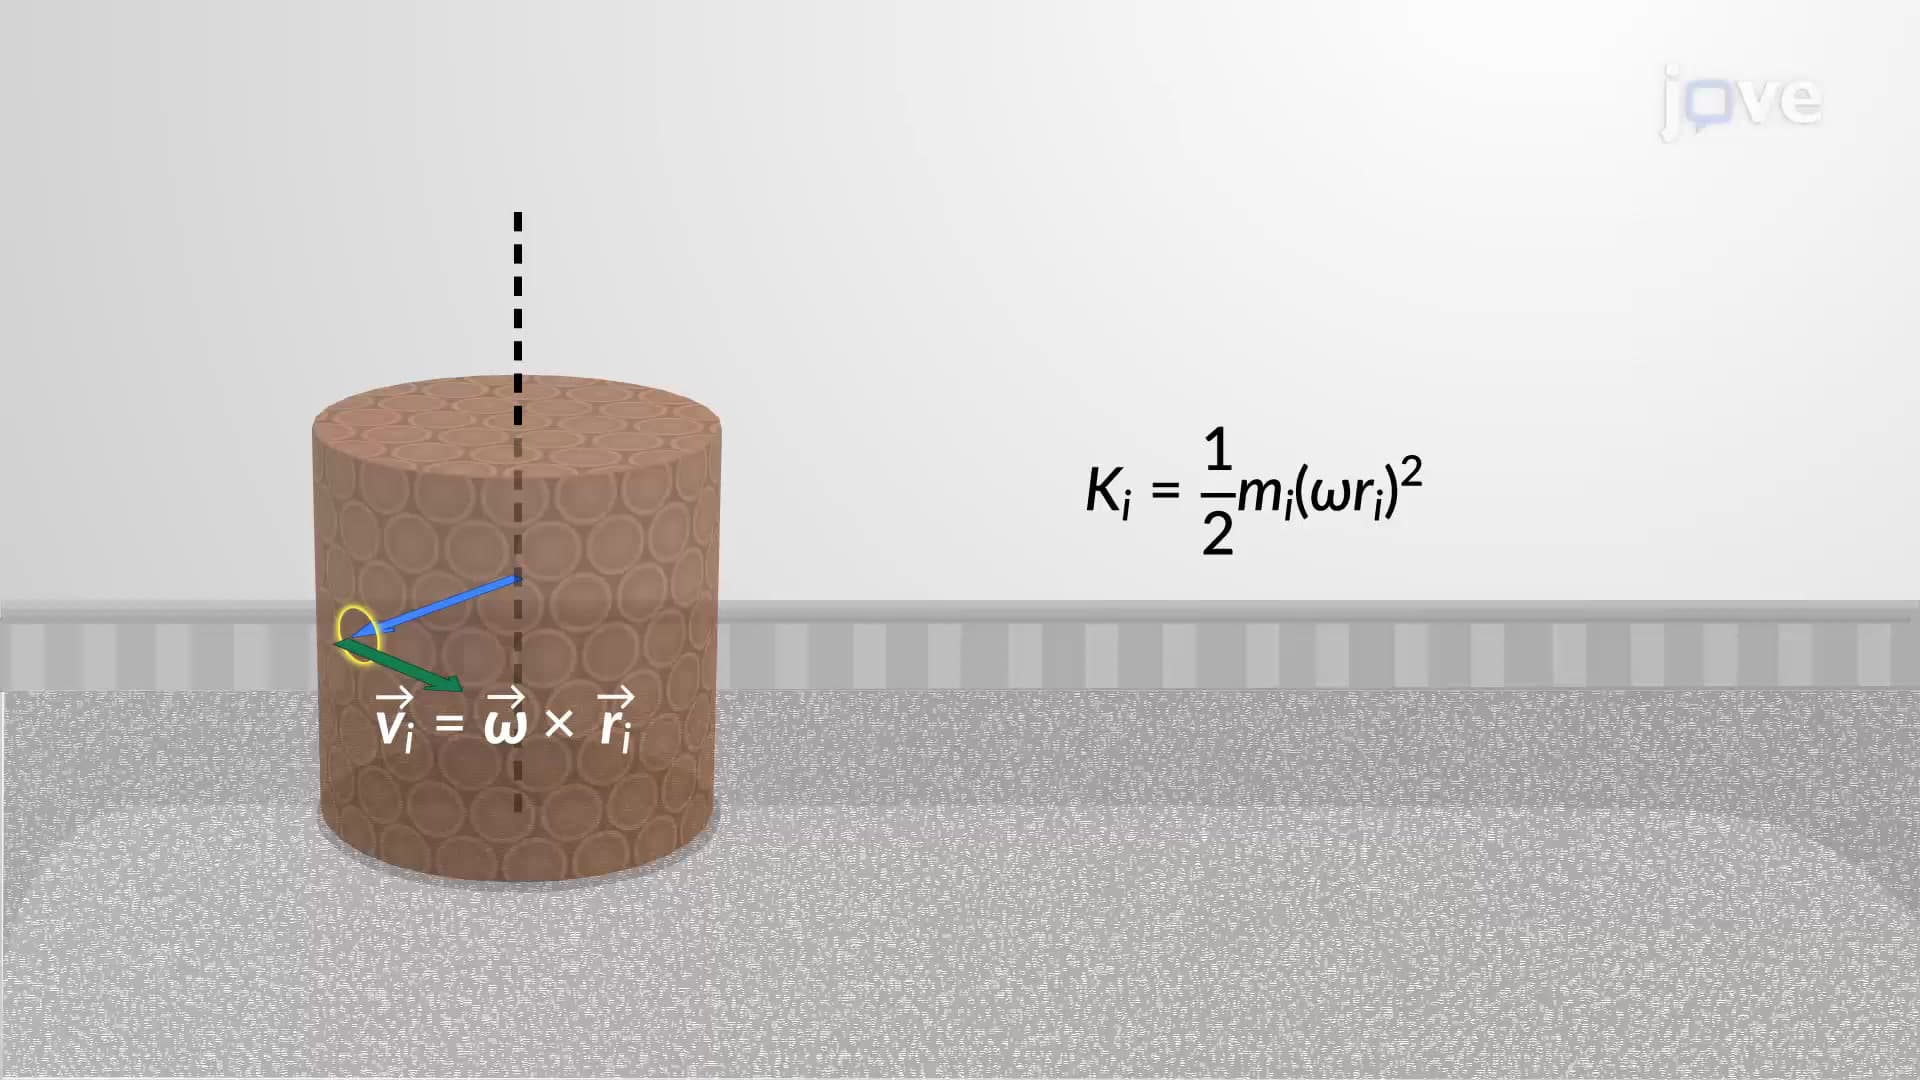
If a rigid body is rotating about an axis but is not in translational motion, its translational kinetic energy is zero. However, since each particle undergoes rotational motion, it possesses non-zero velocity and kinetic energy. Thus, the kinetic energy of the rigid body, which is the sum of the...
If a rigid body is rotating about an axis but is not in translational motion, its translational kinetic energy is zero. However, since each particle undergoes rotational motion, it possesses non-zero velocity and kinetic energy. Thus, the kinetic energy of the rigid body, which is the sum of the...
12.4K