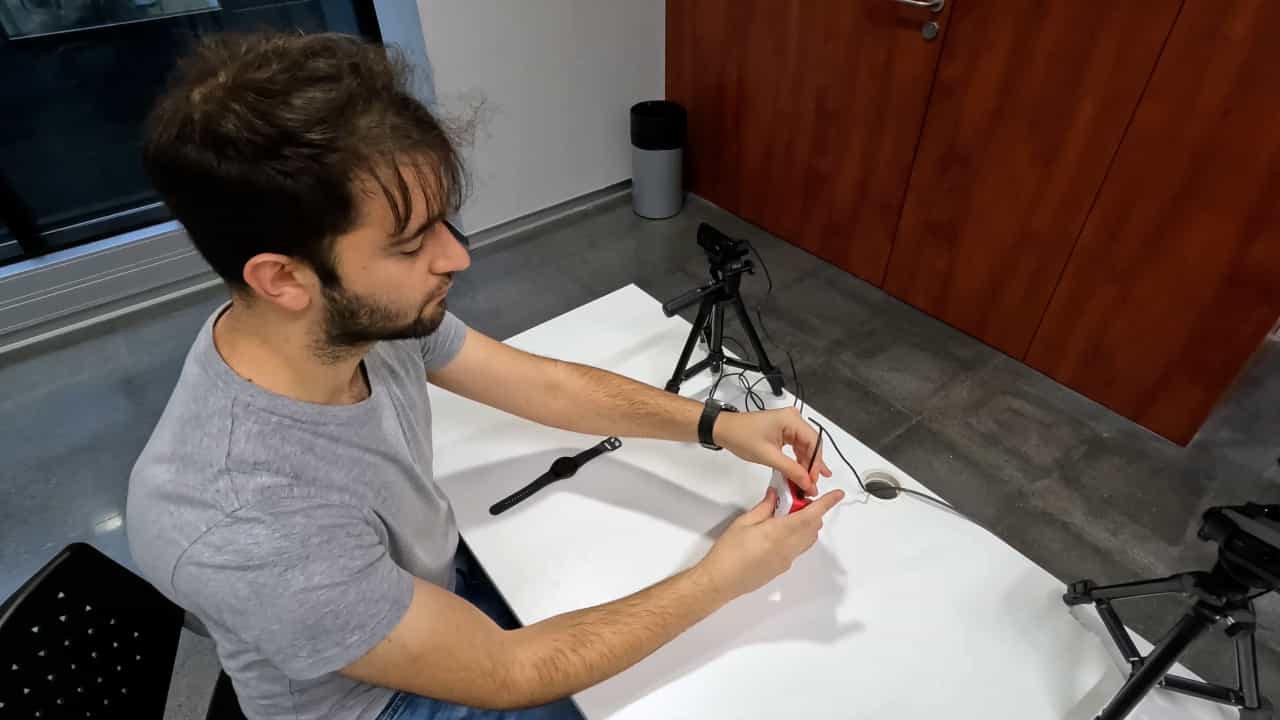

减少传感器定向变量的影响在人类活动识别中,使用一致的参考系统
Manuel Gil-Martín1, Javier López-Iniesta1, Fernando Fernández-Martínez1
1Speech Technology and Machine Learning, Information Processing and Telecommunications Center, E.T.S.I. de Telecomunicación, Universidad Politécnica de Madrid, 28040 Madrid, Spain.
Sensors (Basel, Switzerland)
|July 14, 2023

概括
传感器方向的变化显著影响人类活动识别 (HAR) 系统. 本研究引入了一个预处理模块,该模块建立了一个一致的参考系统,转换三轴信号以减轻定向错误并提高HAR准确性.
科学领域:
- 计算机科学 计算机科学
- 机器学习 机器学习
- 信号处理 信号处理
背景情况:
- 传感器的定位对于使用三轴信号进行准确的人类活动识别 (HAR) 是至关重要的.
- 传感器位置的变化引入了重大错误,降低了HAR系统的性能.
研究的目的:
- 开发和评估一种新的预处理模块,以解决HAR中的传感器方向变化.
- 为了提高HAR系统的稳定性和准确性,尽管传感器的方向不一致.
主要方法:
- 一个预处理模块被设计用于估计一个一致的参考系统.
- 三轴传感器信号被转化为这个参考系统.
- 该方法在六个不同的HAR数据集中使用主体智能交叉验证进行了验证.
主要成果:
- 拟议的模块有效地减轻了传感器方向变化对HAR准确度的负面影响.
- 即使在传感器方向发生突然变化时,也可以实现强大的HAR性能.
- 在WISDM数据集上,精度从89.19%恢复到91.46%,与一致的定向相匹配的性能.
结论:
- 开发的预处理模块在现实场景中显著提高了HAR系统的可靠性.
- 这种方法为部署HAR系统提供了一个实用的解决方案,在这些系统中,传感器的方向不能被严格控制.
- 该方法在多个数据集的分类准确性方面取得了实质性的改进.
相关概念视频
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
424
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
424
 01:25
Relative Motion Analysis using Rotating Axes
489
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
489