相关实验视频
Updated: Jul 23, 2025
10:16

A Protocol for Real-time 3D Single Particle Tracking
Published on: January 3, 2018
15.0K
在单个观察者被动定位中用于速度向量估计的次优化优化策略
Shuyi Gu1,2, Zhenghua Luo1,2,3, Yingjun Chu2,3
1School of Electronic Information and Electrical Engineering, Chengdu University, Chengdu 610106, China.
Sensors (Basel, Switzerland)
|July 14, 2023

概括
本研究提出了一种新的亚最佳估计方法,用于在被动定位系统中独立确定目标速度. 该方法通过动态加权优化标准来提高准确性和稳定性,以实现更快的融合.
科学领域:
- 工程 工程师 工程师 工程师
- 信号处理 信号处理
- 机器人技术 机器人技术 机器人技术
背景情况:
- 单个观察者被动定位系统同时估计目标位置和速度.
- 同时估计可能会导致相关错误,扭曲结果并需要独立估计.
- 准确的速度估计对于有效的被动定位至关重要.
研究的目的:
- 在单个观察者被动本地化中引入一种新的亚最佳估计策略,用于独立的速度向量的估计.
- 为了解决传统的同时估计方法中相关错误的局限性.
- 为了提高被动定位系统的准确性和稳定性.
主要方法:
- 开发了一个次优估计策略,将速度估计重新定义为全球优化搜索.
- 从初始解决方案空间实现了多个优化标准的动态权重.
- 使用模拟模型验证了对均运动和恒定加速度目标轨迹的方法.
主要成果:
- 与传统方法相比,拟议的次优估计方法显示了较快的趋同.
- 在速度向量的估计中取得了更高的准确性.
- 在不同的运动模型中表现出强大的稳定性.
结论:
- 非最佳估计策略为被动本地化中的独立速度估计提供了显著的进步.
- 该方法具有动态权重标准的能力,确保了更好的性能和可靠性.
- 这种方法提高了单个观察者被动定位系统的整体有效性.
相关概念视频
 01:12
Average and Instantaneous Velocity Vectors
6.3K
To calculate other physical quantities in kinematics, the time variable must be introduced. The time variable not only allows us to state where an object is (its position) during its motion, but also how fast it’s moving. The speed at which an object is moving is given by the rate at which the position changes with time. For each position, a particular time is assigned. If the details of the motion at each instant are not important, the rate is usually expressed as the average velocity v.
6.3K
 01:24
Relative Motion Analysis - Velocity
394
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
394
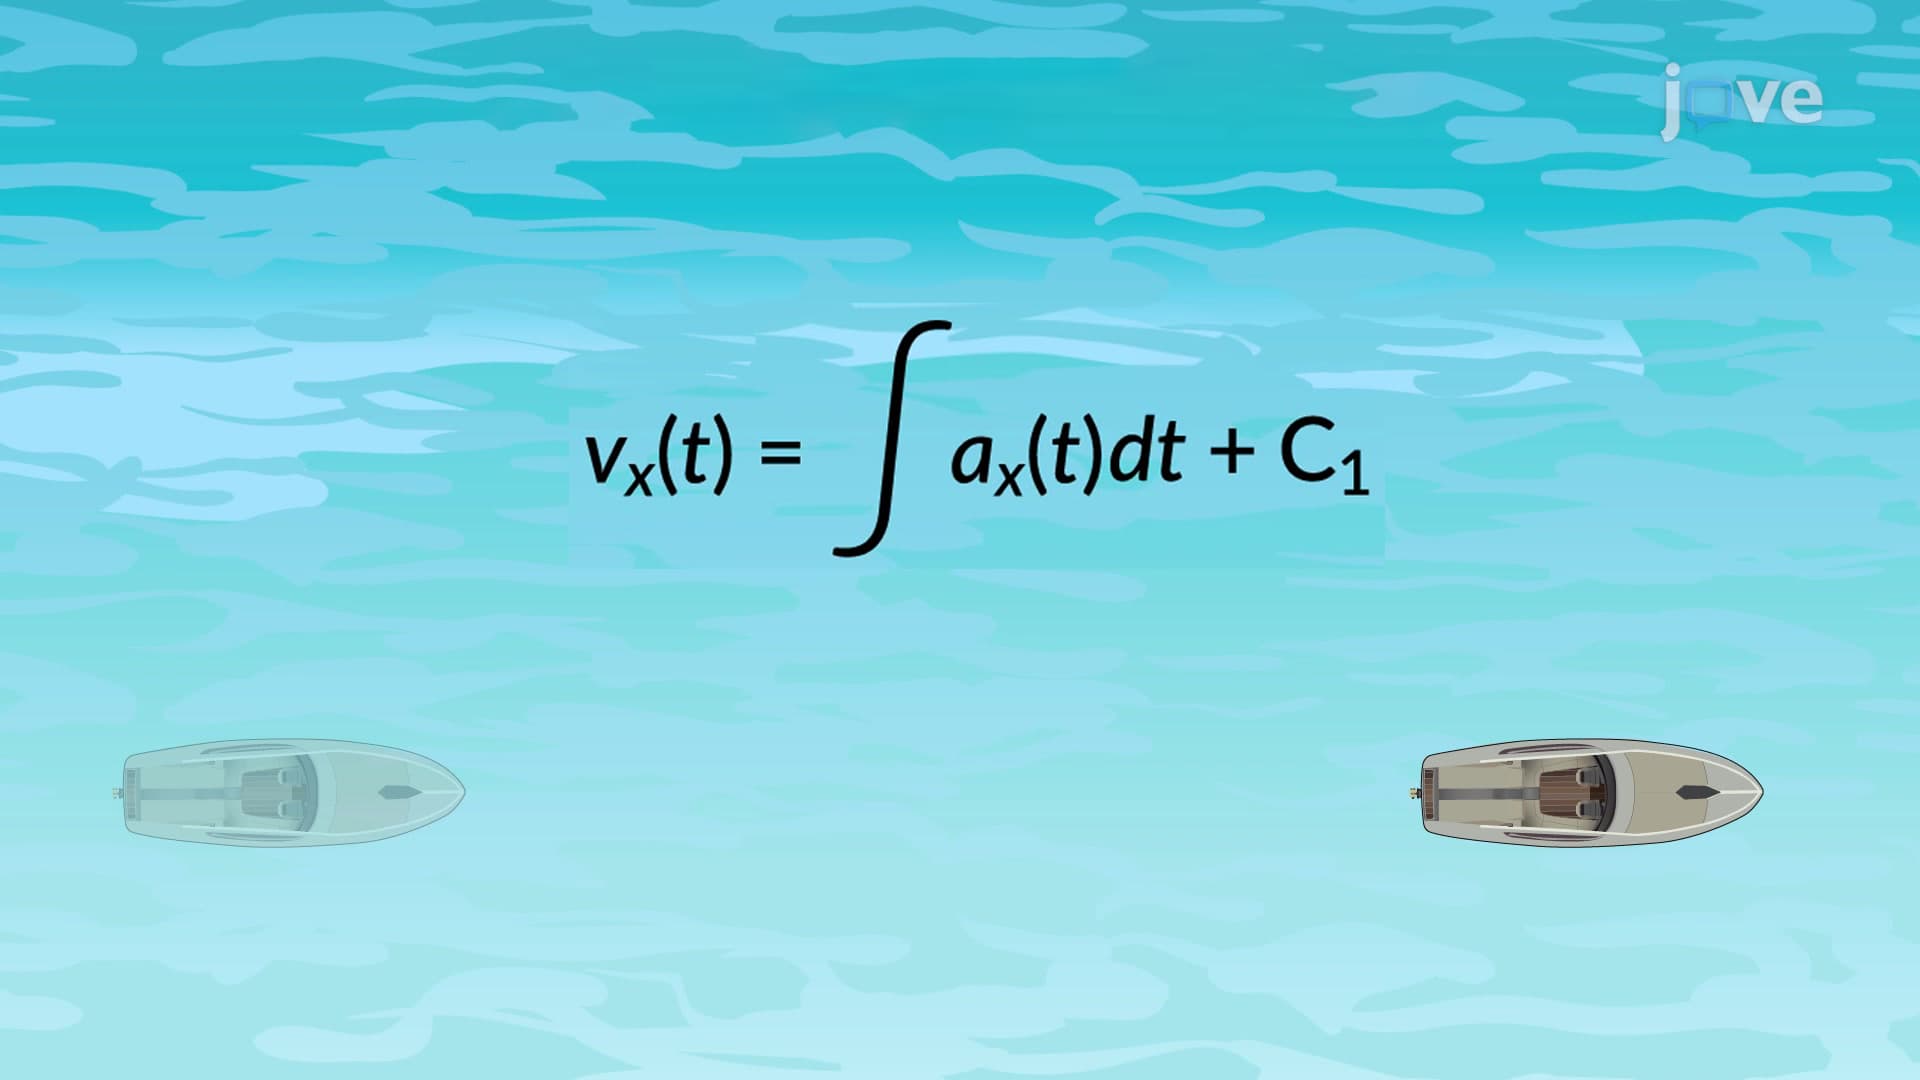 01:13
Velocity and Position by Integral Method
6.1K
If acceleration as a function of time is known, then velocity and position functions can be derived using integral calculus. For constant acceleration, the integral equations refer to the first and second kinematic equations for velocity and position functions, respectively.
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
6.1K
 01:30
Types of Global Positioning System Surveys
81
GPS surveying methods vary in application, accuracy, and data collection techniques, catering to diverse surveying and mapping needs. Static GPS, kinematic GPS, and real-time kinematic (RTK) surveying are widely used. Each technique offers distinct advantages.Static GPS involves placing one receiver at a known reference point and another at the target point. It collects exact positional data by observing multiple satellite ranges over an extended period, achieving centimeter-level accuracy for...
81
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
424
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
424
 01:11
Relative Velocity in Two Dimensions
7.3K
Relative velocity is the velocity of an object as observed from a particular reference frame, or the velocity of one reference frame with respect to another reference frame. The concept of relative velocity can be used to describe motion in two dimensions. Consider a particle P and two reference frames S and S′. The position of the origin of S′ as measured in S is , the position of P as measured in S′ is , and the position of P as measured in S is , which can be evaluated by...
7.3K