对于保持姿势稳定性,对干部肌肉的自主依赖性在老年患者中减少,这些患者患有沙吉塔不平衡
Tadashi Ito1, Yoshihito Sakai2, Keitaro Kawai3
1Three-Dimensional Motion Analysis Laboratory, Aichi Prefectural Mikawa Aoitori Medical and Rehabilitation Center for Developmental Disabilities, Okazaki 444-0002, Japan; Department of Integrated Health Sciences, Graduate School of Medicine, Nagoya University, Nagoya 461-8673, Japan.
Gait & posture
|July 14, 2023

概括
患有斜腰不平衡的老年人不太依赖部平衡策略. 这项研究量化了自感控制,突出了改善平衡和姿势稳定的干预措施的必要性.
科学领域:
- 老年学是一门学科.
- 生物力学 生物力学
- 神经科学是一个神经科学.
背景情况:
- 老年人的 Sagittal 失衡与平衡和自身感知障碍有关.
- 关于影响脊柱对齐和形的自感机制的证据有限.
- 了解这些机制对于管理与年龄相关的姿势衰退至关重要.
研究的目的:
- 在老年人中量化自身感知控制,以沙吉塔不平衡.
- 为了澄清在这个队列中的自感输入过程中特有的姿势调整.
- 为了研究沙吉塔不平衡和亲感权重比率之间的关系.
主要方法:
- 一个横截面的观察性研究,对36名对照组和68名患有沙吉塔不平衡的患者进行了观察.
- 参与者站在平衡板上,闭上眼睛,接受胃半肌和腰部多肌的振动刺激.
- 测量了相对自感权重比 (RPW) 和压力中心,以评估姿势调整.
主要成果:
- 与对照组 (p=0.013) 相比,患有斜腰不平衡的老年人表现出更高的RPW (56-100 Hz).
- 沙吉塔不平衡与足自感受控制的显著优势有关 (OR:1.1,p=0.012).
- 对平衡控制的部策略的依赖,在那些有斜腰不平衡的人群中减少了.
结论:
- 在体感输入过程中对姿势稳定性的定量评估对老年人具有斜腰不平衡至关重要.
- 识别改变的姿势策略,如减少部依赖,是针对性干预的关键.
- 旨在改善自身感知的干预措施可以提高这一群体的姿势稳定性和策略性.

相关概念视频
 01:22
Indirect Motor Pathways
1.6K
The indirect motor or extrapyramidal pathways originate in the brainstem, the lower portion of the brain that connects it to the spinal cord. They consist of several distinct tracts, each with specialized functions. The four main tracts of the indirect motor pathways are the vestibulospinal tract, the reticulospinal tract, the tectospinal tract, and the rubrospinal tract.
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
1.6K
 01:28
Major Somatic Sensory Pathways
1.0K
Sensory impulses related to touch, pressure, vibration, and proprioception from various body parts, such as the limbs, trunk, neck, and posterior head, travel to the cerebral cortex through the posterior column-medial lemniscus pathway. The pathway’s name derives from the two white-matter tracts that convey the impulses: the spinal cord's posterior column and the brainstem's medial lemniscus. First-order sensory neurons extend their axons into the spinal cord, forming the...
1.0K
 01:22
Somatic Spinal Reflexes
2.2K
Somatic spinal reflexes are rapid, involuntary muscular responses to external stimuli that involve the somatic musculature and the spinal cord.
One of the most well-known somatic spinal reflexes is the stretch reflex, which is activated by the sudden stretching of a muscle. This reflex involves the activation of specialized sensory receptors called muscle spindles, which are located in the muscle tissue and detect changes in the length and speed of muscle contractions. When a muscle is suddenly...
One of the most well-known somatic spinal reflexes is the stretch reflex, which is activated by the sudden stretching of a muscle. This reflex involves the activation of specialized sensory receptors called muscle spindles, which are located in the muscle tissue and detect changes in the length and speed of muscle contractions. When a muscle is suddenly...
2.2K
 01:21
Rigid Body Equilibrium Problems - II
7.1K
A rigid body is in static equilibrium when the net force and the net torque acting on the system are equal to zero.
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
7.1K
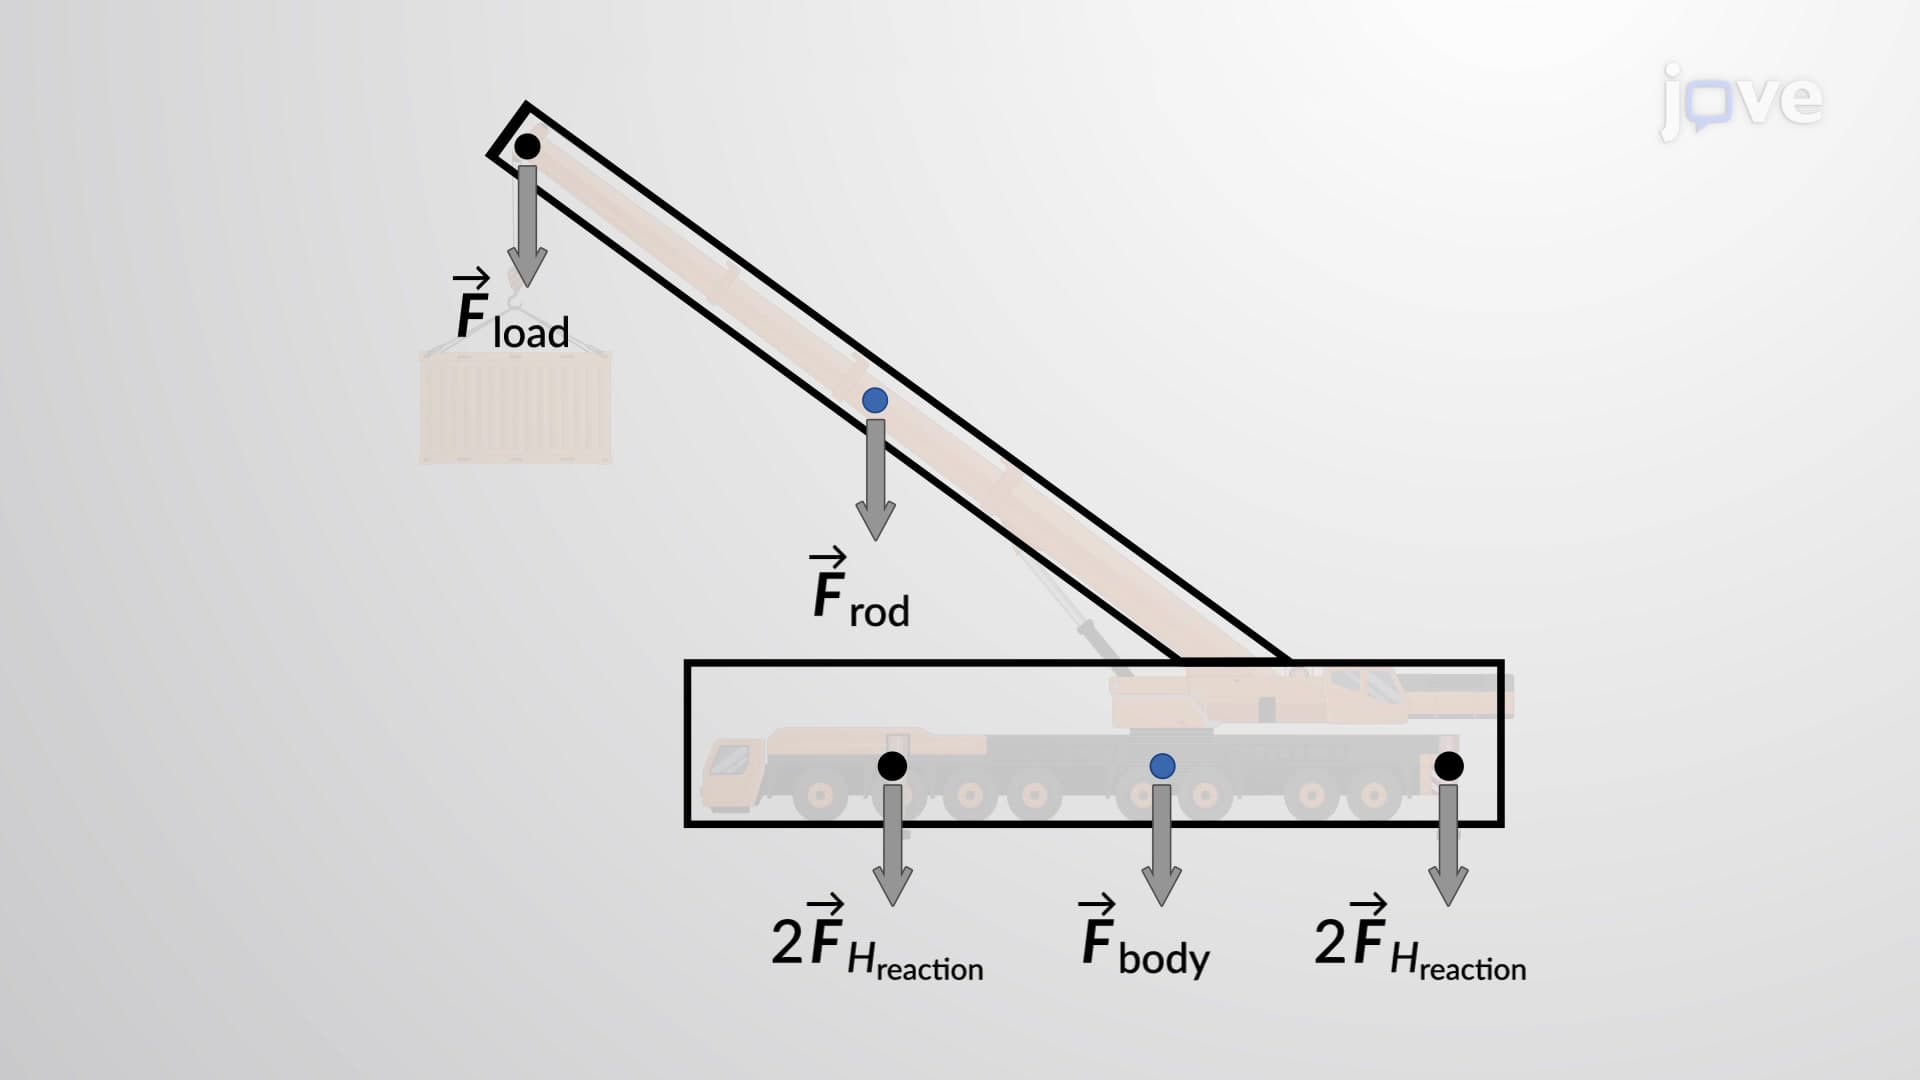 00:49
Rigid Body Equilibrium Problems - I
4.5K
A rigid body is said to be in static equilibrium when the net force and the net torque acting on the system is equal to zero. To solve for rigid body equilibrium problems, do the following steps.
4.5K