
一个基于干扰观察器和神经网络的有限时间滑动模式控制器,用于歇斯底里系统,用于压电执行器
Liqun Cheng1,2, Wanzhong Chen1, Liguo Tian2
1College of Communication Engineering, Jilin University, Changchun 130012, China.
Sensors (Basel, Switzerland)
|July 29, 2023

概括
本研究介绍了一种新的有限时间滑动模式控制器 (SMC),使用辐射基函数 (RBF) 神经网络 (NN) 和干扰观察器 (DOB) 来提高压电执行器 (PEA) 控制精度. 该方法有效地减轻了hysteresis,并提高了高精度定位系统的跟踪性能.
科学领域:
- 机械电子和控制系统
- 材料科学与工程 材料科学与工程
- 机器人和自动化 机器人和自动化
背景情况:
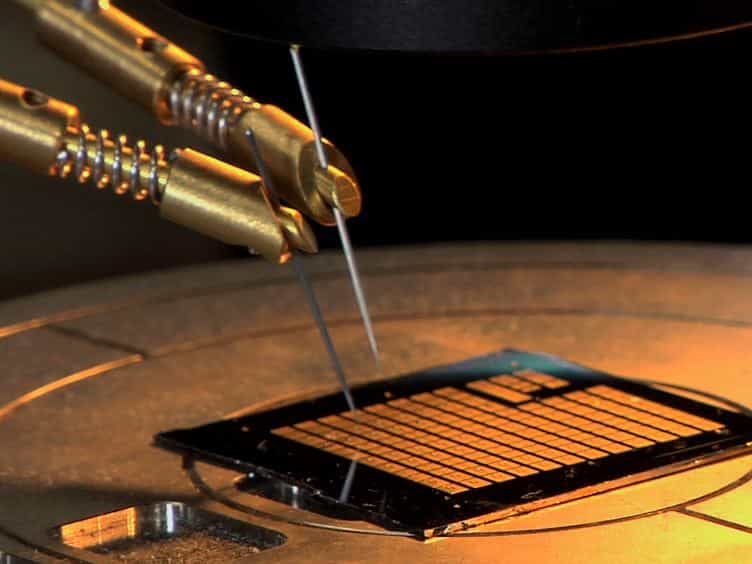
- 压电执行器 (PEAs) 对于微/纳米高精度定位至关重要,因为它们的高分辨率和频率响应.
- PEAs表现出非线性歇斯底里,受输入频率的影响,这使精确的控制变得复杂.
- 现有的PEA适应性控制研究解决了跟踪控制的挑战.
研究的目的:
- 为压电执行器 (PEAs) 开发一种先进的控制策略,克服固有的歇斯底里非线性.
- 为了提高PEAs在高精度应用中的跟踪控制精度和稳定性.
- 提出一种新的控制方法,消除了对显式歇斯底里模型的需求.
主要方法:
- 实现一个有限时间滑动模式控制器 (SMC),集成到一个辐射基函数 (RBF) 神经网络 (NN).
- 使用一种新的有限时间适应性干扰观察器 (DOB) 来估计没有先前知识的系统干扰.
- 使用 RBF-NN 来动态补偿歇斯底里,取代传统的歇斯底里模型.
主要成果:
- 拟议的基于RBF-NN的DOB控制器证明了闭环系统的实际有限时间稳定性.
- 在各种频率上,追踪错误在有限的时间内汇聚到零的小邻里.
- 在商业PEA平台上的实验验证证证了该方法在提高追踪精度方面的可行性和有效性.
结论:
- 开发的具有RBF-NN和自适应DOB的有限时间SMC为精确的PEA控制提供了强大的解决方案.
- 这种方法显著提高了跟踪控制的准确性,特别是在动态条件和不同频率下.
- 该方法与显式歇斯底里模型的独立性及其简单的DOB结构有助于其实际应用.

相关概念视频
 01:07
Time-Domain Interpretation of PD Control
141
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
141
 01:26
PD Controller: Design
282
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
282
 01:27
Time and frequency -Domain Interpretation of PI Control
160
Proportional-Integral (PI) controllers are essential in many control systems to improve stability and performance. They are commonly used in everyday devices like thermostats to enhance system damping and reduce steady-state error. When the zero in the controller's transfer function is optimally placed, the system benefits significantly in terms of stability and accuracy.
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
160
 01:24
PI Controller: Design
331
Proportional Integral (PI) controllers are a fundamental component in modern control systems, widely used to enhance performance and mitigate steady-state errors. They are particularly effective in applications such as automatic brightness adjustment on smartphones, where they excel at mitigating steady-state errors for step-function inputs. Unlike PD controllers, which require time-varying errors to function optimally, PI controllers leverage their integral component to address residual...
331
 01:18
Second Order systems II
131
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
131
 01:19
PID Controller
146
Proportional-Integral-Derivative (PID) controllers are widely used in various control systems to enhance stability and performance. In a thermostat, it adjusts heating or cooling based on the temperature difference between the actual and desired levels. They are often used in automotive speed systems, effectively managing sudden speed changes while maintaining a constant speed under varying conditions. On the other hand, PI controllers, commonly employed in voltage regulation, enhance stability...
146