
在功能性任务评估过程中,用光学运动捕捉和惯性测量单元定义部轴旋转
Angelica E Lang1, Kenzie B Friesen2
1Canadian Centre for Health and Safety in Agriculture, College of Medicine, University of Saskatchewan, 104 Clinic Place, Saskatoon, SK, S7N 2Z4, Canada. angelica.lang@usask.ca.
Medical & biological engineering & computing
|August 3, 2023

概括
真轴旋转方法提供了比欧勒角更一致的部轴旋转测量,改善了光学运动捕捉和惯性测量单位 (IMU) 之间的比较. 这提高了肩膀运动分析的精度.
科学领域:
- 生物力学 生物力学
- 人类运动分析 人类运动分析
- 整形外科 整形外科 整形外科
背景情况:
- 精确测量骨轴旋转对于理解肩膀生物力学至关重要.
- 传统的欧勒/卡丹角序列用于部旋转分析对所选择的旋转顺序敏感,导致可变的结果.
- 一种新的"真轴旋转"计算方法已被提出,其精度可能更高.
研究的目的:
- 为了比较从光学运动捕捉和惯性测量单元 (IMU) 获得的部轴旋转测量.
- 为了评估两个计算方法的准确性和一致性:欧勒角与真轴旋转方法对比.
主要方法:
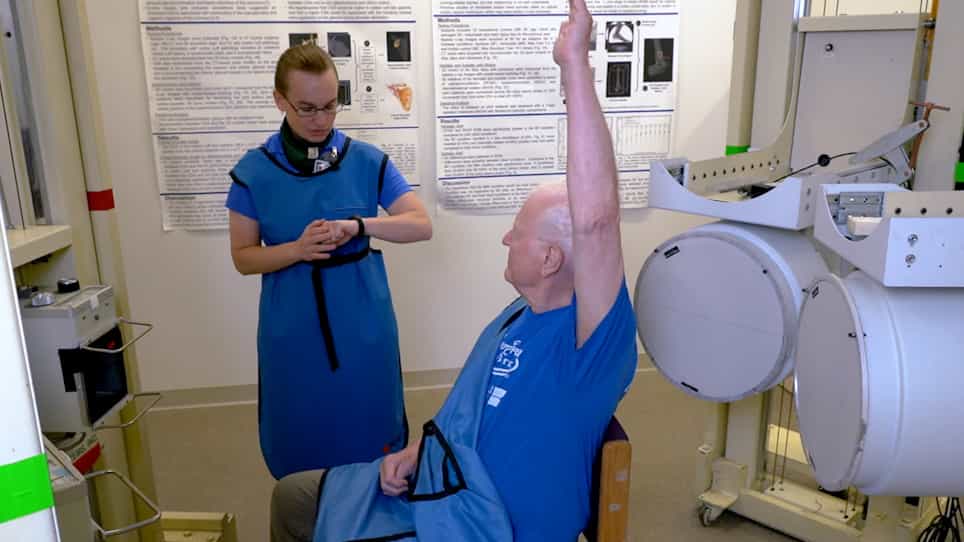
- 三十名没有上肢损伤的参与者通过光学运动捕捉和IMU进行了干和主导腰椎运动跟踪.
- 参与者执行了一个标准化的功能任务协议.
- 使用欧勒分解和True轴方法计算骨轴旋转;使用双向ANOVA统计比较数据.
主要成果:
- 真轴旋转方法在光学运动捕捉和IMU之间没有显著差异 (p > 0.05).
- 相比之下,欧勒的角度计算在两种系统之间产生了实质性的大小差异 (大约20-30°).
- 对于两种运动捕捉系统,欧勒角度和真轴方法之间观察到显著的差异.
结论:
- 真正轴旋转方法在不同的运动捕捉系统中提供了更一致和可比的膀轴旋转测量.
- 这种增强的一致性促进了在肩膀生物力学研究中更精确的测量和可靠的比较.
- 推使用True轴方法来准确分析部轴旋转,特别是在比较光学和IMU系统的数据时.
相关概念视频
 01:25
Relative Motion Analysis using Rotating Axes
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...