在随机激发下的一类非线性Duffing型系统中,极端事件的发生机制
Dan Zhao1, Yongge Li1, Qi Liu1,2
1School of Mathematics and Statistics, Northwestern Polytechnical University, Xi'an 710072, China.
Chaos (Woodbury, N.Y.)
|August 4, 2023

概括
在非线性系统中,极端事件可能由于强烈的激发,分叉或切换到罕见的吸引器而发生. 了解这些机制有助于预测和避免极端事件.
科学领域:
- 非线性动力学是一种非线性动力学.
- 随机过程 随机过程
- 混沌理论的理论.
背景情况:
- 在具有随机干扰的系统中驱动极端事件的机制尚未完全理解.
- 一般化的Duffing类型系统作为研究这些复杂现象的模型.
研究的目的:
- 阐明三种不同的机制,负责非线性系统中极端事件的发生.
- 为预测和减轻极端事件提供洞察力.
主要方法:
- 对受到随机干扰的一般化Duffing型系统的分析.
- 研究极端刺激,分叉动态和罕见的吸引物现象.
主要成果:
- 极端事件可以由强烈的刺激 (例如,莱维噪声) 引发.
- 随机变化的分叉参数可以在有分叉的系统中引发极端事件.
- 随机的冲动刺激 (例如,Poisson白噪声) 可以导致模式切换到罕见的吸引器,从而导致极端事件.
结论:
- 在Duffing型系统中确定了极端事件发生的三个主要机制.
- 这些发现为类似非线性系统中极端事件的增强预测和避免策略提供了基础.
更多相关视频
相关概念视频
 01:07
Damped Oscillations
5.8K
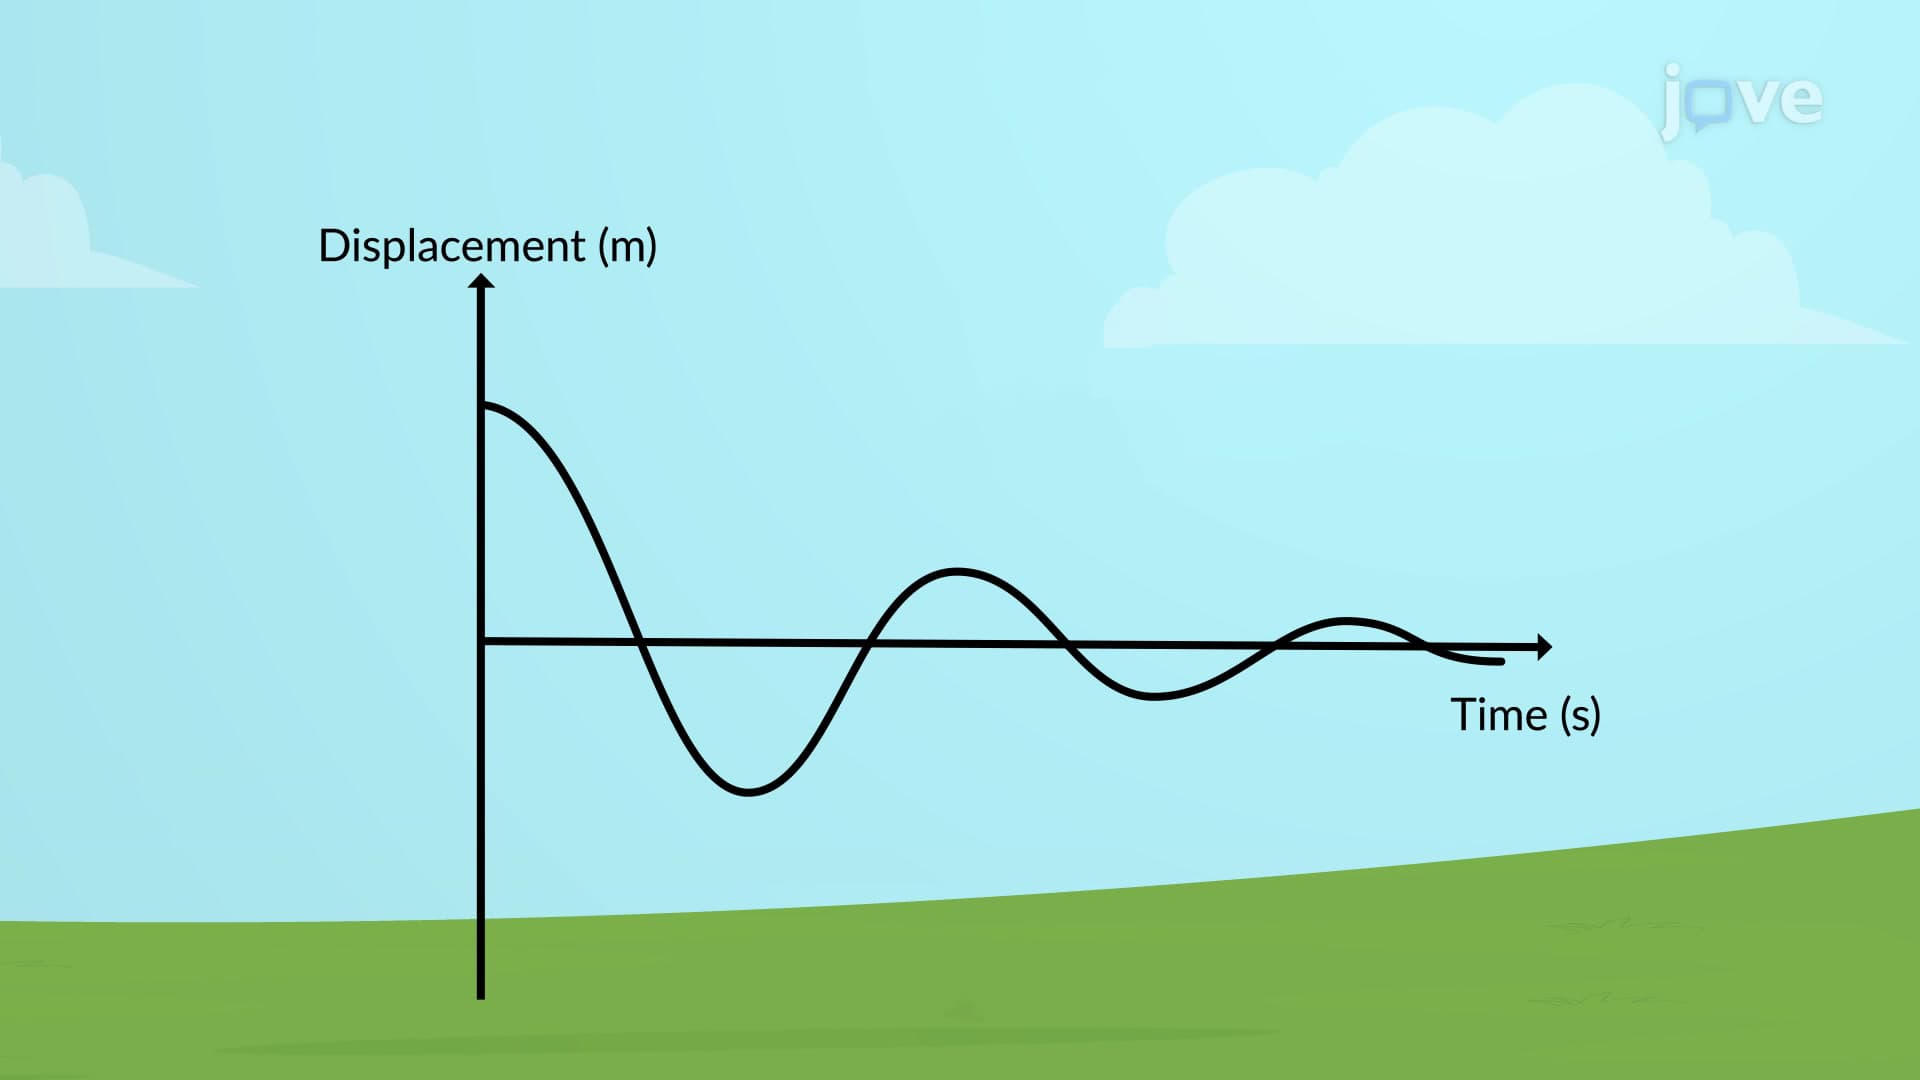
In the real world, oscillations seldom follow true simple harmonic motion. A system that continues its motion indefinitely without losing its amplitude is termed undamped. However, friction of some sort usually dampens the motion, so it fades away or needs more force to continue. For example, a guitar string stops oscillating a few seconds after being plucked. Similarly, one must continually push a swing to keep a child swinging on a playground.
Although friction and other non-conservative...
Although friction and other non-conservative...
5.8K
 01:20
Types of Damping
6.5K
If the amount of damping in a system is gradually increased, the period and frequency start to become affected because damping opposes, and hence slows, the back and forth motion (the net force is smaller in both directions). If there is a very large amount of damping, the system does not even oscillate; instead, it slowly moves toward equilibrium. In brief, an overdamped system moves slowly towards equilibrium, whereas an underdamped system moves quickly to equilibrium but will oscillate about...
6.5K
 01:18
Second Order systems II
130
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
130
 01:06
Forced Oscillations
6.6K
When an oscillator is forced with a periodic driving force, the motion may seem chaotic. The motions of such oscillators are known as transients. After the transients die out, the oscillator reaches a steady state, where the motion is periodic, and the displacement is determined.
6.6K
 01:11
Types of Responses of Series RLC Circuits
921
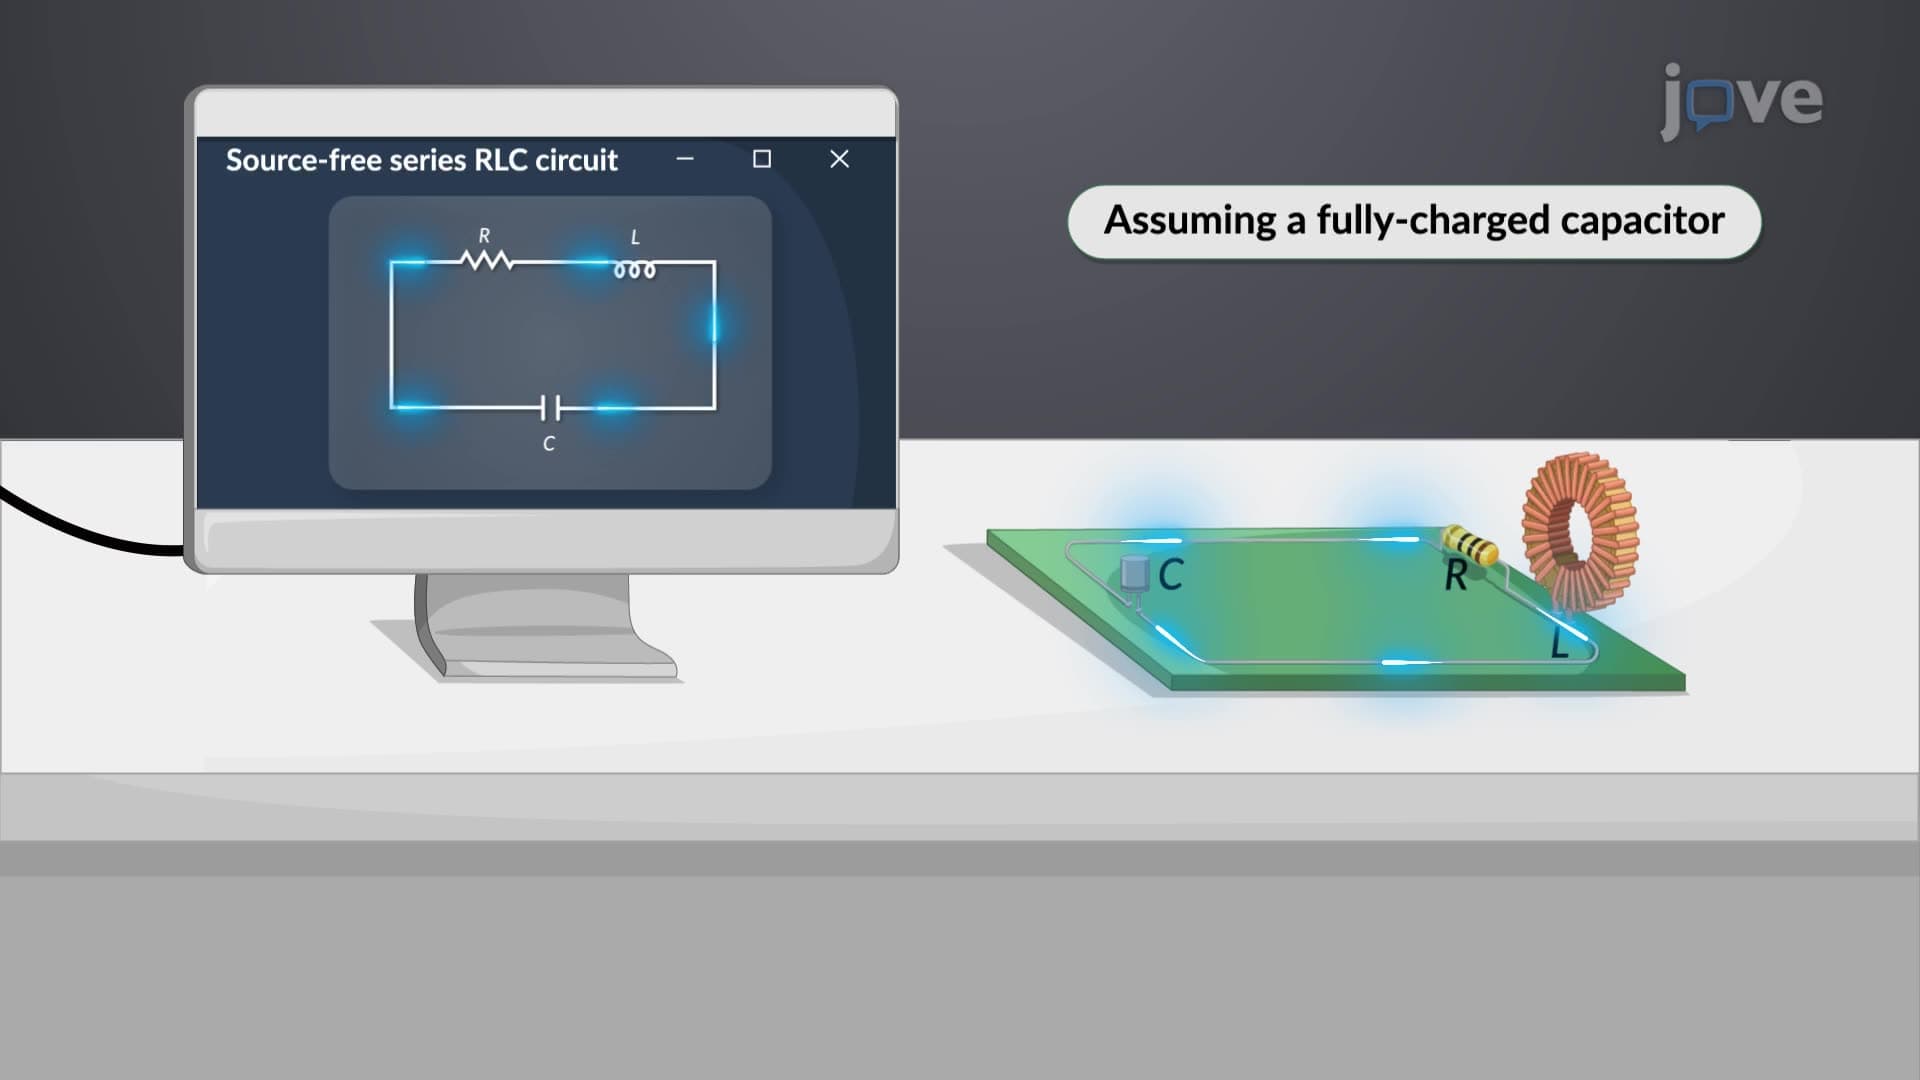
A second-order differential equation characterizes a source-free series RLC circuit, marking its distinct mathematical representation. The complete solution of this equation is a blend of two unique solutions, each linked to the circuit's roots expressed in terms of the damping factor and resonant frequency.
921
 01:26
Linear Approximation in Frequency Domain
110
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
110