相关实验视频
Updated: Jul 19, 2025

10:09

Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
6.7K
基于圆排斥范围边界约束潜力场方法的果园割草机器人的本地路径规划研究
Wenyu Zhang1, Ye Zeng1, Sifan Wang1
1College of Engineering, South China Agricultural University, Guangzhou, China.
Frontiers in plant science
|August 7, 2023

概括
这项研究介绍了一种改进的人工潜力场算法,用于果园割草机器人. 改进的算法通过防止机器人越过果树边界来确保更安全的导航,从而导致更短,更流的路径.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 农业工程 农业工程
- 人工智能的人工智能
背景情况:
- 果园环境为自主割草机器人带来了复杂的地形挑战.
- 运营安全受到不可预测的障碍和避免损害果树的必要性所影响.
研究的目的:
- 开发一个改进的本地路径规划算法,用于人工潜在的基于现场导航.
- 在复杂的果园地形中提高割草机器人的安全性和效率.
主要方法:
- 引入了一个圆的排斥潜力场来定义边界.
- 利用了一个改进的可变多项式潜在场函数,具有距离因子.
- 整合了一个水果树边界潜力场,以防止穿越指定区域.
主要成果:
- 改进的算法有效地解决了不可达到的目标和局部最小值的问题.
- 通过将排斥场范围修改为圆,减少了环境潜在场的复杂性.
- 与传统的人工潜能方法相比,实现了6.78%更短的路径长度.
- 证明了更短,更光滑的路径,具有卓越的避障能力.
结论:
- 增强的人工潜力场算法显著提高了果园中自动割草机器人的安全性和效率.
- 该算法能够先发制人地避开障碍物,并尊重果树边界的能力使其适合于独立的机器人操作.

相关概念视频
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
421
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
421
 01:19
Root-Locus Method
180
A cruise control system in a car is designed to maintain a specified speed automatically by adjusting the gas pedal. The system continuously measures the vehicle's speed and makes fine adjustments to the pedal to achieve this goal. The root locus method is particularly useful for understanding how the cruise control system's behavior changes under varying conditions, such as when the car goes uphill, downhill, or faces strong wind resistance.
This system can be represented by a block...
This system can be represented by a block...
180
 01:19
Plotting and Calibrating the Root Locus
147
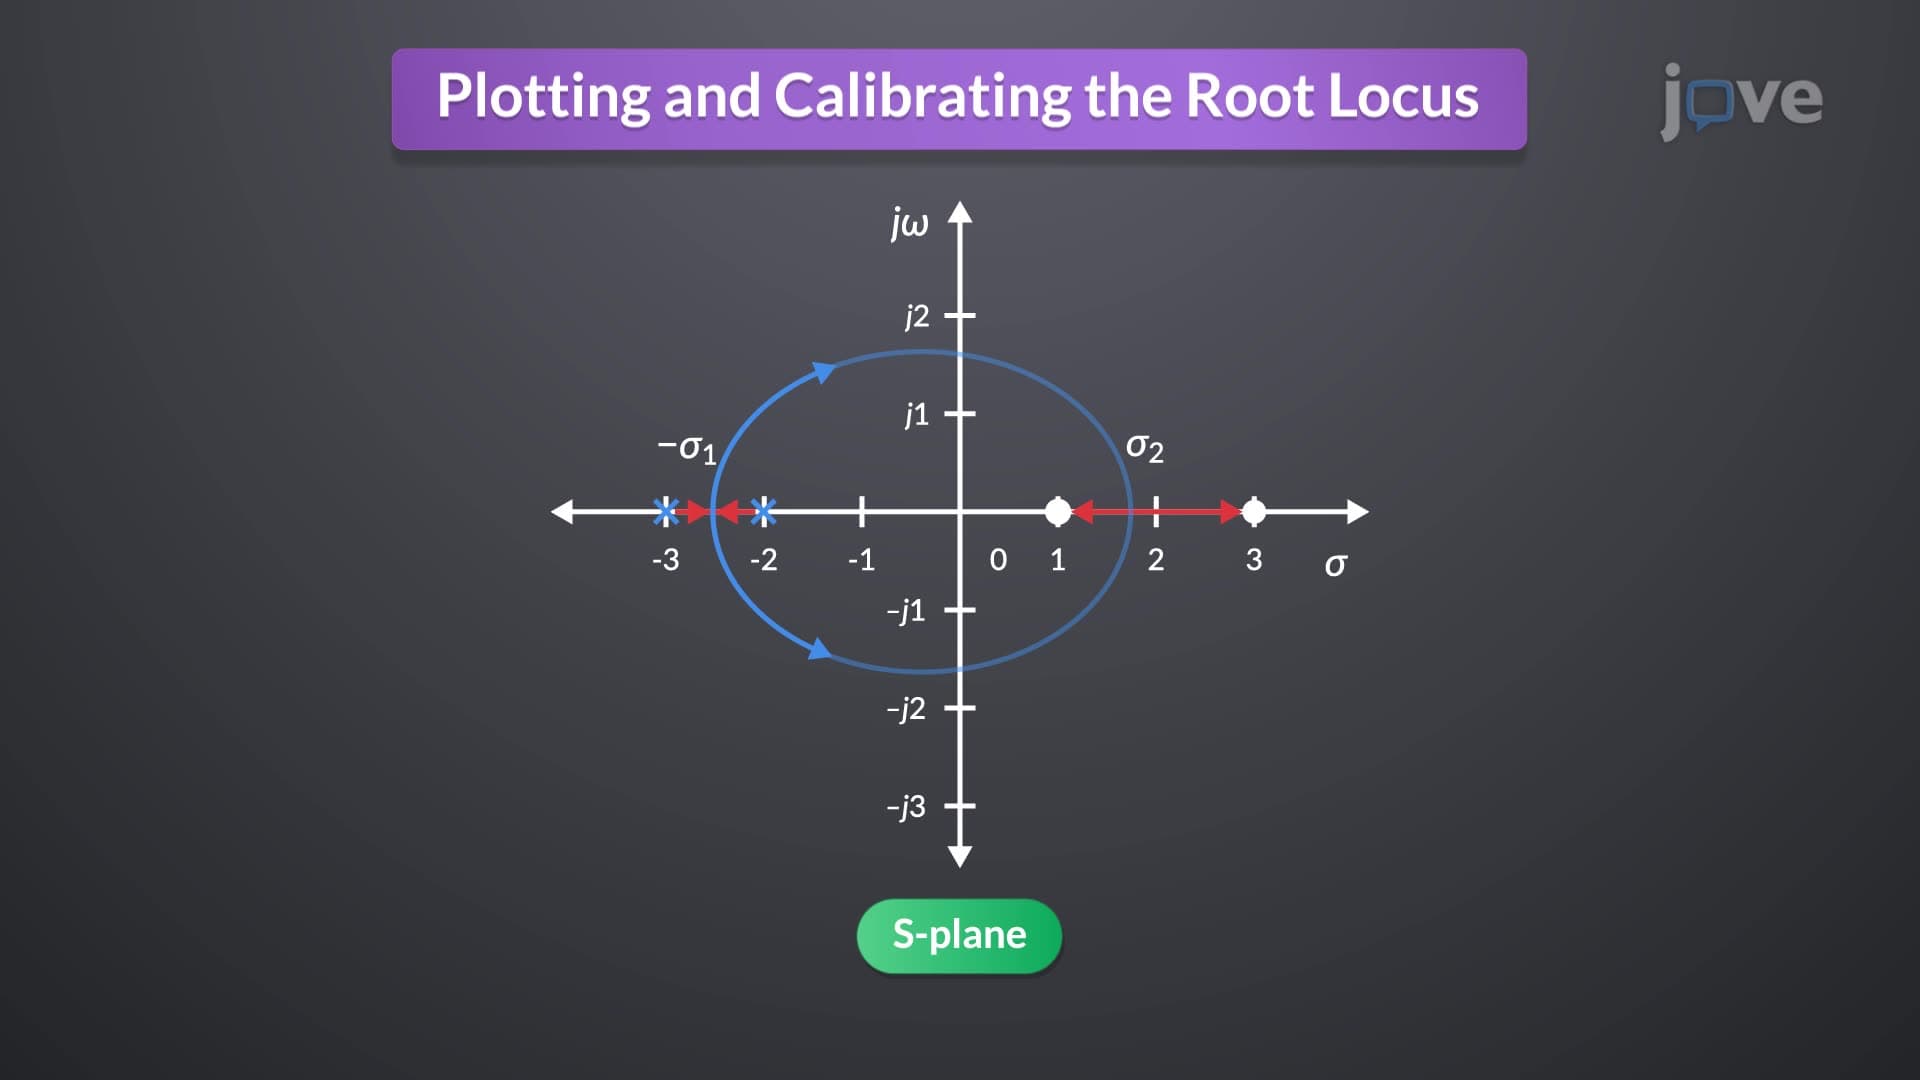
Root loci often diverge as system poles shift from the real axis to the complex plane. Key points in this transition are the breakaway and break-in points, indicating where the root locus leaves and reenters the real axis. The branches of the root locus form an angle of 180/n degrees with the real axis, where n is the number of branches at a breakaway or break-in point.
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
147
 01:26
Areas Within Irregular Boundaries
95
Calculating areas within irregular boundaries, such as along rivers or curved roads, is crucial in various fields, including surveying, engineering, and environmental management. Surveyors often begin by creating a traverse, a connected series of straight lines approximating the area's boundary. The coordinates of each traverse point are essential for calculating the enclosed area. The double meridian distance formula is a widely used technique for this purpose. This method utilizes the...
95
 01:29
Two-Dimensional Force System: Problem Solving
615
Solving problems related to two-dimensional force systems is an essential aspect of mechanics and engineering. By applying the principles of vector analysis and force equilibrium, one can determine the effect of multiple forces acting on an object in a two-dimensional space.
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
615
 01:30
Three-Dimensional Force System:Problem Solving
693
A three-dimensional force system refers to a scenario in which three forces act simultaneously in three different directions. This type of problem is commonly encountered in physics and engineering, where it is necessary to calculate the resultant force on the system, which can then be used to predict or analyze the behavior of the object or structure under consideration.
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
693