

四轮转向车辆系统的稳定性和宝分叉与驾驶员的方向盘控制
Pengcheng Miao1, Denghui Li2, Yuan Yue3
1School of Mechanical Engineering, Yangtze University, Jingzhou 434023, China.
Chaos (Woodbury, N.Y.)
|August 7, 2023

概括
这项研究研究了四轮转向 (4WS) 车辆系统与驾驶员控制中的稳定性和宝分叉. 影响关键速度的关键参数,如可见性和拐角刚度,被确定为增强车辆动态.
科学领域:
- 车辆动力学和控制系统
- 非线性动力学和分叉理论
- 汽车工程 汽车工程
背景情况:
- 了解车辆的稳定性对于安全操作至关重要,尤其是在四轮方向盘 (4WS) 等复杂系统中.
- 分叉分析有助于预测系统行为的突然变化,例如稳定性丧失.
- 驾驶员的方向盘控制引入了非线性,这显著影响了车辆动态.
研究的目的:
- 分析包含驾驶员方向盘控制的4WS车辆系统的稳定性和宝分叉.
- 在系统的参数空间中确定波分叉的拓结构.
- 调查各种系统参数如何影响临界速度和分叉行为.
主要方法:
- 应用中央多元体理论和投影方法.
- 计算第一个和第二个Lyapunov系数来预测Hopf分叉.
- 分析系统参数及其对临界分叉值的影响.
主要成果:
- 波丁分叉,一种退化的霍夫分叉,在参数空间中表征,揭示了系统动态.
- 增加前方可见度距离和后轮转硬度提高了关键速度.
- 从引力中心到前轴的距离增加,驾驶员的时间延迟和前轮拐角刚性降低了关键速度.
结论:
- 该研究提供了关于驾驶员控制下的4WS车辆复杂动态的见解.
- 基于这些发现的参数调整可以优化车辆的稳定性和关键速度.
- 这项研究有助于设计更安全,更可预测的车辆控制系统.

相关概念视频
 01:22
Controller Configurations
119
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
119
 01:22
Multi-input and Multi-variable systems
129
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence...
In the absence...
129
 01:24
Pole and System Stability
329
The transfer function is a fundamental concept representing the ratio of two polynomials. The numerator and denominator encapsulate the system's dynamics. The zeros and poles of this transfer function are critical in determining the system's behavior and stability.
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
329
 01:14
Stability of structures
196
In mechanical engineering, the stability of systems under various forces is critical for designing durable and efficient structures. One fundamental way to explore these concepts is by analyzing systems like two rods connected at a pivot point, O, with a torsional spring of spring constant k at the pivot point. This system is similar in appearance to a scissor jack used to change tires on a car. In this case, the arms of the linkage (equivalent to the rods in this system) are entirely vertical,...
196
 01:26
PD Controller: Design
282
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
282
 01:28
Stability
155
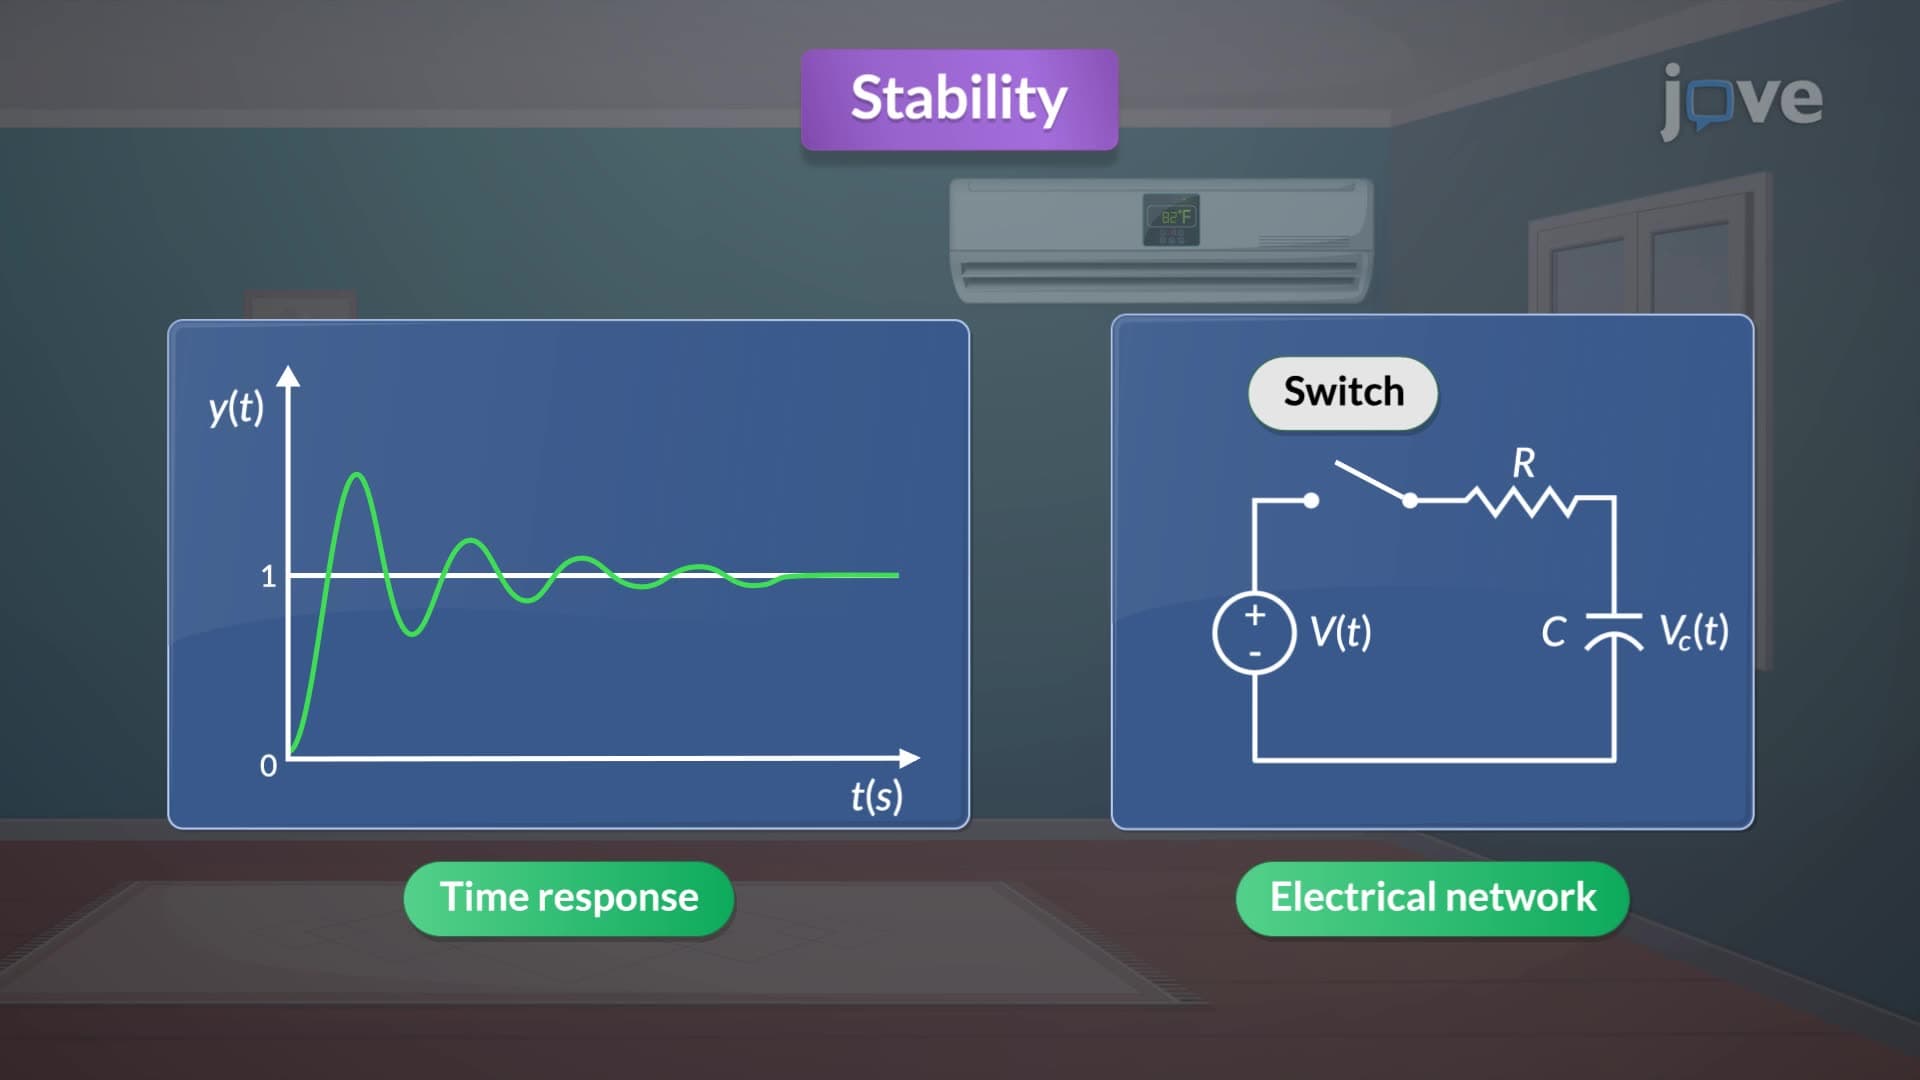
The time response of a linear time-invariant (LTI) system can be divided into transient and steady-state responses. The transient response represents the system's initial reaction to a change in input and diminishes to zero over time. In contrast, the steady-state response is the behavior that persists after the transient effects have faded.
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
155