
计算编码曲率之前的曲线结构跟踪的地理路径
Da Chen1, Jean-Marie Mirebeau2, Minglei Shu1
1Shandong Artificial Intelligence Institute, Qilu University of Technology (Shandong Academy of Sciences), Jinan 250014, China.

概括
我们开发了一种高效的方法来计算最佳曲线,使用一个增强的弹性能量模型与曲率先. 这种方法通过解决汉密尔顿 - 雅各比 - 贝尔曼方程来保证全球最佳性,以获得准确的中心线跟踪.
科学领域:
- 计算几何学计算几何学
- 图像分析 图像分析
- 微分几何学的差异几何学
背景情况:
- 尽量减少曲线能量对于形状分析和图像分割至关重要.
- 传统的弹性模型可能无法有效地捕捉复杂的几何特征.
- 纳入数据驱动的先验可以增强曲线演变模型.
研究的目的:
- 引入一种有效的计算曲线的方法,使修改后的欧勒 - 福德弹性能量最小化.
- 以用户定义的,数据驱动的曲率提升曲能量.
- 在图像数据中准确追踪曲线结构.
主要方法:
- 静态汉密尔顿-雅各比-贝尔曼 (HJB) 偏微分方程 (PDE) 的粘度解的数值计算.
- 对修改弹性模型的显式哈密尔顿推导.
- 使用自适应有限差异方案对HJB PDE进行分离.
- 通过通用快速行进方法解决HJB PDE.
- 从图像数据中实际估计曲率前值.
主要成果:
- 开发了一种高效和全球最佳的曲线计算方法.
- 拟议的方法有效地结合了曲率先验,以提高能量的最小化.
- 证明了曲线结构中心线的准确跟踪.
- 数字实验验证了该方法在合成和真实图像数据上的性能.
结论:
- 带有曲率先验的增强弹性模型为复杂的几何结构提供了优势.
- 拟议的数值方法有效计算全球最佳曲线.
- 这种方法对先进的图像分析和计算几何应用具有前途.

相关概念视频
 01:23
Curvilinear Motion: Rectangular Components
487
Curvilinear motion characterizes the movement of a particle or object along a curved path, notably evident when envisioning a car navigating a winding road. If the car starts at point A, its position vector is established within a fixed frame of reference, where the ratio of the position vector to its magnitude signifies the unit vector pointing in the position vector's direction.
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
487
 01:27
Curvilinear Motion: Normal and Tangential Components
423
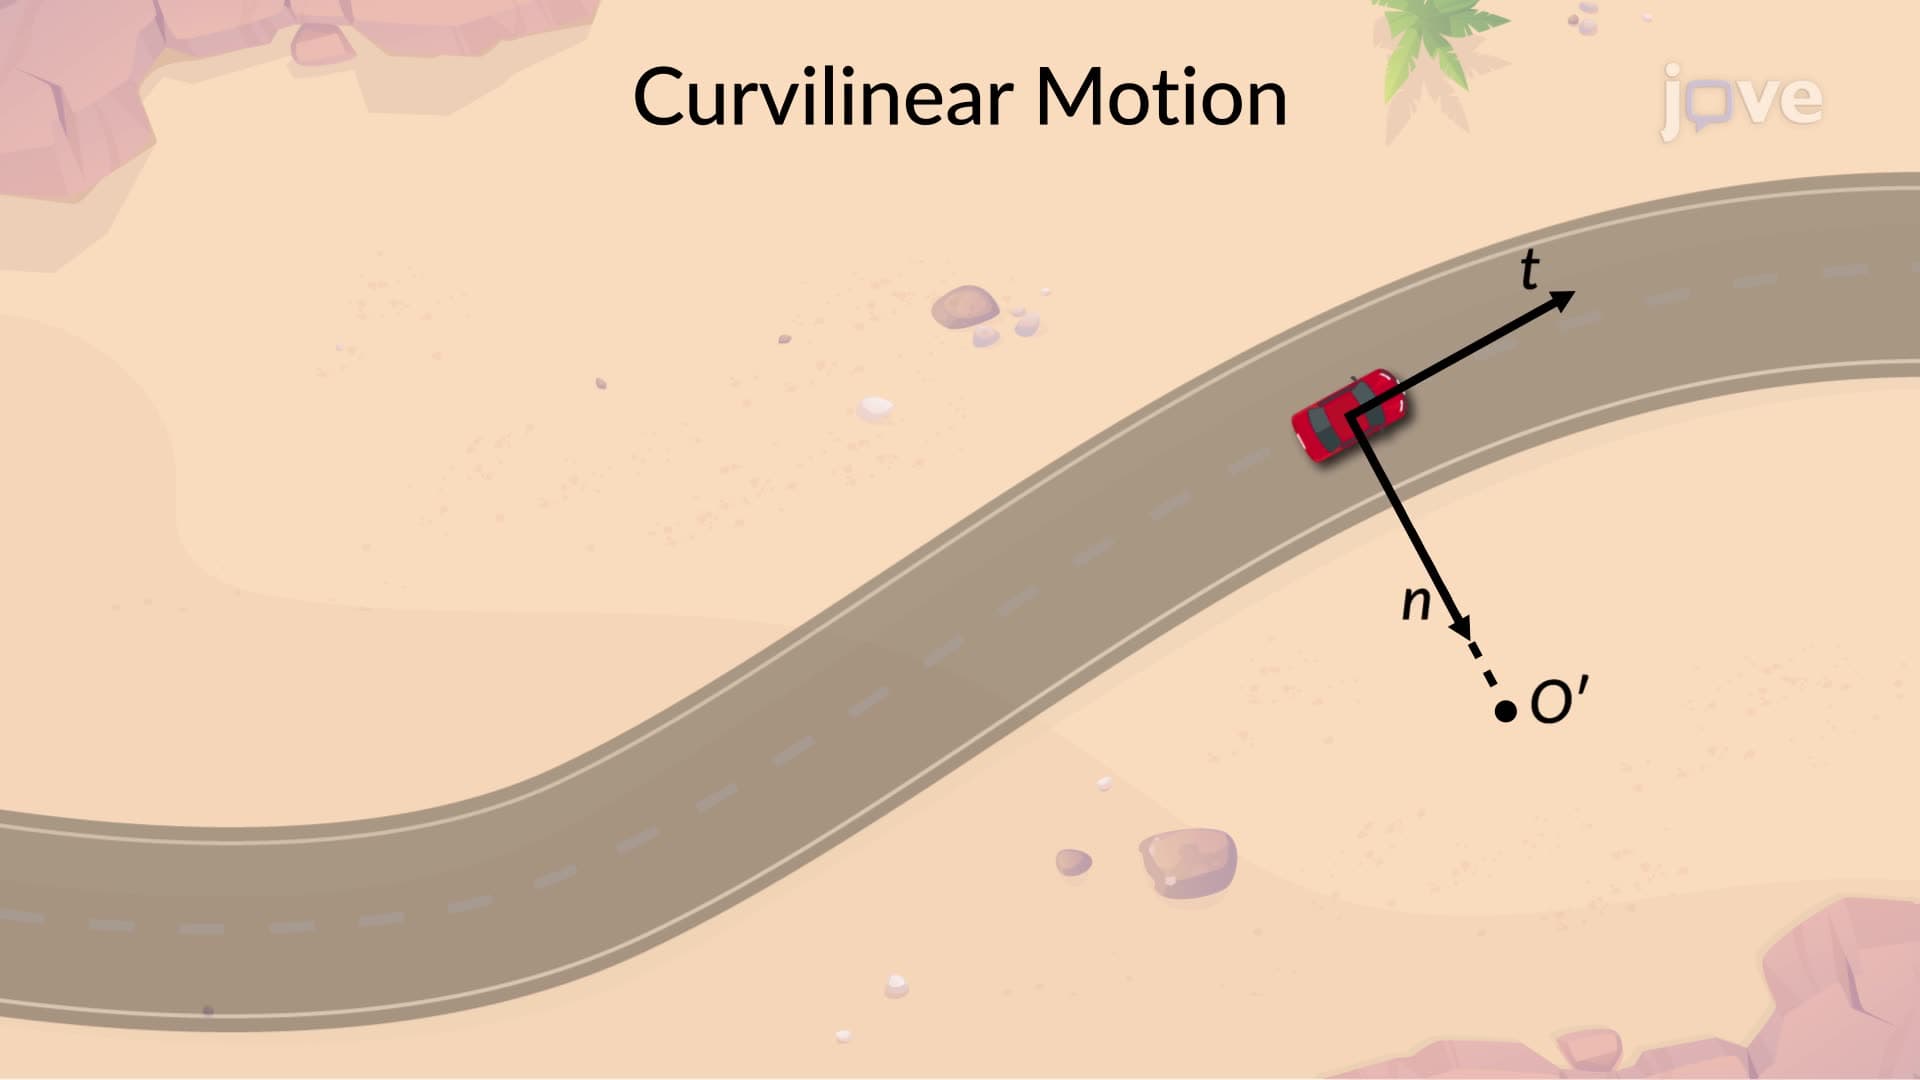
When a car traverses a curved road, its motion can be elucidated by breaking it down into tangential and normal components. The car-centric coordinates attached to the vehicle move with it.
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
423
 01:27
Curvilinear Motion: Polar Coordinates
389
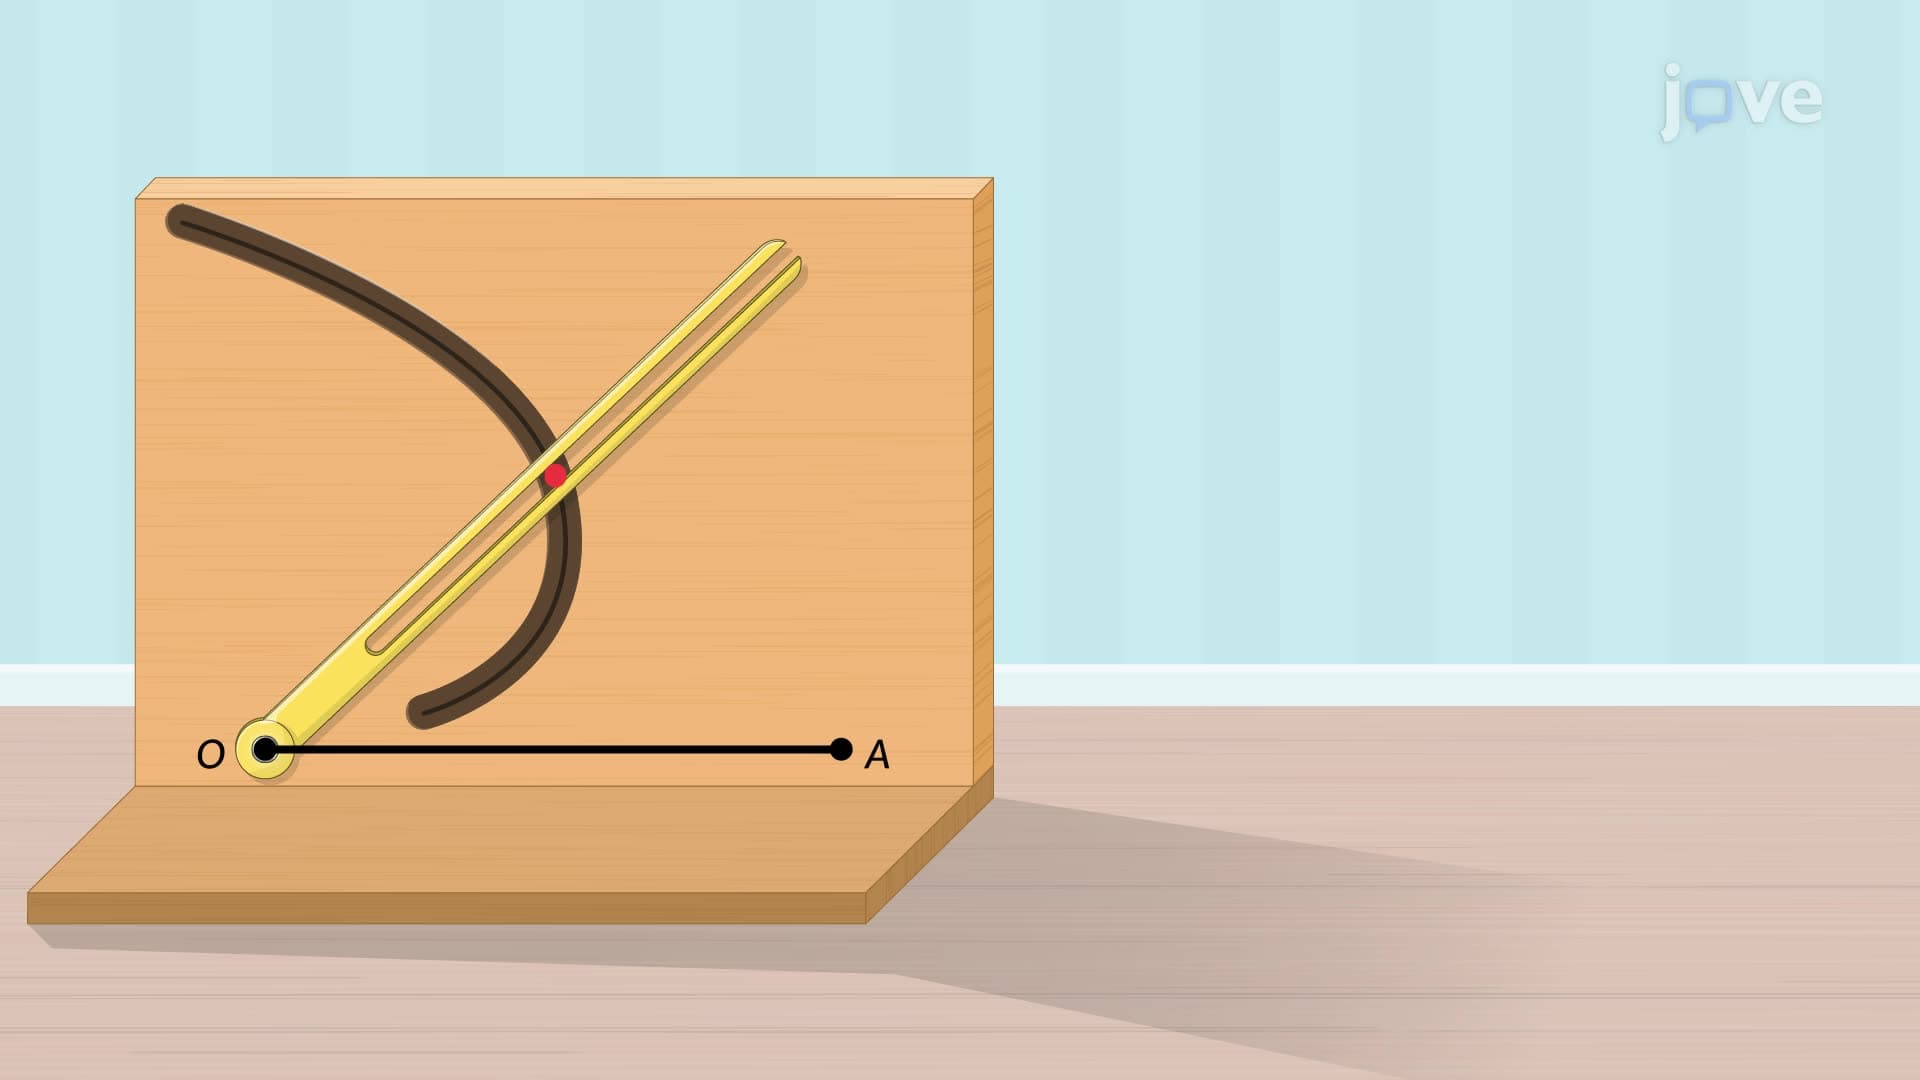
In polar coordinates, the motion of a particle follows a curvilinear path. The radial coordinate symbolized as 'r,' extends outward from a fixed origin to the particle, while the angular coordinate, 'θ,' measured in radians, represents the counterclockwise angle between a fixed reference line and the radial line connecting the origin to the particle.
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...
389
 01:19
Degree of Curvature and Radius of Curvature
80
The degree of curvature and the radius of curvature are fundamental concepts in determining the sharpness or smoothness of a curve. The degree of curvature is a measure of how steeply a curve bends and can be determined using the chord basis or the arc basis. In the chord basis method, the degree of curvature is defined as the central angle subtended by a chord of 30.48 meters, helping in the calculation of the radius of the curve. The arc basis method defines the degree of...
80
 01:26
Field Procedure for Staking Out Curves
73
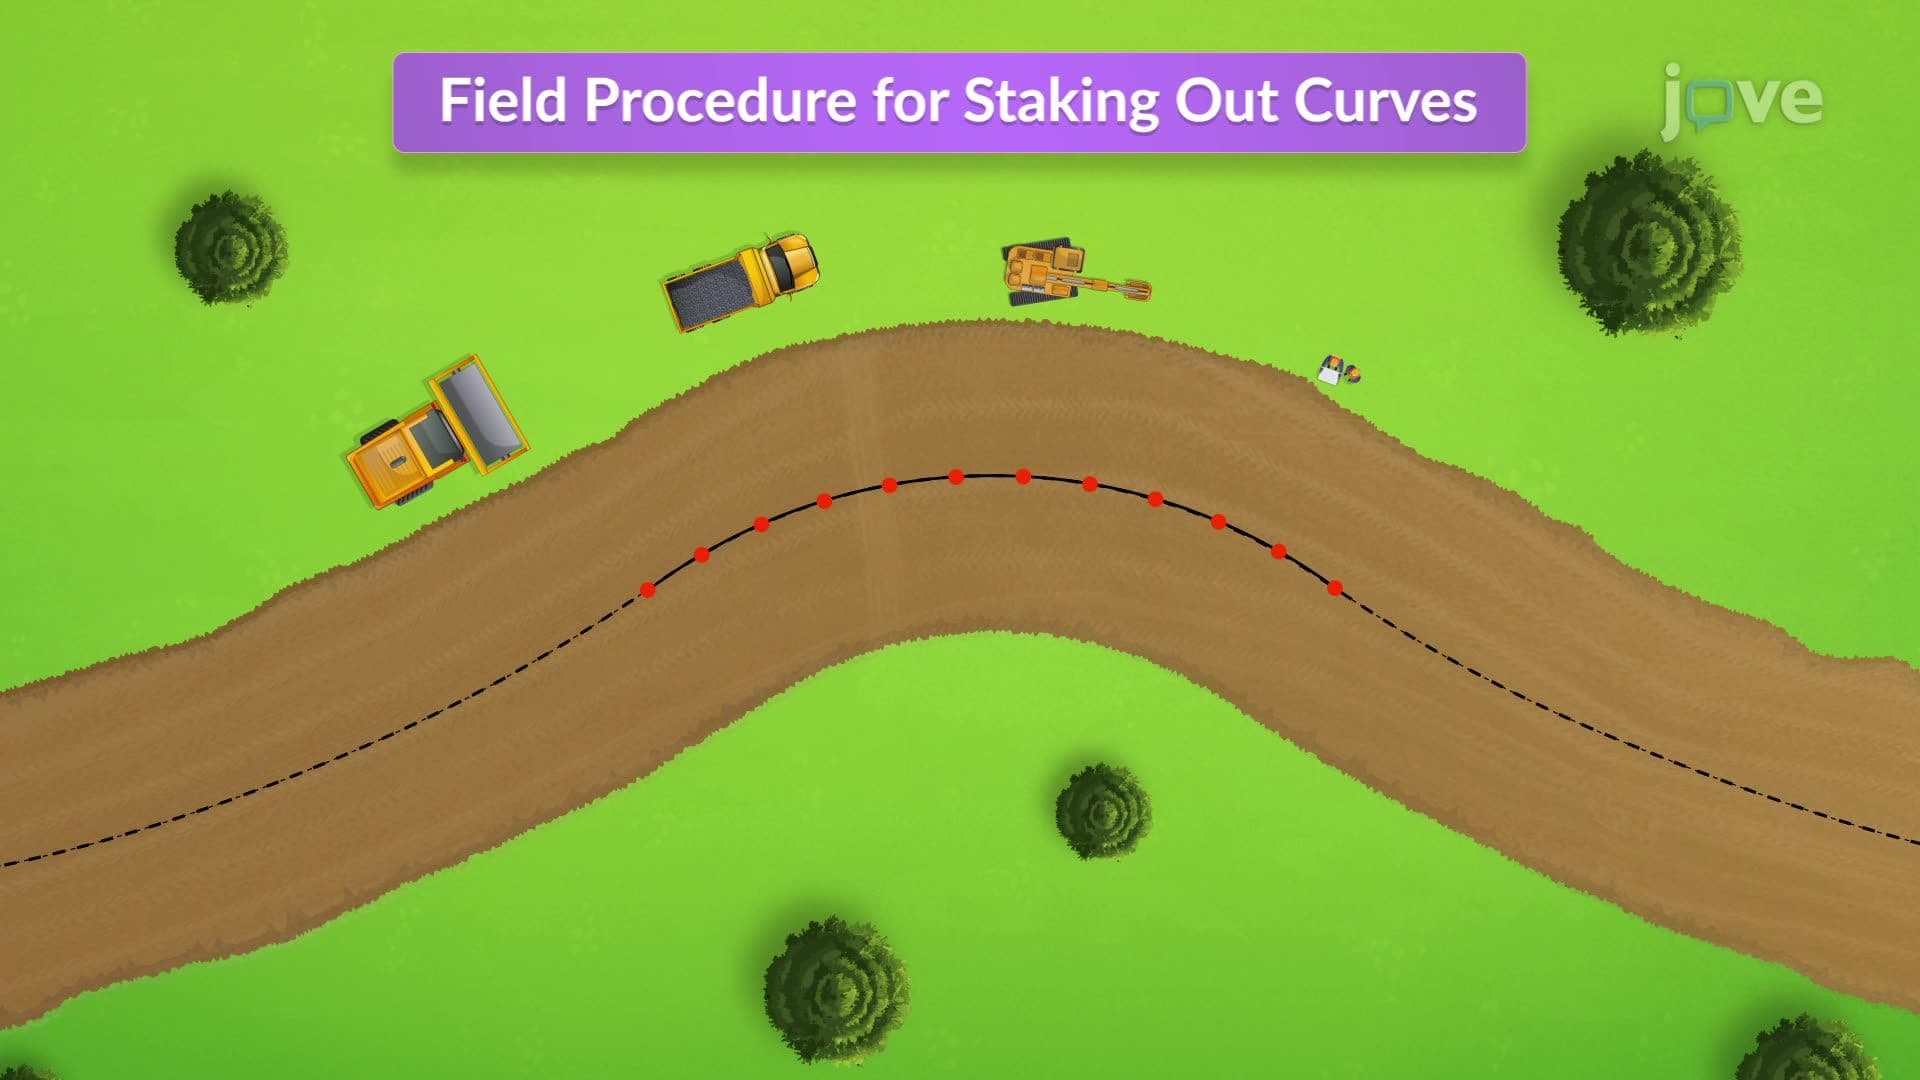
Staking out curves is an essential process in construction to ensure the accurate alignment of structures along a curved path. This task involves positioning stakes at calculated locations corresponding to the curve's design, effectively translating plans into physical markers in the field. The process begins by determining the geometric parameters of the curve, including the radius, central angle, and tangent distances. These parameters are critical for identifying key points such as the...
73
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
421
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
421