
循环MLP:一种类似于MLP的架构,用于密集的视觉预测

概括
CycleMLP是一个新的多层感知器 (MLP) 架构,旨在进行密集的视觉预测. 它有效地处理各种图像大小,并实现线性计算复杂性,优于现有模型.
科学领域:
- 计算机视觉 计算机视觉
- 人工智能的人工智能
- 机器学习 机器学习
背景情况:
- 多层感知器 (MLP) 在密集的视觉预测任务中存在局限性,原因是对图像大小和二次计算复杂性的敏感性.
- 现有的先进的MLP架构,如MLP-Mixer,ResMLP和gMLP,对于密集的预测任务通常是不可行的.
- 卷积神经网络 (CNN) 和变压器占主导地位,但可能是计算密集的.
研究的目的:
- 介绍CycleMLP,一个通用的神经骨干网络,用于密集的视觉预测任务.
- 解决现有的MLP架构在图像大小适应性和计算效率方面的局限性.
- 提供一个理论分析,比较CycleMLP与卷积和自我注意力机制.
主要方法:
- 开发了CycleMLP,一种新的MLP架构,利用本地窗口进行高效的计算.
- 在图像大小方面实现了线性计算复杂性,与传统MLP的O(N^2) 复杂性形成鲜明对比.
- 进行理论分析,以了解CycleMLP,卷积和多头自我注意力之间的关系.
主要成果:
- 循环MLP证明了适应各种空间图像大小的适应性.
- 实现了线性计算复杂性,使其适合大规模的密集预测任务.
- 使用CycleMLP构建的模型在性能上超过了最先进的MLP和变压器模型,使用的参数和FLOP更少.
- 在ADE20 K数据集上,CycleMLP-Tiny的表现比Swin-Tiny优于1.3%mIoU.
- 在ImageNet-C数据集上表现出卓越的零射击稳定性.
结论:
- CycleMLP提供了一个多功能和高效的骨干,用于密集的视觉预测任务,如对象检测,细分和人类姿势估计.
- 该架构克服了以前的MLP的局限性,使其在计算机视觉中具有更广泛的适用性.
- 循环MLP为变压器模型提供了有竞争力的替代方案,可以在降低计算成本的情况下获得优异或可比的结果.
相关概念视频
 01:07
End Point Prediction: Gran Plot
381
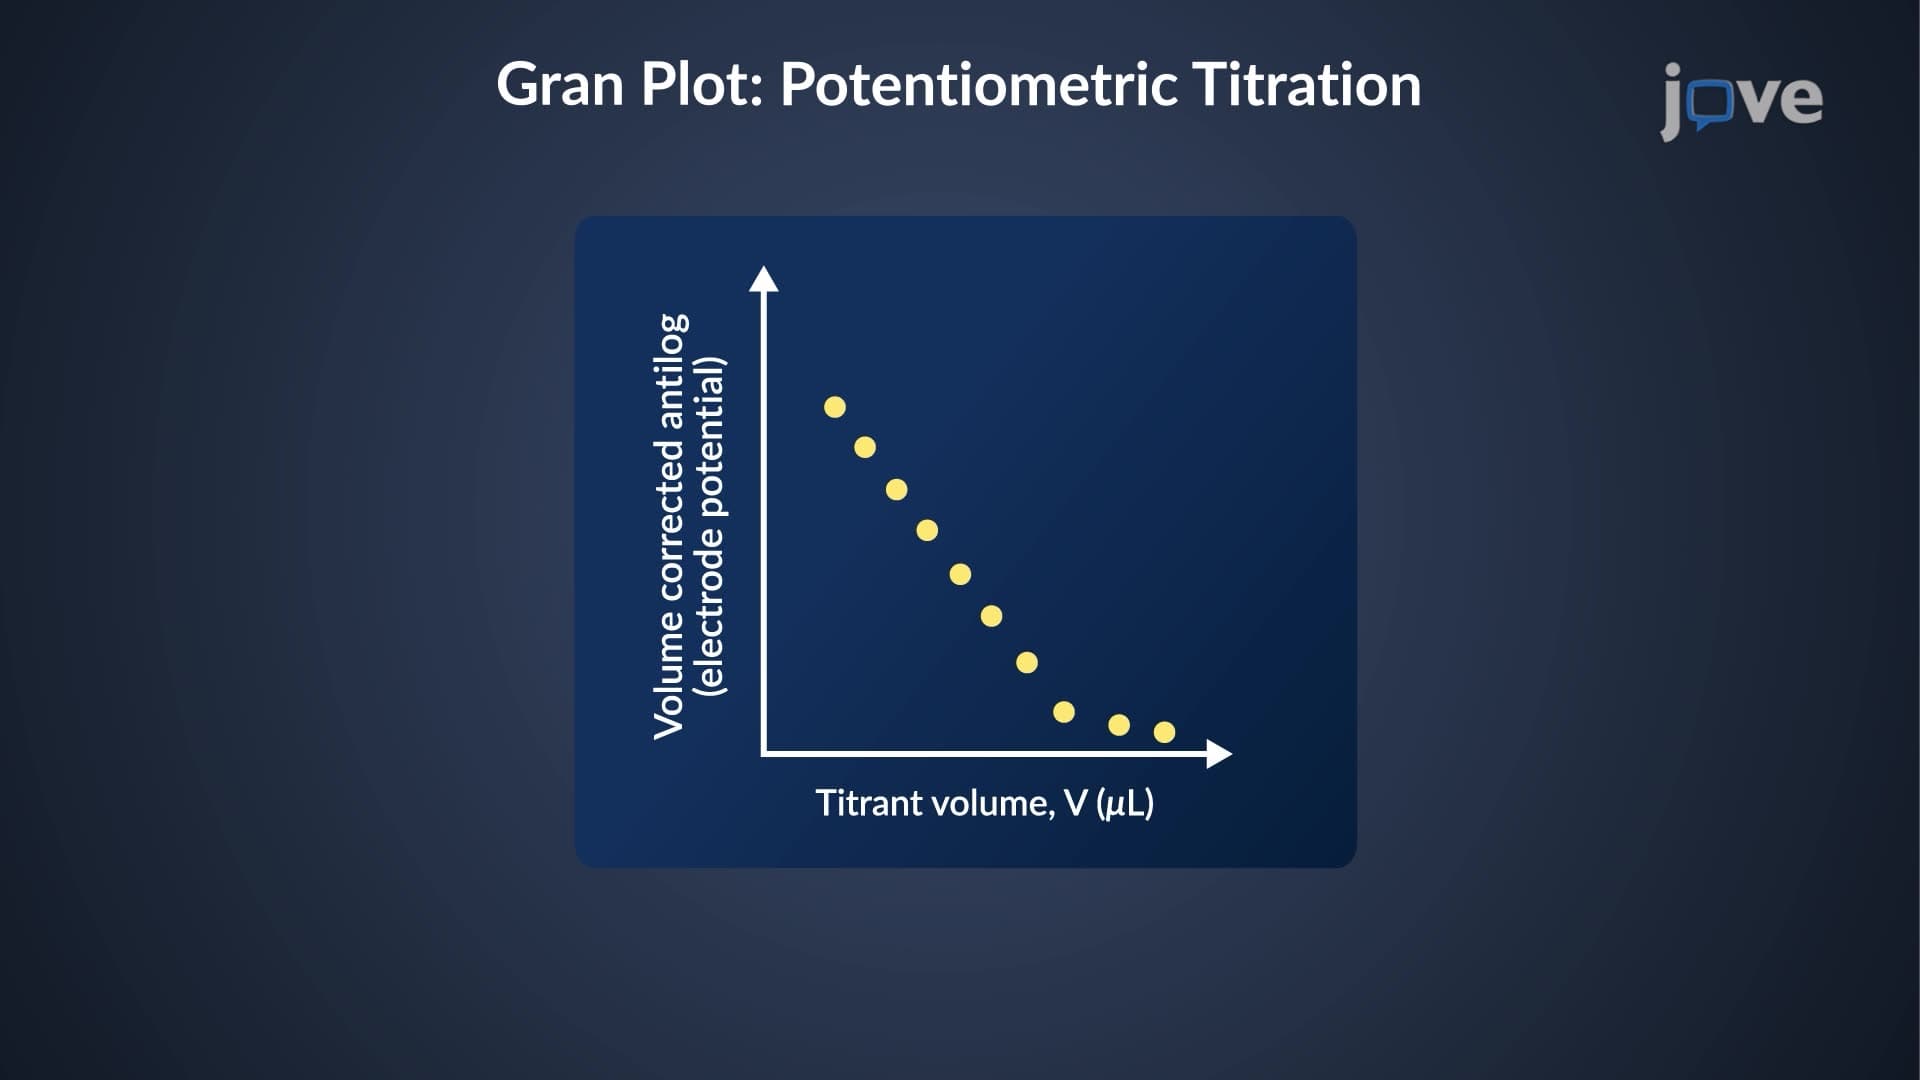
A Gran plot is used to predict the equivalence volume or endpoint of a potentiometric or acid-base titration without reaching the endpoint. Typically, titration data is collected as a function of the titrant's volume up to a point less than the equivalence volume and then transformed into a linear format. The straight line is extended to the x-axis, indicating the necessary titrant volume to achieve the equivalence point.
For potentiometric titration, the Gran plot is created by plotting...
For potentiometric titration, the Gran plot is created by plotting...
381
 01:26
Visual System
617
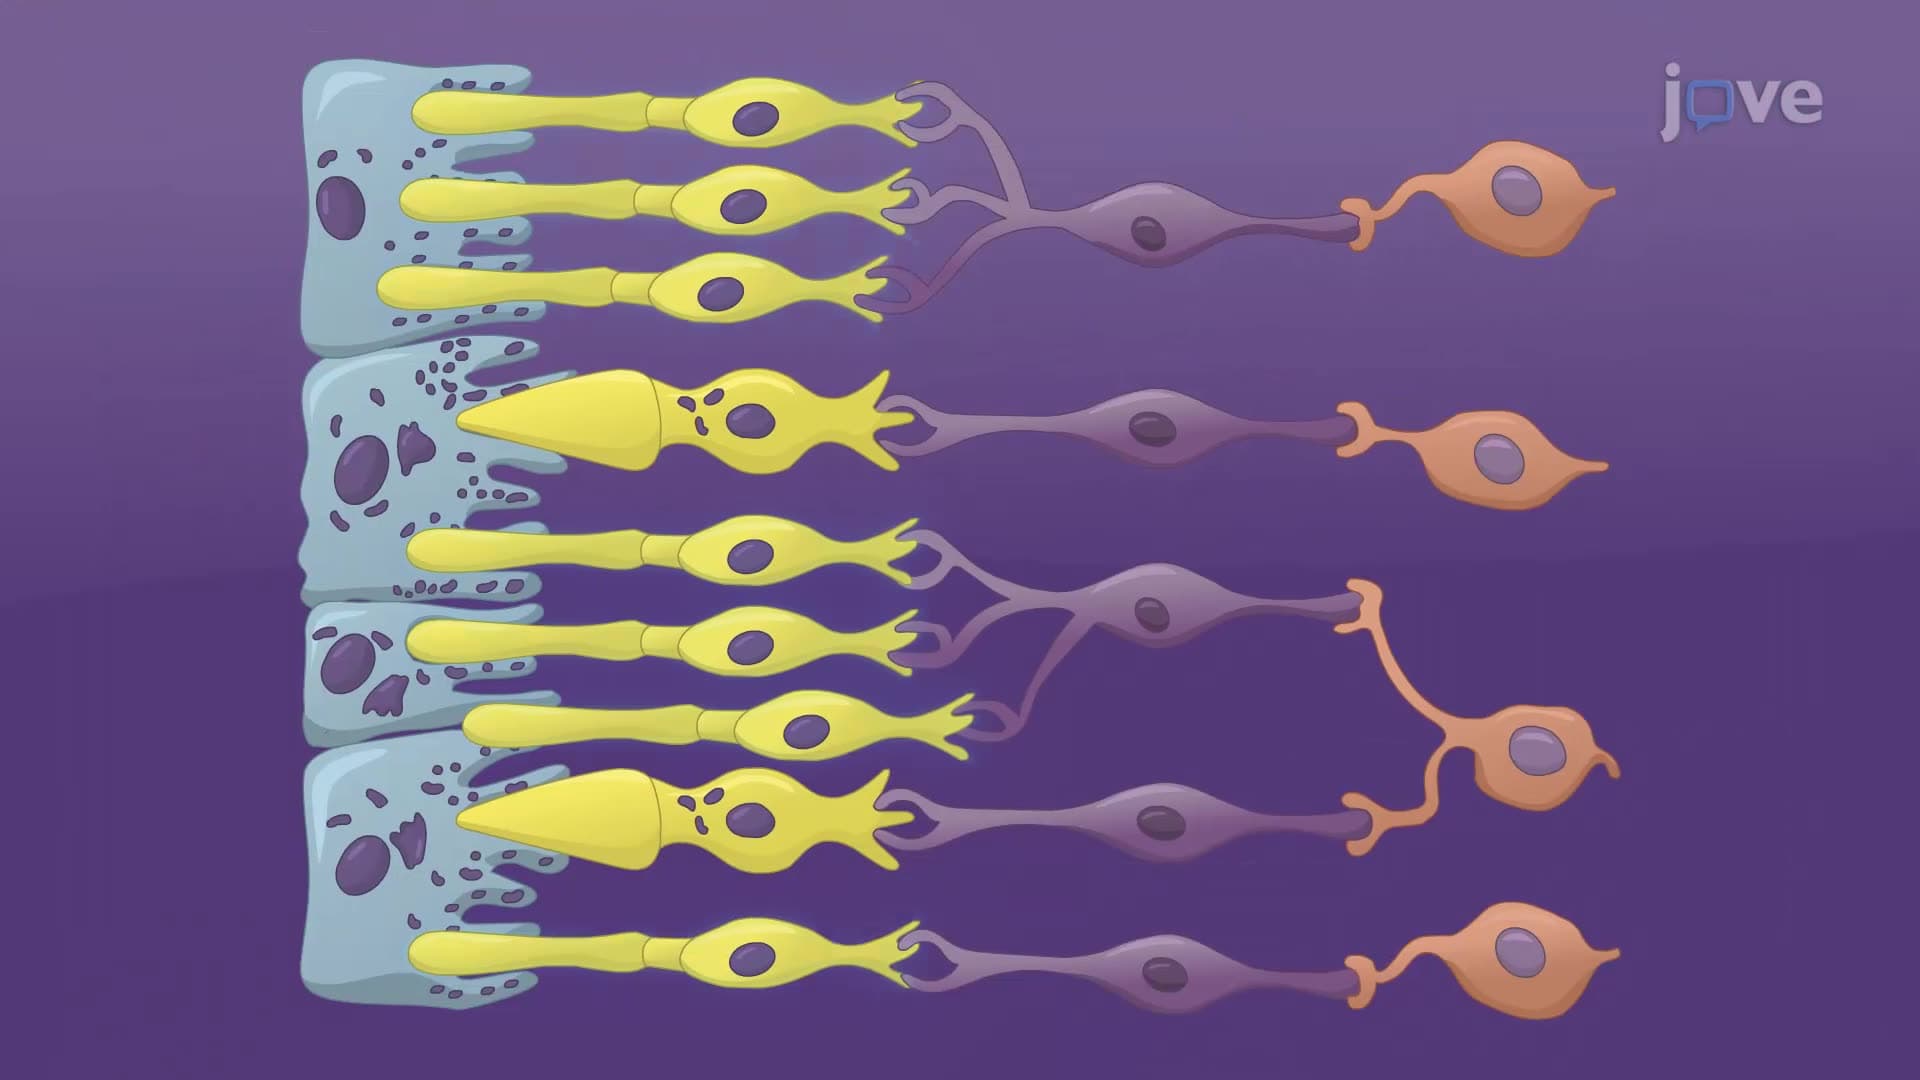
Light enters the eye through the cornea, a transparent, dome-shaped surface covering the surface of the eyeball that helps to direct and focus incoming light. This light is then channeled toward the pupil, an adjustable opening whose size is controlled by the iris. The iris, a pigmented muscle, regulates the amount of light entering the eye by contracting or dilating the pupil, thereby ensuring optimal light levels for clear vision.
Once through the pupil, the light passes through the lens, a...
Once through the pupil, the light passes through the lens, a...
617
 01:15
Depth Perception and Spatial Vision
720
Depth perception is the ability to perceive objects three-dimensionally. It relies on two types of cues: binocular and monocular. Binocular cues depend on the combination of images from both eyes and how the eyes work together. Since the eyes are in slightly different positions, each eye captures a slightly different image. This disparity between images, known as binocular disparity, helps the brain interpret depth. When the brain compares these images, it determines the distance to an object.
720
 01:25
Neural Circuits
1.3K
Neural circuits and neuronal pools are two of the main structures found in the nervous system. Neural circuits are networks of neurons that work together to carry out a specific task or process. They consist of interconnected neurons and glial cells, which provide structural and metabolic support.
Neuronal pools are collections of nerve cells with similar functions and interact through chemical and electrical signals. These pools include both interneurons (the central neural circuit nodes that...
Neuronal pools are collections of nerve cells with similar functions and interact through chemical and electrical signals. These pools include both interneurons (the central neural circuit nodes that...
1.3K