基于多维泰勒网络的强大的最佳跟踪控制,用于MIMO非线性离散时间系统

Qiming Sun1, Ying Yan2, Yihan Xu3
1College of Information Science and Technology, Nanjing Forestry University, Nanjing, 210037, China.
ISA transactions
|August 9, 2023

概括
本研究介绍了针对面临不确定性和非线性问题的非线性系统的强大最佳跟踪控制策略. 该方法使用自适应的多维泰勒网络 (MTN) 来有效地管理系统的不确定性并提高控制性能.
科学领域:
- 控制系统工程 控制系统工程
- 非线性系统动力学 非线性系统动力学
- 适应性控制理论 适应性控制理论
背景情况:
- 实用工程系统通常由于模型不确定性,速度不可用,输入非线性和多输入合而遭受不满意的控制.
- 现有的控制策略很难有效地应对这些在离散时间系统中的复杂挑战.
研究的目的:
- 为具有未知不确定性的非线性多输入多输出离散时间系统提出一个强大的最佳跟踪控制策略.
- 通过开发适应性控制方法,最大限度地降低成本功能并稳定闭环系统.
主要方法:
- 使用多维泰勒网络 (MTN),包括一个演员MTN和一个批评MTN,用于自适应控制.
- 使用MTN的近似属性通过动作MTN.生成最佳控制信号.
- 使用批评者MTN近似计算成本函数,由于准确成本函数无法访问,因此在线调整.
主要成果:
- 开发了一种新的成本函数,以减少控制过程中的计算负载.
- 集成的自适应式批评设计原则,以有效处理系统的不确定性.
- 模拟结果表明,拟议的强有力的最佳跟踪控制策略具有显著的有效性.
结论:
- 拟议的强大的最佳跟踪控制策略成功地解决了离散时间系统中的不确定性和非线性.
- 使用多维泰勒网络的自适应方法为复杂的系统控制挑战提供了有希望的解决方案.
- 该战略提供了一种稳定有效的方法,用于在实际工程应用中实现最佳的跟踪性能.

相关概念视频
 01:26
Linear Approximation in Frequency Domain
110
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
110
 01:23
Linear time-invariant Systems
289
A system is linear if it displays the characteristics of homogeneity and additivity, together termed the superposition property. This principle is fundamental in all linear systems. Linear time-invariant (LTI) systems include systems with linear elements and constant parameters.
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
289
 01:21
Transfer Function in Control Systems
565
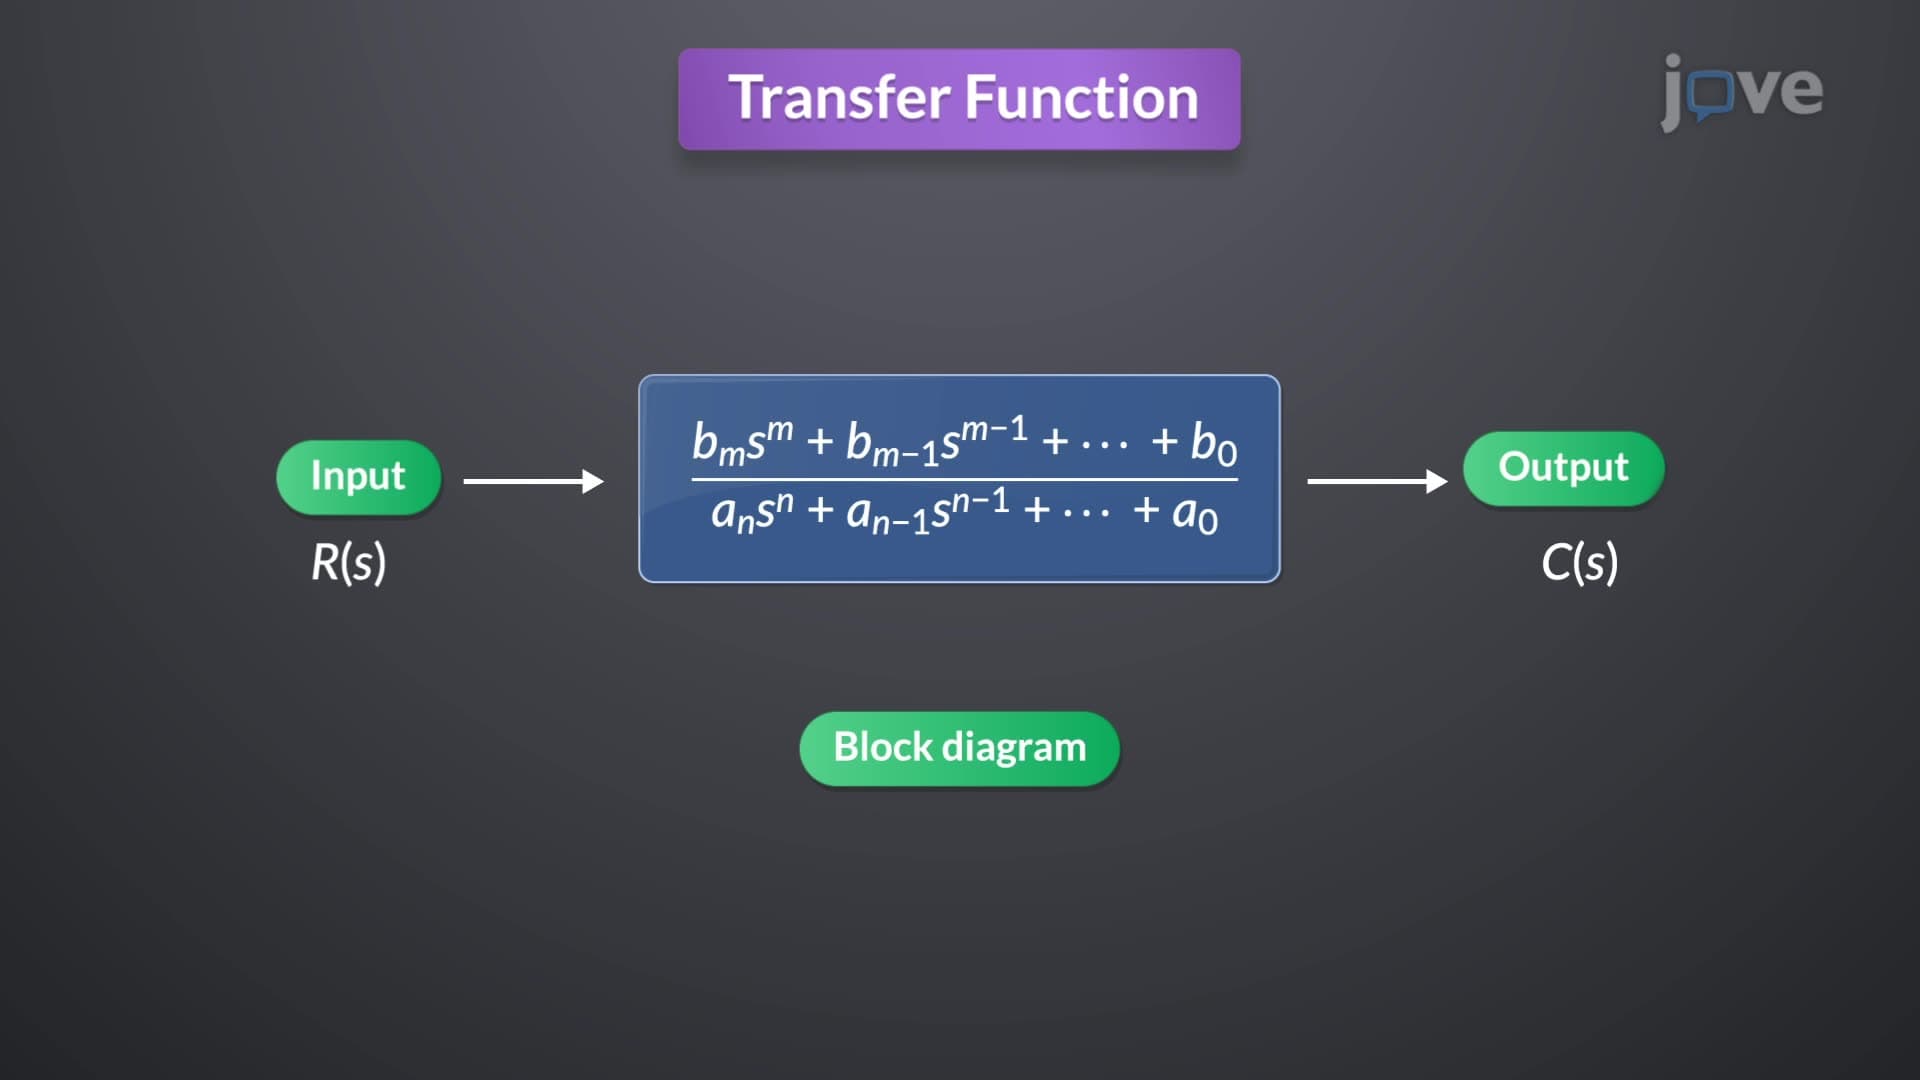
The transfer function is a fundamental concept in the analysis and design of linear time-invariant (LTI) systems. It offers a concise way to understand how a system responds to different inputs in the frequency domain. It serves as a bridge between the time-domain differential equations that describe system dynamics and the frequency-domain representation that facilitates easier manipulation and analysis.
To derive the transfer function, consider a general nth-order linear time-invariant...
To derive the transfer function, consider a general nth-order linear time-invariant...
565
 01:26
Feedback control systems
344
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
344
 01:07
Time-Domain Interpretation of PD Control
141
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
141
 01:24
BIBO stability of continuous and discrete -time systems
437
System stability is a fundamental concept in signal processing, often assessed using convolution. For a system to be considered bounded-input bounded-output (BIBO) stable, any bounded input signal must produce a bounded output signal. A bounded input signal is one where the modulus does not exceed a certain constant at any point in time.
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
437