相关实验视频
Updated: Jul 19, 2025
16:14
Trajectory Data Analyses for Pedestrian Space-time Activity Study
Published on: February 25, 2013
13.6K
使用增强组合变形卡尔曼波器进行行人定位
1Department of Software, Sangmyung University, Cheonan-si 31066, Republic of Korea.
Sensors (Basel, Switzerland)
|August 12, 2023

概括
这项研究介绍了QETKF,这是一个改进的卡尔曼波器,用于室内定位,使用行人死亡计算 (PDR) 和接收信号强度 (RSS) 指纹. 通过计算模型错误,QETKF提高了准确性,超过了现有的方法.
科学领域:
- 室内定位系统 室内定位系统
- 国家估计.
- 传感器融合式传感器
背景情况:
- 全球定位系统 (GPS) 在室内不可用,需要使用替代定位方法.
- 现有的室内定位依赖于来自惯性测量单元 (IMU) 的传感器数据和无线信号 (例如,PDR,RSS指纹).
- 贝叶斯波器通常用于融合来自PDR和RSS指纹的杂位置数据.
研究的目的:
- 提出和评估一种新的增强状态估计方法,QETKF,用于室内行人定位.
- 通过纳入模型错误考虑来解决集成转换卡尔曼波器 (ETKF) 的局限性.
- 调查QETKF的可行性,以使用PDR和RSS指纹进行准确的行人位置估计.
主要方法:
- 开发了QETKF,一种增强的ETKF变体,作为室内定位的贝叶斯波器.
- 从PDR与RSS指纹测量使用集体转换的融合预测位置.
- 在状态预测模型中包含模型错误,与标准ETKF不同.
主要成果:
- 与ETKF和其他集成式卡尔曼过器 (EBKF) 相比,QETKF显示了更准确的定位结果.
- 拟议的QETKF通过考虑模型错误,有效地避免系统地低估错误协变率.
- 在基于智能手机的室内定位系统上进行的实验验证了QETKF的性能.
结论:
- QETKF显示了改善室内行人定位准确性的巨大潜力.
- 使用QETKF精确的错误共变率估计导致了优越的位置估计性能.
- 该方法适用于基于智能手机的室内定位系统,利用PDR和RSS数据.
相关概念视频
 01:29
Position Vectors
946
A position vector is a fundamental concept in mathematics that helps determine the position of one point with respect to another point in space. It is a vector that describes the direction and distance between two points. Position vectors are highly useful in the field of math and science, as they help represent spatial relationships and make calculations easier.
For instance, we want to locate a point P(x, y, z) relative to the origin of coordinates O. In that case, we can define a position...
For instance, we want to locate a point P(x, y, z) relative to the origin of coordinates O. In that case, we can define a position...
946
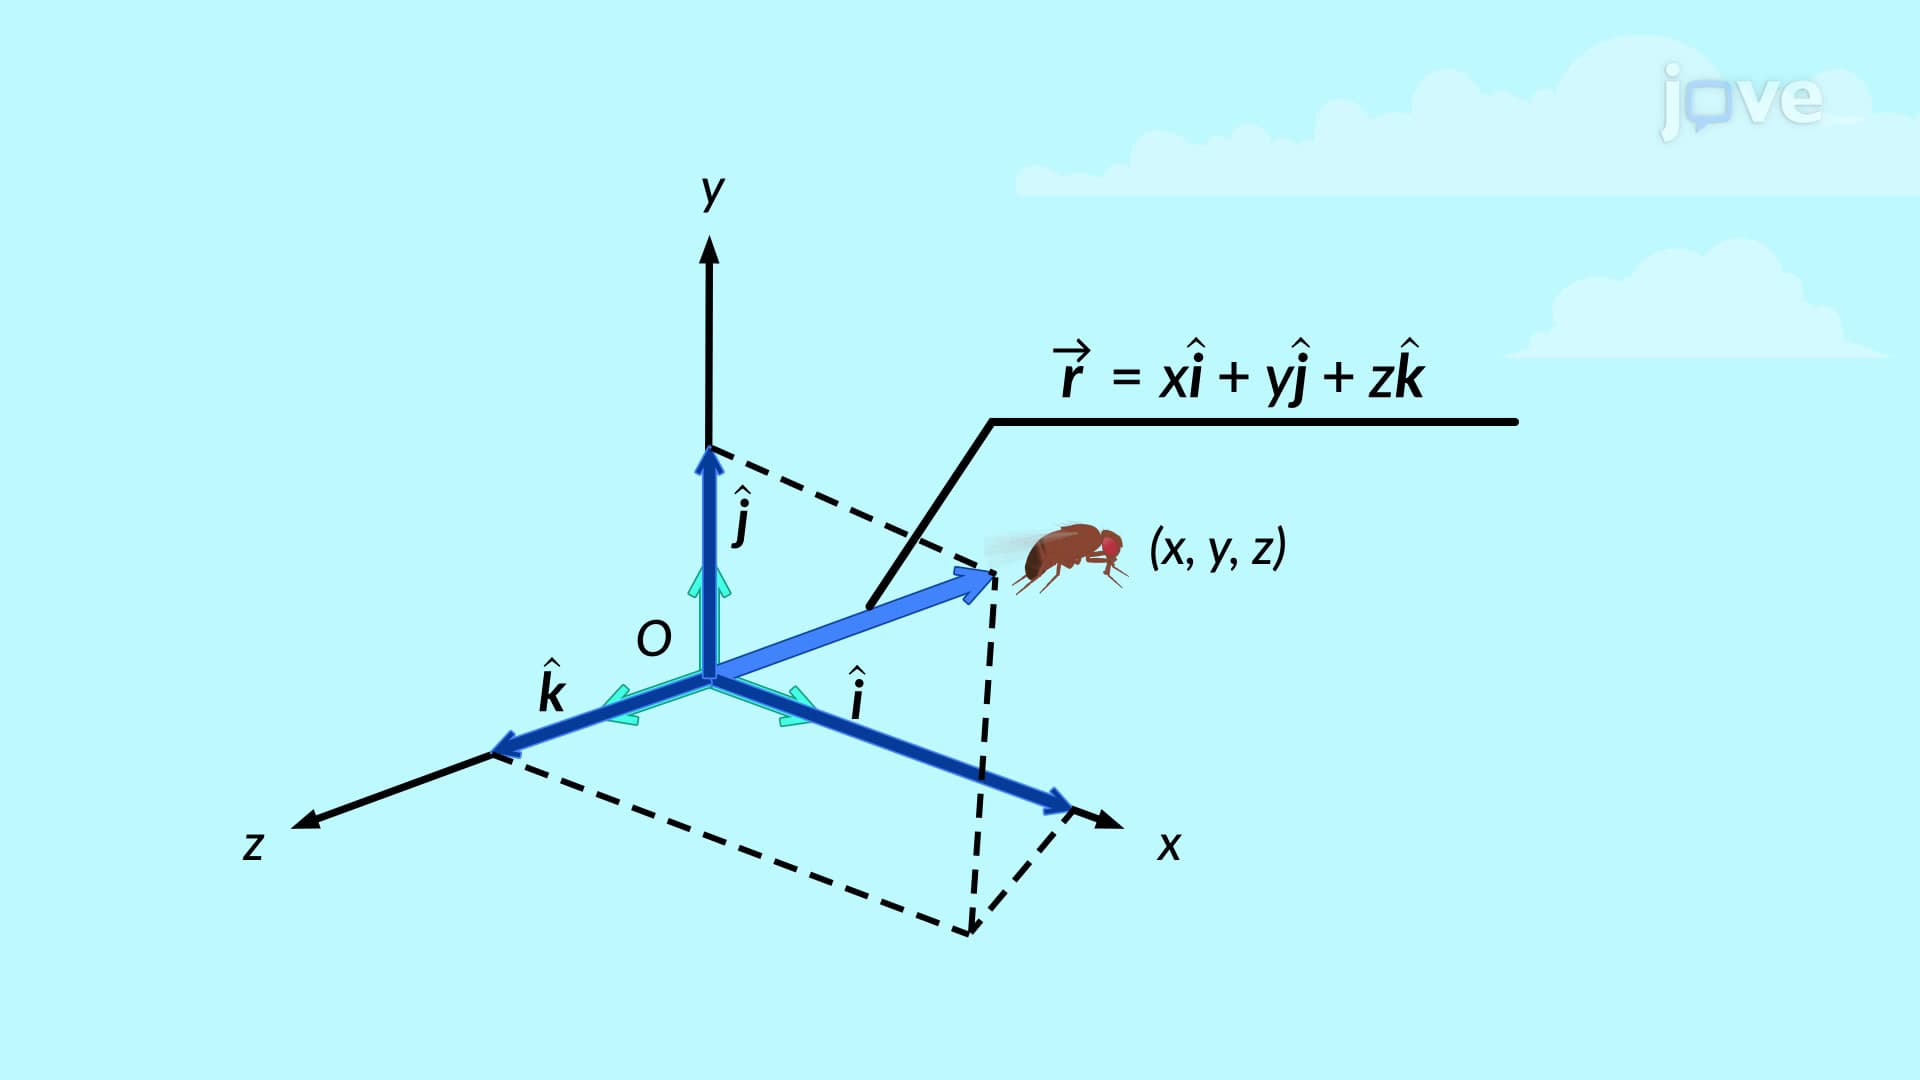 01:00
Position and Displacement Vectors
9.6K
To describe the motion of an object, one should first be able to describe its position (where it is at any particular time). More precisely, the position needs to be specified relative to a convenient frame of reference. A frame of reference is an arbitrary set of axes from which the position and motion of an object are described. Earth is often used as a frame of reference to describe the position of an object in relation to stationary objects on Earth.
Further, several important kinds of...
Further, several important kinds of...
9.6K