

对于用于轨迹跟踪的软可伸缩气动执行器的反向动力学的几何方法
Mahboubeh Keyvanara1, Arman Goshtasbi2, Irene A Kuling1
1Reshape Lab, Dynamics and Control Group, Department of Mechanical Engineering, Eindhoven University of Technology, 5600 MB Eindhoven, The Netherlands.
Sensors (Basel, Switzerland)
|August 12, 2023

概括
本研究介绍了一种简化的几何模型,用于控制多段软机器人,减少复杂性,以便更好地跟踪轨迹. 新模型为软机器人应用提供了高精度和较低的计算成本.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 控制系统 控制系统
- 材料科学 材料科学 材料科学
背景情况:
- 软机器人表现出超冗余性,由于非线性连续动力学和复杂的材料特性,造成了重大建模挑战.
- 现有的模型经常与软机器人系统的复杂性作斗争,导致高计算成本和精度降低.
研究的目的:
- 开发一个简化的几何逆动力学 (IK) 模型,用于跟踪多段可扩展软机器人的轨迹.
- 通过近似具有刚性链接和接头的细分来降低软机器人建模的复杂性.
主要方法:
- 软执行器段的几何近似使用一个刚性链接模型与旋转和镜连接.
- 优化方法的应用,以确定所需的终端效应器位置的配置变量.
- 用机器人冗余来执行次要任务,例如控制尖角.
主要成果:
- 拟议的几何IK模型在模拟和基准中显示了较低的计算成本和更高的准确性,与现有模型相比.
- 该模型在3D打印软机器人操纵器上进行了成功的实验验证,显示出高精度的路径跟踪.
- 该方法在2D和3D多段软机器人中都被证明是有效的.
结论:
- 几何IK模型为控制多段可扩展软机器人提供了一种有效和计算效率高的方法.
- 这种简化的建模技术提高了轨迹跟踪的准确性,并允许利用机器人冗余.
- 经过验证的模型为控制3D打印软机器人操纵器提供了实用解决方案.
相关概念视频
 01:15
Kinematic Equations: Problem Solving
12.5K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
12.5K
 01:18
Kinematic Equations - III
7.7K
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
7.7K
 01:17
Kinematic Equations - II
9.6K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
9.6K
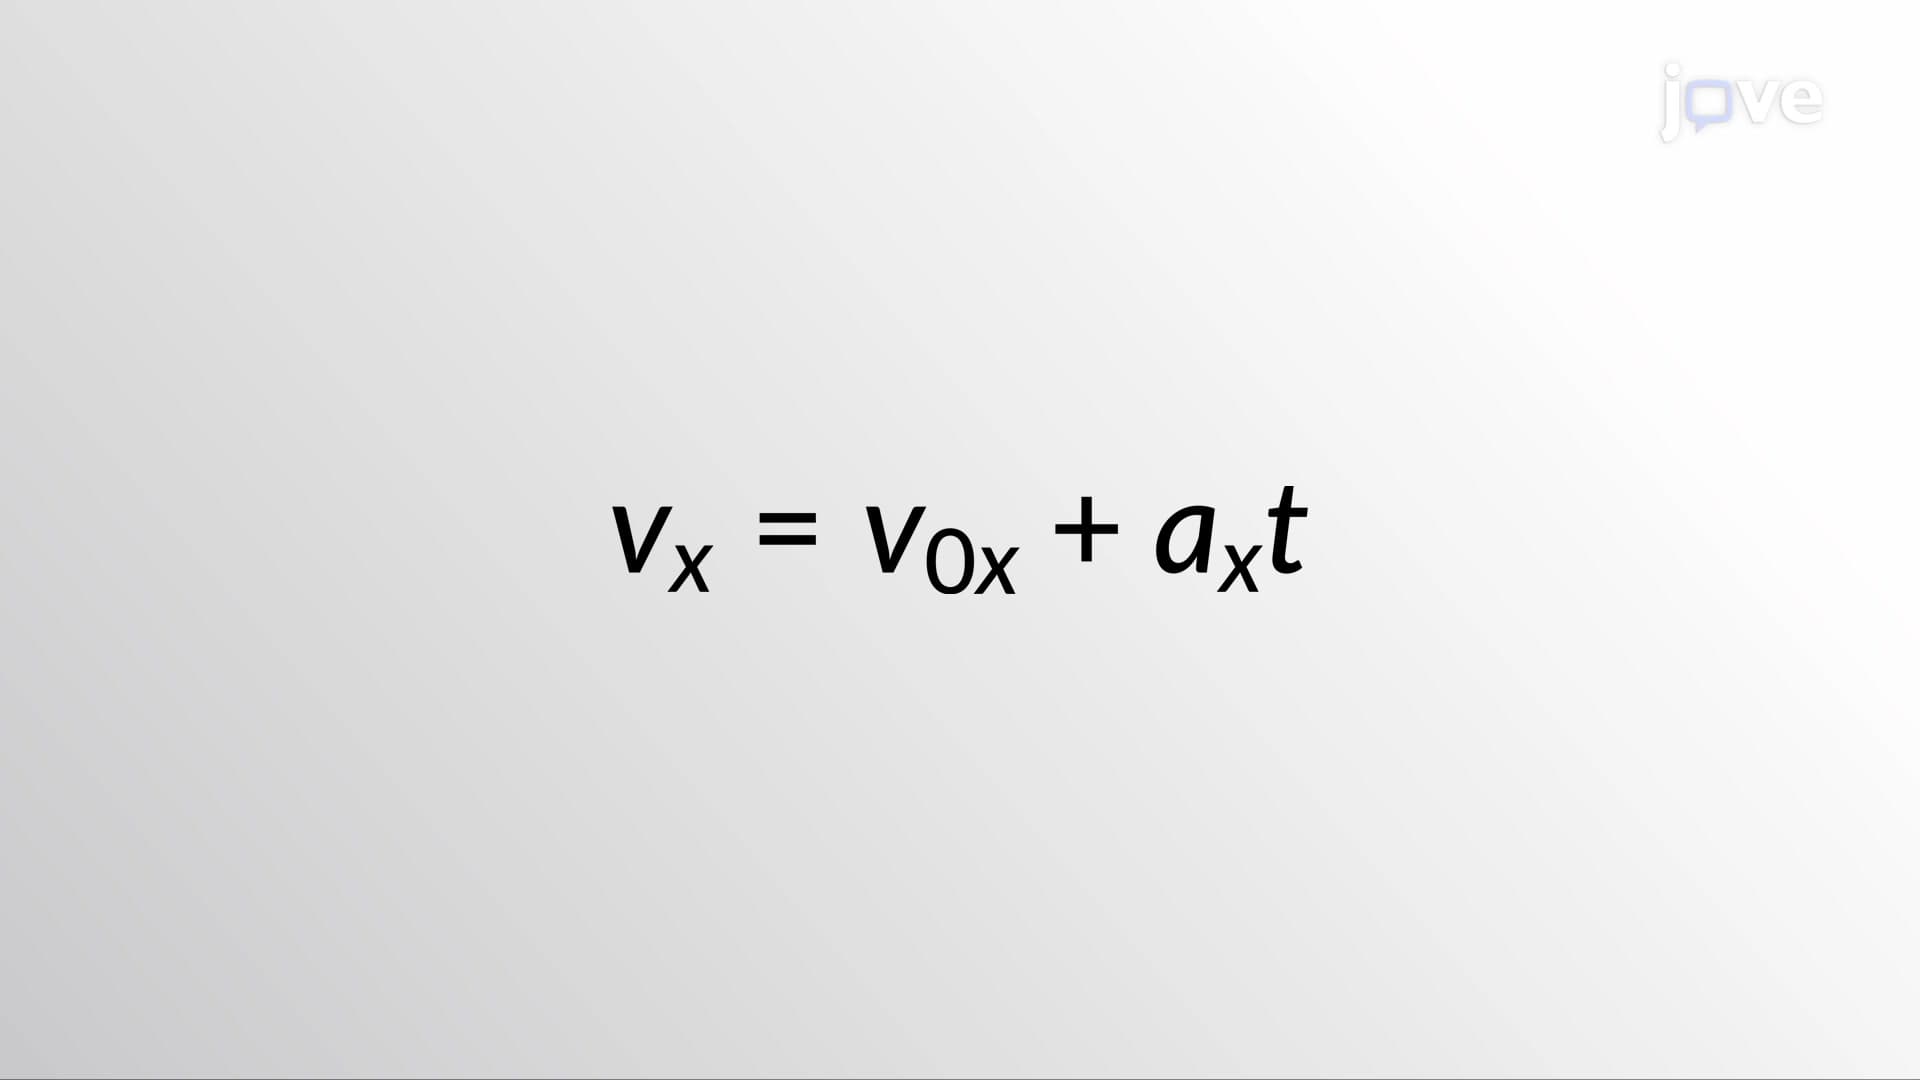 01:26
Kinematic Equations - I
10.7K
When an object moves with constant acceleration, the velocity of the object changes at a constant rate throughout the motion. The kinematic equations of motions are derived for such cases where the acceleration of the object is constant. The first kinematic equation gives an insight into the relationship between velocity, acceleration, and time. We can see, for example:
10.7K
 01:30
Kinematic Equations for Rotation
349
In mechanics, when one observes a rigid body in rotational motion with constant angular acceleration, it is possible to establish equations for its rotational kinematics. This process resembles how linear kinematics are dealt with in simpler motion studies.
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
349
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
421
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
421