
基于视觉的拼图用机器人手臂解决拼图
Chang-Hsian Ma1, Chien-Liang Lu1, Huang-Chia Shih1
1Department of Electrical Engineering, Yuan Ze University, Taoyuan 32003, Taiwan.
Sensors (Basel, Switzerland)
|August 12, 2023

概括
本研究介绍了两种新的算法,用于使用颜色兼容性进行自动拼图重建. 这些方法取得了很高的成功率,在复杂的图像上超过了人类的准确性.
科学领域:
- 计算机视觉 计算机视觉
- 机器人技术 机器人技术 机器人技术
- 人工智能的人工智能
背景情况:
- 拼图重建是一个复杂的计算挑战.
- 需要自动化解决方案,以提高对象组装任务的效率和准确性.
- 现有的方法可能难以处理复杂的纹理,缺乏现实世界的机器人集成.
研究的目的:
- 开发和评估两个用于自动拼图重建的新算法.
- 在现实的应用场景中评估这些算法的性能,有或没有原始图像.
- 为了使机器人操纵能够准确地放置拼图片.
主要方法:
- 提出了两种算法,利用颜色兼容功能来匹配拼图片.
- 计算转换矩阵以确定精确的零件位置.
- 集成的位置信息与机器人手臂用于自动装配.
主要成果:
- 在35块和70块的拼图上测试的算法.
- 在测试中获得了87.1%的平均成功率.
- 在复杂的纹理图像上,与人类视觉系统相比,证明了更高的准确性.
结论:
- 开发的算法为自动拼图重建提供了有效的解决方案.
- 颜色兼容性是解决复杂组装任务的强大功能.
- 该系统显示了机器人操纵和计算机视觉应用中提高准确性和效率的潜力.
更多相关视频


相关概念视频
 01:30
Three-Dimensional Force System:Problem Solving
693
A three-dimensional force system refers to a scenario in which three forces act simultaneously in three different directions. This type of problem is commonly encountered in physics and engineering, where it is necessary to calculate the resultant force on the system, which can then be used to predict or analyze the behavior of the object or structure under consideration.
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
693
 01:30
Machines: Problem Solving II
335
Machines are complex structures consisting of movable, pin-connected multi-force members that work together to transmit forces. Consider a lifting tong carrying a 100 kg load. It comprises movable sections DAF and CBG linked together with member AB.
335
 01:22
Machines: Problem Solving I
355
A toggle clamp is a mechanical device commonly used for holding and clamping objects in various applications, such as woodworking, metalworking, and assembly operations. Consider a toggle clamp subjected to a force of 200 N at the handle. The vertical clamping force can be calculated, provided the dimensions of the toggle clamp are known.
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
355
 01:29
Two-Dimensional Force System: Problem Solving
615
Solving problems related to two-dimensional force systems is an essential aspect of mechanics and engineering. By applying the principles of vector analysis and force equilibrium, one can determine the effect of multiple forces acting on an object in a two-dimensional space.
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
615
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
421
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
421
 01:03
Centroid of a Body: Problem Solving
1.2K
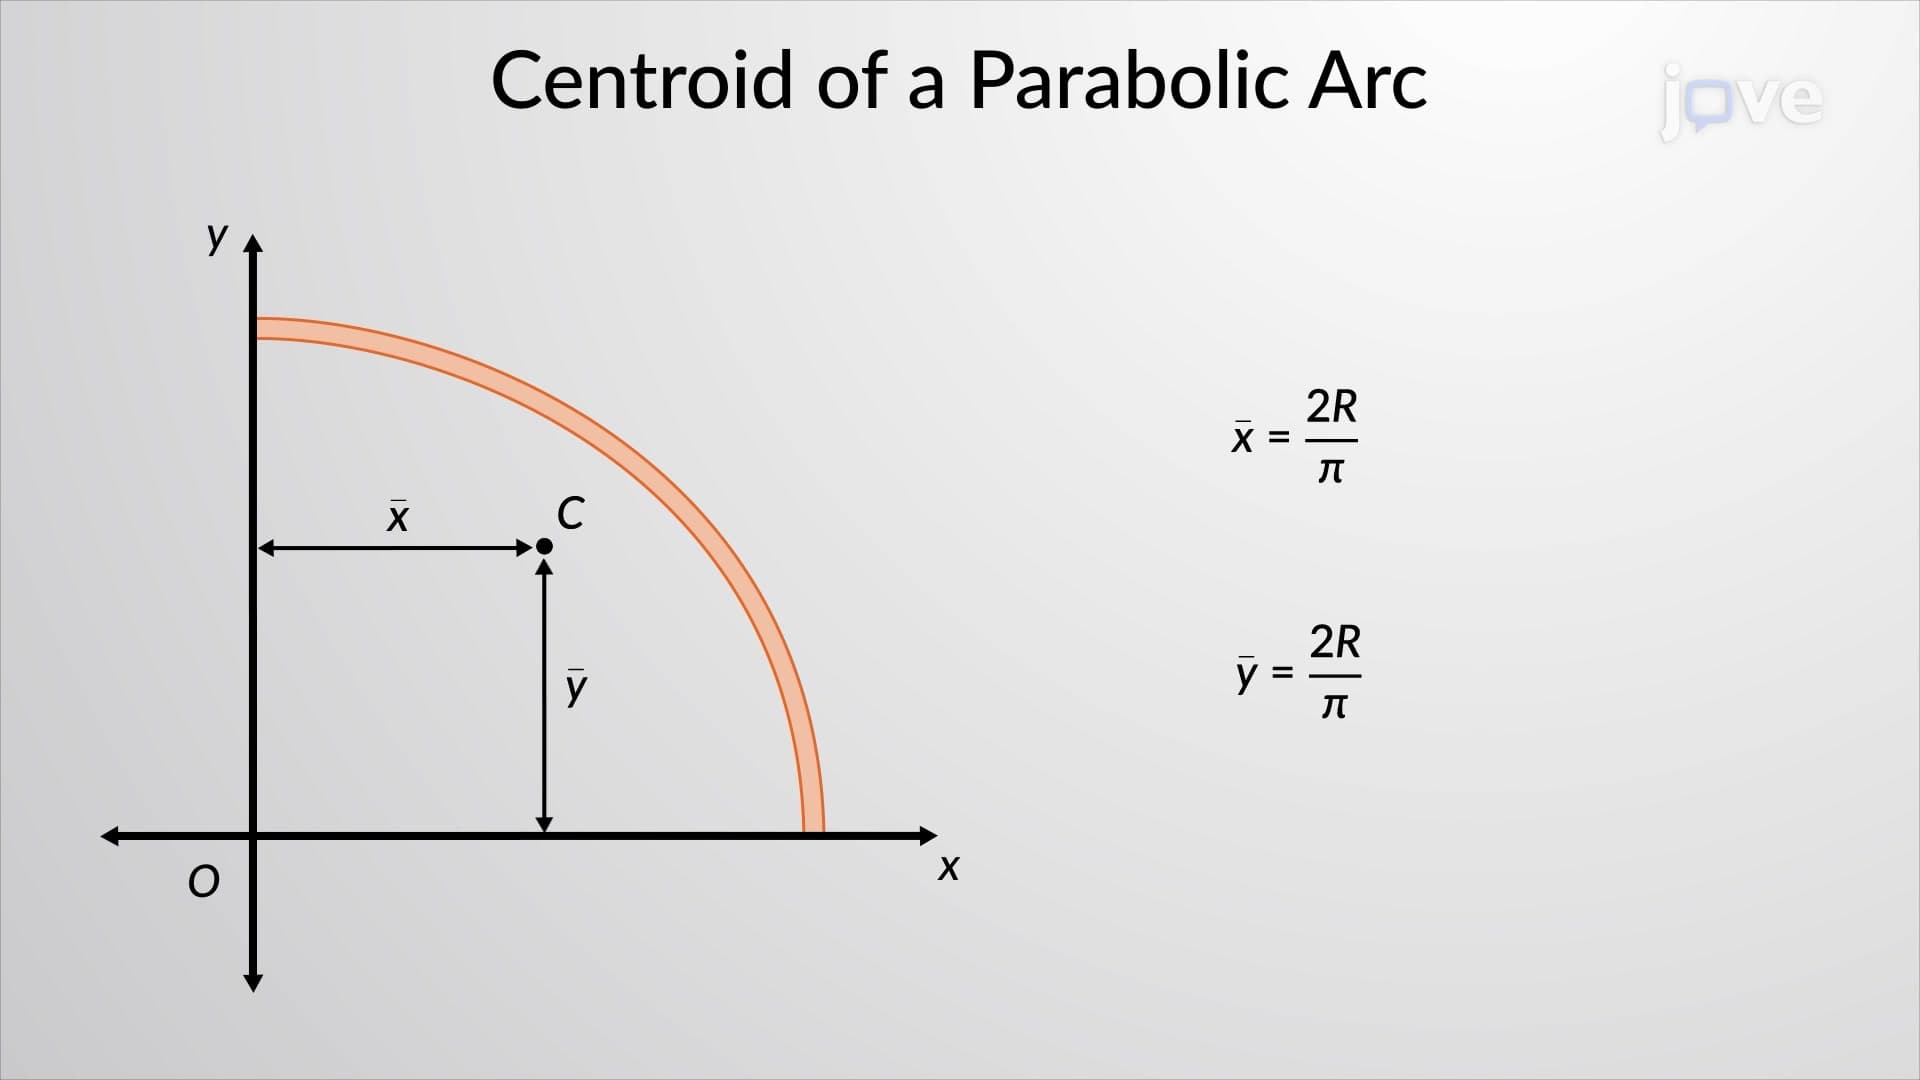
The centroid of a body is a crucial concept in engineering and physics. Finding the centroid of a body can help determine its stability, its balance point, and even its design. In this context, consider a thin wire bent in the form of a quarter circular arc. Polar coordinates are used to calculate the centroid. The wire is first divided into small differential elements of a length equal to the radius multiplied by the differential angle.
The x-coordinates and y-coordinates of each element's...
The x-coordinates and y-coordinates of each element's...
1.2K