
同步和完全可引导的活性粒子系统,用于更好地模仿自然界的集体运动
Zhihan Chen1, Hongru Ding2, Pavana Siddhartha Kollipara2
1Materials Science and Engineering Program and Texas Materials Institute, The University of Texas at Austin, Austin, TX, 78712, USA.
Advanced materials (Deerfield Beach, Fla.)
|August 12, 2023

概括
研究人员开发了一种光学反系统来控制活性粒子,模仿像鸟群一样的集体运动. 该系统使得在现实,扰乱的环境中研究复杂的行为成为可能,进步了群体机器人.
科学领域:
- 物理 物理学 物理
- 机器人技术 机器人技术 机器人技术
- 复杂的系统复杂的系统.
背景情况:
- 活体活性物质表现出复杂的集体运动 (例如,鱼群,鸟群).
- 无生命活性粒子可以模仿这种行为,但缺乏精确的控制.
- 现有的系统在研究复杂的集体动态时,与同步和任意的控制作斗争.
研究的目的:
- 提出一种新的光学反控制系统,以模拟活性粒子的集体运动.
- 为了使Vicsek模型在微尺度扰乱环境中进行实验性研究.
- 为研究集体行为提供可控制和现实的平台.
主要方法:
- 开发一种新的光学反控制系统.
- 利用活性粒子来模仿集体运动.
- 在扰乱条件下对速度对齐 (Vicsek模型) 的实验研究.
主要成果:
- 观察到各种运动状态和动态过渡的自发形成.
- 验证了在扰动下在临界密度下活性粒子组的高稳定性.
- 在现实,扰乱的环境中证明了速度对齐的有效性.
结论:
- 光学反系统有效地模拟了活性粒子中的集体运动.
- 速度对齐在现实世界乱的环境中是有效的.
- 该系统为基础集体运动研究和小群微型机器人开发提供了一个多功能平台.

相关概念视频
 01:22
Planar Rigid-Body Motion
474
Understanding the movement of a rigid body in planar motion involves recognizing that every particle within this body is traversing a path that maintains a consistent distance from a specific plane. This concept is fundamental in the study of physics and mechanical engineering, and it allows us to comprehend better how objects move in space.
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
474
 01:13
Nonconscious Mimicry
4.6K
Nonconscious mimicry occurs when individuals alter their mannerisms to match the behaviors and expressions of those nearby, without intention.
4.6K
 01:24
One-Degree-of-Freedom System
517
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
517
 01:23
Principle of Linear Impulse and Momentum for a Single Particle: Problem Solving
226
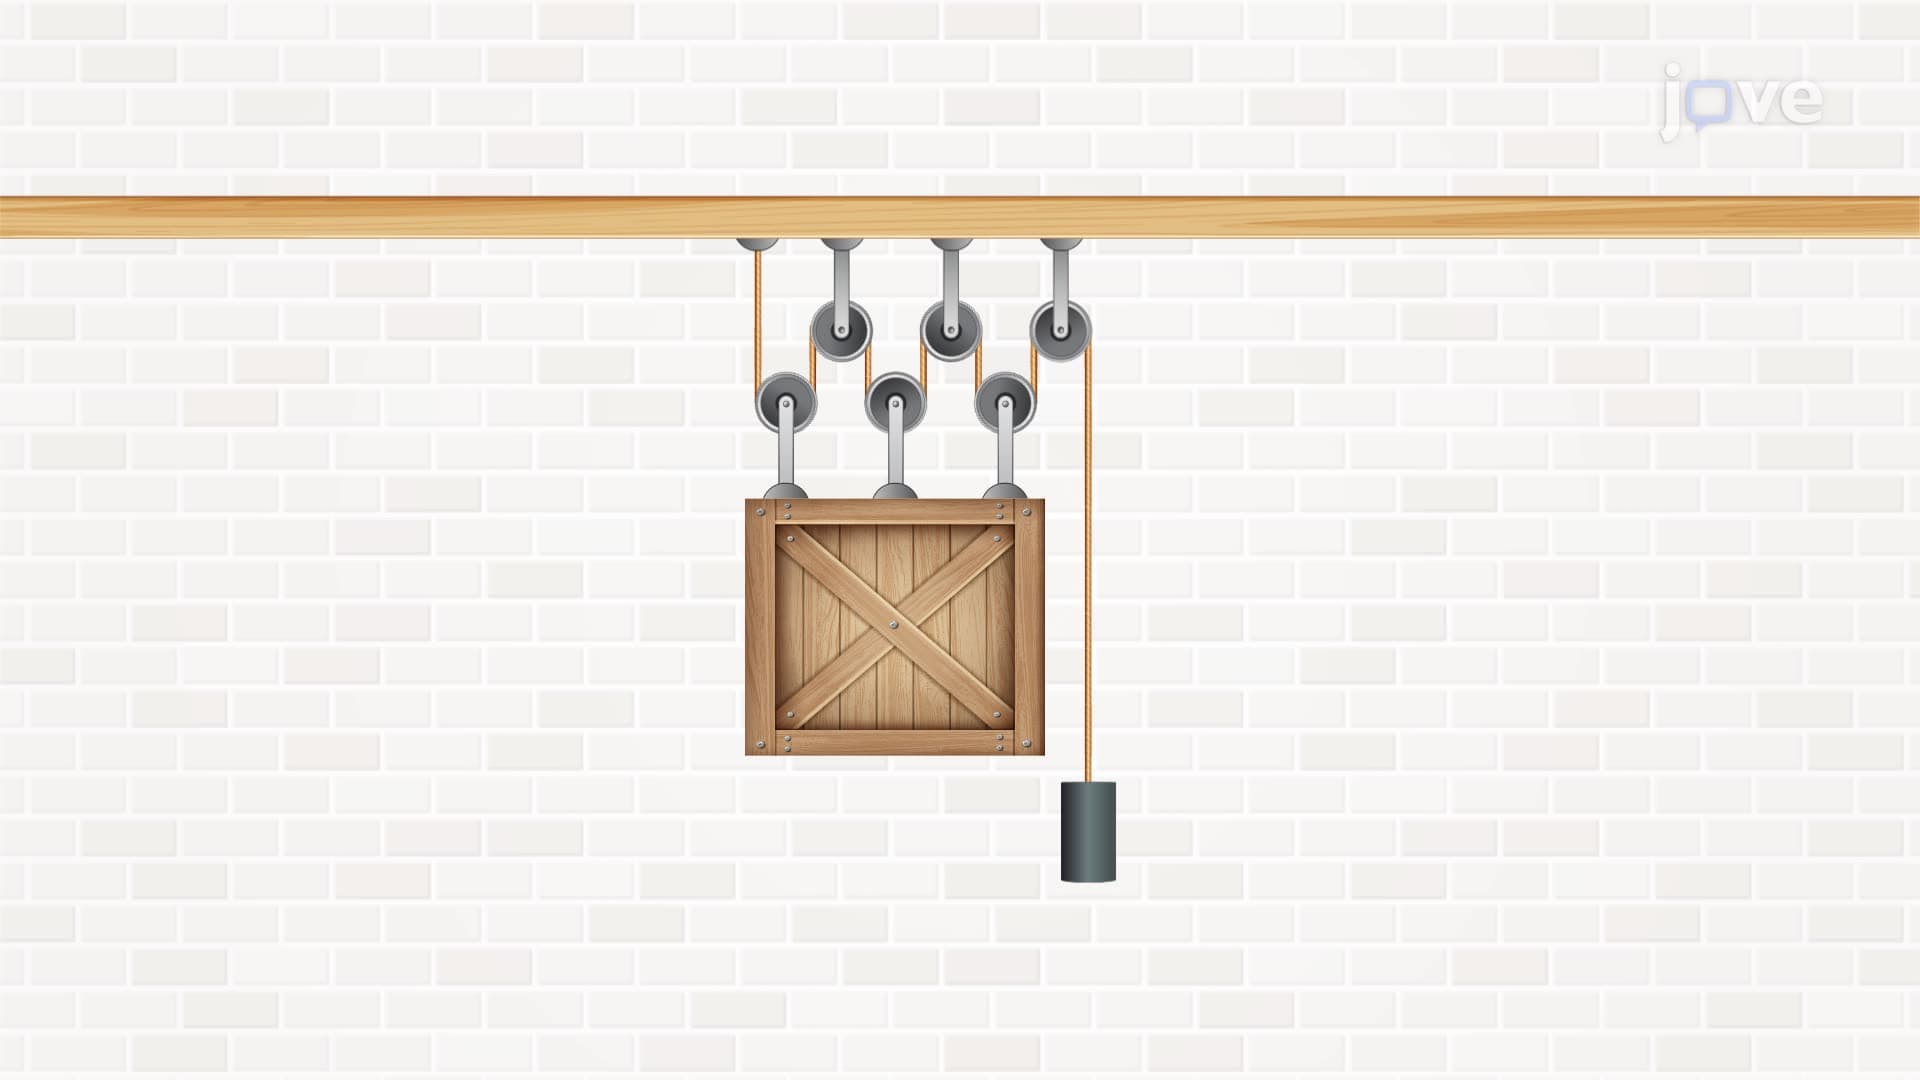
Consider a wooden box and a cylinder of known masses m1 and m2, respectively, hanging from a ceiling with the help of a massless pulley system.
226
 01:14
Equation of Motion: Center of Mass
173
The equation of motion for a single particle can be expanded to encompass a system of particles consisting of n particles. For any arbitrarily chosen particle within this system, the net force acting upon it is the aggregate of both internal and external forces. Extending this principle to all particles within the system results in the equation of motion for the entire assembly.
Internal forces between any pair of particles manifest as collinear pairs of equal magnitude but opposite directions,...
Internal forces between any pair of particles manifest as collinear pairs of equal magnitude but opposite directions,...
173
 01:06
Virtual Work for a System of Connected Rigid Bodies
421
Virtual work is a powerful method used to solve problems involving several connected rigid bodies. When the system is in equilibrium, virtual work is zero. This allows the calculation of the resulting forces when a system undergoes a virtual displacement. When attempting to analyze such a system, first, use a free-body diagram, where an independent coordinate represents the configuration of the links, and mark its deflected position resulting from the positive virtual displacement.
Next,...
Next,...
421