
从动力学预测静态和移动达到目标的深度和方向效应
A Bosco1,2, M Filippini3,4, D Borra5
1Department of Biomedical and Neuromotor Sciences, University of Bologna, Bologna, Italy. annalisa.bosco2@unibo.it.
Scientific reports
|August 12, 2023

概括
在reach-to-grasp运动中的行动意图适应不断变化的视觉目标目标. 研究人员使用循环神经网络来解码运动动力学,揭示了对目标转移的时间预测结构.
科学领域:
- 神经科学是一个神经科学.
- 机器人技术 机器人技术 机器人技术
- 人与计算机的交互
背景情况:
- 从伸到抓的运动动力学受到行动意图的影响.
- 意想不到的视觉目标对行动意图和运动期间时间预测的影响仍然不清楚.
研究的目的:
- 调查行动意图是否会在达成过程中随着目标目标的修改而改变.
- 为了确定目标目标预测的时间结构,在达到-抓取运动期间.
- 分析动态数据来解码运动意图和预测目标转移.
主要方法:
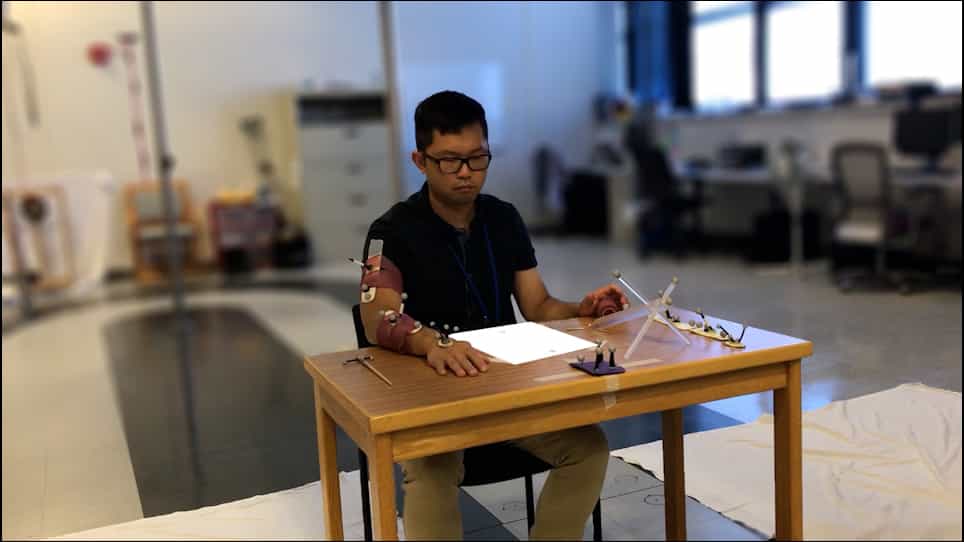
- 在达到运动时记录了23名参与者的运动数据 (手指和手腕).
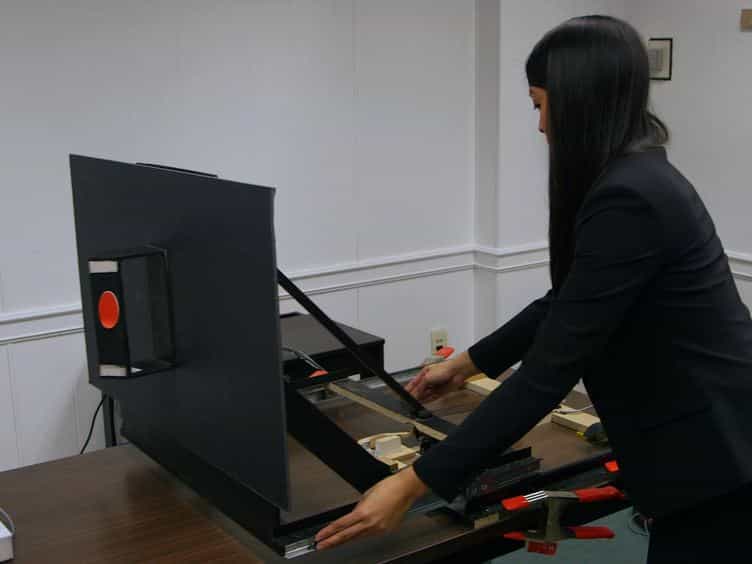
- 在各种位置引入静态和移动的视觉目标.
- 采用循环神经网络来从动态数据中对最终目标和中间轨迹进行时间解码.
主要成果:
- 从运动开始到完成,分类性能逐渐提高.
- 成功解码了静态和移动目标.
- 横向目标的解码准确度超过了斜向目标的解码准确度.
结论:
- 人类的触摸-抓取动作表现出适应性的动力学策略,以应对不断变化的视觉目标.
- 运动动力学的时间解码可以揭示目标转移的预测机制.
- 通过动力学分析,研究结果为优化3D空间中人机器人协作提供了信息.
相关概念视频
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
421
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
421
 01:15
Kinematic Equations: Problem Solving
12.5K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
12.5K
 01:25
Relative Motion Analysis using Rotating Axes
486
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
486
 01:18
Kinematic Equations - III
7.7K
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
7.7K
 01:17
Kinematic Equations - II
9.6K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
9.6K
 01:30
Kinematic Equations for Rotation
349
In mechanics, when one observes a rigid body in rotational motion with constant angular acceleration, it is possible to establish equations for its rotational kinematics. This process resembles how linear kinematics are dealt with in simpler motion studies.
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
349