
低概率状态,数据统计和估计
Damián G Hernández1,2, Ahmed Roman1, Ilya Nemenman1,3,4
1Department of Physics, Emory University, Atlanta, Georgia, USA.
Physical review. E
|August 16, 2023

概括
在复杂系统中估计是具有挑战性的,因为未采样状态. 这项研究揭示了关键数据统计数据,如样本大小和巧合,这些数据塑造了低样本分布的贝叶斯 Entropy 估计器.
科学领域:
- 复杂系统分析 复杂系统分析
- 信息理论 信息理论
- 统计建模 统计建模
背景情况:
- 在复杂系统中估计概率分布的是至关重要的,但很困难.
- 最大概率估计器被未采样状态所偏见,低估了真实.
- 贝叶斯估计器通过建模低概率尾巴来解决这个问题,但驱动因素仍然不清楚.
研究的目的:
- 确定观察到的数据的统计特征,这些特征决定了贝叶斯 entropy 估计器中的尾部模型.
- 为低样本分布开发近似的分析估计器.
- 为了提供一个直观的理解贝叶斯 entropy 估计器是如何工作的.
主要方法:
- 对离散概率分布的众所周知的估计器的分析.
- 基于已识别的数据统计数据的近似分析估计器的推导.
- 调查样本大小的影响,最大概率估计和巧合统计.
主要成果:
- 影响尾部建模的关键数据统计包括样本大小,最大概率估计,巧合数和巧合分散.
- 对于低样本分布,获得了近似的分析估计器.
- 这项研究阐明了数据统计和贝叶斯 Entropy 估计之间的关系.
结论:
- 贝叶斯 Entropy 估计中的低概率尾巴的结构主要由几个基本数据统计统计控制.
- 衍生出的分析估计器为不足样本的场景提供了一种实际的方法.
- 这项工作提高了复杂系统分析中贝叶斯值估计的解释性.

相关概念视频
 01:14
Probability in Statistics
13.4K
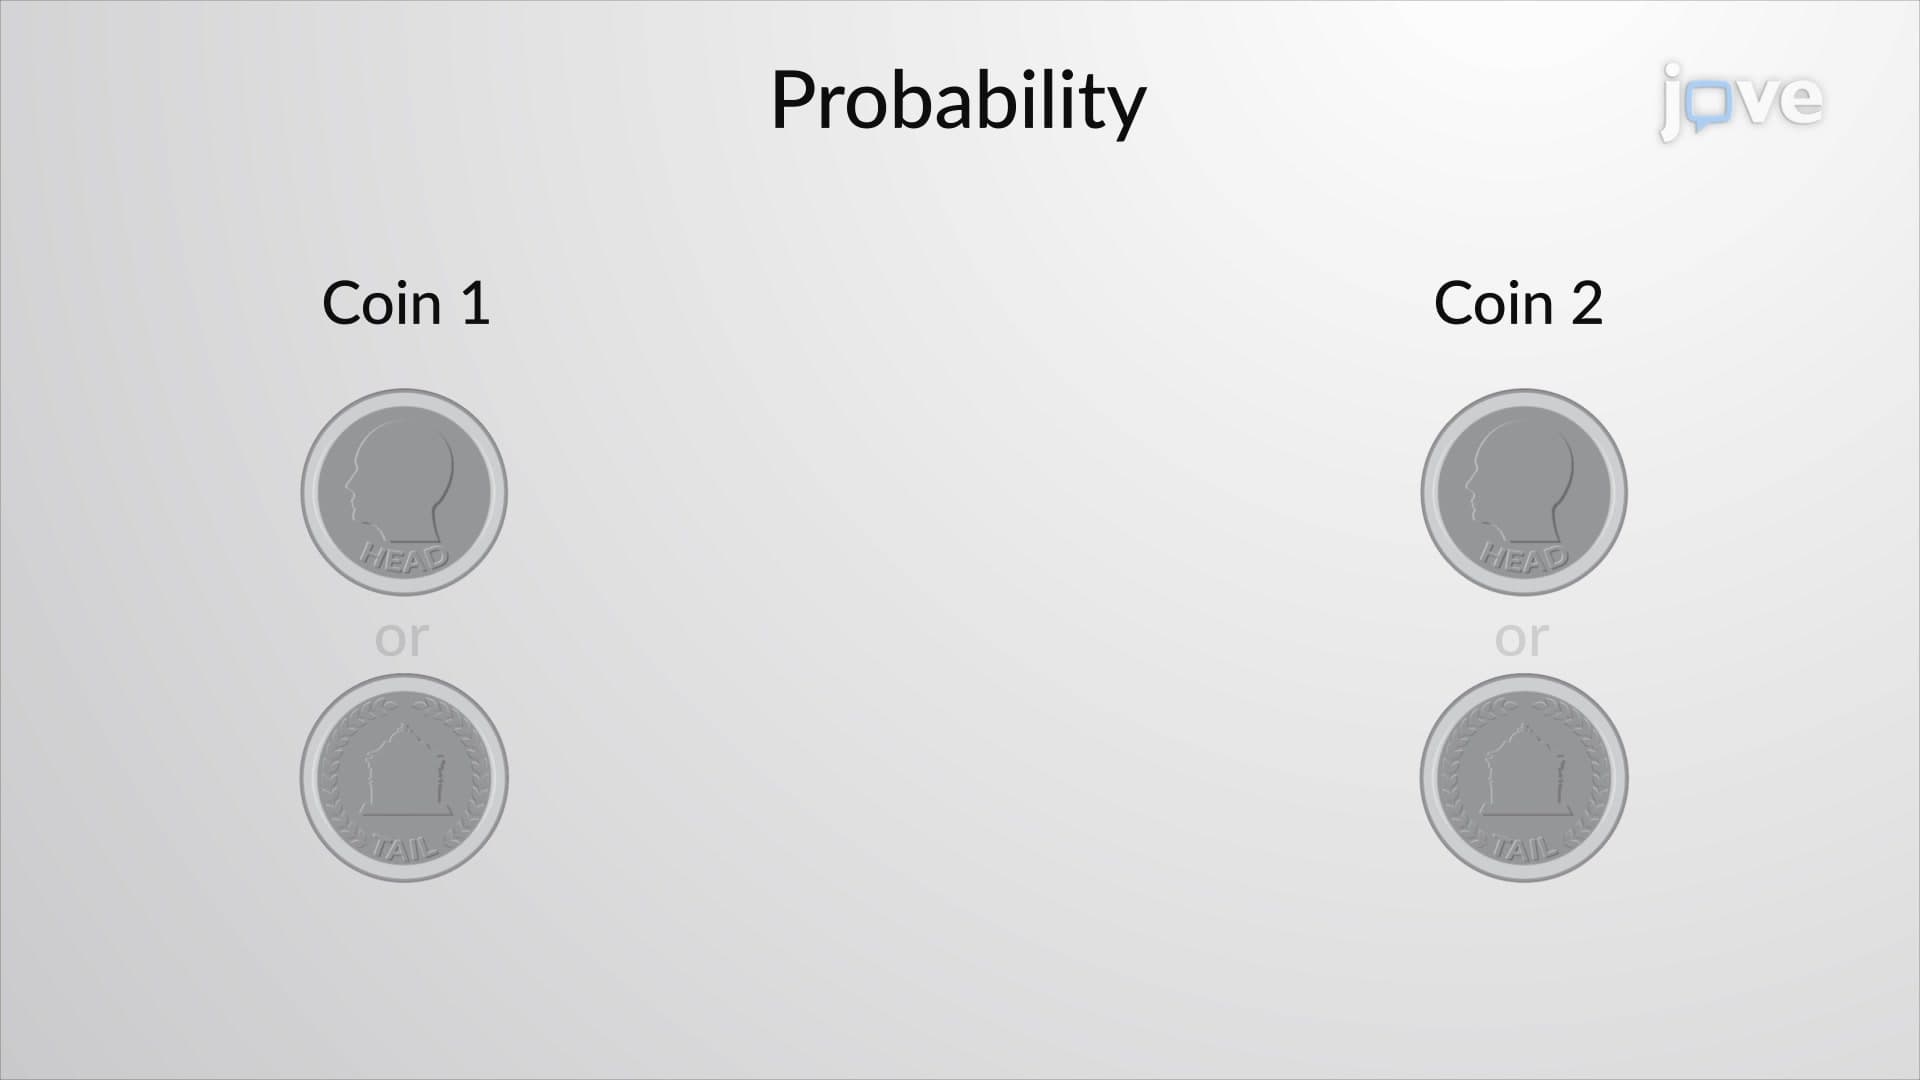
Probability is the likelihood of an event occurring. The term event is defined as a collection of results of a procedure. An event is a simple event when an outcome cannot be divided into simpler parts.
An example of a simple event is a coin toss. The result of a coin toss is either a head or a tail. Here, head and tail are two simple events. These two simple events make up the sample space. Further, the probability of an event occurring falls within the range of 0 to 1. The probability of an...
An example of a simple event is a coin toss. The result of a coin toss is either a head or a tail. Here, head and tail are two simple events. These two simple events make up the sample space. Further, the probability of an event occurring falls within the range of 0 to 1. The probability of an...
13.4K
 01:32
Probability Distributions
7.3K
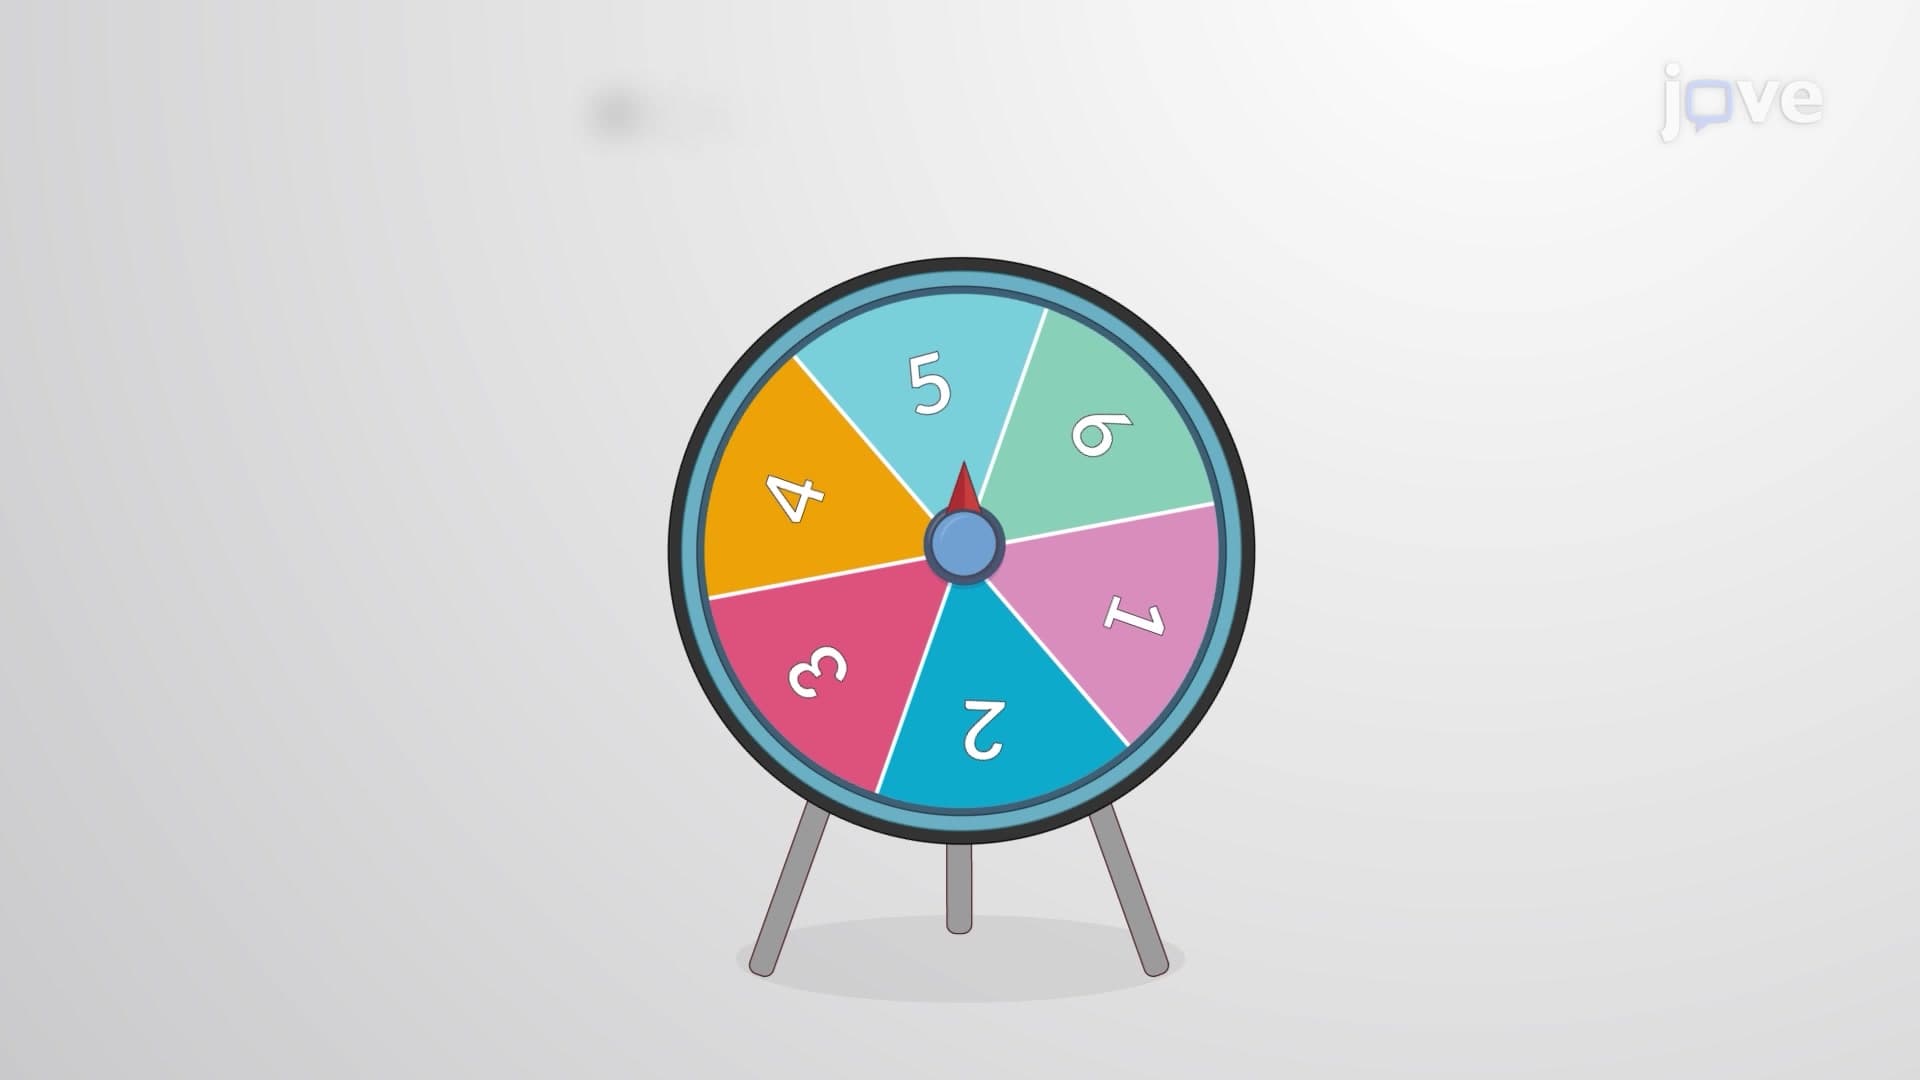
The probability of a random variable x is the likelihood of its occurrence. A probability distribution represents the probabilities of a random variable using a formula, graph, or table. There are two types of probability distribution– discrete probability distribution and continuous probability distribution.
A discrete probability distribution is a probability distribution of discrete random variables. It can be categorized into binomial probability distribution and Poisson...
A discrete probability distribution is a probability distribution of discrete random variables. It can be categorized into binomial probability distribution and Poisson...
7.3K
 01:17
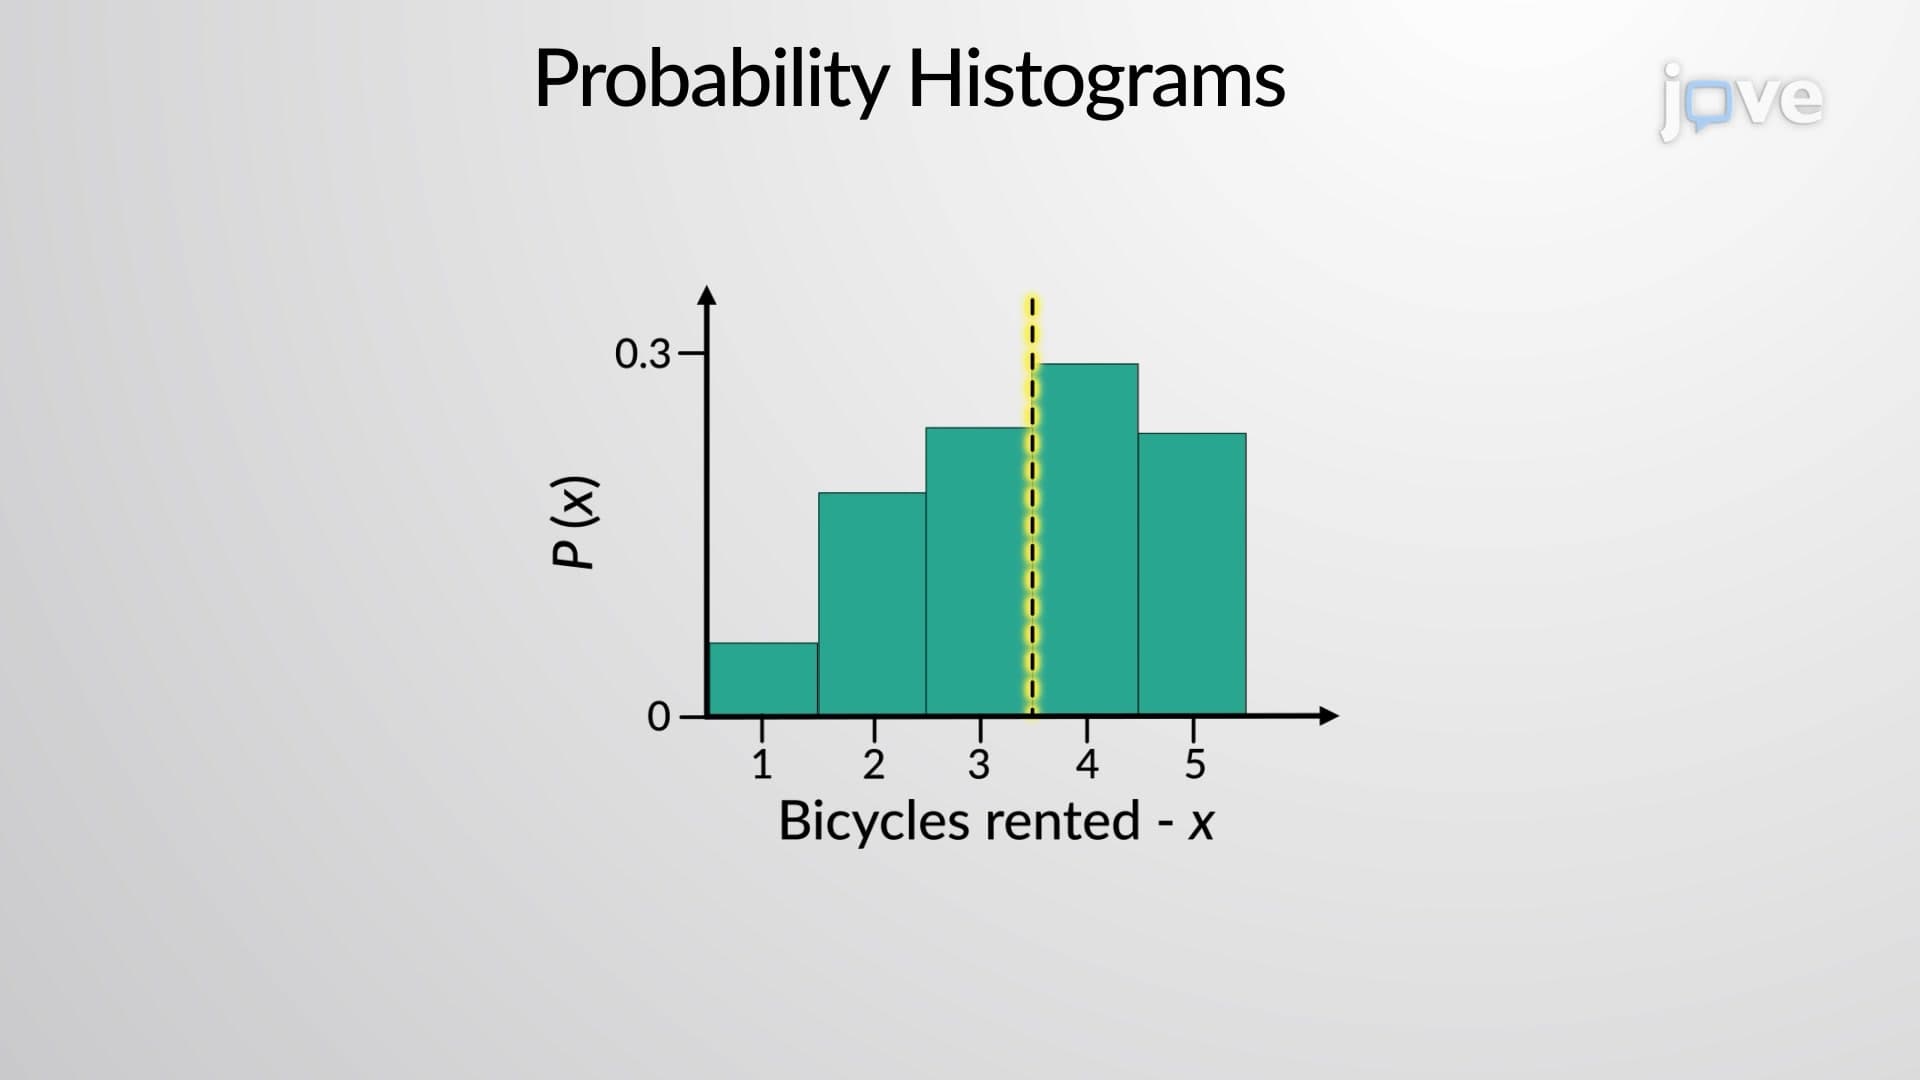
Probability Histograms
11.7K
A probability histogram is a visual representation of a probability distribution. Similar a typical histogram, the probability histogram consists of contiguous (adjoining) boxes. It has both a horizontal axis and a vertical axis. The horizontal axis is labeled with what the data represents. The vertical axis is labeled with probability. Each rectangular bar in the histogram is 1 unit wide, which suggests that the area under each bar equals the probability, P(x), where x is 1, 2, 3, and so on.
11.7K
 01:04
Random Error
925
Random or indeterminate errors originate from various uncontrollable variables, such as variations in environmental conditions, instrument imperfections, or the inherent variability of the phenomena being measured. Usually, these errors cannot be predicted, estimated, or characterized because their direction and magnitude often vary in magnitude and direction even during consecutive measurements. As a result, they are difficult to eliminate. However, the aggregate effect of these errors can be...
925
 01:16
Unusual Results
3.2K
Unusual results are those that have a very low chance of occurring. Unusual results can be identified using probabilities and the range rule of thumb. In problems involving probability, unusual results can be observed in 2 instances – an unusually high number of successes or an unusually low number of successes.
According to the range rule of thumb, any value above or below two standard deviations, 2σ from the mean, μ is considered unusual.
Maximum unusual value =...
According to the range rule of thumb, any value above or below two standard deviations, 2σ from the mean, μ is considered unusual.
Maximum unusual value =...
3.2K
 01:26
Distributions to Estimate Population Parameter
4.1K
The accurate values of population parameters such as population proportion, population mean, and population standard deviation (or variance) are usually unknown. These are fixed values that can only be estimated from the data collected from the samples. The estimates of each of these parameters are sample proportion, the sample mean, and sample standard deviation (or variance). To obtain the values of these sample statistics, data are required that have particular distribution and central...
4.1K