
有限地平线H∞ 对于具有不确定的合和数据包损失的复杂网络的状态估计:处理放大和转发中继
IEEE transactions on neural networks and learning systems
|August 23, 2023

概括
本研究开发了一个复杂网络 (CNs) 的状态估计器,这些复杂网络面临不确定的合和数据包丢失. 该方法确保性能约束得到满足,为在线状态估计提供递归算法.
科学领域:
- 控制系统工程 控制系统工程
- 网络科学 网络科学
- 信息理论 信息理论
背景情况:
- 复杂的网络 (CN) 容易受到内部连接的不确定性和传输过程中数据丢失的影响.
- 有效的状态估计对于监控和控制这些网络至关重要,特别是在存在通信限制的情况下.
研究的目的:
- 为具有不确定的内部合和数据包损失的复杂网络 (CN) 设计状态估计器.
- 为了确保在有限的时间范围内满足动态错误系统的规定的性能约束.
- 开发一种用于在线计算状态估计器的递归算法.
主要方法:
- 使用放大和转发 (AaF) 继电协议来提高通信质量.
- 使用伯努利随机变量建模数据包损失.
- 通过合的倒向里卡蒂差异方程 (RDE) 来推导估计器存在的足够条件并确定估计器收益.
主要成果:
- 对于具有不确定的参数和通信噪声的复杂网络而言,一种新的状态估计器设计.
- 一种适用于网络系统中实时状态估计的递归算法.
- 通过一个数值示例证明其有效性的拟议方法的验证.
结论:
- 拟议的状态估计方法有效地解决了复杂网络中的不确定性和数据包损失.
- 开发的递归算法促进了实际在线实施状态估计.
- 这些发现有助于在具有挑战性的通信条件下对网络系统进行可靠的控制和监控.
相关概念视频
 00:59
Propagation of Uncertainty from Random Error
726
An experiment often consists of more than a single step. In this case, measurements at each step give rise to uncertainty. Because the measurements occur in successive steps, the uncertainty in one step necessarily contributes to that in the subsequent step. As we perform statistical analysis on these types of experiments, we must learn to account for the propagation of uncertainty from one step to the next. The propagation of uncertainty depends on the type of arithmetic operation performed on...
726
 01:10
Propagation of Uncertainty from Systematic Error
554
The atomic mass of an element varies due to the relative ratio of its isotopes. A sample's relative proportion of oxygen isotopes influences its average atomic mass. For instance, if we were to measure the atomic mass of oxygen from a sample, the mass would be a weighted average of the isotopic masses of oxygen in that sample. Since a single sample is not likely to perfectly reflect the true atomic mass of oxygen for all the molecules of oxygen on Earth, the mass we obtain from this...
554
 01:25
Multimachine Stability
188
Multimachine stability analysis is crucial for understanding the dynamics and stability of power systems with multiple synchronous machines. The objective is to solve the swing equations for a network of M machines connected to an N-bus power system.
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
188
 01:27
State Space Representation
236
The frequency-domain technique, commonly used in analyzing and designing feedback control systems, is effective for linear, time-invariant systems. However, it falls short when dealing with nonlinear, time-varying, and multiple-input multiple-output systems. The time-domain or state-space approach addresses these limitations by utilizing state variables to construct simultaneous, first-order differential equations, known as state equations, for an nth-order system.
Consider an RLC circuit, a...
Consider an RLC circuit, a...
236
 01:23
Transfer Function to State Space
296
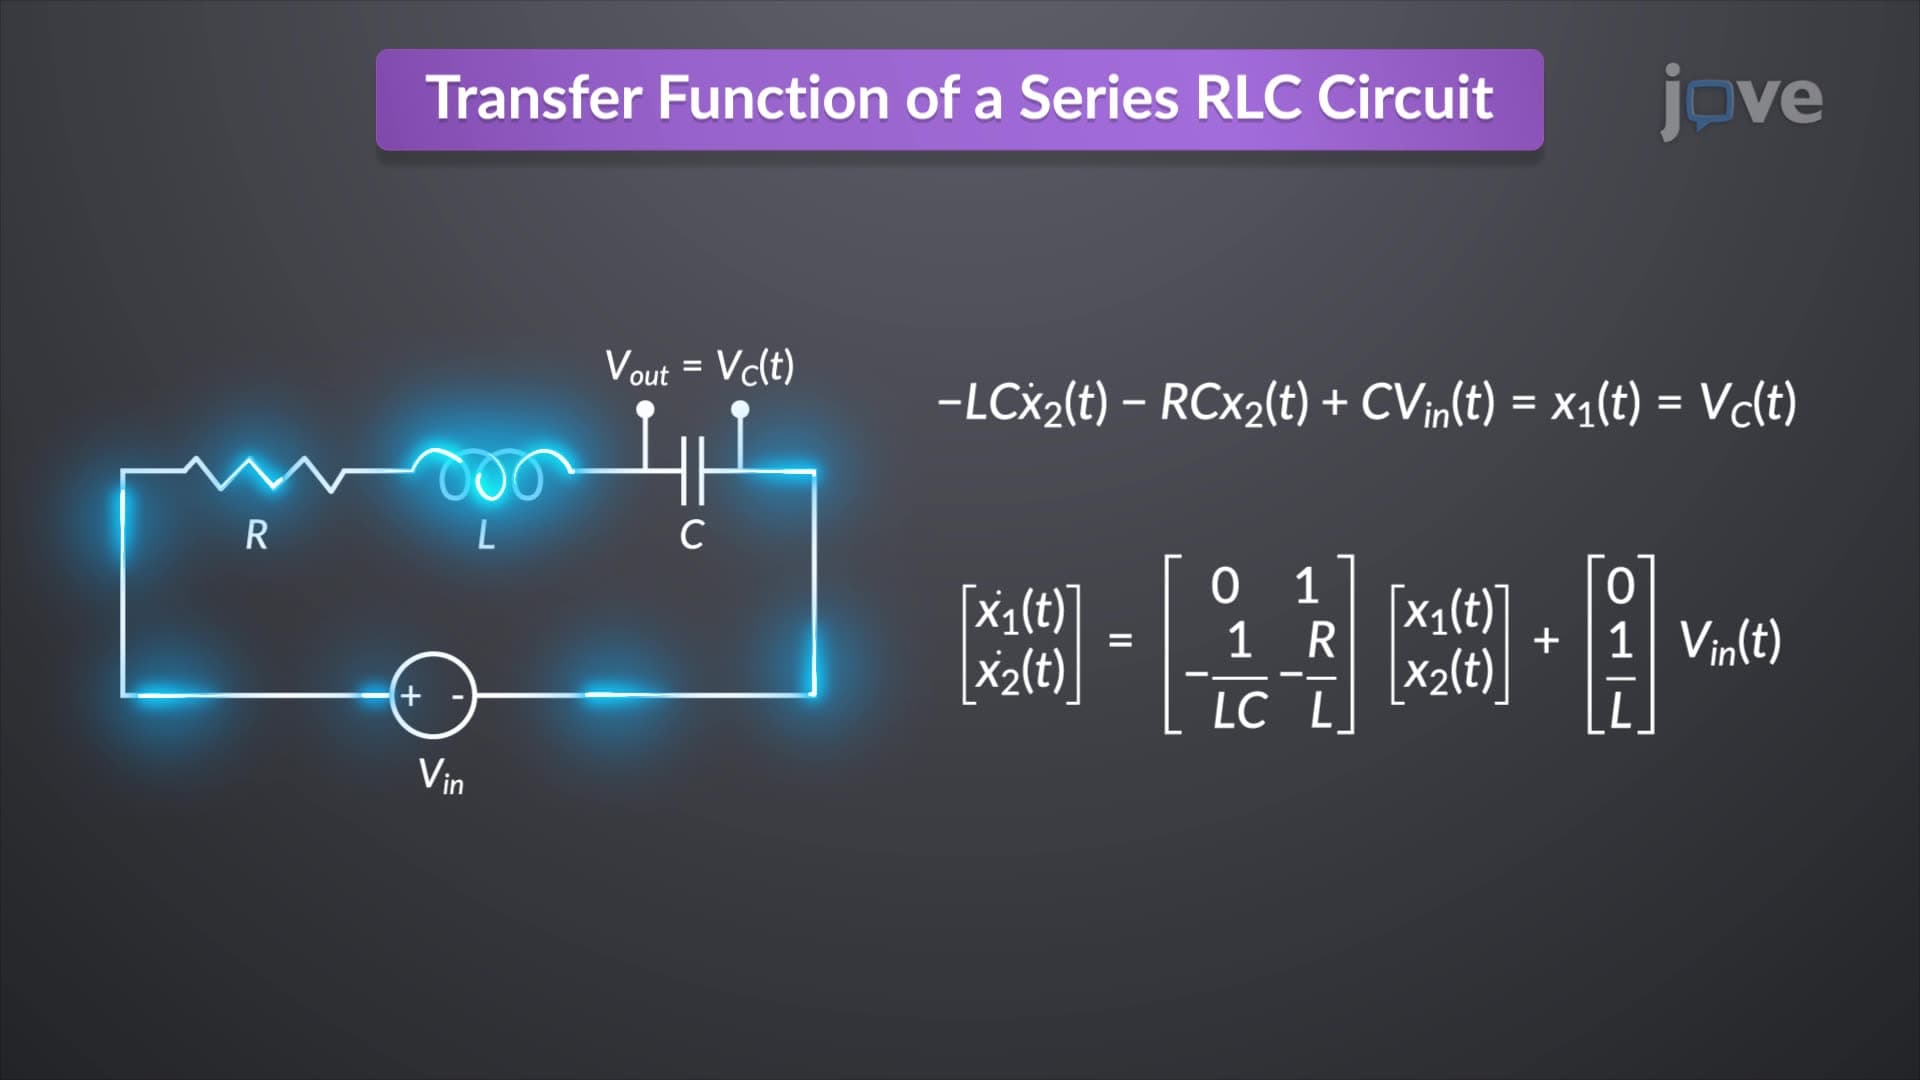
State-space representation is a powerful tool for simulating physical systems on digital computers, necessitating the conversion of the transfer function into state-space form. Consider an nth-order linear differential equation with constant coefficients, like those encountered in an RLC circuit. The state variables are selected as the output and its n−1 derivatives. Differentiating these variables and substituting them back into the original equation produces the state equations.
In an...
In an...
296
 01:21
State Space to Transfer Function
234
The conversion of state-space representation to a transfer function is a fundamental process in system analysis. It provides a method for transitioning from a time-domain description to a frequency-domain representation, which is crucial for simplifying the analysis and design of control systems.
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
234