

一个轮式振动驱动机器人的机动特性,带有增强的泛流机类型悬挂
Vitaliy Korendiy1, Oleksandr Kachur1
1Department of Technical Mechanics and Engineering Graphics, Institute of Mechanical Engineering and Transport, Lviv Polytechnic National University, Lviv, Ukraine.
Frontiers in robotics and AI
|August 28, 2023

概括
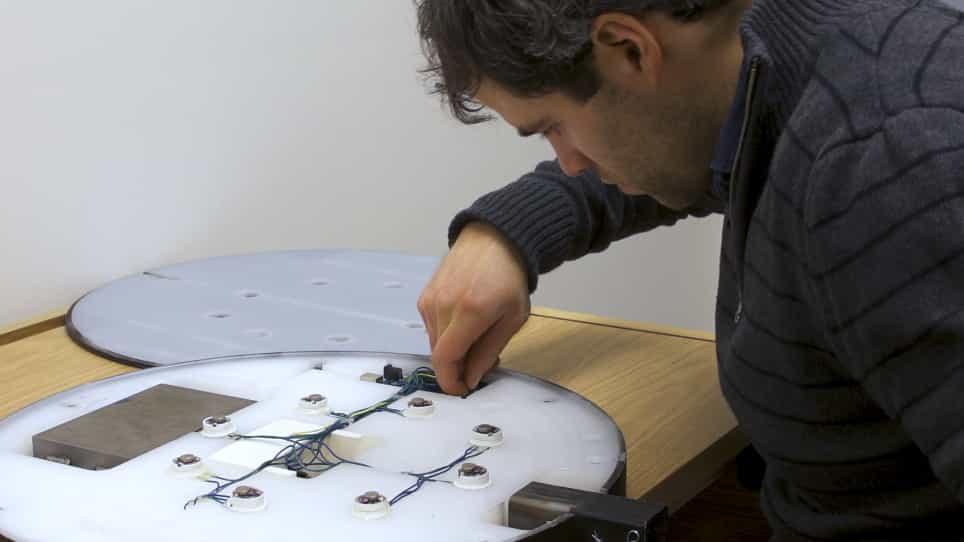
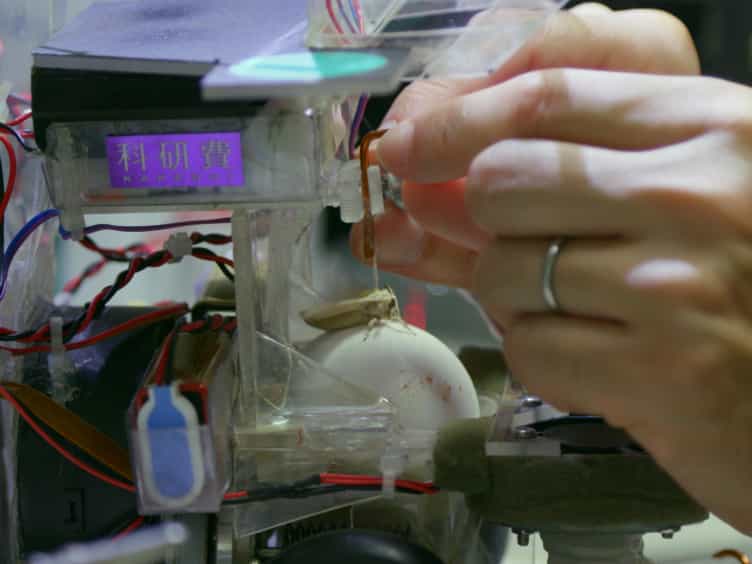
这项研究介绍了一种改进的轮式振动驱动机器人,具有增强的泛相机悬挂. 数学建模,模拟和实验证实了改进的动力学特性,达到高达40毫米/秒的运动速度.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 机械工程 机械工程
- 振动工程 振动工程
背景情况:
- 轮式振动驱动机器人提供独特的机动能力.
- 改进的悬架系统对于提高动力性能至关重要.
- 优化机器人设计需要综合建模,模拟和实验验证.
研究的目的:
- 为了研究一个轮式振动驱动机器人的改进设计,并增强了泛相机类型悬挂.
- 以数学模型,模拟和实验测试新型机器人原型的运动条件.
- 为了证明增强的泛流机悬挂对提高动力学特性,特别是平均转换速度的好处.
主要方法:
- 使用欧勒-拉格朗日方程开发简化动态图和数学模型.
- 在Mathematica中的数值建模和在SolidWorks Motion中的计算机模拟.
- 使用WitMotion加速度计和MathCad中的数据处理进行实验验证.
主要成果:
- 数学建模,计算机模拟和实验结果显示出一致的动力学参数依赖性.
- 运动速度从每分钟500转的1mm/s到每分钟1500转的40mm/s不等.
- 增强的泛相机悬挂显著影响机器人的转换速度.
结论:
- 增强的泛相机类型悬架有效地改善了轮式振动驱动机器人的动力特性.
- 该研究为设计和测试类似机器人系统提供了经过验证的方法.
- 结果适用于开发工业原型,用于管道检查和清洁等任务.
相关概念视频
 01:17
Rolling Resistance: Problem Solving
372
Rolling resistance, also known as rolling friction, is the force that resists the motion of a rolling object, such as a wheel, tire, or ball, when it moves over a surface. It is caused by the deformation of the object and the surface in contact with each other, as well as other factors like internal friction, hysteresis, and energy losses within the materials. Rolling resistance opposes the object's motion, requiring additional energy to overcome it and maintain movement. In practical...
372
 01:17
Characteristics of Simple Harmonic Motion
13.0K
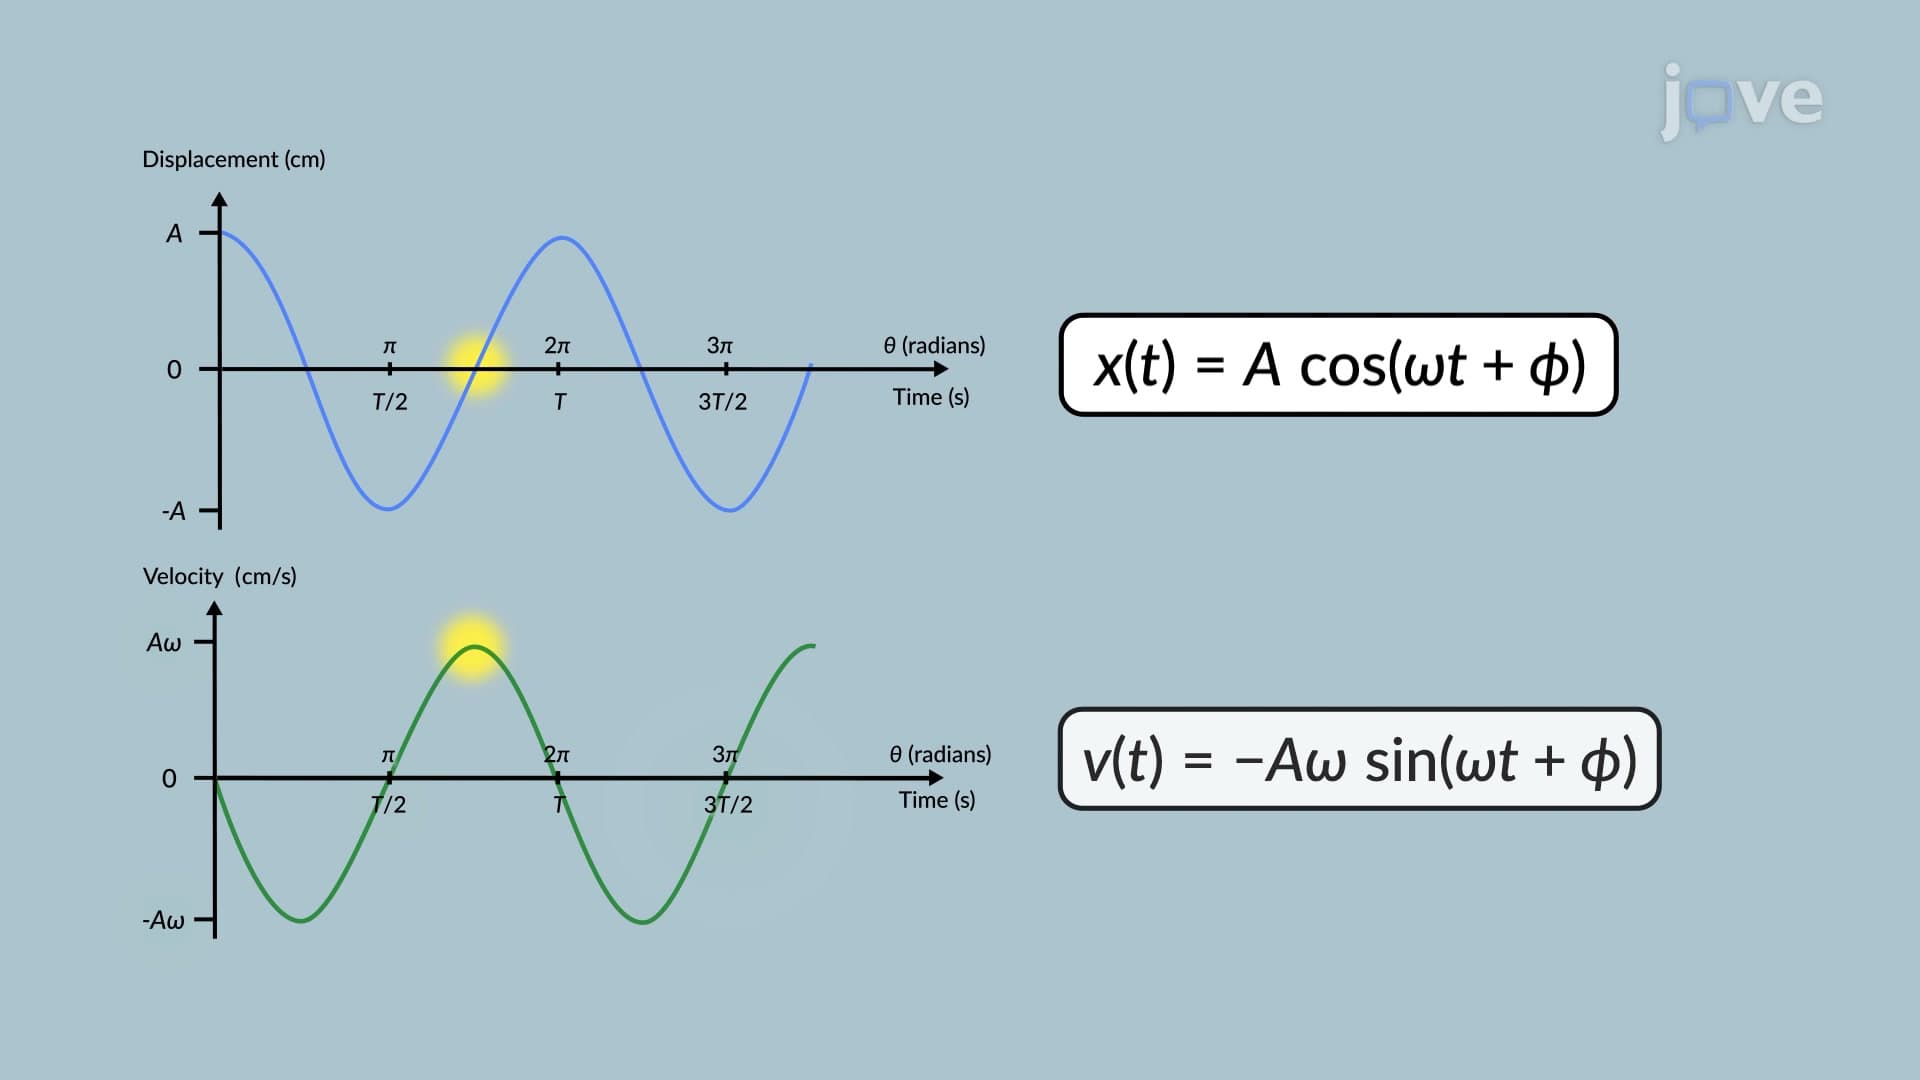
The key characteristic of the simple harmonic motion is that the acceleration of the system and, therefore, the net force are proportional to the displacement and act in the opposite direction to the displacement. Additionally, the period and frequency of a simple harmonic oscillator are independent of its amplitude. For example, diving boards move faster or slower based on their thickness. A stiff, thick diving board has a large force constant, which causes it to have a smaller period, while a...
13.0K
 01:21
Rolling Resistance
318
When a solid cylinder rolls steadily on a rigid surface, the normal force applied by the surface on the cylinder is perpendicular to the tangent at the contact point. However, since no materials are entirely rigid, the surface's reaction to the cylinder involves a range of normal pressures.
For instance, imagine a hard cylinder rolling on a comparatively soft surface. The cylinder's weight compresses the surface beneath it. As the cylinder moves, the material in front of it slows down...
For instance, imagine a hard cylinder rolling on a comparatively soft surface. The cylinder's weight compresses the surface beneath it. As the cylinder moves, the material in front of it slows down...
318
 01:16
Equation of Motion: General Plane motion - Problem Solving
204
Consider a lawn roller with a mass of 100 kg, a radius of 0.2 meters, and a radius of gyration of 0.15 meters. A force of 200 N is applied to this roller, angled at 60 degrees from the horizontal plane. What will be the angular acceleration of the lawn roller?
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
204
 01:09
Rolling Without Slipping
4.1K
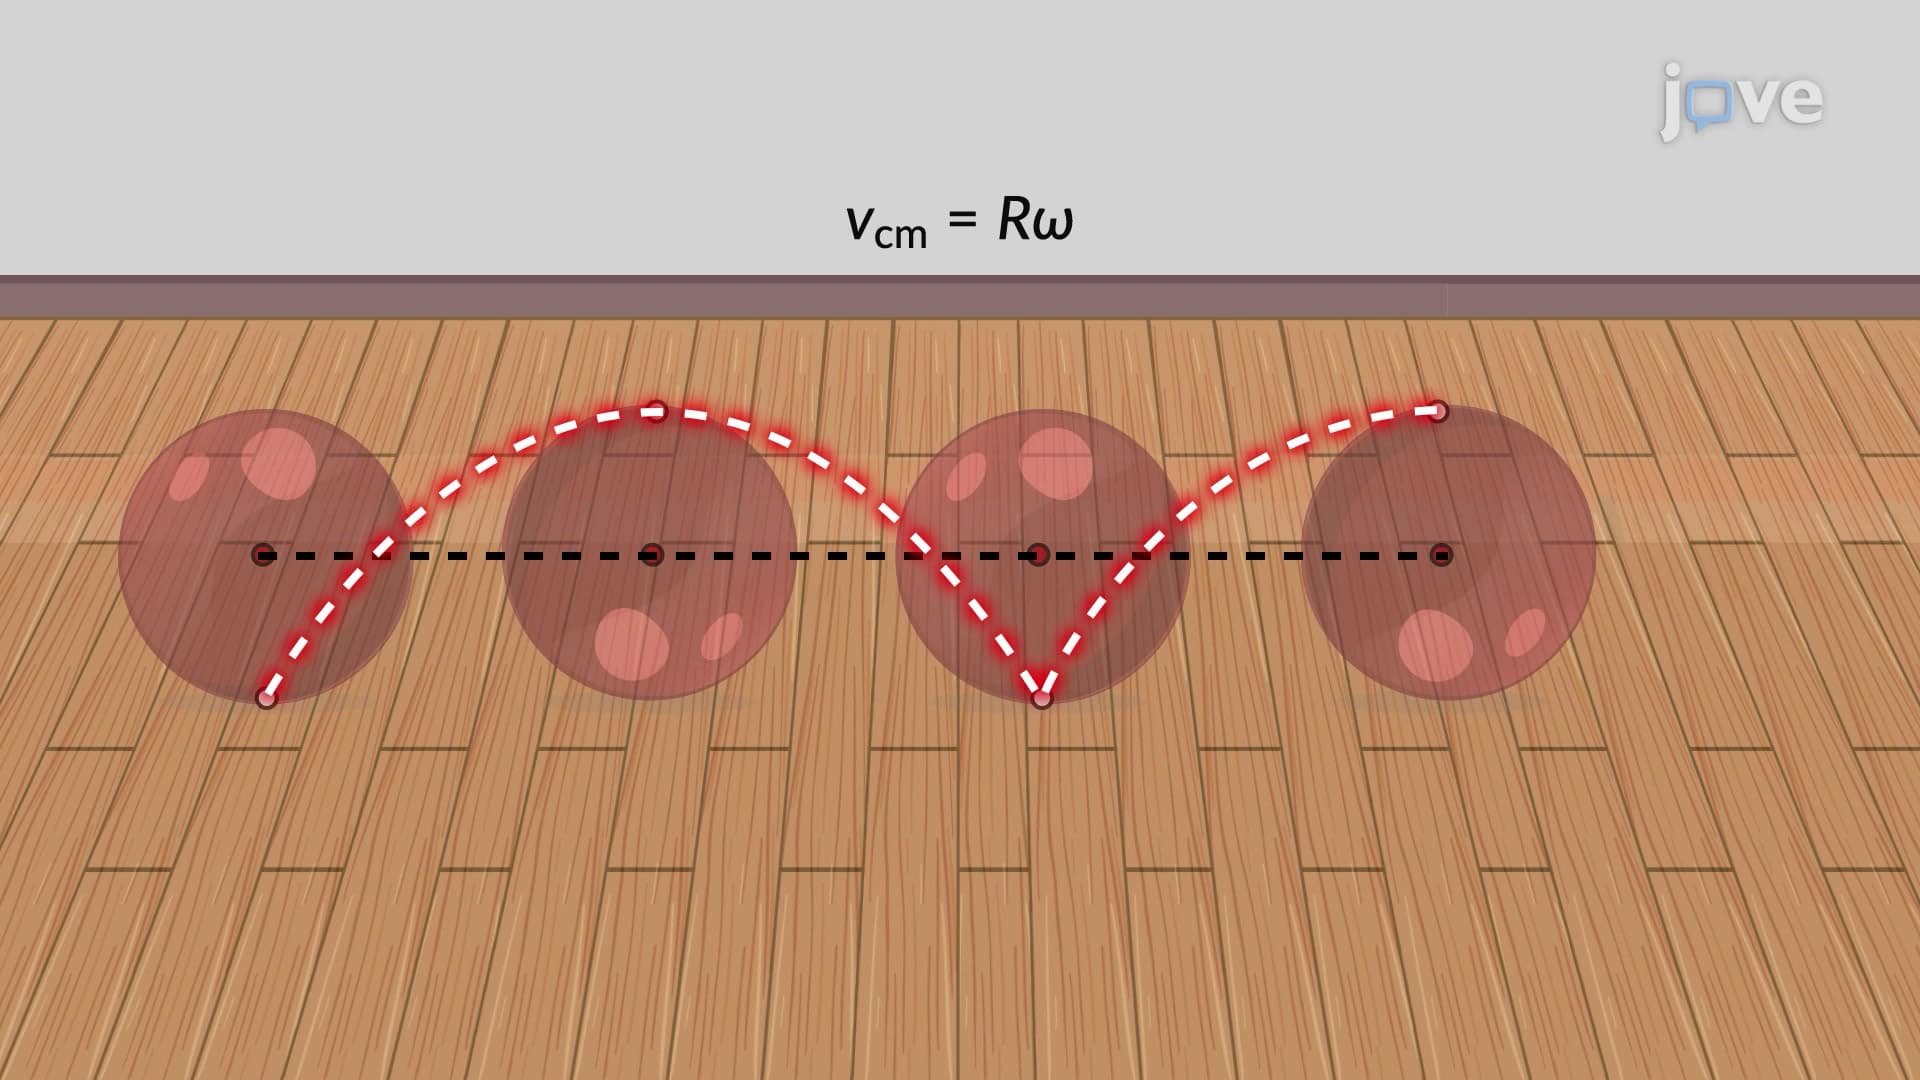
People have observed the rolling motion without slipping ever since the invention of the wheel. For example, one can look at the interaction between a car's tires and the surface of the road. If the driver presses the accelerator to the floor so that the tires spin without the car moving forward, there must be kinetic friction between the wheels and the road's surface. If the driver slowly presses the accelerator, causing the car to move forward, the tires roll without slipping. It is...
4.1K
 01:26
PD Controller: Design
277
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
277