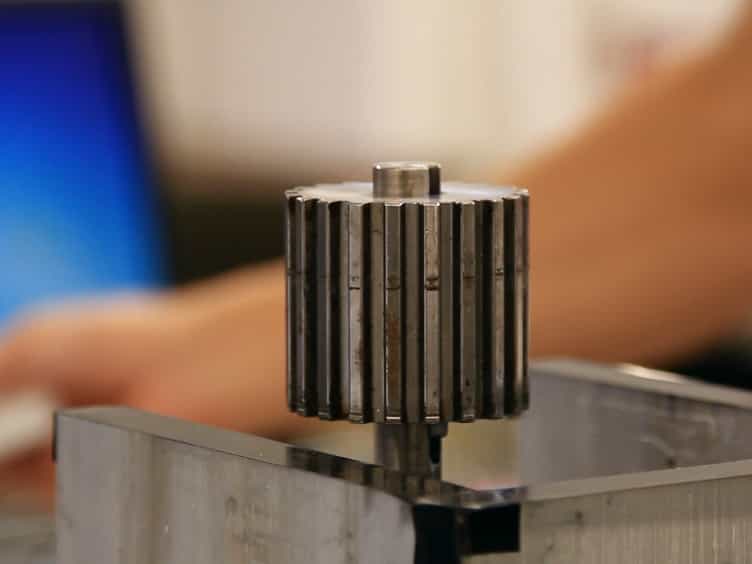

一种双脚协同驱动方法用于棒滑压电动执行器,以实现平滑运动
Zhaochen Ding1, Huadong Yu1, Xiaoqin Zhou1
1School of Mechanical and Aerospace Engineering, Jilin University, Changchun, Jilin 130022, China.
The Review of scientific instruments
|September 1, 2023

概括
一种新的双脚协同驱动方法改进了滑驱动器,以实现更顺的运动. 这种压电驱动器设计提高了性能,并扩大了应用,即使在负载下.
科学领域:
- 机械工程 机械工程
- 材料科学 材料科学 材料科学
背景情况:
- 现有的步进压电驱动器表现出非平滑的运动,限制了性能和应用.
- 驱动原理和结构设计有助于这些限制,特别是在施加的负载下.
研究的目的:
- 为滑驱动器提出双脚合作驱动方法.
- 增强步行特征,在各种条件下实现平滑运动.
主要方法:
- 一个新的双脚合作驱动机制,利用两个灵活的驱动脚.
- 脚的交替推动动作诱导旋转器顺时针旋转.
主要成果:
- 观察到步骤特征随驱动电压而变化,显示从非平滑到平滑到突然跳跃的过渡.
- 保持平滑的位移曲线在20-30g的水平负载范围内.
- 在100V和1400Hz时,达到1452mrad/s的最大角速度.
结论:
- 双脚合作驱动方法有效地改善了棒滑动执行器的步进特性.
- 增强的光滑性和承载能力扩大了压电驱动器的实际应用范围.
更多相关视频
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
1.7K
 08:59
Modeling and Experimental Analysis of the Single-Shaft Coaxial Motor-Pump Assembly in Electrohydrostatic Actuators
Published on: June 13, 2022
2.6K
相关概念视频
 01:10
Relative Motion Analysis - Acceleration
378
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
378
 01:26
PD Controller: Design
277
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
277
 01:24
PI Controller: Design
327
Proportional Integral (PI) controllers are a fundamental component in modern control systems, widely used to enhance performance and mitigate steady-state errors. They are particularly effective in applications such as automatic brightness adjustment on smartphones, where they excel at mitigating steady-state errors for step-function inputs. Unlike PD controllers, which require time-varying errors to function optimally, PI controllers leverage their integral component to address residual...
327
 01:05
Static and Kinetic Frictional Force
16.0K
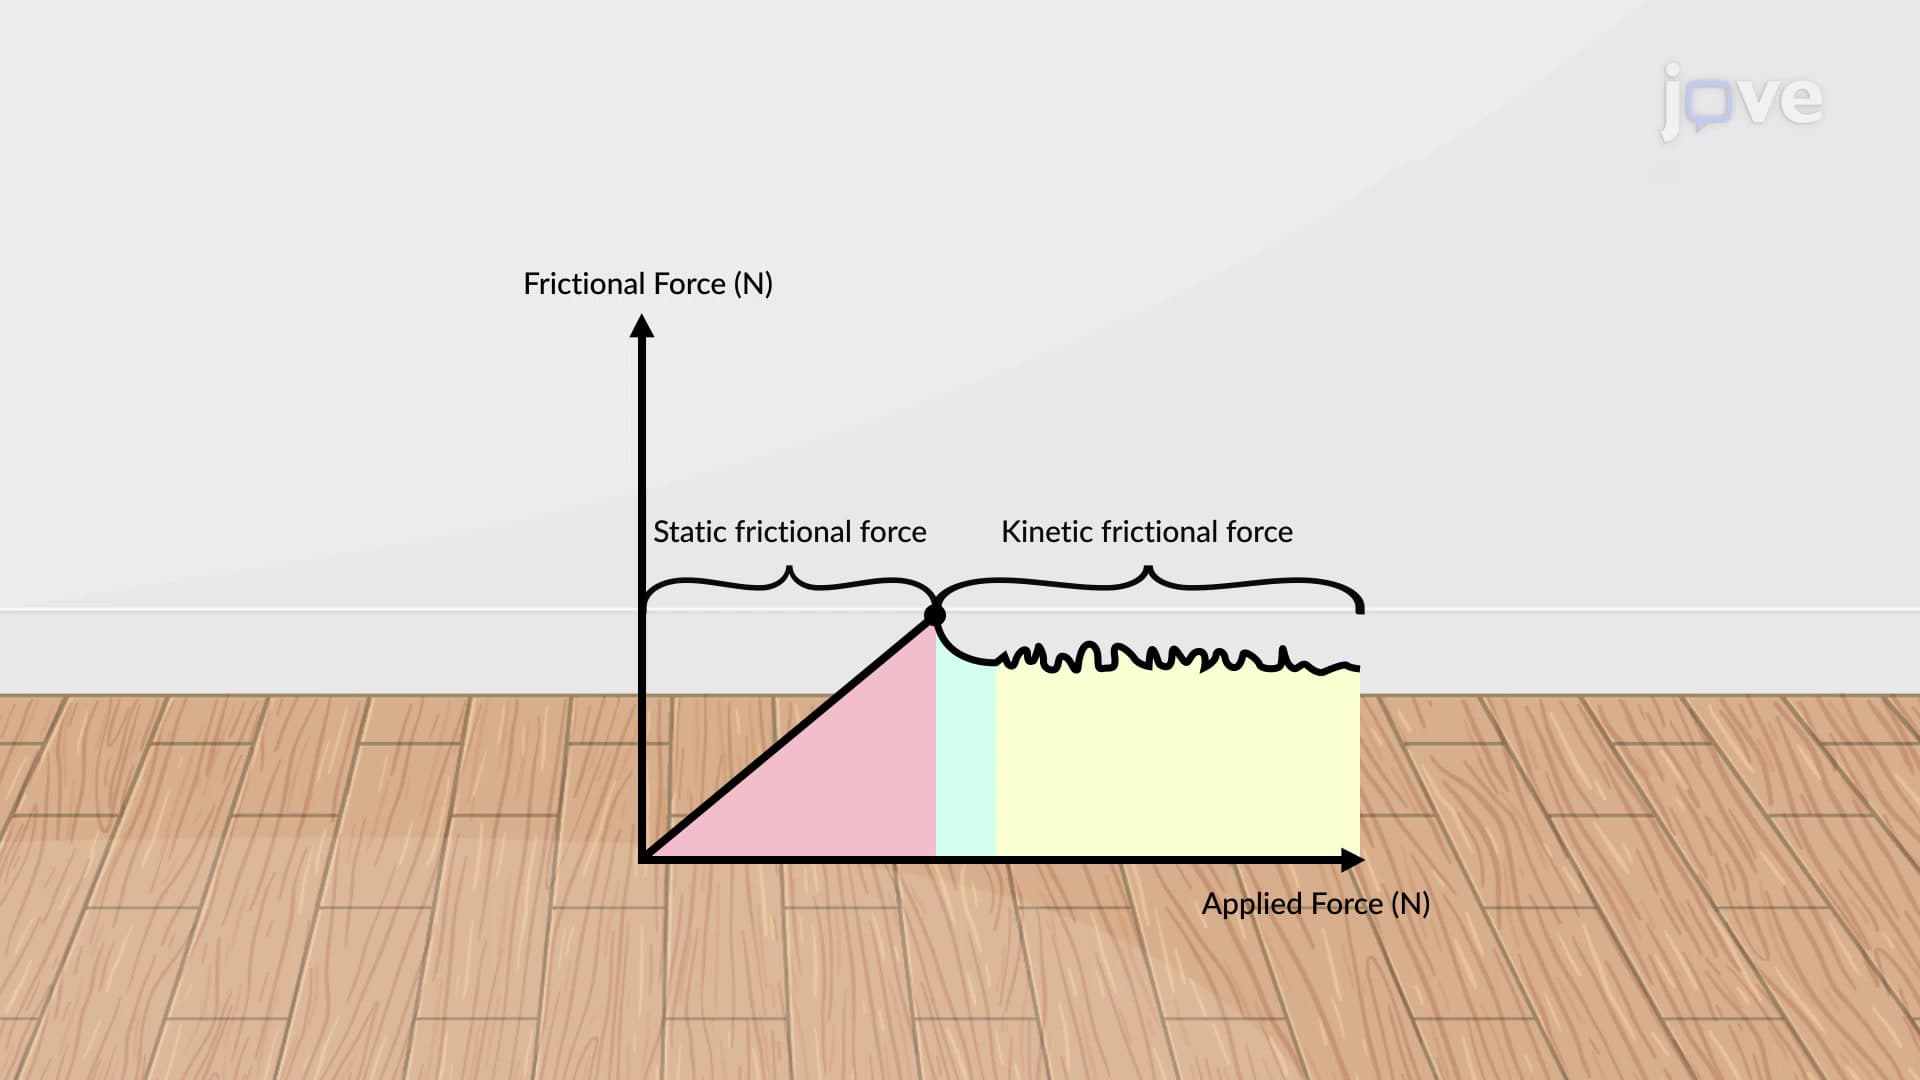
One of the simpler characteristics of sliding friction is that it is parallel to the contact surfaces between systems, and is always in a direction that opposes the motion or attempted motion of the systems relative to each other. If two systems are in contact and moving relative to one another, then the friction between them is called kinetic friction. For example, kinetic friction slows a hockey puck sliding on ice.
However, if two systems are in contact and are stationary relative to one...
However, if two systems are in contact and are stationary relative to one...
16.0K
 01:19
Root-Locus Method
180
A cruise control system in a car is designed to maintain a specified speed automatically by adjusting the gas pedal. The system continuously measures the vehicle's speed and makes fine adjustments to the pedal to achieve this goal. The root locus method is particularly useful for understanding how the cruise control system's behavior changes under varying conditions, such as when the car goes uphill, downhill, or faces strong wind resistance.
This system can be represented by a block...
This system can be represented by a block...
180
 01:16
Equation of Motion: General Plane motion - Problem Solving
204
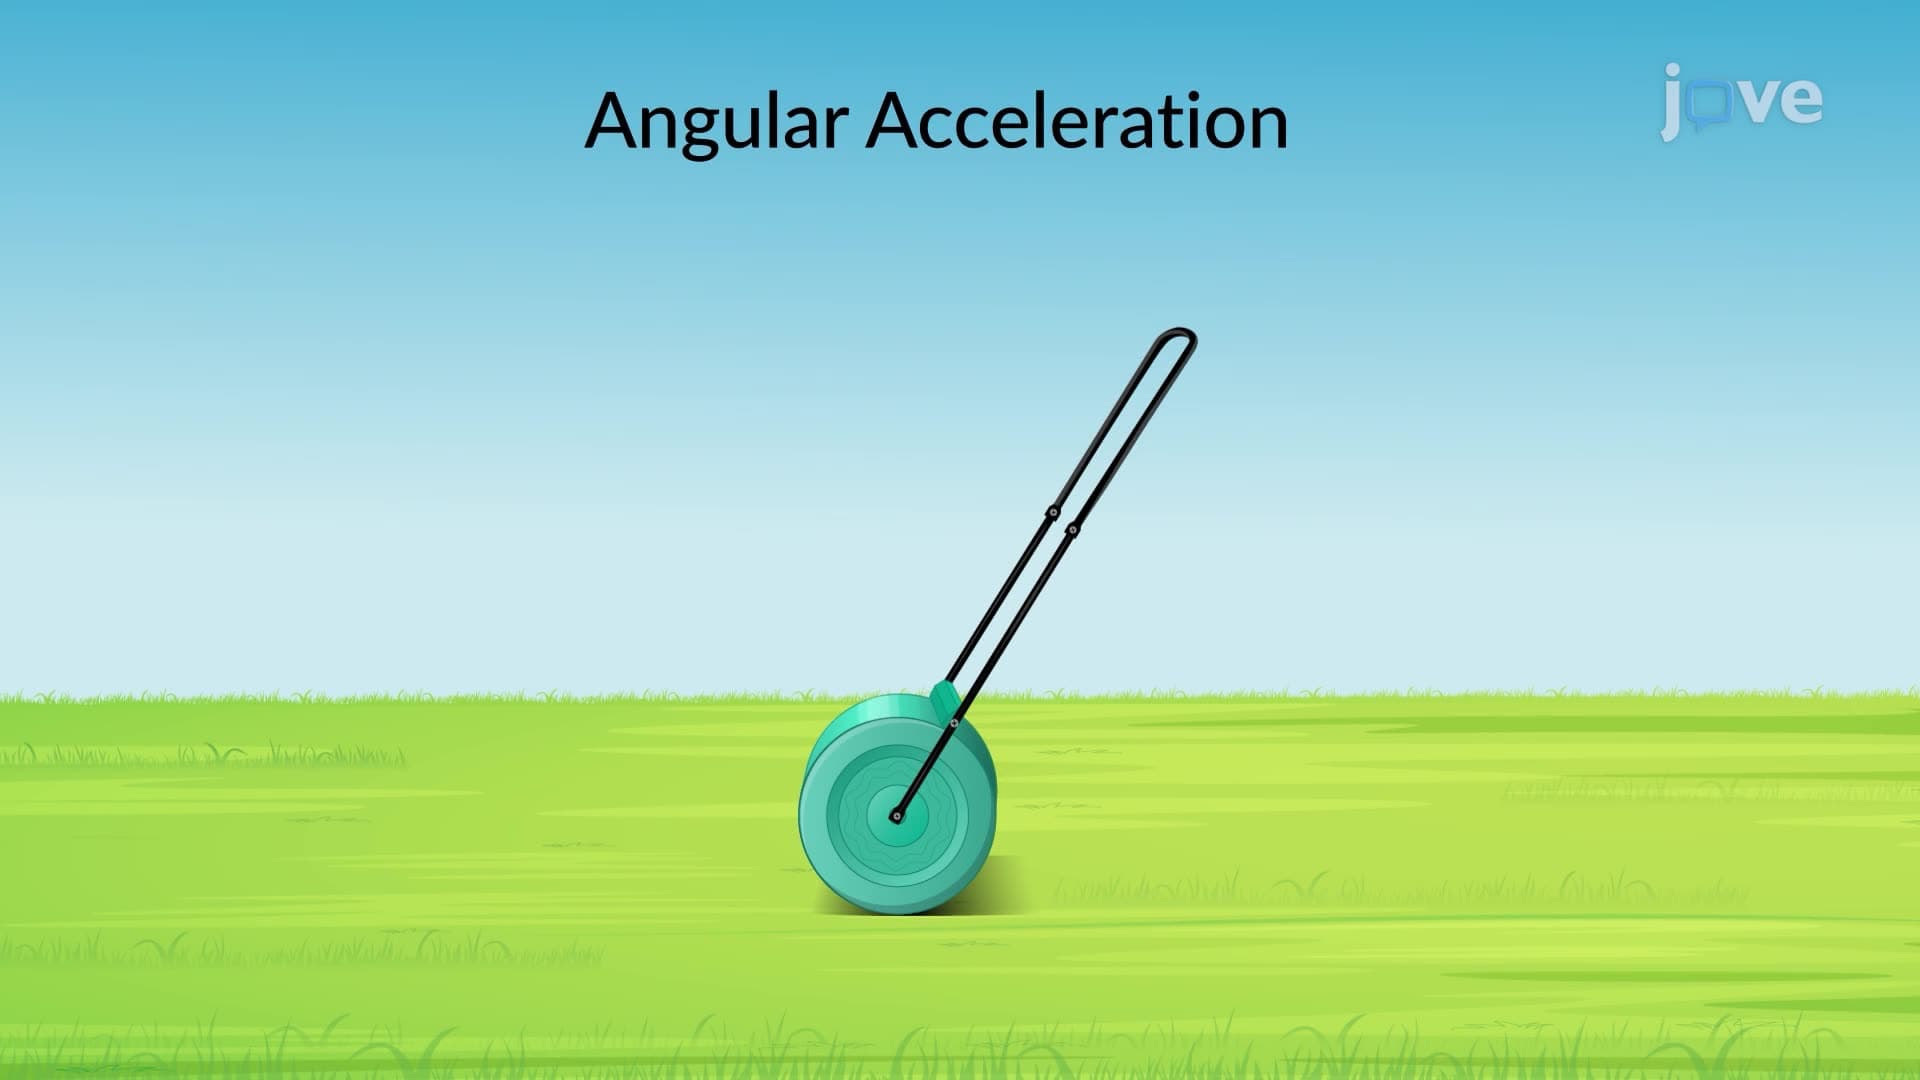
Consider a lawn roller with a mass of 100 kg, a radius of 0.2 meters, and a radius of gyration of 0.15 meters. A force of 200 N is applied to this roller, angled at 60 degrees from the horizontal plane. What will be the angular acceleration of the lawn roller?
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
204