

使用Takagi-Sugeno模糊模型增强反转的稳定性控制,具有干扰拒绝和输入输出约束
Thi-Van-Anh Nguyen1, Bao-Trung Dong2, Ngoc-Tam Bui3
1Hanoi University of Science and Technology, Hanoi, 11615, Vietnam. anh.nguyenthivan1@hust.edu.vn.
Scientific reports
|September 2, 2023

概括
这项研究通过优化模糊规则和使用Lyapunov定理来稳定,增强了Takagi-Sugeno (T-S) 旋转倒置的模糊控制. 它通过干扰拒绝和输入/输出约束实现了强大的控制.
科学领域:
- 控制系统工程 控制系统工程
- 模糊逻辑系统 模糊逻辑系统
- 机器人技术 机器人技术 机器人技术
背景情况:
- 塔卡吉-苏杰诺 (T-S) 模糊模型在控制系统中得到广泛应用.
- 在优化TS模型参数和确保稳定性方面存在挑战.
- 利亚普诺夫定理和线性矩阵不等式 (LMI) 为强大的控制提供了潜在的解决方案.
研究的目的:
- 为了应对TS模糊系统中的控制挑战.
- 为了优化前提变量选择和模糊规则准确性.
- 通过使用集成控制策略,实现旋转倒置摆形 (RIP) 的强大稳定性.
主要方法:
- 用莱普诺夫定理进行稳定性分析.
- 开发了一个基于LMI的理论,用于干扰排斥.
- 在复审期间对输出角度和控制输入施加了约束.
- 集成的TS模糊控制与干扰拒绝和约束.
主要成果:
- 成功确定了TS模型的最佳前提变量和准确的模糊规则.
- 使用基于LMI的定理实现了有效的干扰排斥.
- 在通过综合方法控制复审期方面表现出强大的稳定性.
- 模拟结果验证了拟议的控制方法的有效性.
结论:
- 结合TS模糊控制,干扰排斥和输入/输出约束的综合方法确保了RIP控制的稳定性.
- 提出的方法是高效和有效的,通过广泛的模拟验证.

相关概念视频
 01:28
Stability
155
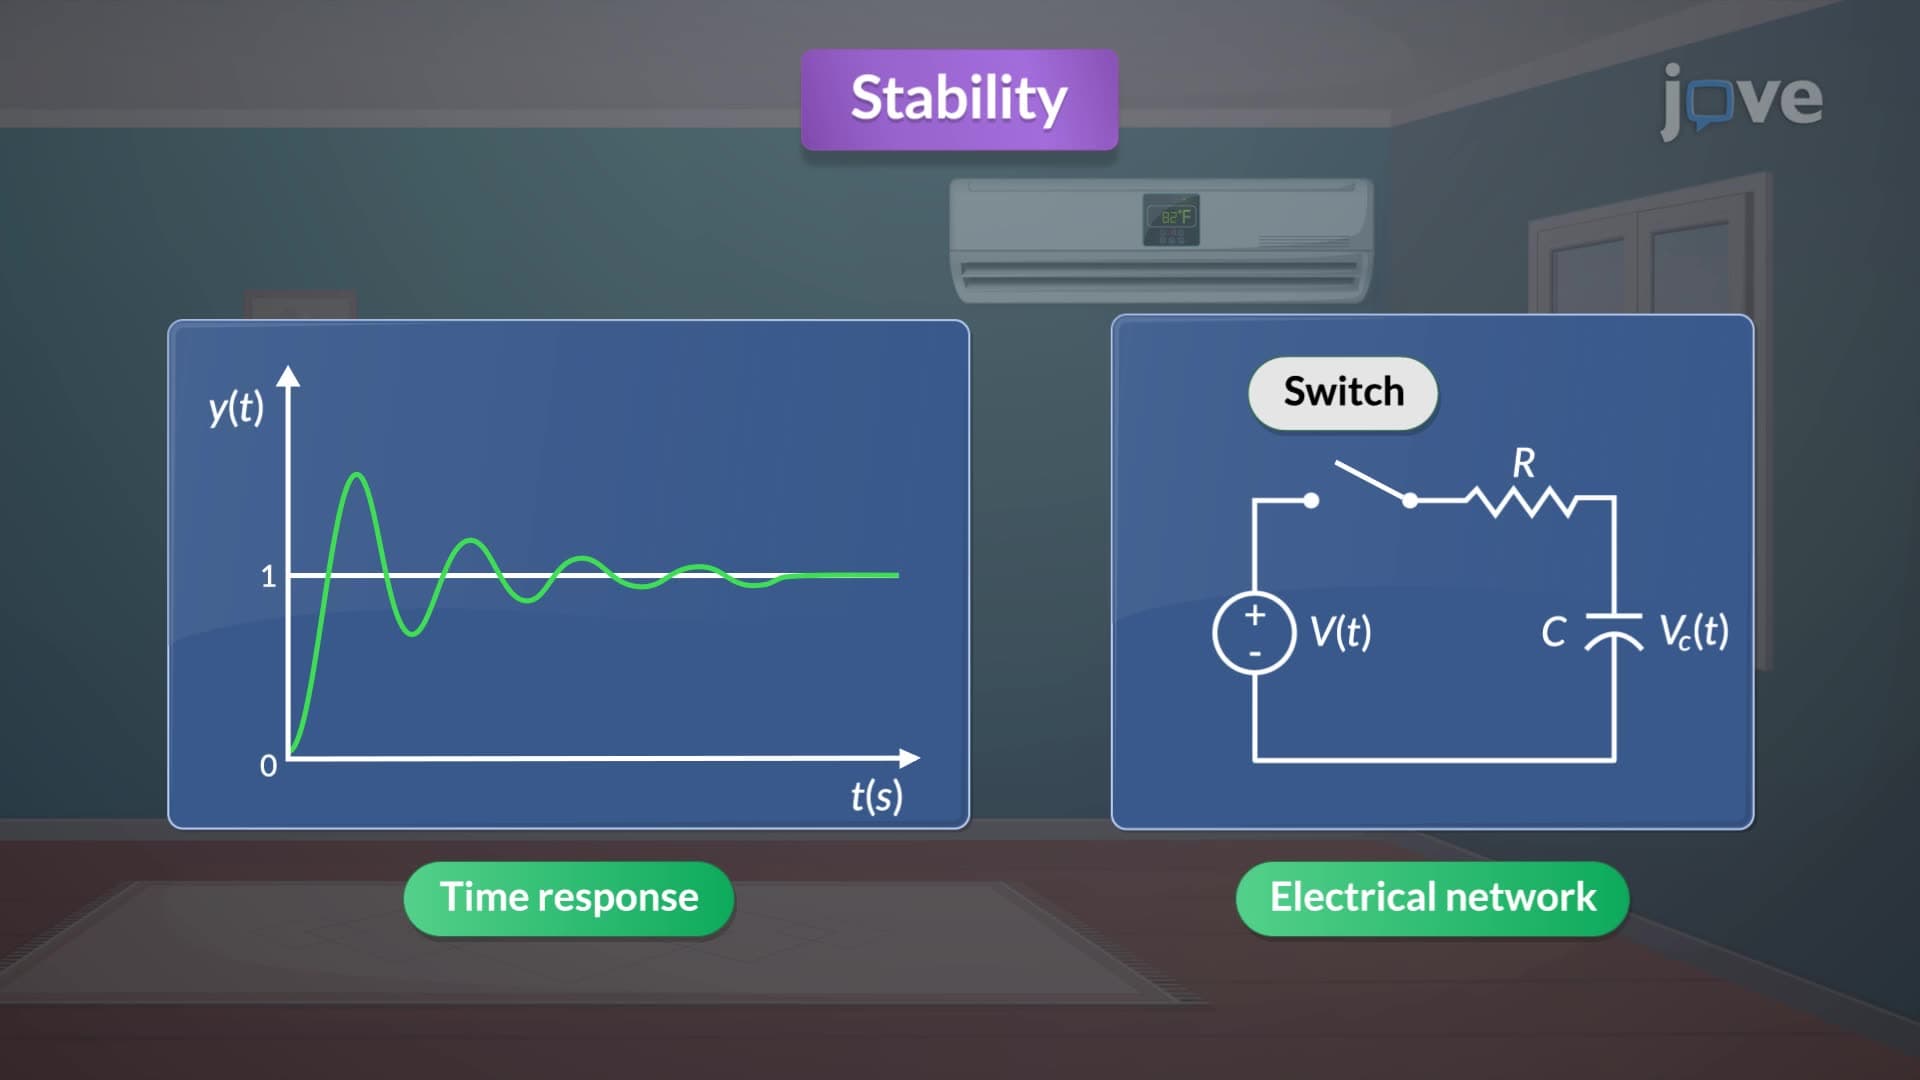
The time response of a linear time-invariant (LTI) system can be divided into transient and steady-state responses. The transient response represents the system's initial reaction to a change in input and diminishes to zero over time. In contrast, the steady-state response is the behavior that persists after the transient effects have faded.
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
155
 01:24
Pole and System Stability
325
The transfer function is a fundamental concept representing the ratio of two polynomials. The numerator and denominator encapsulate the system's dynamics. The zeros and poles of this transfer function are critical in determining the system's behavior and stability.
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
325
 01:21
Linear Approximation in Time Domain
100
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
100
 01:21
Control System Problem
144
In an open-loop system, such as a basic thermostat, the poles of the transfer function influence the system's response but do not determine its stability. However, when feedback is introduced to form a closed-loop system, such as an advanced thermostat that adjusts heating based on room temperature, stability is governed by the new poles of the closed-loop transfer function.
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
144
 01:14
Stability of structures
195
In mechanical engineering, the stability of systems under various forces is critical for designing durable and efficient structures. One fundamental way to explore these concepts is by analyzing systems like two rods connected at a pivot point, O, with a torsional spring of spring constant k at the pivot point. This system is similar in appearance to a scissor jack used to change tires on a car. In this case, the arms of the linkage (equivalent to the rods in this system) are entirely vertical,...
195
 01:07
Time-Domain Interpretation of PD Control
140
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
140