一个异步线性波器架构用于混合事件摄像头
相关实验视频
Updated: Jul 17, 2025
10:56
Long-term Behavioral Tracking of Freely Swimming Weakly Electric Fish
Published on: March 6, 2014
12.6K
IEEE transactions on pattern analysis and machine intelligence
|September 4, 2023

概括
本研究介绍了一种异步线性过架构,该架构将事件和相机数据融合为高动态范围 (HDR) 视频重建. 这种新的方法显著提高了图像质量,并使实时机器人视觉应用成为可能.
科学领域:
- 计算机视觉 计算机视觉
- 机器人技术 机器人技术 机器人技术
- 传感器融合式传感器
背景情况:
- 事件摄像头在高动态范围 (HDR) 和运动方面表现出色,但在静态场景方面却很难.
- 传统的图像传感器在静态场景中表现良好,但受到HDR和运动的限制.
- 现有的方法往往无法利用这两种传感器类型的互补优势.
研究的目的:
- 开发一种新的异步线性过架构,用于融合事件和相机数据.
- 为了实现实时机器人系统的强大的HDR视频重建和空间卷积.
- 利用事件和基于的传感模式的优势.
主要方法:
- 提出了一个异步线性过架构,集成一个状态来编码图像信息.
- 状态由来自事件和摄像头的传入数据异步更新.
- 该架构支持后续视觉模块的实时读取,并集成空间卷积内核.
主要成果:
- 拟议的AKF管道显著优于HDR视频重建中的最先进方法.
- 实现了69.4%的绝对强度误差减少和35.5%的图像相似性指数的改善.
- 证明了高斯,索贝尔和拉普拉斯空间内核的成功集成.
结论:
- 开发的架构有效地融合了事件和摄像头数据,以实现卓越的HDR视频重建.
- 该系统为实时机器人视觉任务提供了多功能和高效的解决方案.
- 这种融合方法克服了单个传感器类型的局限性,增强了视觉数据处理.

相关概念视频
 01:10
Reconstruction of Signal using Interpolation
234
Signal processing techniques are essential for accurately converting continuous signals to digital formats and vice versa. When a continuous signal is sampled with a period T, the resulting sampled signal exhibits replicas of the original spectrum in the frequency domain, spaced at intervals equal to the sampling frequency. To handle this sampled signal, a zero-order hold method can be applied, which creates a piecewise constant signal by retaining each sample's value until the next...
234
 01:23
Linear time-invariant Systems
287
A system is linear if it displays the characteristics of homogeneity and additivity, together termed the superposition property. This principle is fundamental in all linear systems. Linear time-invariant (LTI) systems include systems with linear elements and constant parameters.
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
287
 01:25
Active Filters
856
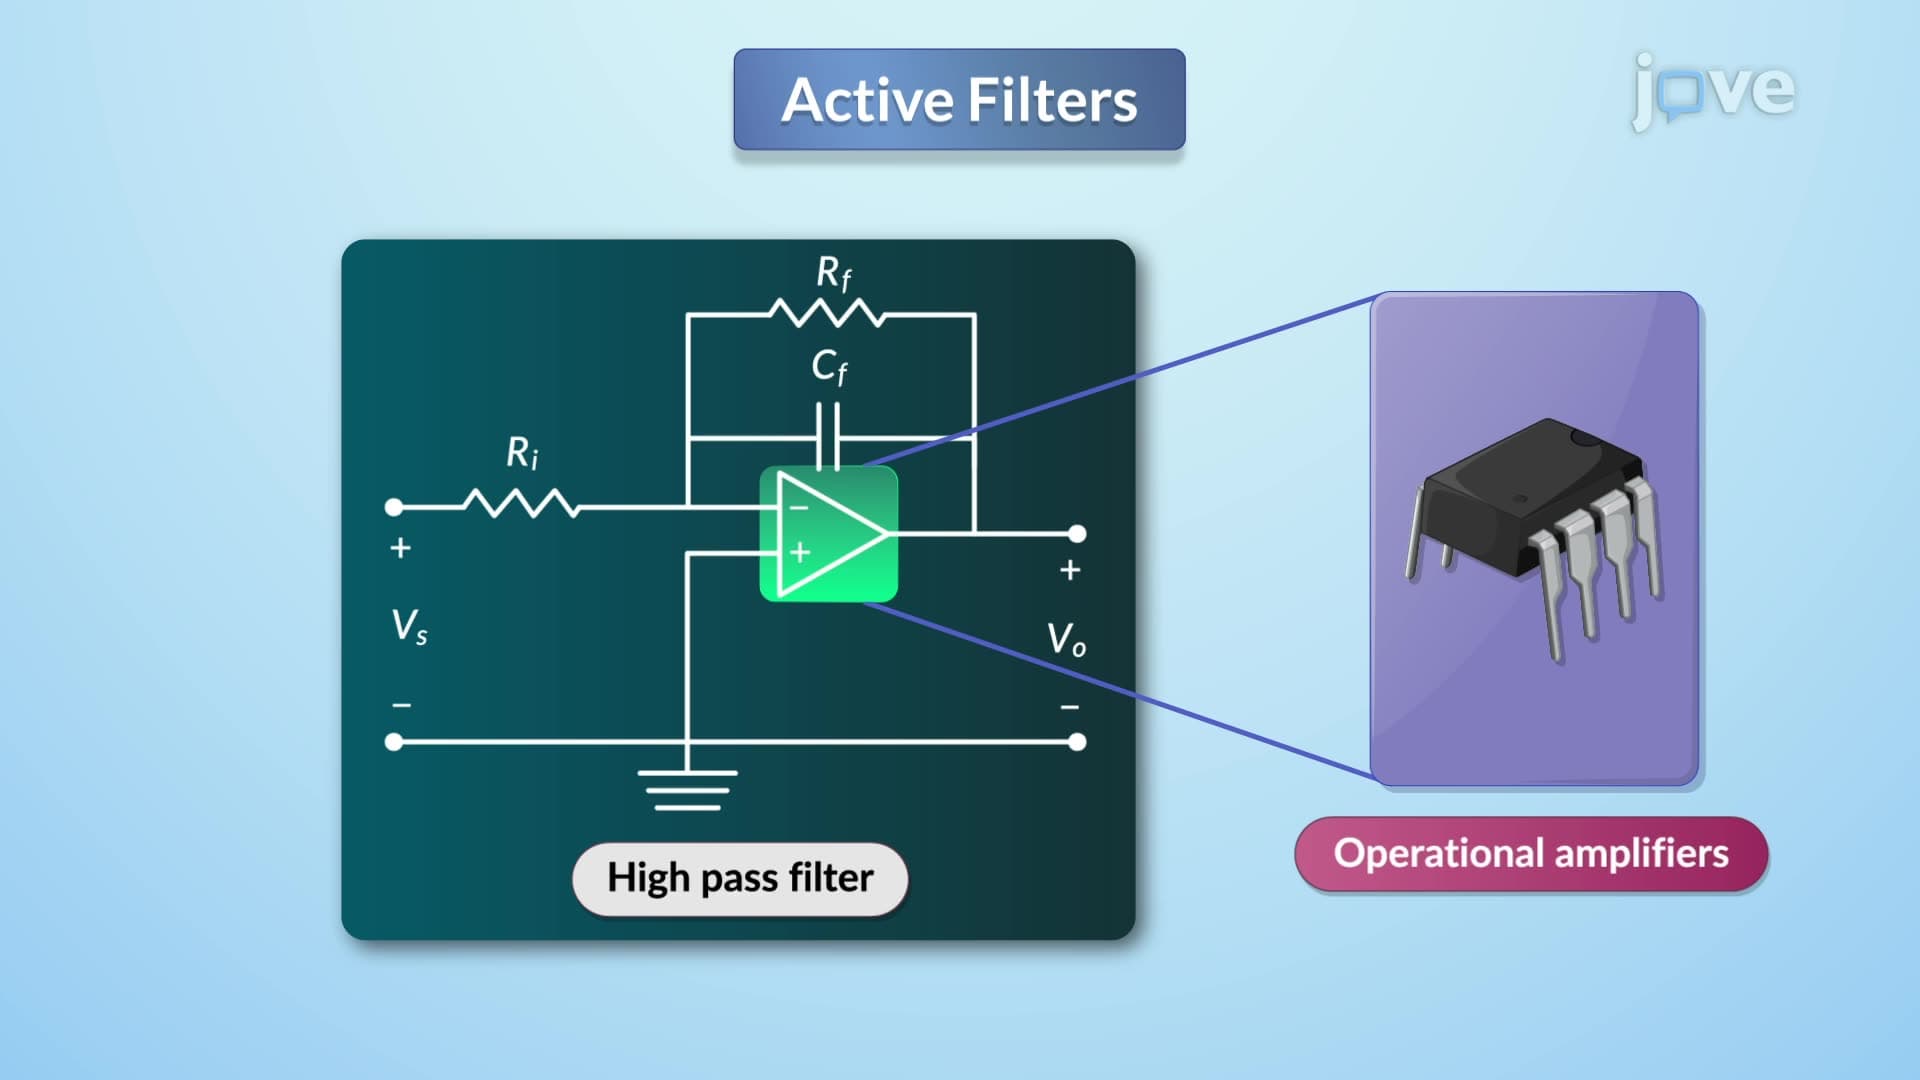
Active filters are electronic circuits that use operational amplifiers (op-amps), resistors, and capacitors to filter out unwanted frequency components from a signal. A first-order low-pass active filter is designed to pass signals with a frequency lower than a certain cutoff frequency and attenuate frequencies higher than that cutoff frequency. The transfer function for a first-order low-pass active filter is:
856
 01:22
Upsampling
261
Managing signal sampling rates is essential in digital signal processing to maintain signal integrity. A decimated signal, characterized by a reduced frequency range due to its lower sampling rate, can be upsampled by inserting zeros between each sample. This upsampling process expands the original spectrum and introduces repeated spectral replicas at intervals dictated by the new Nyquist frequency. To refine this zero-inserted sequence, it is passed through a lowpass filter with a cutoff...
261
 01:27
Passive Filters
562
Passive filters are utilized to shape the frequency spectrum of signals across a diverse array of applications. These filters, using only passive elements like resistors (R), inductors (L), and capacitors (C), are capable of selectively allowing or blocking certain frequency ranges without the need for external power sources.
Low-Pass Filters
Low-pass filters are designed to transmit signals with frequencies lower than the cutoff frequency, ωc, and attenuate those above it. The cutoff...
Low-Pass Filters
Low-pass filters are designed to transmit signals with frequencies lower than the cutoff frequency, ωc, and attenuate those above it. The cutoff...
562
 01:26
Linear Approximation in Frequency Domain
110
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
110